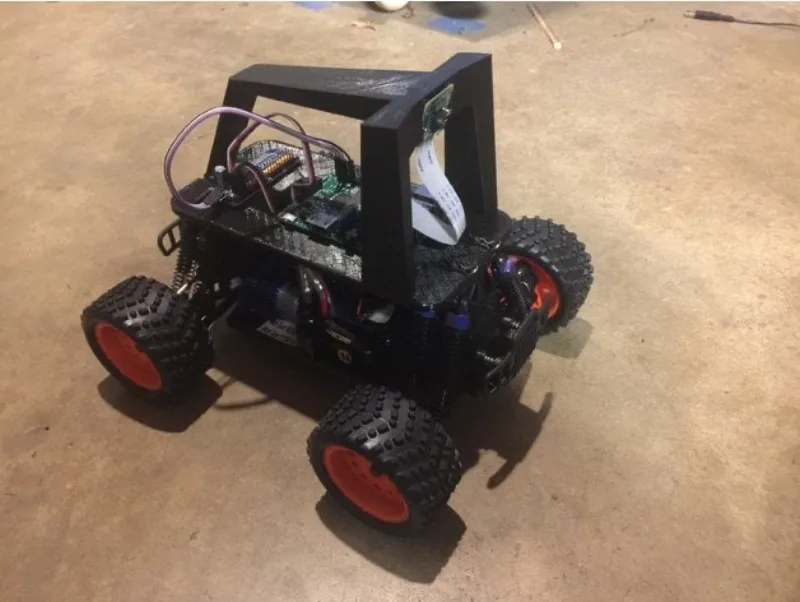
A self-driving RC car platform that puts a Raspberry Pi or Jetson, a camera and a servo driver on a hobby-grade 1/16 scale RC car. A Python library records driving data and trains neural networks that steer the car around a track. It is widely used in community races and classes.
At a glance
| Parts cost | $250–$300 project · The project gives a range of about $246 to $303, excluding 3D-printed parts source ↗ |
|---|---|
| Difficulty | 2/5 Easy · Bolt-on hardware onto a ready-to-run RC car, but the software install and model training need comfort with Linux and Python. |
| Build time | Not stated |
| Tools needed | 3D printer for roll cage and top plate (or buy printed parts), screwdriver, M2.5 screws, no soldering in the standard build |
| Motors | The RC car's own steering servo and ESC-driven motor (WLToys 144010, HSP 94186 or Exceed models) |
| Controller | Raspberry Pi (Pi 5 recommended) or NVIDIA Jetson Nano, PCA9685 servo driver |
| Sensors | Wide-angle camera; optional lidar, IMU, GPS, OAK-D |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✓ Video MkDocs website + GitHub, STLs on Thingiverse, YouTube build videos, Discord |
| Activity | Last update 2026-08-17 · 3,513 GitHub stars · Discord, regular DIY Robocars races; 1,368 GitHub forks |
| Kits | Donkey Store sells printed parts/kits; Waveshare PiRacer Pro is a supported pre-built car |
Licenses
| Design files | CC BY 4.0 ("Donkey Chassis and Adapters" STLs on Thingiverse) source ↗ |
|---|---|
| Code | MIT source ↗ |
| Documentation | None found (autorope/donkeydocs repo has no LICENSE file and the docs site shows no license) source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- Raspberry Pi OS Trixie (Debian 13, Python 3.13) wasn't supported as of early 2026 and the pip install failed, so maintainers advised staying on Bookworm. source ↗
- The developer install instructions briefly had a typo that pulled the PC dependency set on the Pi. The correct extra for a Pi is pi,dev rather than pc,dev. source ↗
- The Adafruit_PCA9685 servo-driver library used by Donkey Car is deprecated, and a 2026 pull request moves it to the CircuitPython driver. Older SD-card images and guides may still reference the old library. source ↗
- Some supported trucks (Desert Monster, Blaze, Short Course) need extra printed adapters to mount the top plate, and the docs warn 1/16 scale cars are fast and heavy enough to damage themselves indoors. source ↗
Other wheeled plans
- LeKiwi · $480 · difficulty 2/5
- OpenBot (smartphone robot) · $50 (2020) · difficulty 2/5
- XLeRobot · $660 · difficulty 3/5
- F1TENTH (RoboRacer) autonomous race car · $3,000 · difficulty 3/5
- OpenMower · $790 · difficulty 3/5
- Upkie wheeled biped · $4,600 · difficulty 4/5
- TidyBot++ · $5,200–$6,300 (2024) · difficulty 4/5
- NVIDIA JetBot · $640 (2024) · difficulty 2/5
- MuSHR racecar · $1,100 (2022) · difficulty 3/5