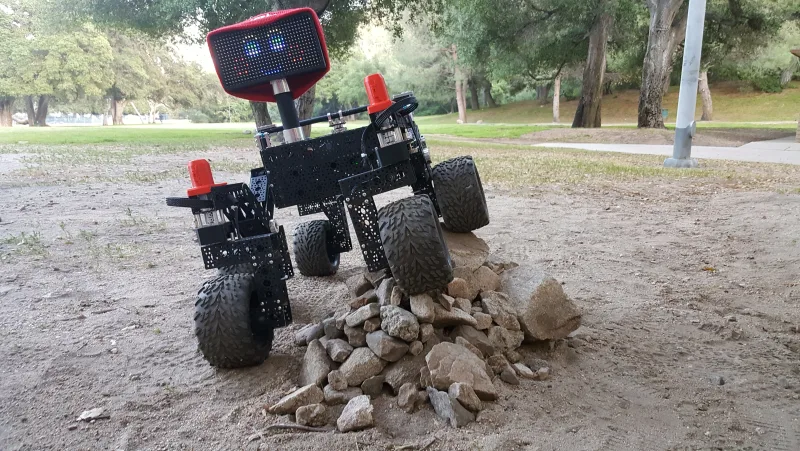
A six-wheel, roughly half-meter scale model of JPL's Mars rovers, built almost entirely from goBILDA aluminum parts with a rocker-bogie suspension, differential pivot and four steerable corner wheels. A Raspberry Pi running ROS drives ten motors through a custom two-layer control PCB that the builder solders. It is aimed at school teams and serious hobbyists who want a rugged outdoor platform.
At a glance
| Parts cost | $1,400 project · Total of the project's auto-generated parts list, before shipping and the 15% goBILDA education discount. The README rounds it to about $1,600 source ↗ |
|---|---|
| Difficulty | 4/5 Advanced · Large parts order, soldering a custom control PCB, ROS setup and an estimated 100+ hours of build time, though no machining is required. |
| Build time | No less than 100 person-hours source ↗ |
| Tools needed | Soldering (control PCB with through-hole parts, XT30 headers), hex keys, pliers, wire strippers, multimeter, optional 3D printer and laser cutter for body plates (online services possible), no metal machining for the base version |
| Motors | 6 goBILDA 5203 Yellow Jacket planetary gear motors with encoders (drive) + 4 goBILDA 2000-series servos (steering) |
| Controller | Raspberry Pi with custom JPL control board (motor board + brain board, RoboClaw motor controllers) |
| Sensors | Wheel encoders, INA260 current/voltage sensing on the board; camera/IMU/lidar are optional add-ons |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✗ Video GitHub markdown mirrored to a ReadTheDocs site, Onshape CAD, KiCad PCB files |
| Activity | Last update 2026-09-03 · 9,678 GitHub stars · Slack workspace (community-run, not official JPL); 1,510 GitHub forks |
| Kits | No full commercial kit found; parts are ordered from goBILDA and Digikey (unconfirmed whether any vendor sells a complete kit) |
Licenses
| Design files | Apache-2.0 (repo-wide LICENSE.txt, Copyright Caltech; OSHWA certification US002551 lists hardware license as "Other") source ↗ |
|---|---|
| Code | Apache-2.0 source ↗ |
| Documentation | Apache-2.0 (same repo-wide license; OSHWA lists docs license as "Other") source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- The README quotes roughly $1600, while the auto-generated parts list totals about $1421 before shipping. goBILDA prices change without notice, and schools can apply for a 15% goBILDA education discount before ordering. source ↗
- The control board guide covers board revision v2.0.3, but its photos were taken on a v2.0.1 board. The written steps take priority where they differ. source ↗
- The current design is a major revision. Builders following older community guides or videos should check the v3.1.0 tag, since earlier rovers used different parts and electronics. source ↗
- The older standalone DROK voltmeter could not be read by the Pi, so maintainers moved current and voltage sensing onto the control board. They kept the sensor as a through-hole-friendly module because surface-mount soldering was judged too hard for beginners. source ↗
Other rovers plans
- Sawppy the Rover · $500 (2018) · difficulty 3/5
- ExoMy · $280–$560 (2020) · difficulty 3/5