Mechanical assembly is shown in a handful of photos plus the FreeCAD model rather than written steps.
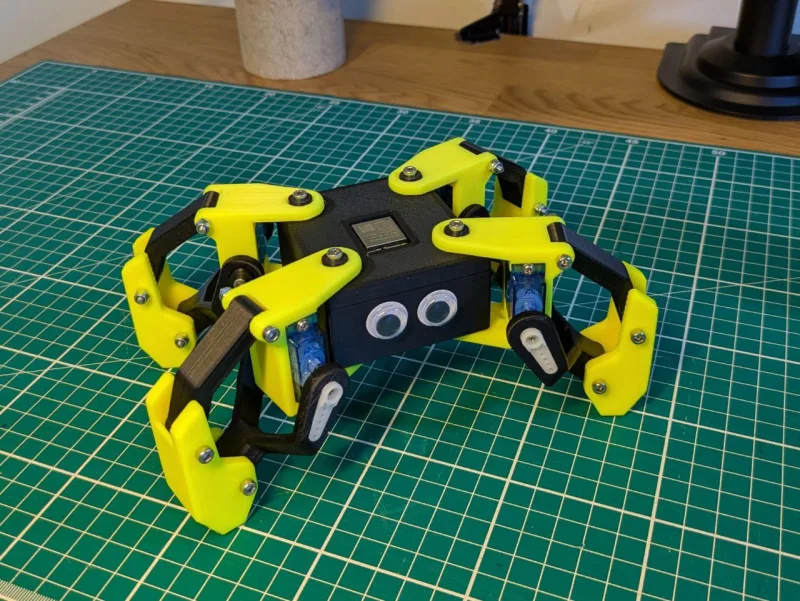
Kame32 is a small 3D-printed quadruped with eight micro servos and parallelogram legs that keep the feet level, a redesign of the 2016 MiniKame by Javier Isabel. An ESP32 on a small custom board runs oscillator-based walking gaits and gamepad control. Frames are provided for either SG90 or MG90S servos.
At a glance
| Parts cost | $90–$100 estimated How Estimated for this page from current retail prices (2026-10-02) of the parts in the project parts list source ↗ Build priced Standard build with protoboard shield; low = SG90 servos, high = MG90S servos Not included 3D printing, tools, shipping, tax; custom PCB order (protoboard priced instead) |
|---|---|
| Difficulty | 2/5 Easy · Few parts and simple through-hole soldering, though the body is tightly packed. |
| Build time | Not stated |
| Tools needed | 3D printer (small parts, about 25 pieces), soldering (protoboard shield or Kame32 PCB), small screwdrivers |
| Motors | 8 SG90 or MG90S micro servos |
| Controller | ESP32 30-pin dev board on a custom Kame32 PCB or protoboard |
| Sensors | None |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✓ Video Author's website (parts list, step-by-step PCB assembly, wiring diagram, body assembly photos) + GitHub (STL, FreeCAD, KiCad, PlatformIO code) |
| Activity | Last update 2025-11-13 · 130 GitHub stars · Kame32 130 stars; original miniKame 538 stars and 119 forks; also on Printables, Thingiverse, Cults3D and MakerWorld |
| Kits | No kit; the PCB can be ordered from PCBWay |
Licenses
| Design files | CC BY-SA 4.0 (README says the robot is licensed CC BY-SA 4.0; same on Thingiverse) source ↗ |
|---|---|
| Code | GPL-3.0 (LICENSE file in the repo) source ↗ |
| Documentation | CC BY-SA 4.0 for the repo README and photo; none found for the javierih.com build pages source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- Builders found the MG90S frame's horn recesses sized for SG90-style horns. MG90S horns vary between sellers, so some sand the horns to fit. source ↗
- The original M3x6 screws were too short to pass through the bushings, and the author now recommends M3x8 with a revised bushing model. source ↗
- The battery must be a 2S pack with both a 2-pin power lead and a 3-pin balance lead, no larger than about 48x26x12 mm. A 1S cell will not drive the DC-DC converters properly. source ↗
- An open issue reports that capacitors C1 and C2 are missing from the published Gerber files. source ↗
- Body assembly is shown only as a few photos of the inside, so the FreeCAD model is the main reference for putting the legs together. source ↗
Other quadrupeds plans
- Stanford Pupper (servo version) · $900–$1,000 (2024) · difficulty 3/5
- Spot Micro (SpotMicroAI) · $420–$510 · difficulty 3/5
- SpotMicroESP32 Leika · $230–$600 · difficulty 3/5
- Pupper v3 · $2,000 · difficulty 4/5
- ODRI Solo 12 · $7,100 (2022) · difficulty 5/5
- Mini Pupper (MangDang) · $760 · difficulty 2/5
- Dingo Quadruped · $900 · difficulty 3/5
- Stanford Pupper v2.1 (DJI motor version) · $1,600 (2023) · difficulty 4/5
- openDog V3 · $2,800–$3,400 (2023) · difficulty 4/5