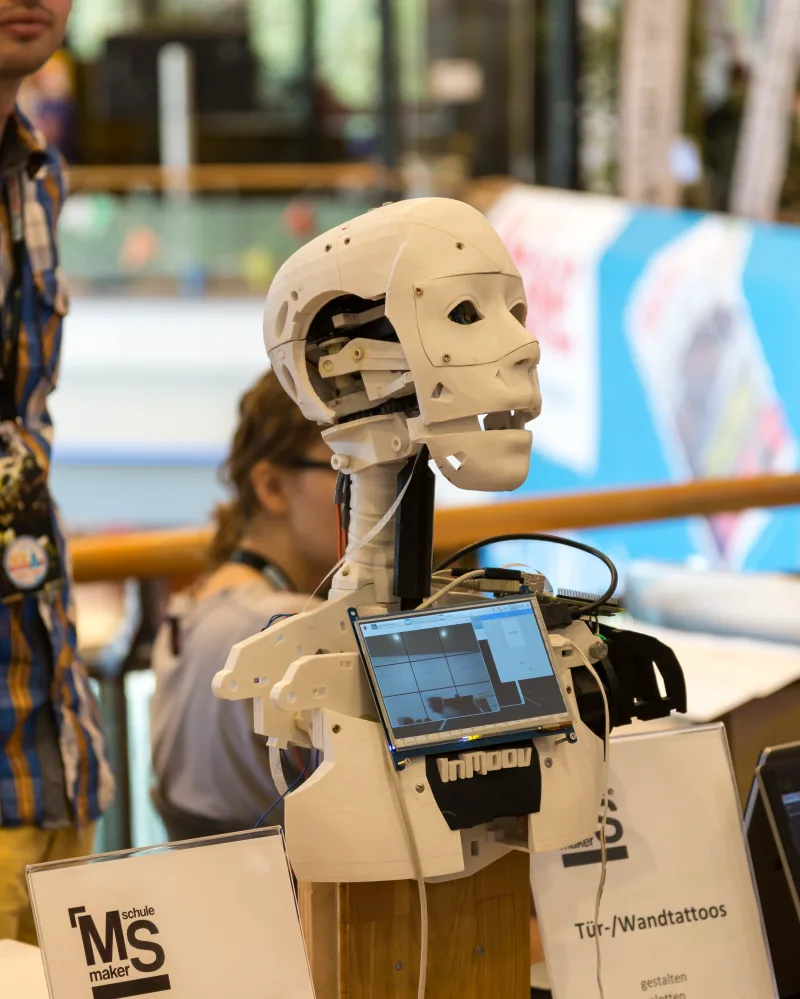
InMoov is a life-size, 3D-printed humanoid upper body created by French sculptor Gael Langevin in 2011, with articulated hands, a moving head with cameras, and arms and torso driven by hobby servos. It is controlled from Arduino boards through the open-source MyRobotLab software, and many builders extend it with speech, vision and Kinect sensing.
At a glance
| Parts cost | $1,300–$1,400 estimated How Estimated for this page from current retail prices (2026-10-02) of the parts in the project parts list source ↗ Build priced Standard InMoov upper body per the Default Hardware Map: both hands/forearms, arms, shoulders, head (jaw, neck, eyes, one camera) and stomach, 33 servos, 2 Arduino Mega + 2 Nervo boards, 6V supply Not included 3D printing (about 4-6 kg ABS), tools, shipping, tax; the PC or tablet running MyRobotLab (assumed owned); optional Kinect/OAK-D, finger pressure sensors, NeoPixels, ultrasonic sensors, i2 head; non-motorized display legs |
|---|---|
| Difficulty | 3/5 Intermediate · No custom PCBs or machining, but a very large print job, dozens of servos and long wiring and calibration work. |
| Build time | Not stated |
| Tools needed | 3D printer with at least a 12 x 12 x 12 cm bed (some leg parts exceed it), ABS preferred, PLA also used; a very large total print volume, soldering and wiring (Arduino Mega/Uno, Nervo boards) |
| Motors | Hobby servos (HK15298B, Hitec HS805BB, MG996) in the hands, arms, neck and torso |
| Controller | Arduino Uno and Mega boards, driven from a PC or tablet running MyRobotLab |
| Sensors | Cameras in the eyes, plus optional Kinect, PIR, ultrasonic and finger sensors |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✓ Video WordPress website with per-part tutorial pages, hardware map, forum, Discord, STL gallery |
| Activity | Last update 2024-12-01 · Forum on inmoov.fr, Google Group, Discord server, Russian and French forums |
| Kits | Parts are sold through the shop on inmoov.fr (contents unconfirmed) |
Licenses
The design license is non-commercial. Building one for personal, educational or research use is allowed, but selling builds, parts or kits is not.
| Design files | CC BY-NC (Creative Commons Attribution-NonCommercial, version not stated on the page) source ↗ |
|---|---|
| Code | Apache-2.0 (MyRobotLab control software) source ↗ |
| Documentation | None found source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- The downloadable parts are licensed non-commercially (CC BY-NC), so printed InMoov parts or robots cannot be sold, and the name InMoov is a trademark. Only the MyRobotLab software is under a permissive license. source ↗
- Despite being called a humanoid, the official legs are a non-motorized version for display, so the robot does not walk. Two thigh parts are larger than the 12 cm cube the rest of the design targets, some leg parts need supports, and the designer suggests printing a calibrator part first and using about -0.15 mm horizontal expansion if parts fit too tightly. source ↗
- The Hitec HS805BB servo used in the shoulders and stomach can be hard to find. In replies on the hardware map page the designer points to the JX PDI-2060MG as a sturdy low-cost substitute, and says the cheaper HK15338 also fits but has lower-quality motor brushes and should be avoided for the omoplate joint. source ↗
- The newest work (i2 head and eyes) was posted in 2024, so the project is still updated, but slowly, and much of the support lives in years of page comments and the forum rather than a versioned repository. source ↗
Other humanoids plans
- ToddlerBot · under $6,000 · difficulty 4/5
- Berkeley Humanoid Lite · under $5,000 · difficulty 4/5
- Poppy Humanoid · $8,500 (2021) · difficulty 3/5
- Asimov 1 (Menlo Research) · $20,000 · difficulty 5/5