The project website and forum are offline, and docs survive on GitHub.
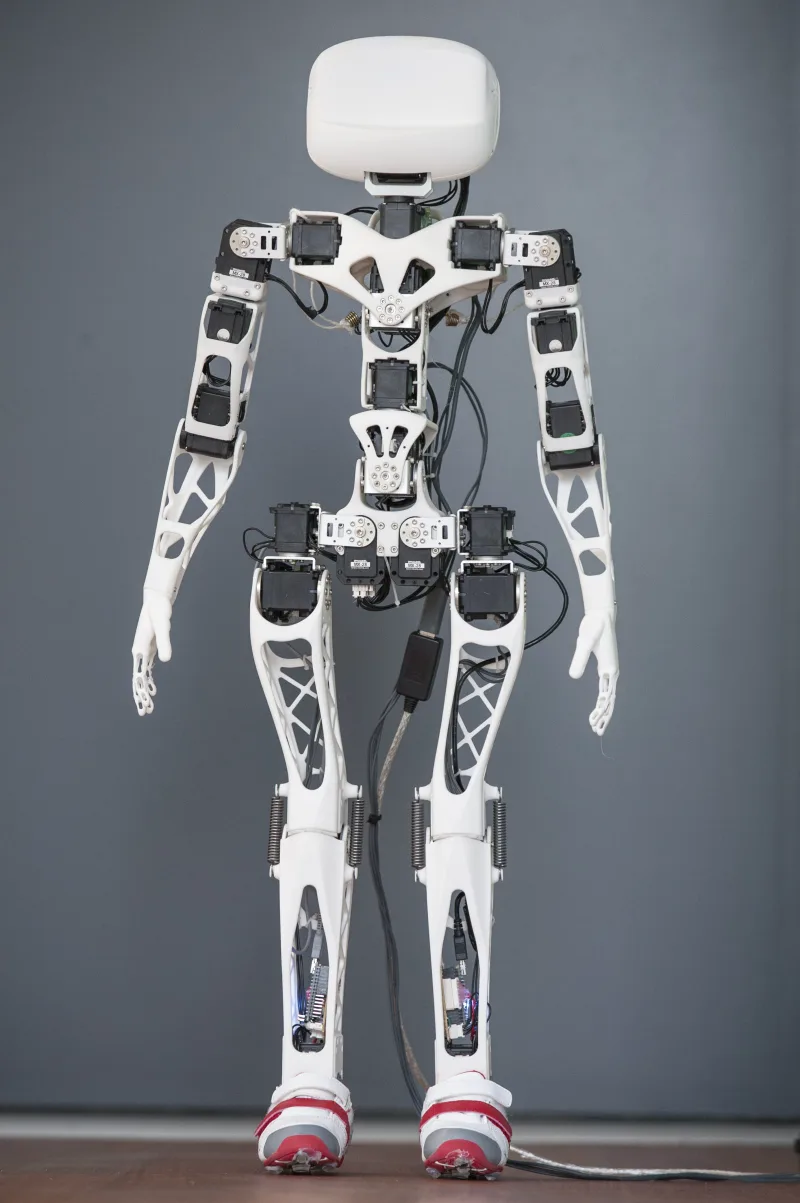
Poppy Humanoid is a 3D-printed humanoid from Inria, built around 25 Dynamixel smart servos and a Raspberry Pi in the head. It was designed for research and education on walking and physical human-robot interaction and is programmed in Python.
At a glance
| Parts cost | $8,500 (2021) project · The project puts it at roughly $8,000 to $9,000, most of it for the Dynamixel servos source ↗ |
|---|---|
| Difficulty | 3/5 Intermediate · Kit-like assembly with no electronics design, but expensive Dynamixel servos, irreversible horn mounting and a 25-servo bus to configure. |
| Build time | About 7 hours of assembly for an experienced builder (printing not included) source ↗ |
| Tools needed | Printed structural parts (SLS sintering recommended over FDM), hex drivers and thread locker |
| Motors | 25 Robotis Dynamixel servos, mostly MX-28AT plus MX-64AT and one AX-12A |
| Controller | Raspberry Pi 3 or 4 in the head (USB2AX adapters to the servo buses) |
| Sensors | Camera in the head, servo position/load feedback |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✓ Video GitBook docs (source in the poppy-docs GitHub repo, the hosted site is offline) plus GitHub README and releases |
| Activity | Last update 2021-12-06 · 1,070 GitHub stars · Forum and docs domains (poppy-project.org, poppy.discourse.group) no longer resolve as of 2026-10-02; 291 GitHub forks |
| Kits | Kits were sold by Generation Robots, who co-wrote the assembly guide (current availability unconfirmed) |
Licenses
| Design files | CC BY-SA 4.0 source ↗ |
|---|---|
| Code | GPL-3.0 source ↗ |
| Documentation | CC BY-SA 4.0 source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- As of October 2026 the poppy-project.org domain no longer resolves, which takes down the hosted docs and forum linked from the README. The assembly guide and parts list survive as Markdown in the poppy-docs GitHub repository. source ↗
- The original MX-28 servo is obsolete and the guide substitutes the MX-28AT, which has a pre-threaded side. The assembly videos still show the older motors and an older configuration tool, and there is no video for the head. source ↗
- The MX-28 horn is press-fitted, so mounting it out of alignment cannot be undone. The guide also recommends cutting the unused 12 V wire on the cable next to the USB2AX if random servo timeouts appear. source ↗
- A maintainer advises sintered (SLS) parts from a fablab or print service rather than FDM, although some builders have used FDM. The Manga screen in the head is no longer made and a printed fake screen replaces it. source ↗
- The roughly $8,000-9,000 cost is mostly the Dynamixel servos, and the maintainers point to forum threads (now offline) for cheaper-motor experiments, since the design is not drop-in compatible with hobby servos. source ↗
Other humanoids plans
- InMoov · $1,300–$1,400 · difficulty 3/5
- ToddlerBot · under $6,000 · difficulty 4/5
- Berkeley Humanoid Lite · under $5,000 · difficulty 4/5
- Asimov 1 (Menlo Research) · $20,000 · difficulty 5/5