2 robots in the guide · Germany / USA
The Open Dynamic Robot Initiative began as an effort to build a low-cost, low-complexity brushless actuator module for torque-controlled legged robots and manipulators, built mostly from 3D-printed and off-the-shelf parts. Its hardware and software, including the quadruped Solo, are open-sourced under the BSD 3-clause license. The work is a collaboration between the Max Planck Institute for Intelligent Systems, New York University's Tandon School of Engineering and the Gepetto team at LAAS-CNRS. Open Dynamic Robot Initiative ↗
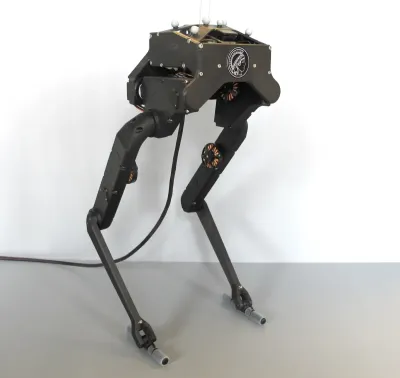 Bolt
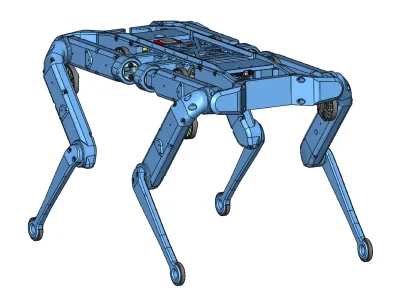 Solo 8 / Solo 12