DIY (open hardware)Built from the ODRI open actuator modules. No kit sold
Not for sale (research)RL walkingOpen hardwareTetheredPoint feet
Not for saleShipping: Build. Not for sale. It can be built from the ODRI files with machined and 3D-printed parts.
Overview
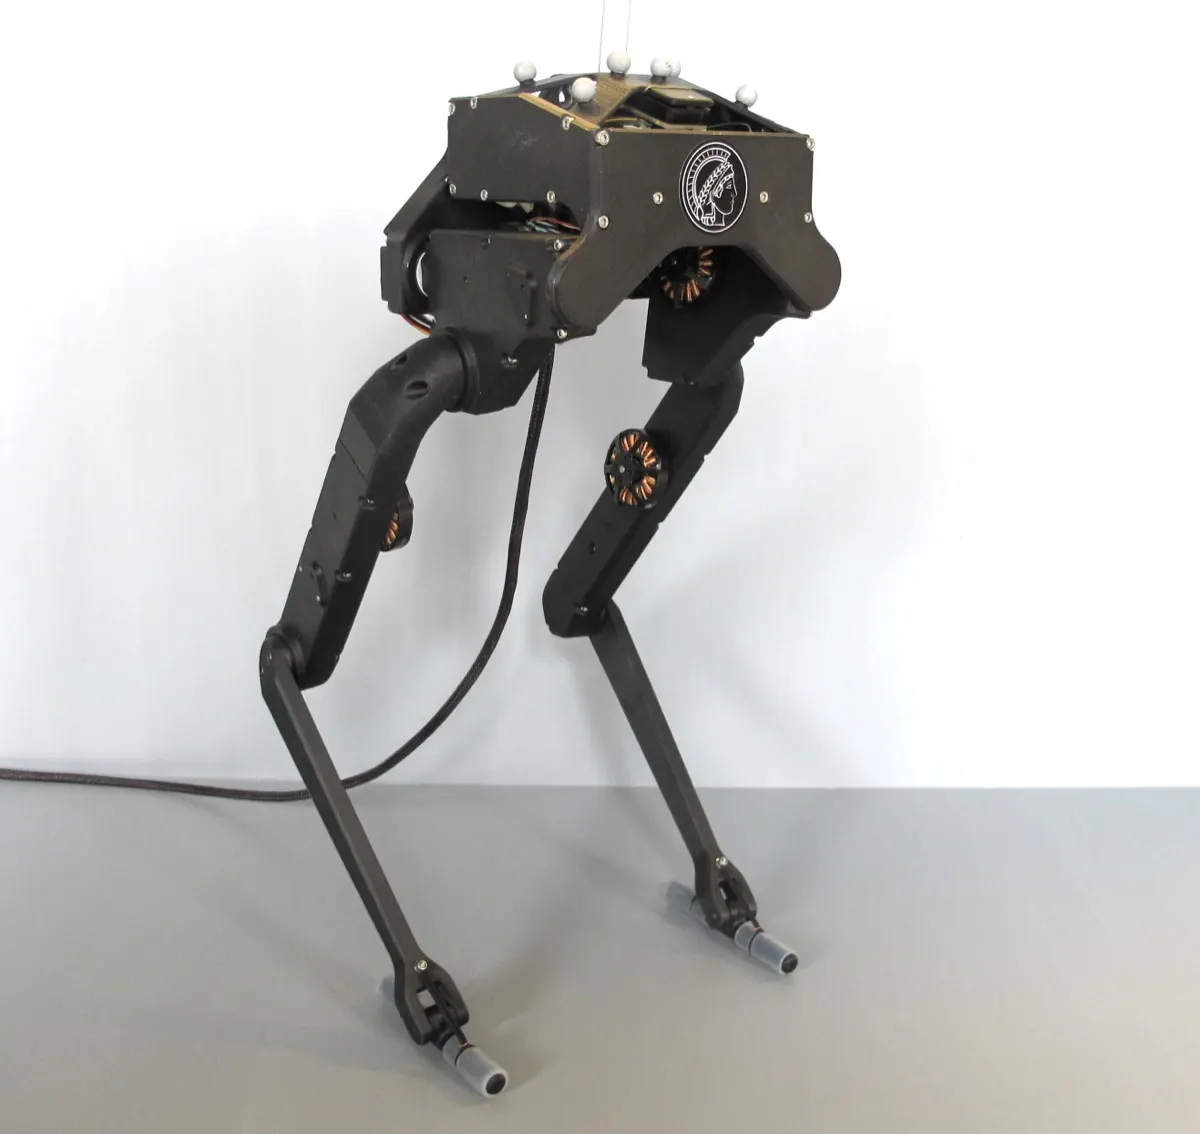
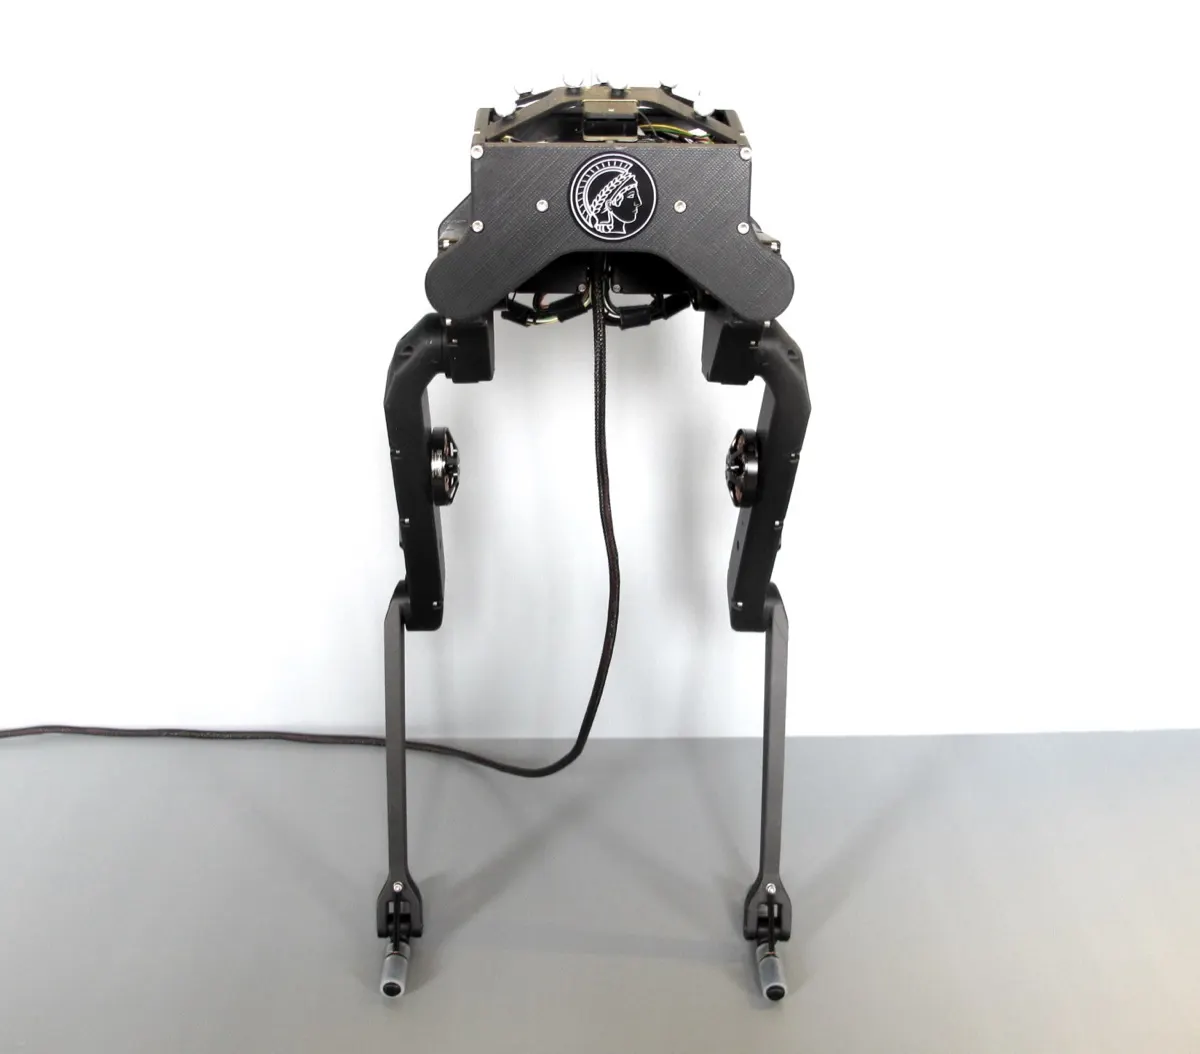
A tiny tethered biped from the Open Dynamic Robot Initiative, the group behind the Solo quadrupeds, built from the same open brushless actuator modules. With no ankle actuation it must constantly step to stay up, which makes it a clean testbed for dynamic balance and learned controllers. Everything, from CAD to electronics, is published.
Specifications
| Category | Bipeds · Research & legacy bipeds |
|---|---|
| Released | 2021 |
| Country | Germany, USA |
| Availability | Not for sale (research) |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Balance type | RL walking |
| Height | Not published |
| Weight | 1.34 kg |
| Compute | Off-board PC via ODRI master board |
| Speed | Not published |
| DOF | 6 (3 per leg, passive ankles) |
| Sensors | IMU, joint encoders |
| Balance | Point-foot dynamic balancing with torque-controlled brushless actuators. Used for MPC and RL research. |
| SDK | Open-source ODRI software (C++/Python), BSD-licensed hardware |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
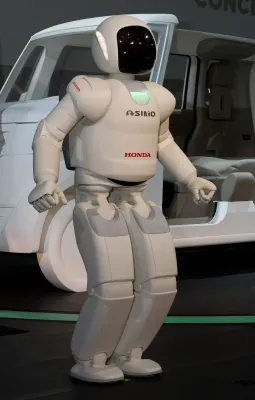 ASIMO (2011 "All-new ASIMO")Honda (Japan)Not for sale
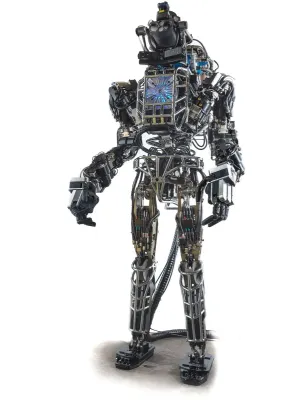 Atlas (hydraulic)Boston Dynamics (USA)Not for sale
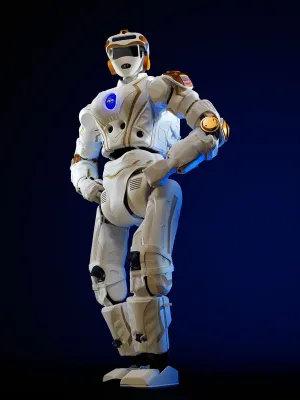 Valkyrie (R5)NASA Johnson Space Center (USA)Not for sale
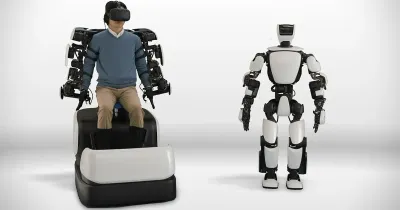 T-HR3Toyota (Japan)Not for sale
 CyberOneXiaomi (China)Not for sale
 Tiangong (Tien Kung)Beijing Humanoid Robot Innovation Center (China)Quote (China)