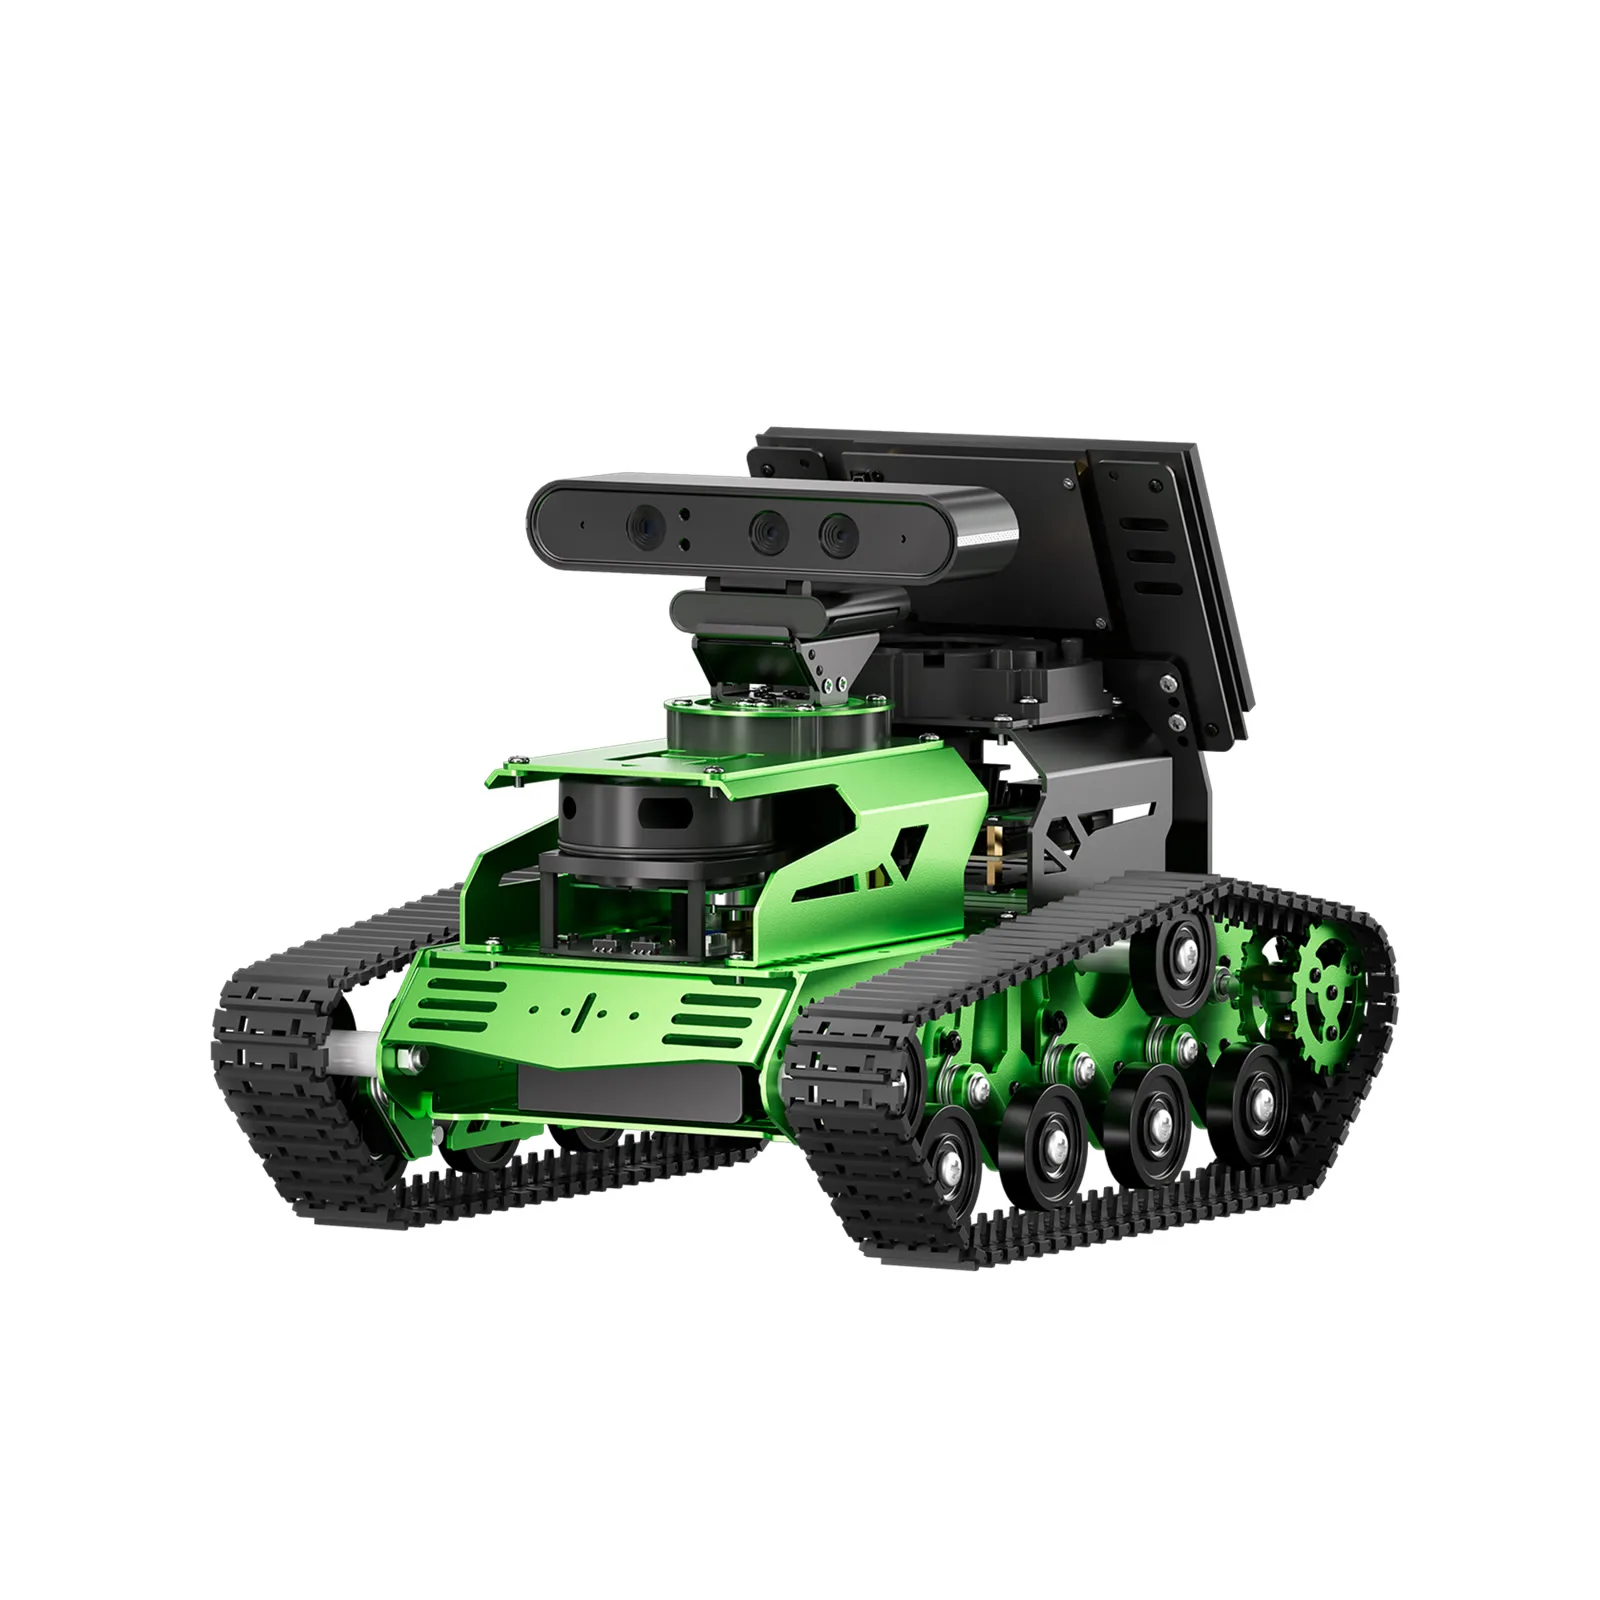
$659.99 – $1,239.99Hiwonder store, October 2026. Every kit includes a Jetson Nano and a choice of SLAMTEC A1 or EAI G4 lidar. Starter $659.99 (A1) or $799.99 (G4) has lidar but no depth camera. Standard $859.99 (A1) or $999.99 (G4) adds the Astra Pro Plus depth camera, so the Standard A1 kit at $859.99 is the cheapest version with depth. Advanced $1,099.99 (A1) or $1,239.99 (G4) adds a 7-inch touch screen and 6-mic array. No Amazon US listing found (unconfirmed).
AvailableVia SSH / web / bridgeTracksJetsonLidarDepth cameraROS 1
Possibly ≤ 1 weekShipping: Next-business-day dispatch, transit not published. Sold by Hiwonder, whose shipping policy says orders are processed within about 24 hours and shipped the next business day, with no transit time given (October 2026). Shipping origin is not stated, likely China (unconfirmed). No Amazon US listing was found (unconfirmed). Hiwonder ↗
Remote control: ROS Melodic on Ubuntu 18.04 runs on the Jetson Nano. Remote access from a laptop through NoMachine or the ROS network, and Hiwonder supplies a virtual machine image for some lessons.
Overview
A tracked ROS robot on a Jetson Nano with lidar, a depth camera on a pan-tilt and an optional screen and mic array. The course covers 2D lidar SLAM, RTAB-Map 3D mapping and navigation with the depth camera, YOLOv5 detection and multi-robot formation. It runs ROS Melodic on Ubuntu 18.04 and no ROS 2 image was found in its docs, so it suits learners who accept ROS 1. For ROS 2 on a similar budget, Hiwonder's JetAuto and JetAcker are the newer options.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2022 |
| Country | China |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Possible via SDK · ROS Melodic and Python on a Jetson Nano. Voice control uses a 6-mic array for wake words, sound source localization and voice navigation, and no official large-model course was found for JetTank. JetTank docs ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | Official model · Hiwonder's JetTank docs include URDF, Gazebo hardware simulation, and Gazebo mapping and navigation lessons. JetTank docs (Simulation Model and URDF) ↗ |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Lidar, Depth camera, Camera |
| Actuators | DC / gear motors |
| Audio | Speaker, Microphone |
| Compute type | NVIDIA Jetson |
| Remote control | Via SSH / web / bridge |
| Size | 31×24.6×26.5 cm, 2.9 kg |
| Drive | Nylon tracks, differential drive, 2 × 520 Hall-encoder DC motors |
| Compute | NVIDIA Jetson Nano (4 GB, unconfirmed) plus Hiwonder ROS expansion board with IMU |
| Vision | Orbbec Astra Pro Plus depth camera, structured light, 0.6–8 m, on a 240° pan-tilt (Standard and Advanced) |
| Lidar | SLAMTEC A1 (0.15–12 m) or EAI G4 (0.12–16 m) 360° 2D lidar, chosen at order |
| Sensors | IMU on the expansion board, motor encoders, 6-mic array and speaker (Advanced kit), 7-inch touch screen (Advanced kit) |
| Runtime | About 60 min (11.1 V 6,000 mAh battery) |
| Speed | Not published (the app's speed setting runs 10–100 cm/s) |
| SDK | Ubuntu 18.04 + ROS Melodic (ROS 1), Python/C/C++/JavaScript. Gmapping, Hector, Karto and Cartographer mapping, frontier and RRT exploration, AMCL with single and multi-point navigation, RTAB-VSLAM 3D mapping and navigation with the depth camera, ORB-SLAM2/3, YOLOv5 with TensorRT, MediaPipe, KCF tracking, multi-robot formation, Gazebo simulation, phone app |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3
Image credits
- Image 1: source (official product image)