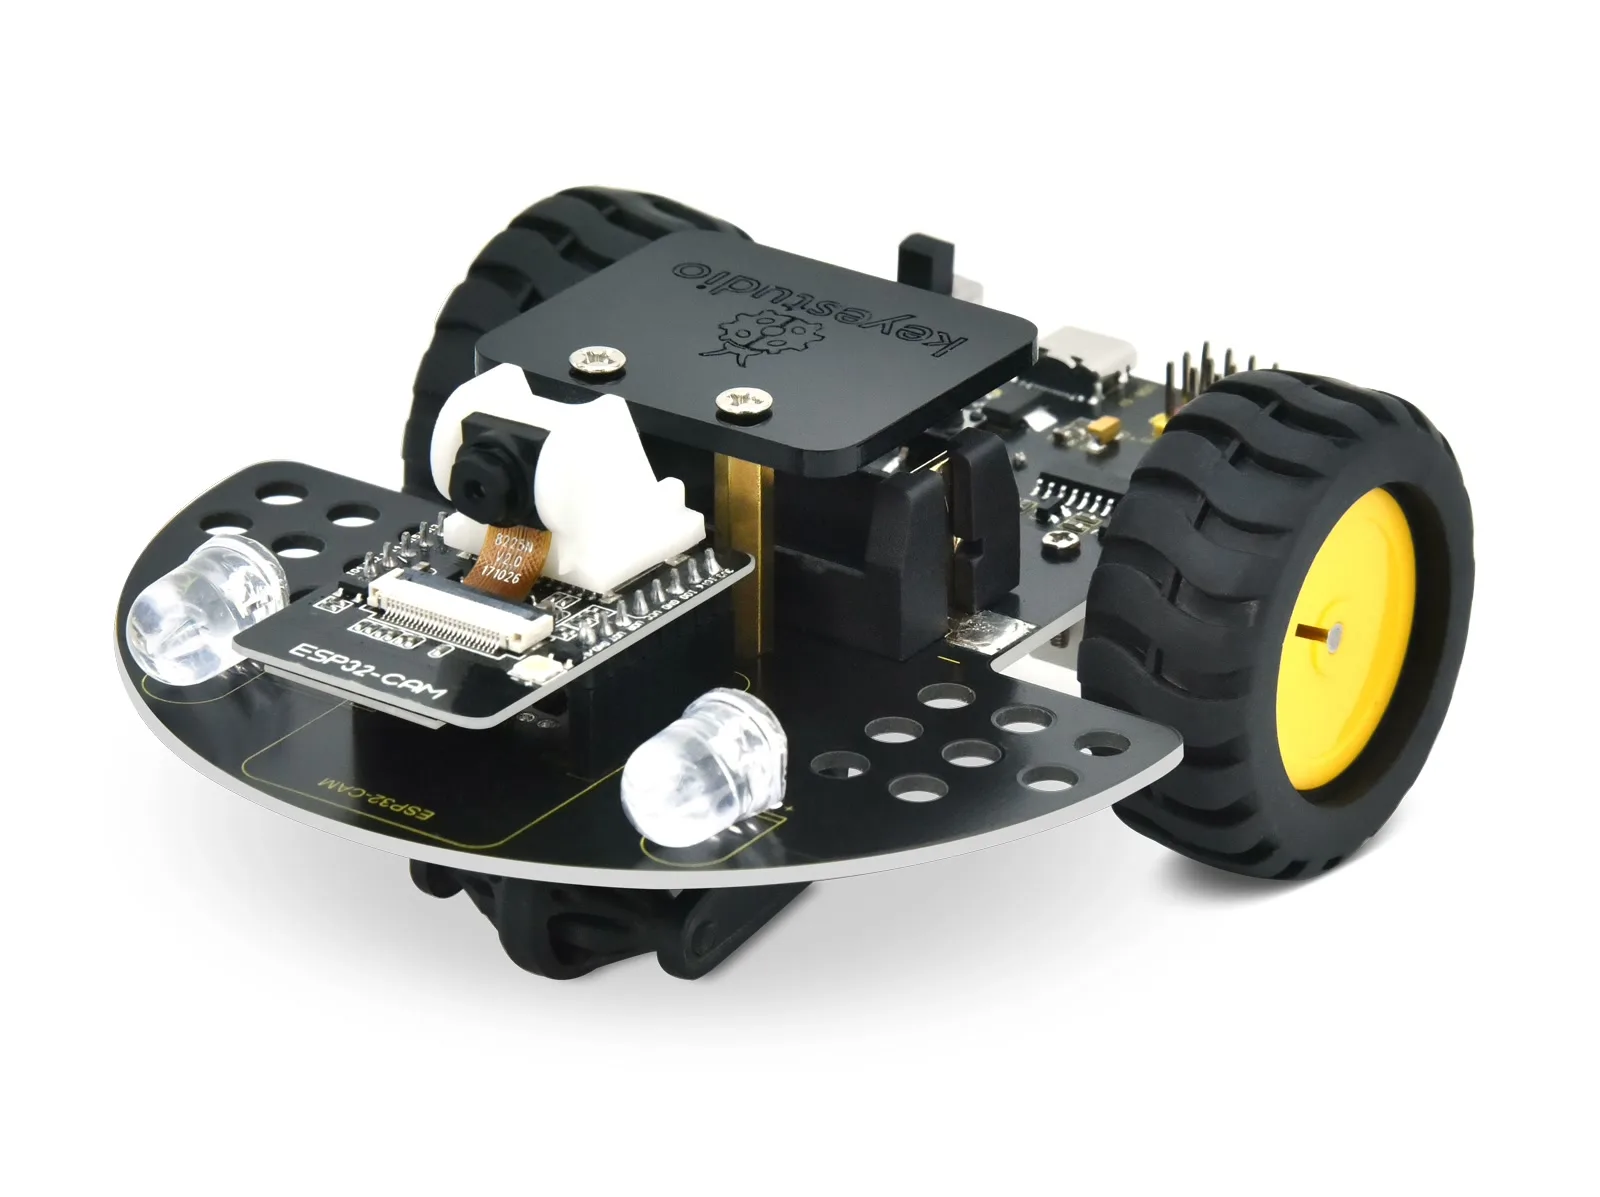
$29.99Amazon US $29.99 and Keyestudio store $32.40 (October 2026). ESP32-CAM board included. The rechargeable 3.7V CR123A (16340) Li-ion cell is not included, though the driver board charges it over USB so no separate charger is needed. Year estimated from the January 2024 image timestamps in the official tutorial (unconfirmed).
AvailableVia SSH / web / bridgeESP32-CAMArduinoCameraWi-FiBudget
≤ 1 weekShipping: 2–3 days (Amazon). Sold by keyes and shipped from Amazon US, in stock in October 2026. Also sold on the Keyestudio web store, which ships from China. Amazon ↗
Remote control: Sketches upload over USB (CH340 serial). The video sketch runs a web server, with MJPEG video at port 81 /stream and drive commands as HTTP GET requests to /control, so a laptop script can grab frames and send moves over Wi-Fi.
Overview
A very small two-wheel camera car where the ESP32-CAM plugs straight into a driver board that also serves as the chassis, so assembly takes minutes. It suits makers who want the cheapest way to get Wi-Fi video and remote driving from an ESP32 and plan to write their own code. The open web-server sketch makes it easy to pull frames into a laptop detector and send drive commands back. There are no other sensors, no pan-tilt, no on-board tracking, and only Arduino IDE lessons, and one Amazon reviewer reported Wi-Fi dropouts when the motors run on the single small cell.
Specifications
| Category | Wheeled rovers · Classroom coding cars |
|---|---|
| Released | 2024 |
| Country | China |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · Open Arduino code and a plain HTTP control endpoint give an LLM something to drive, but Keyestudio supplies no LLM lessons for this kit. |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. |
| Best for | Ages 12+ (estimated) |
| Vision sensors | Camera |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | Driver board (which doubles as the chassis) 115 × 100 mm |
| Drive | 2WD differential drive with 2 small DC gear motors, rubber-tired wheels and a rear caster (motor gearing and wheel diameter not published) |
| Compute | AI-Thinker style ESP32-CAM (ESP32, 4 MB flash, 4 MB PSRAM, Wi-Fi and Bluetooth) on a driver board with CH340C USB serial, an STC8G1K08 helper chip that drives an HR8833 motor driver over I2C, and an ETA9740 charging IC |
| Vision | Fixed forward camera on the ESP32-CAM, held at 90 degrees by a small bracket (likely OV2640, unconfirmed). The sample sketch streams QVGA 320 × 240 JPEG frames |
| Lidar | None |
| Sensors | None beyond the camera. Two LED headlights, four battery-level LEDs, and four spare GPIO pins plus building-block holes for add-ons |
| Runtime | 1 × rechargeable 3.7V CR123A/16340 Li-ion (not included), charged on board over USB, runtime not published |
| Speed | Not published |
| SDK | Arduino IDE (C/C++) sketches with a SetMotor.h library, browser control page served by the car (the earlier app is no longer used) |
Ratings & reviews
Ratings and reviews load on the live site.
Compared side by side
Similar robots
 WeeeBot mini
 mBot
 mBot2 / mBot Neo
 Codey Rocky
 ELEGOO Smart Robot Car Kit V4.0 (with Camera)
 SunFounder GalaxyRVR Mars Rover Kit
Image credits
- Image 1: source (official product image)