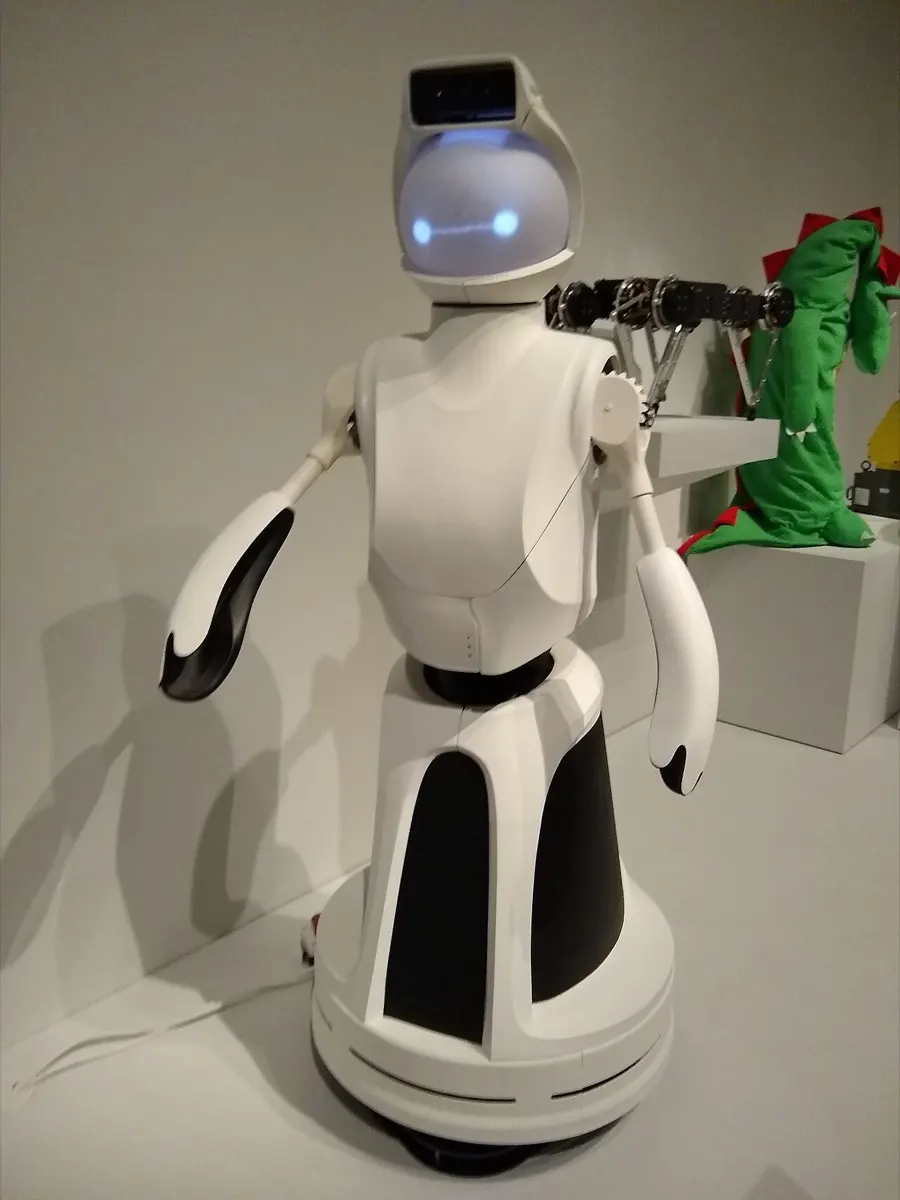
Not for saleBuilt under an NSF infrastructure grant and loaned to HRI research groups
Not for sale (research)Python from a laptopResearchROSNSF
Not for saleShipping: Not for sale. Research program units only. Not for sale.
Remote control: Standard ROS stack drivable from a laptop on the same network.
Overview
A low-cost, modular social-robot platform built so HRI researchers could share a common body. About ten units went to US labs. Its rear-projected spherical face and gesturing arms make it a research cousin to Pepper.
Specifications
| Category | Companion robots · Desk & social robots |
|---|---|
| Released | 2019 |
| Country | USA |
| Availability | Not for sale (research) |
| Sales | 10 prototypes built and awarded to research teams by 2023 Oregon State University ↗ |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| Best for | Professionals & labs |
| Vision sensors | Depth camera, Camera, Lidar |
| Actuators | Unknown |
| Audio | Microphone |
| Compute type | Proprietary / undisclosed |
| Remote control | Python from a laptop |
| Size | 1.35 m tall (resting), about 45–50 kg |
| Drive | Holonomic wheeled base, 2-arm upper body with projected face |
| Compute | Intel NUC running ROS |
| Vision | Depth camera (Orbbec Astra driver in the ROS stack) plus RGB camera |
| Lidar | Laser scanner in the mobile base (used for mapping and navigation) |
| Sensors | Mic array, projected face |
| Runtime | Not published |
| Speed | Up to 0.8 m/s (180°/s rotation) |
| SDK | ROS, open designs published by the project |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 JiboJibo, Inc. (USA)Was $899 (2017)
 MoxieEmbodied, Inc. (USA)Was $1,499 (2020)
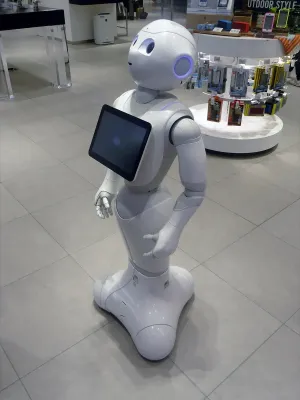 PepperSoftBank Robotics / Aldebaran (Japan/France)Was ¥198,000 (Japan, 2015) + monthly plan
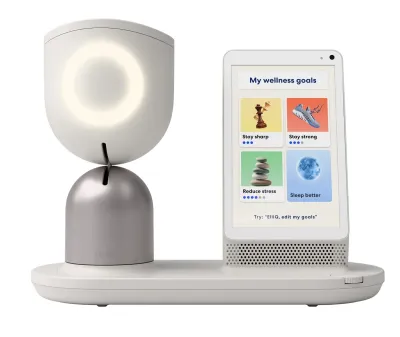 ElliQIntuition Robotics (Israel/USA)$249 + $59/month
 Reachy MiniPollen Robotics / Hugging Face (France/USA)$399 – $499
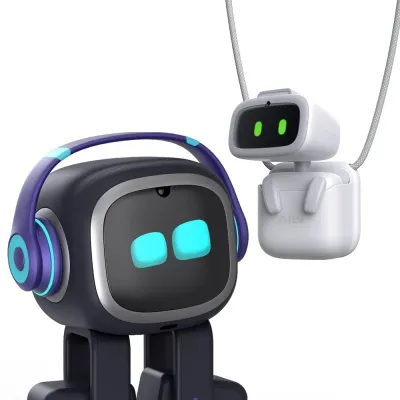 EMOLiving.ai (China)$279 (EMO) / $369 (EMO Go Home)
Image credits
- Image 1: source (CC BY-SA 4.0, Mary Mark Ockerbloom)