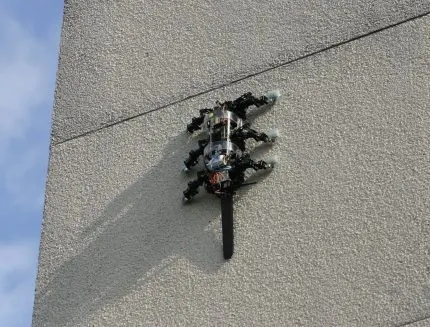
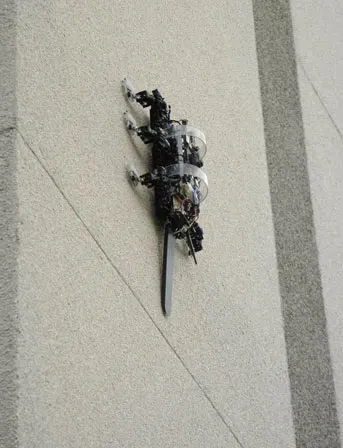
Not soldDARPA-funded research consortium robot.
Not for sale (research)Not programmableBoston DynamicsMicrospine feetTree & wall climbingDARPA
Not soldShipping: Not sold. A research robot that was never sold.
Remote control: Not possible. Research platform with no public interface.
Overview
RiSE (Robots in Scansorial Environments) was a DARPA Biodynotics project in which Boston Dynamics built a small legged robot that climbed walls, fences, trees and poles using feet covered in tiny hooks rather than adhesives. University partners studied claws, gecko-like adhesives and gait control, producing spin-offs such as Stickybot and SpinyBot. RiSE V1 and V2 were hexapods. The later V3 was a faster quadruped for outdoor poles. The project ran from roughly 2005 to 2009.
Specifications
| Category | Crawlers, snakes & climbers · Climbers & inspection crawlers |
|---|---|
| Released | 2006 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Unknown |
| Remote control | Not programmable |
| Size | ~0.25 m long, ~2 kg |
| Locomotion | Six legs (V1/V2, V3 was a quadruped) with microspine claws, plus a tail for balance on steep surfaces |
| Compute | Not published |
| Camera | None documented |
| Sensors | Not published (leg and foot sensing studied in the project) |
| Runtime | Not published |
| Speed | ~5 cm/s climbing (Boston Dynamics), ~0.3 m/s on the ground (Make) |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
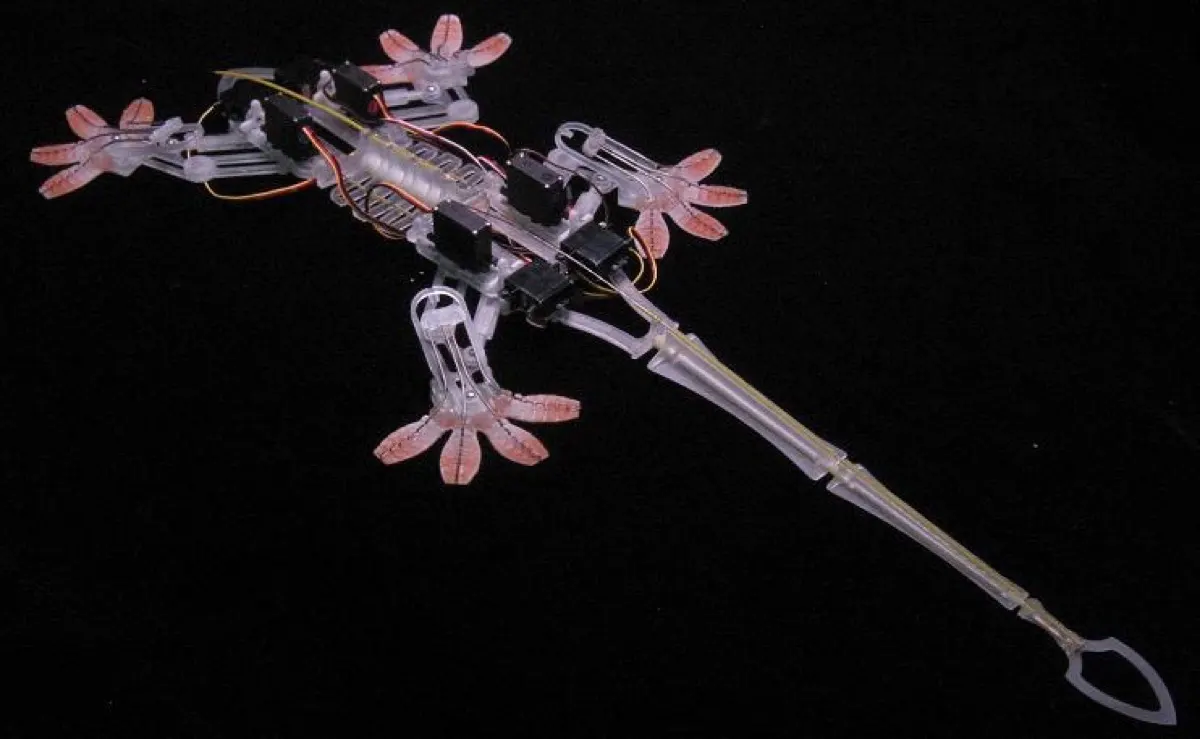 Stickybot / Stickybot IIIBiomimetics & Dexterous Manipulation Lab, Stanford University (USA)Not sold
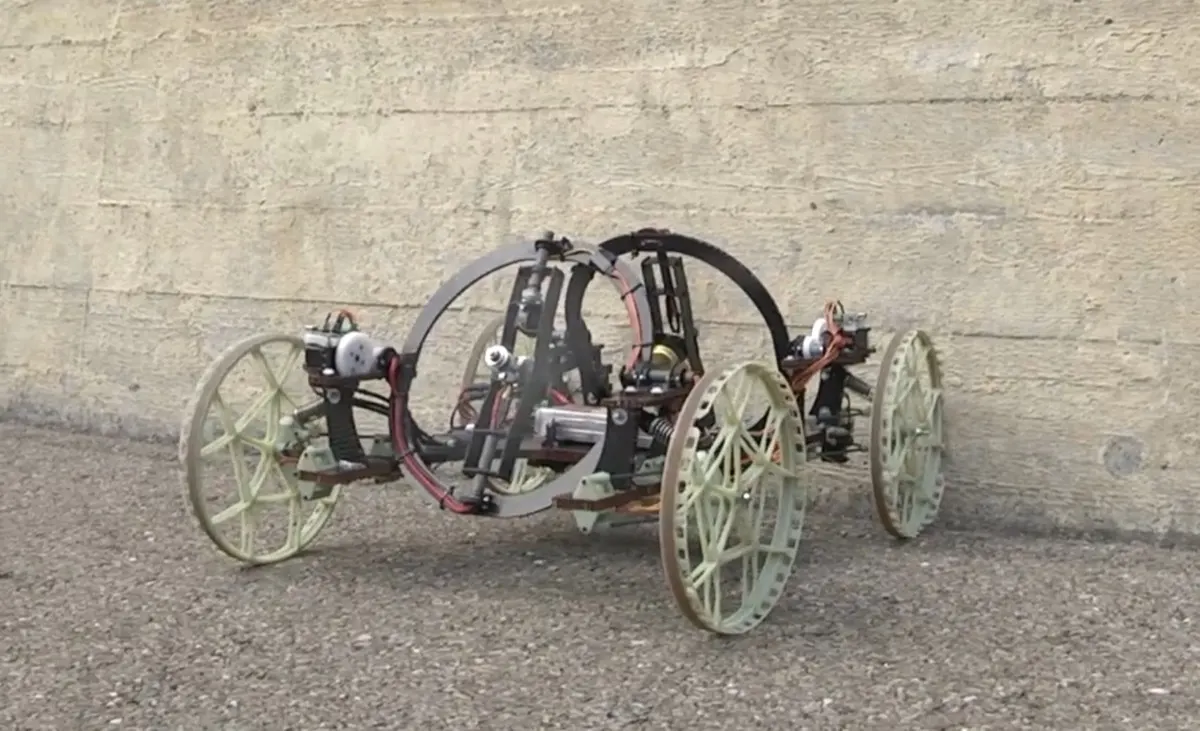 VertiGoDisney Research Zurich & ETH Zurich (Switzerland)Not sold
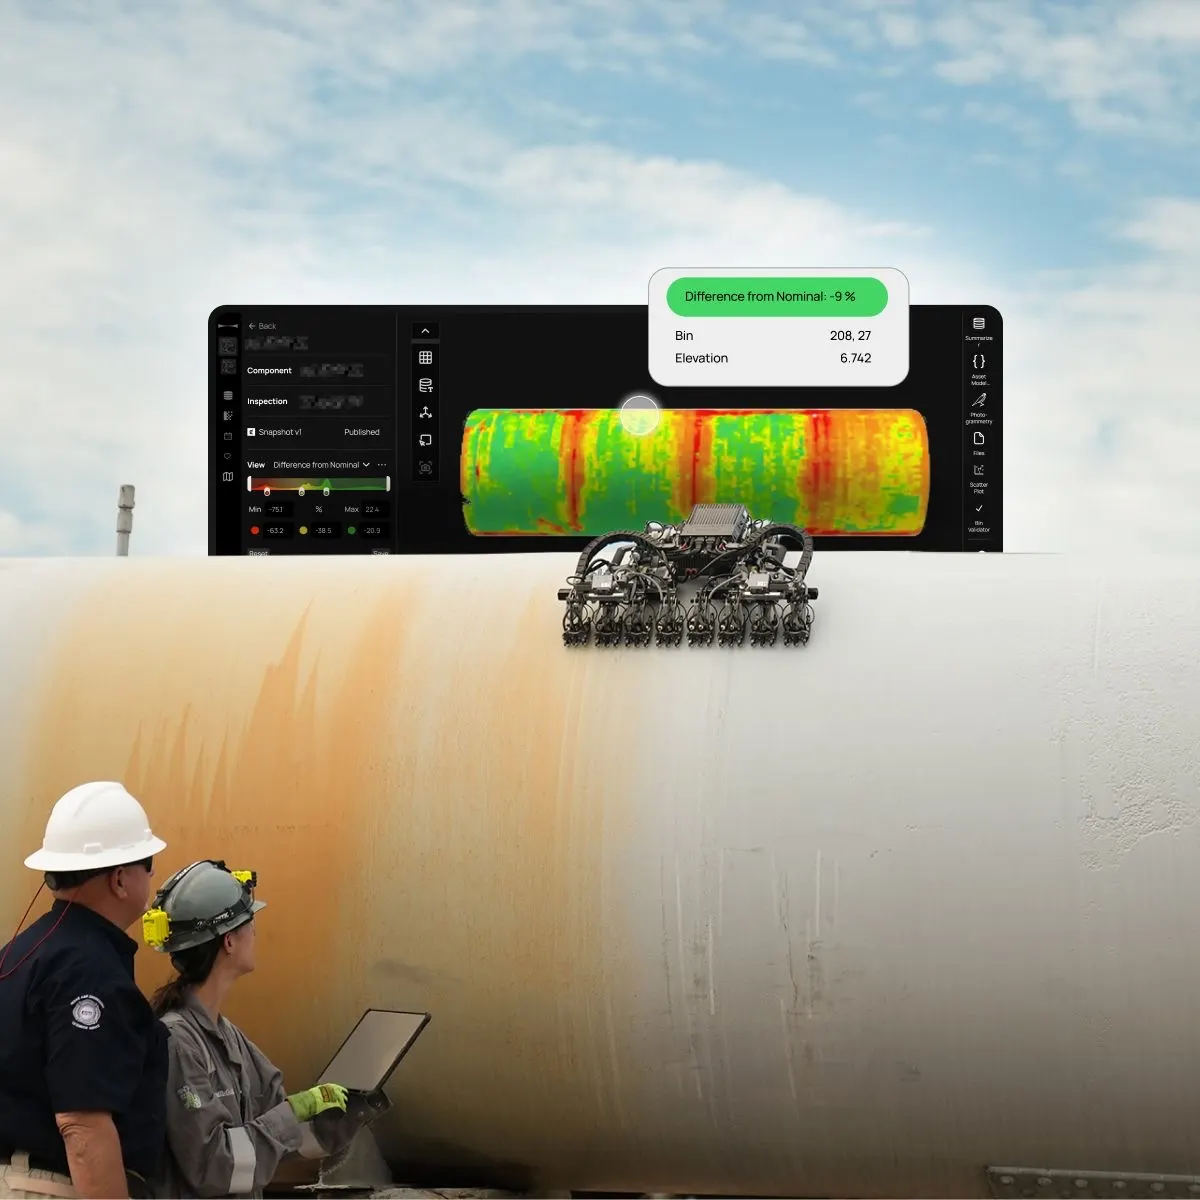 Gecko Robotics TOKA CrawlersGecko Robotics (Pittsburgh, USA)Service contract
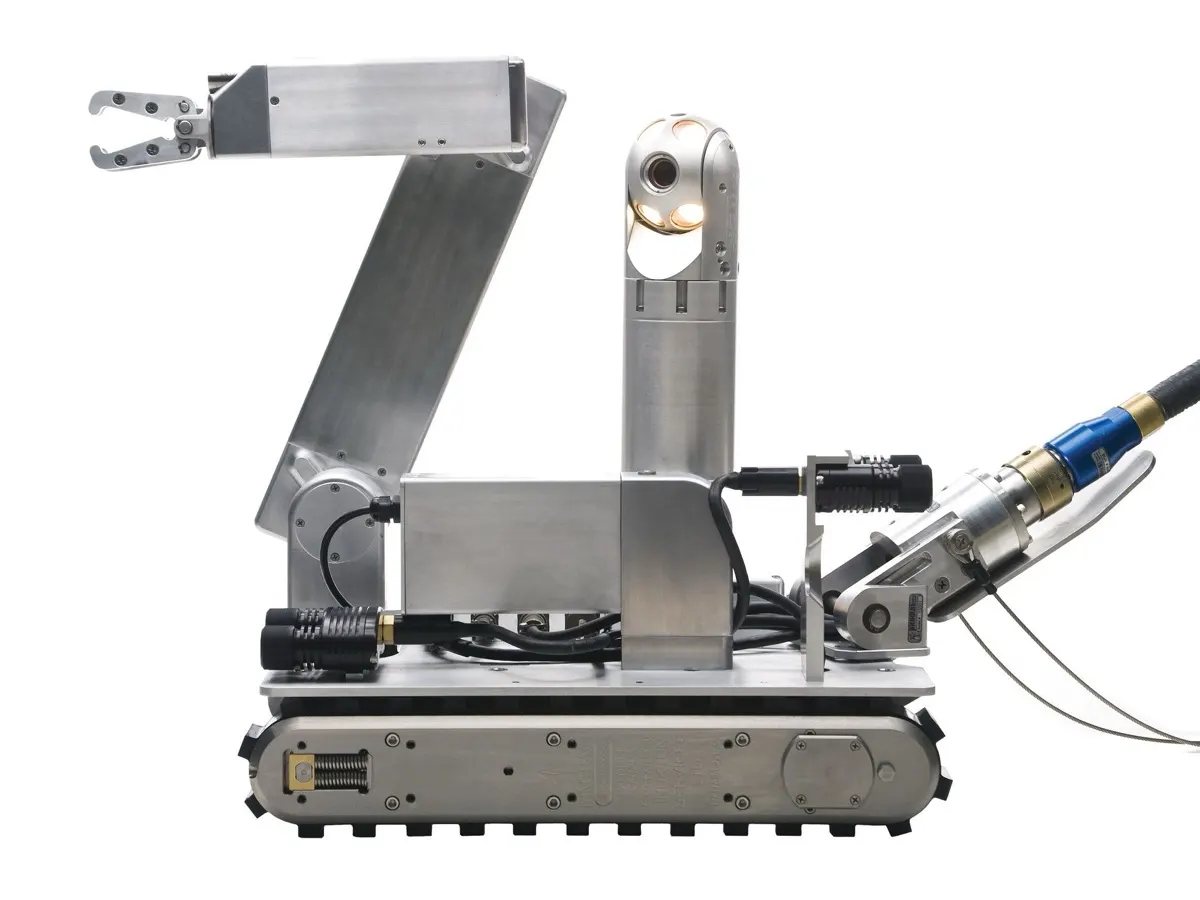 Inuktun / Eddyfi VersaTrax CrawlersEddyfi Technologies (formerly Inuktun, Canada)$139,000 (VersaTrax 450 TTC system)
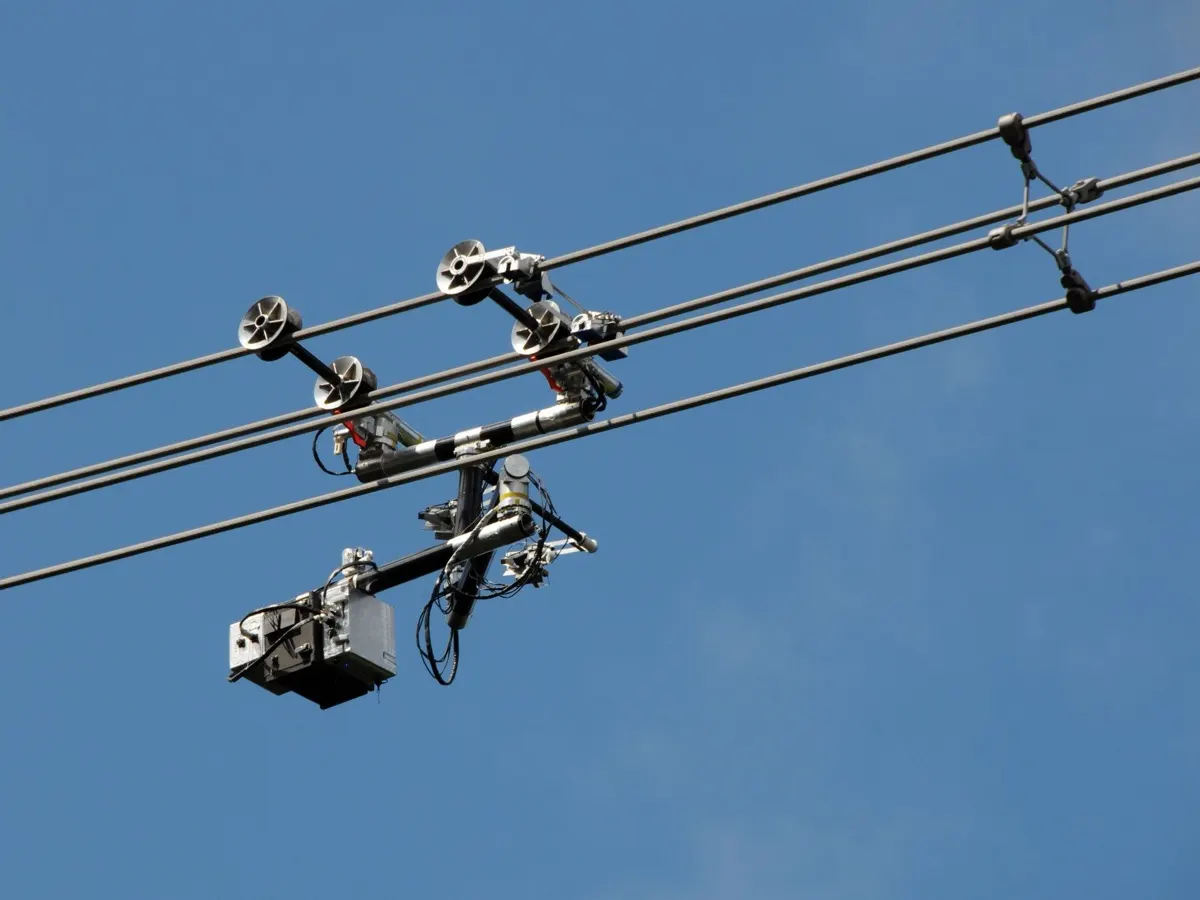 HiBot ExplinerHiBot (Japan)Unannounced
 CMU Modular Snake Robots (Unified / SEA Snake)Biorobotics Lab, Carnegie Mellon University (USA)Not sold