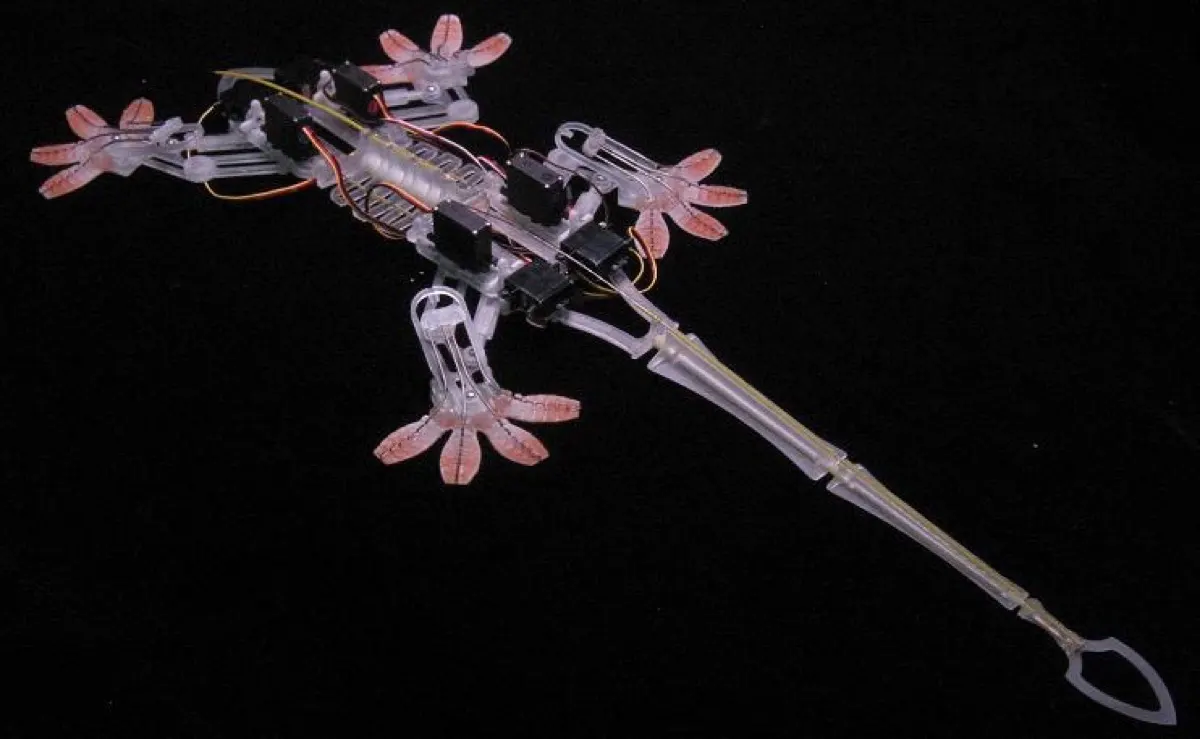
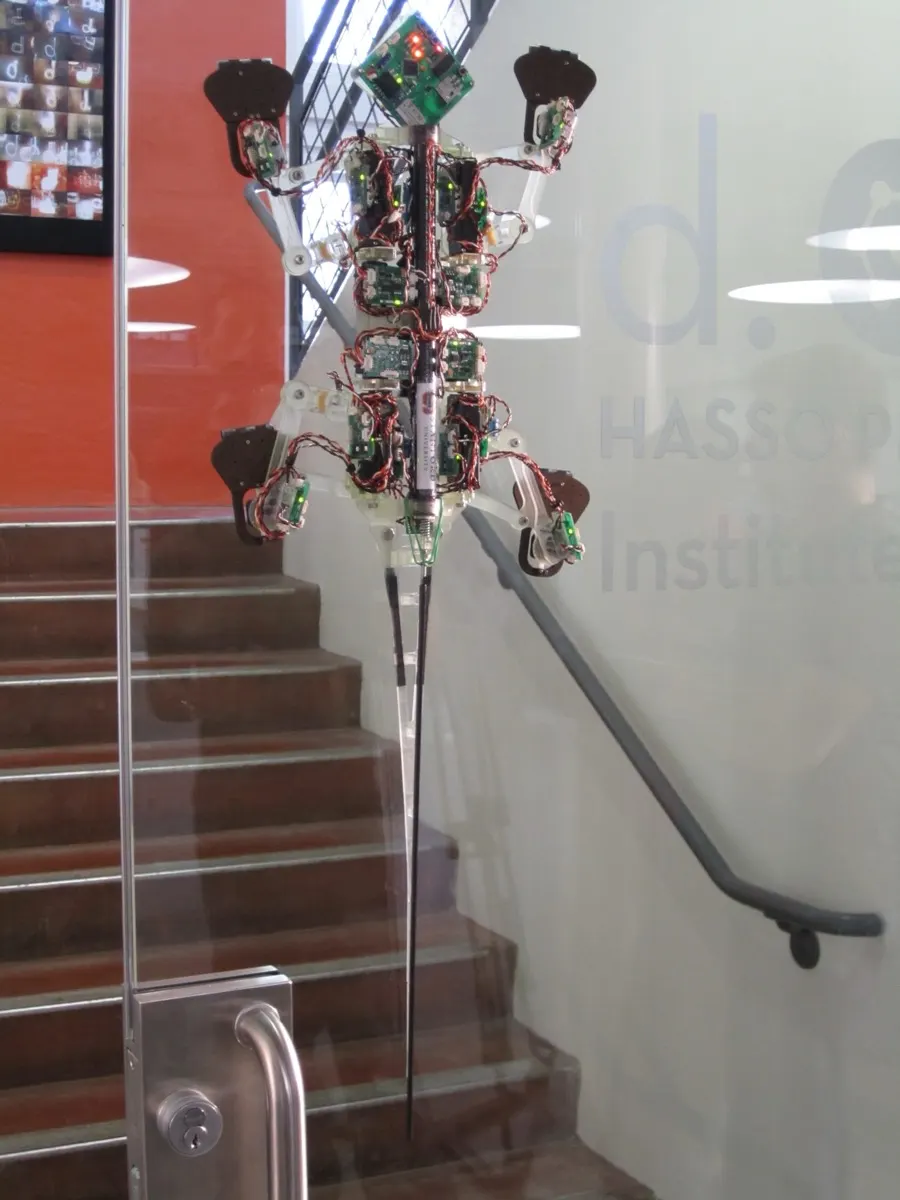
Not soldUniversity research robot.
Not for sale (research)Not programmableGecko adhesiveClimbs glassStanfordTime Best Invention 2006
Not soldShipping: Not sold. A university research robot, not for sale. Stanford licenses the adhesive technology.
Remote control: Not possible. Lab-only robot.
Overview
A gecko-inspired robot that climbs smooth glass, tile and later wood paneling and painted metal using synthetic directional dry adhesive that grips when pulled one way and releases cleanly the other way. It came out of the RiSE project, was named one of Time's Best Inventions of 2006, and the team's IEEE Transactions on Robotics paper on it won the 2009 King-Sun Fu best paper award. The original was retired in July 2010 and replaced by Stickybot III. The adhesive work also fed Stanford's Z-Man project on gecko-inspired human climbing.
Specifications
| Category | Crawlers, snakes & climbers · Climbers & inspection crawlers |
|---|---|
| Released | 2006 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Not programmable |
| Size | Stickybot III: 36 cm body plus 40 cm tail |
| Locomotion | Four legs with directional dry-adhesive toe pads, Stickybot III has 4 DoF per leg including wrist actuation |
| Compute | Stickybot III: local microprocessor servo controller per motor on a high-speed communication bus |
| Camera | None |
| Sensors | Not published |
| Runtime | Not published |
| Speed | ~5 cm/s (Stickybot III) |
| SDK | None public (lab gait uploader) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 RiSE Climbing RobotBoston Dynamics with Stanford, CMU, UC Berkeley, Penn and Lewis & Clark (USA)Not sold
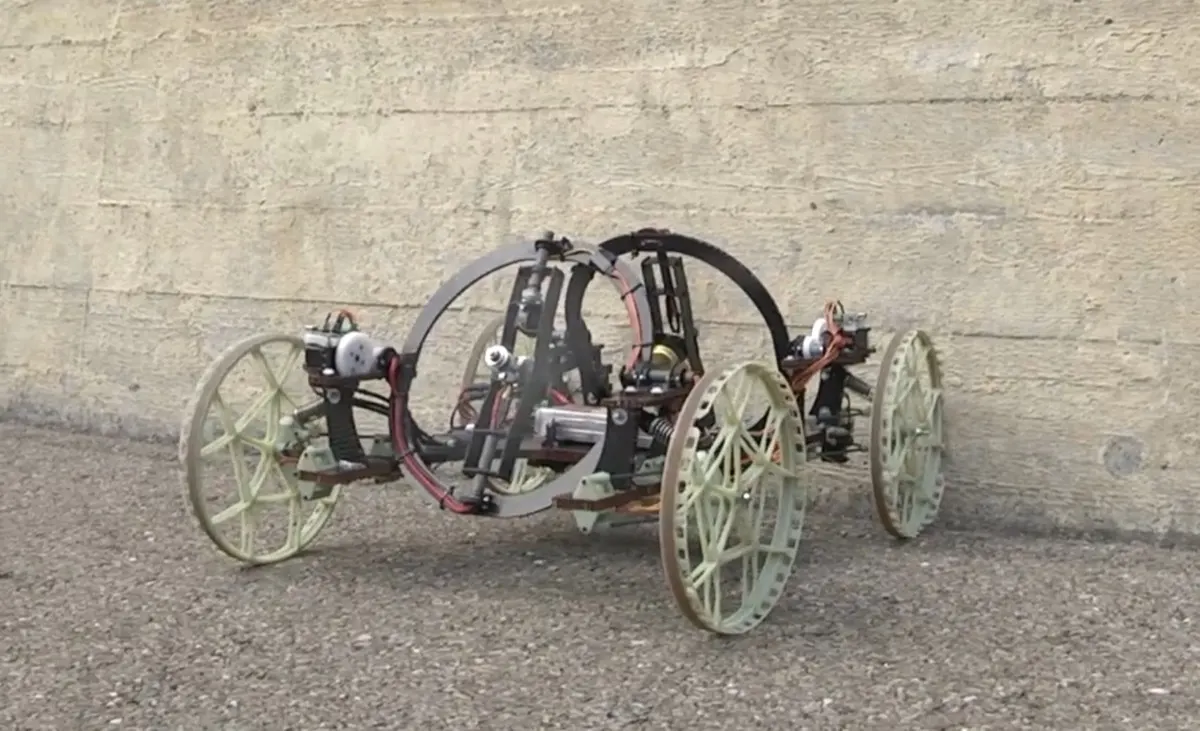 VertiGoDisney Research Zurich & ETH Zurich (Switzerland)Not sold
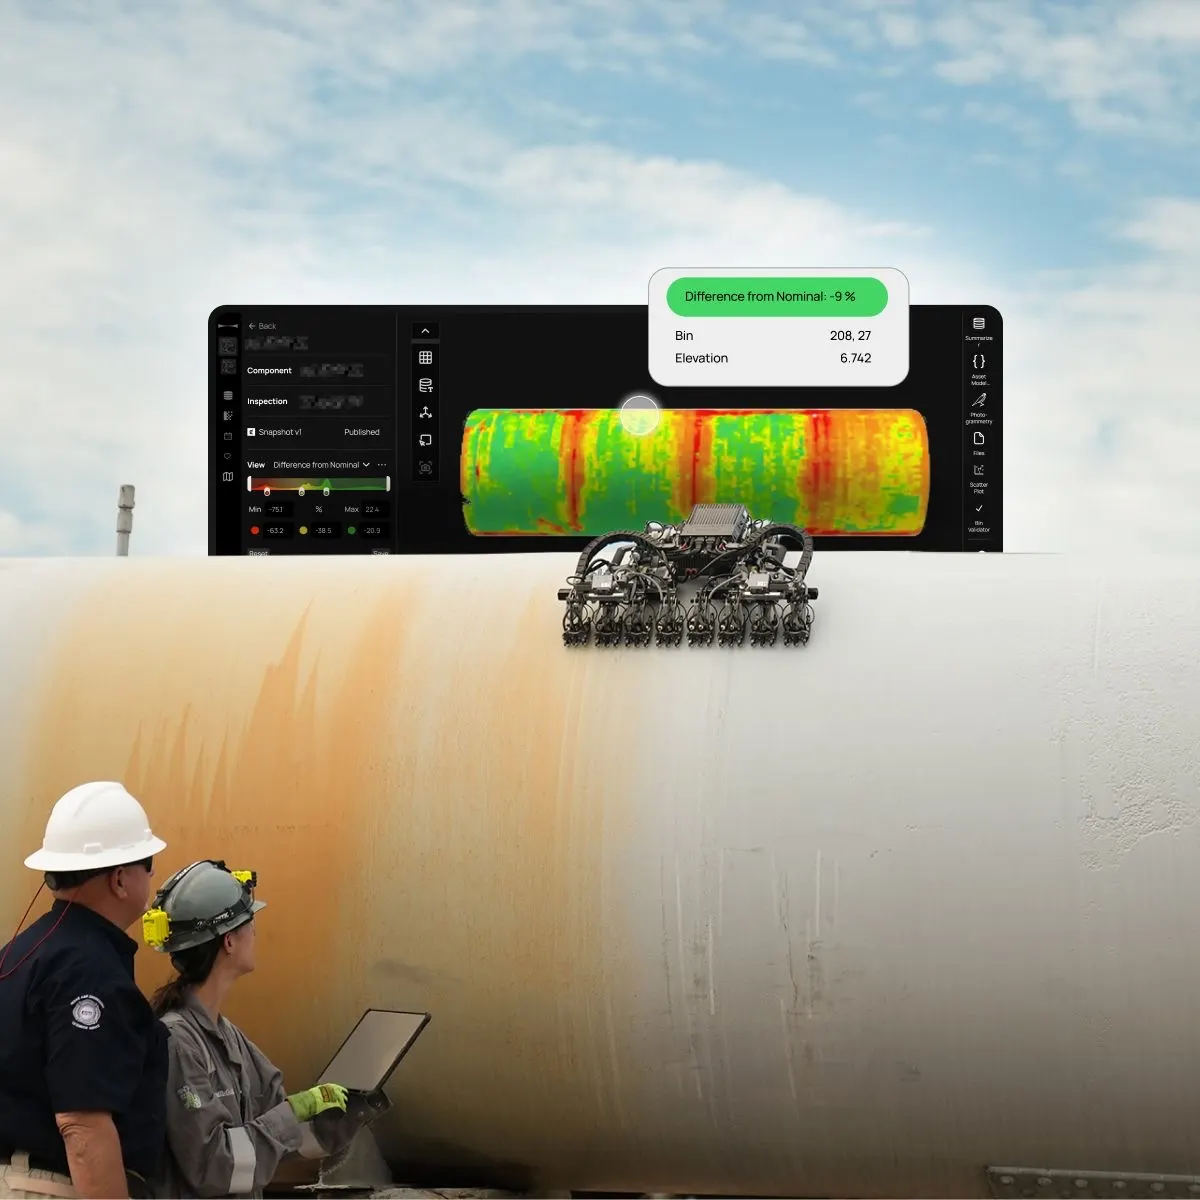 Gecko Robotics TOKA CrawlersGecko Robotics (Pittsburgh, USA)Service contract
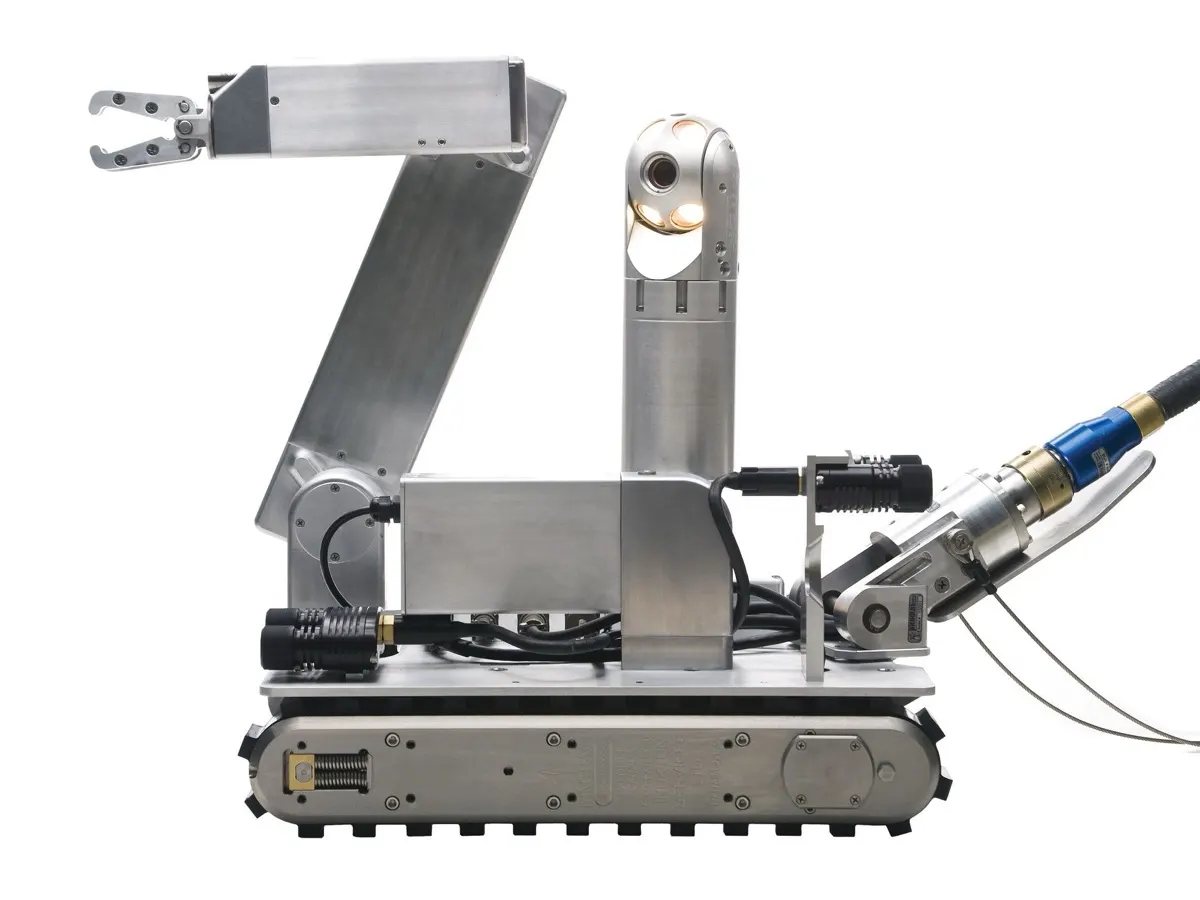 Inuktun / Eddyfi VersaTrax CrawlersEddyfi Technologies (formerly Inuktun, Canada)$139,000 (VersaTrax 450 TTC system)
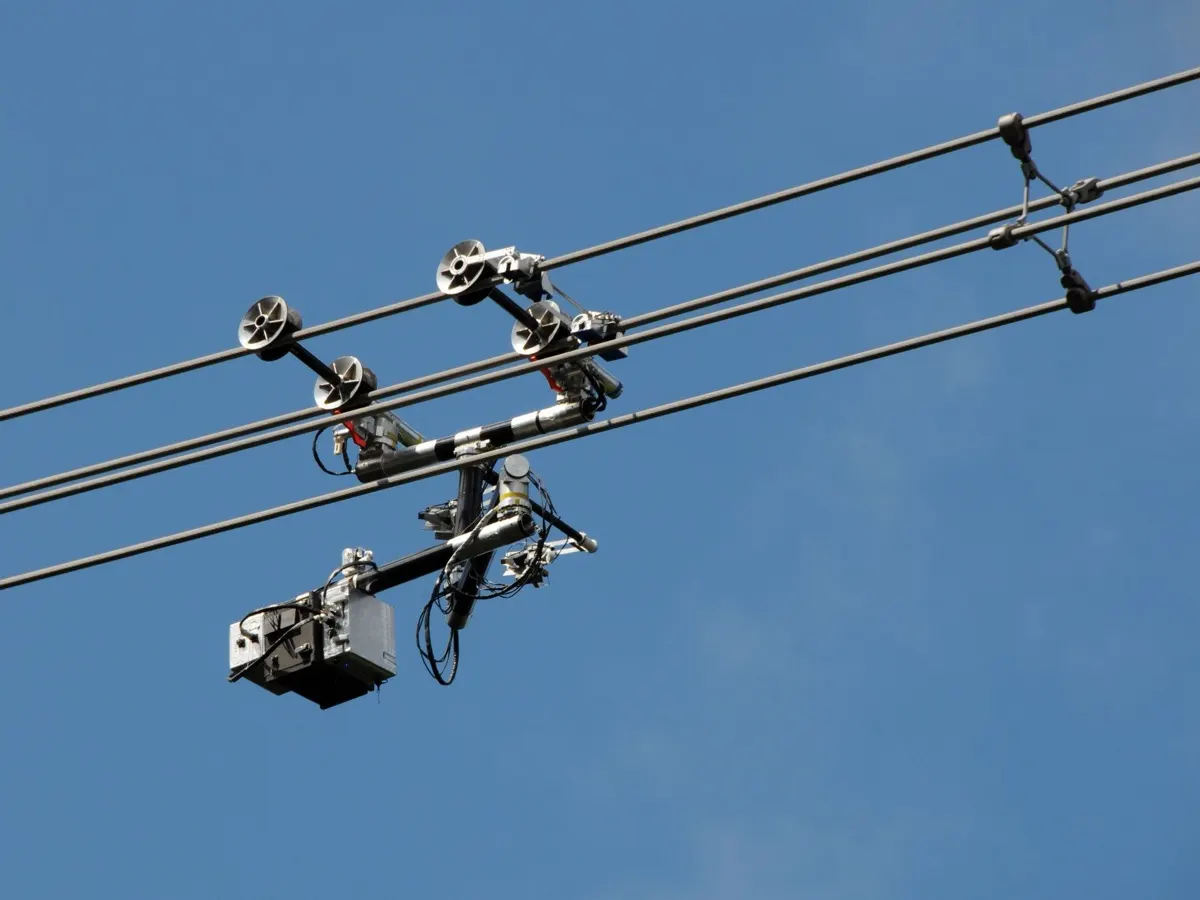 HiBot ExplinerHiBot (Japan)Unannounced
 CMU Modular Snake Robots (Unified / SEA Snake)Biorobotics Lab, Carnegie Mellon University (USA)Not sold