Comparison table
| Unit | Price | Force | Speed | Weight | Status |
|---|---|---|---|---|---|
| Actuonix L16 micro linear actuator (L16-P / L16-S / L16-R) | $70 – $80 | 50–200 N at 12 V | 8–32 mm/s | 56–84 g | Available |
| Actuonix P16 mini linear actuator (P16-P / P16-S / P16-R) | $80 – $90 | 50–300 N at 12 V | 4.8–46 mm/s | 95–125 g | Available |
| Actuonix PQ12 micro linear actuator (PQ12-P / PQ12-S / PQ12-R) | $65 – $70 | 18–50 N | 10–28 mm/s | 19–21 g | Available |
| Progressive Automations PA-14 mini linear actuator | $119.99 – $180.99 | 156–667 N | up to 51 mm/s | 0.68 kg and up | Available |
| Harmonic Drive CSF / CSD strain wave gear (component sets) | Quote only | rotary (torque-rated) | up to 3,500 rpm input | CSF-14 component set 0.09 kg | Available |
| Hydraulic servo actuators for legged robots (Moog Integrated Smart Actuator reference) | Not sold publicly | 4,000–7,500 N | – | ISA v2 920 g | Research only |
| Festo Fluidic Muscle DMSP | about $322 | 630–6,000 N by size | – | base 58 g | Available |
| Soft pneumatic actuators (PneuNets bending actuator and mGrip soft fingers) | DIY materials cost | up to 10 kg payload (mGrip) | – | – | Available |
| Shape memory alloy wire (Dynalloy Flexinol) | $5 – $12 per meter | 0.09–35 N pull by wire size | about 1 s to contract | – | Available |
| Piezoelectric bimorph bending actuators (Thorlabs PB4NB2W reference) | $66.54 – $123.37 | 1.4–13 N blocking | 370–930 Hz resonance | – | Available |
| Clone Robotics Myofiber artificial muscle | Not sold | about 10 N per fiber | under 50 ms response | – | Announced |
| Series elastic actuators (HEBI T-Series and legacy X-Series) | from $3,000 | rotary (torque-rated) | 11–110 rpm | 450 g – 1.5 kg | Available |
Actuonix L16 micro linear actuator (L16-P / L16-S / L16-R)
Actuonix store, October 2026 check. L16-S and L16-R $70.00, L16-P (potentiometer feedback) $80.00. Some configurations on back order.
The L16 is a rod-style miniature linear actuator with a brushed motor and lead screw in a rectangular body, which Actuonix says it designed in the late 2000s. It comes in three control styles (limit switches, raw potentiometer feedback, or a built-in RC servo controller) across several stroke lengths and three gear ratios. Actuonix, formerly Firgelli Technologies (unconfirmed), states on the product page that the L16 design was copied by a competitor and that fake variants are sold online.
- Force
- 50 N (35:1), 100 N (63:1), 200 N (150:1) max lifted force at 12 V. Peak power points 50 N @ 16 mm/s, 75 N @ 10 mm/s, 175 N @ 4 mm/s
- Speed
- 32 mm/s (35:1), 20 mm/s (63:1), 8 mm/s (150:1) no load
- Weight
- 56 g (50 mm stroke), 74 g (100 mm), 84 g (140 mm)
- Size
- 118 / 168 / 208 mm closed length hole to hole for 50 / 100 / 140 mm stroke
- Voltage
- 12 V DC for -P and -S, 6 V DC for -R
- Current
- stall 650 mA at 12 V
- Gearing
- 35:1, 63:1 or 150:1 spur gearing to a lead screw
- Motor
- brushed PMDC
- Feedback
- -P has a linear potentiometer (6/11/16 kΩ by stroke, under 2% linearity), repeatability 0.3–0.5 mm with the LAC board
- Interface
- -S two-wire polarity reversal with end-of-stroke limit switches. -P five-wire with analog position output. -R standard RC servo pulse (1.0 ms retracts, 2.0 ms extends), compatible with the Arduino Servo library and VEX controllers
- Range
- 50, 100 or 140 mm stroke in the datasheet, and the store page also lists a 30 mm version
- Other
- Backdrive force 31 / 46 / 102 N by gear ratio, so it holds position unpowered up to that load. 20% max duty cycle, IP-54, 0.25 mm backlash, 250 N max static force, max side load 40 / 30 / 20 N extended by stroke, 60 dB at 45 cm
Small push-pull motions that need more force than a hobby servo can give through a linkage, such as grippers, hatches and steering on mid-size hobby robots. The -R version drops into any RC or Arduino servo socket.
Fast or continuous motion, since speed tops out at 32 mm/s and duty cycle is limited to 20%. The lead screw is not designed to be backdriven for compliant or force-controlled joints.
Actuonix states its linear servos are legal in FIRST Robotics Competition and FIRST Tech Challenge.
Sources L16 datasheet (Actuonix) ↗ · Actuonix L16 store page ↗
Buying Actuonix online store, which ships worldwide from Victoria, BC, Canada. In-stock items ship within 1–2 days, Monday to Friday, with a 1 PM Pacific cutoff, and shipping is charged at Actuonix's discounted cost. US orders under $800 ship by DHL, UPS Express takes 1–2 days to the US, and import duties are not included.
Actuonix P16 mini linear actuator (P16-P / P16-S / P16-R)
Actuonix store, October 2026 check. P16-S $80.00, P16-P $90.00. P16-R is a P16-P sold with an external RC control board and needs its own power supply, bundle price not listed.
The P16 is Actuonix's mini actuator built with a planetary gearbox and a motor mounted beside the screw rather than in line. The datasheet highlights higher cycle life than its other models thanks to sealed stainless bearings and a stainless lead screw. The 256:1 version is effectively non-backdrivable, holding over 500 N unpowered.
- Force
- 50 N (22:1), 90 N (64:1), 300 N (256:1) max lifted force at 12 V. Peak power points 40 N @ 26 mm/s, 80 N @ 9 mm/s, 250 N @ 2.5 mm/s
- Speed
- 46 mm/s (22:1), 18 mm/s (64:1), 4.8 mm/s (256:1) no load
- Weight
- 95 g (50 mm stroke), 110 g (100 mm), 125 g (150 mm), 140 g (200 mm)
- Size
- 97 / 147 / 197 / 247 mm closed length hole to hole for 50 / 100 / 150 / 200 mm stroke
- Voltage
- 0–15 V DC, rated at 12 V
- Current
- stall 1000 mA at 12 V
- Gearing
- 22:1, 64:1 or 256:1 planetary gearbox, stainless steel lead screw
- Motor
- brushed DC
- Feedback
- -P has a linear potentiometer (6–23 kΩ by stroke, under 2% linearity), repeatability 0.3–0.8 mm with the LAC board
- Interface
- -S two-wire polarity reversal with limit switches, -P five-wire with position output, -R RC servo pulse through an external control board that needs a separate power supply
- Range
- 50, 100, 150 or 200 mm stroke
- Other
- Side-by-side (parallel) motor layout makes it shorter than an L16 of the same stroke. Backdrive force 75 N / 200 N / over 500 N by ratio. 20% max duty cycle, IP-54, 0.3 mm backlash, 500 N max static force, sealed stainless bearings, glass-filled nylon housing, 62 dB at 45 cm
The strongest of the Actuonix miniature line, suited to small lifts, leg or tail mechanisms and tilt platforms that need up to 300 N in a compact package with a long cycle life.
Speed, since the strong 256:1 version moves under 5 mm/s. Side loads above 4–20 N need an external guide.
Sources P16 datasheet (Actuonix) ↗ · Actuonix P16 store page ↗
Buying Actuonix online store, which ships worldwide from Victoria, BC, Canada. In-stock items ship within 1–2 days, Monday to Friday, with a 1 PM Pacific cutoff, and shipping is charged at Actuonix's discounted cost. US orders under $800 ship by DHL, UPS Express takes 1–2 days to the US, and import duties are not included.
Actuonix PQ12 micro linear actuator (PQ12-P / PQ12-S / PQ12-R)
Actuonix store, October 2026 check. PQ12-P and PQ12-S $65.00, PQ12-R linear servo $70.00.
Actuonix bills the PQ12 as the original micro linear actuator, a complete gear motor, lead screw and position sensor in a package of about 20 g. The -R variant replaces a standard RC servo directly, with a 1 ms pulse fully extending it and 2 ms fully retracting it. The datasheet lists 19 g for the -P and -S and 21 g for the -R.
- Force
- 18 N (30:1), 45 N (63:1), 50 N (100:1) max lifted force. Peak power points 15 N @ 15 mm/s, 30 N @ 8 mm/s, 40 N @ 6 mm/s
- Speed
- 28 mm/s (30:1), 15 mm/s (63:1), 10 mm/s (100:1) no load
- Weight
- 19 g (P, S), 21 g (R)
- Voltage
- 6 or 12 V DC (-R is 6 V only)
- Current
- stall 550 mA at 6 V, 210 mA at 12 V
- Gearing
- 30:1, 63:1 or 100:1
- Motor
- brushed DC
- Feedback
- -P has a 5 kΩ linear potentiometer, ±0.1 mm repeatability
- Interface
- -S polarity reversal with limit switches that cut power within 1 mm of each end, -P analog position output (pairs with the LAC board), -R standard 3-wire RC servo input
- Range
- 20 mm stroke
- Other
- Flat ribbon (FPC) cable on -P and -S, 3-pin 2.54 mm servo plug on -R. Backdrive force 9 / 25 / 35 N. Max side load 5–10 N, 20% duty cycle, IP-54, 0.25 mm backlash, 55 dB at 45 cm
Very small mechanisms with only about 2 cm of travel, such as micro grippers, latches, camera shutters and animatronic eyes or lips, where a rotary servo and linkage would not fit.
Anything needing long stroke or more than about 50 N. The ribbon cable is fragile and needs an adapter for longer runs.
Sources PQ12 datasheet (Actuonix) ↗ · Actuonix PQ12 store page ↗
Buying Actuonix online store, which ships worldwide from Victoria, BC, Canada. In-stock items ship within 1–2 days, Monday to Friday, with a 1 PM Pacific cutoff, and shipping is charged at Actuonix's discounted cost. US orders under $800 ship by DHL, UPS Express takes 1–2 days to the US, and import duties are not included.
Progressive Automations PA-14 mini linear actuator
Progressive Automations US store, October 2026 check. $119.99 for 1–12 in strokes, $129.99 for 18 in, $141.99 for 24 in, $162.99 for 30 in, $180.99 for 40 in, same price for every force and voltage. Several variants sold out. Feedback version is the PA-14P.
The PA-14 is a typical 12 V 'furniture and automation' linear actuator, a brushed motor driving an ACME screw inside an aluminum tube with fixed limit switches. Progressive Automations sells it in dozens of stroke and force combinations and now points buyers to the IP65 PA-01 as its newer version. Similar actuators are sold by Firgelli Automations and many generic brands.
- Force
- 35 lb (156 N), 50 lb (222 N) or 150 lb (667 N) dynamic and static force
- Speed
- no load 2.00 in/s (51 mm/s) at 35 lb, 1.14 in/s (29 mm/s) at 50 lb, 0.37 in/s (9.4 mm/s) at 150 lb. Full load 1.38 / 0.83 / 0.28 in/s
- Weight
- 0.68 kg (1.50 lb) at 1 in stroke, 0.88 kg (1.95 lb) at 6 in, 2.2 kg (4.85 lb) at 40 in
- Size
- retracted hole to hole length is stroke + 4.13 in (5.13 in for 1 in stroke)
- Voltage
- 12 V DC or 24 V DC
- Current
- 12 V: 1.0 A no load, 5.0 A full load. 24 V: 0.5 A no load, 2.5 A full load
- Gearing
- ACME lead screw, polyformaldehyde gears (35 lb model) or powder-metallurgy steel alloy gears
- Motor
- brushed DC
- Feedback
- none on PA-14, optional on the PA-14P
- Interface
- two-wire polarity reversal, Molex Mini-Fit Jr 2-pin connector, 40 in cable
- Range
- 1 to 40 in stroke (25–1016 mm)
- Other
- Built-in non-adjustable limit switches, 25% duty cycle, IP54, under 45 dBA, aluminum alloy housing and rod, -5 to 65 °C, CE and RoHS, no overload protection
Heavy, slow linear moves on larger robots and props, such as lifting a mast, tilting a solar panel, opening hatches or moving a seat, where hundreds of newtons matter more than speed.
Fast or precise joints, since there is no feedback on the base model and the duty cycle is only 25%. It is far too heavy for small or walking robots.
Sources PA-14 product page and specifications (Progressive Automations) ↗ · PA-01 newer version (Progressive Automations) ↗
Buying Progressive Automations online store, prices in USD, product page lists 'Ships within 24 hours' and 'Low stock'. Ship-from location and transit time not stated (unconfirmed).
Harmonic Drive CSF / CSD strain wave gear (component sets)
Harmonic Drive LLC does not list prices online (October 2026 check). Component sets are sold through sales engineers and distributors.
A strain wave gear uses an elliptical wave generator to flex a thin steel cup (the flexspline) into a rigid ring gear with two more teeth, so one input turn moves the output by only two teeth. Harmonic Drive credits the invention to C. Walton Musser, in the 1950s (unconfirmed), and Harmonic Drive is the original trademark, now often used as a generic name. The CSF is the company's mainstream cup-type set, and the CSD is its ultra-flat version for thin robot joints.
- Torque
- CSF-2A rated torque from 0.9 N·m (size 8, 30:1) to 3,550 N·m (size 100, 160:1). Example CSF-14-50 rated 5.4 N·m, repeated peak 18 N·m, momentary peak 35 N·m
- Weight
- CSF-14 component set 0.09 kg, CSF-20 0.28 kg, CSF-32 0.89 kg
- Size
- CSF sizes 8 to 100, CSD sizes 14 to 50. CSD is the ultra-flat version, which Harmonic Drive lists as a quarter the thickness of CSF, with a hollow bore
- Gearing
- single-stage reduction from 30:1 to 160:1 (CSF) or 50:1 to 100:1 (CSD) via flexspline, circular spline and elliptical wave generator
- Other
- Zero backlash, standard accuracy 1–2 arc min, average input speed limit 3,500 rpm for sizes 8 and 14 and 1,200 rpm for size 100. Backdriving torque 0.65 N·m (size 8) up to 540 N·m (size 100), so joints are hard to backdrive. Torsional stiffness is nonlinear (three-slope K1/K2/K3)
Robot arm joints that need high reduction in one compact, light stage with zero backlash and arc-minute accuracy, the standard choice for cobots and precision rotary axes.
Cheap or impact-heavy legged robots, since the flexspline is expensive, hard to backdrive and can fail under shock loads. Quasi-direct-drive planetary actuators are usually preferred there.
Robots in the guide that use this type of actuator
UFACTORY 850, myCobot Pro 600 and Husky Carbon are described as using harmonic drives without naming the brand. Strain wave gears are standard in the joints of industrial and collaborative arms, reported for Universal Robots, Kinova and Franka arms (unconfirmed for each), as well as many humanoid joints and NASA rover arms.
Sources CSF-2A component sets (Harmonic Drive LLC) ↗ · CSD-2A component sets (Harmonic Drive LLC) ↗ · CSF-14-50-2A-R data (Harmonic Drive LLC) ↗ · Harmonic Drive technology overview ↗
Buying Sold through Harmonic Drive LLC (Beverly, Massachusetts) sales and distributors by quote. Lead times not stated (unconfirmed). Generic Chinese strain wave gears are sold on AliExpress at much lower prices.
Hydraulic servo actuators for legged robots (Moog Integrated Smart Actuator reference)
October 2026 check. Moog's ISA appears only in research papers and a 2019 press release, not in a public catalog.
Hydraulic actuation powered the famous dynamic robots of 2005–2024, including Boston Dynamics' BigDog, LS3 and hydraulic Atlas and IIT's HyQ family. BigDog used custom cylinders with a Moog Series 30 servo valve, load cell and potentiometer. Moog and IIT then built the Integrated Smart Actuator, which packs cylinder, servo valve, sensors and electronics into one 3D-printed body (the v5 sits in HyQReal's legs). Boston Dynamics retired hydraulic Atlas in April 2024, marking the end of hydraulics in its humanoids.
- Force
- ISA v2 4,000 N, ISA v5 7,500 N at 20.7 MPa (3,000 psi) supply pressure
- Weight
- ISA v2 920 g, ISA v5 1,600 g
- Size
- ISA v2 16 mm bore, 12 mm rod, 80 mm stroke. ISA v5 21.5 mm bore, 12 mm rod, 100 mm stroke
- Motor
- hydraulic cylinder with integrated servo valve, fed by a separate electric or engine-driven pump
- Feedback
- position, both chamber pressures, load cell, temperature and IMU
- Interface
- onboard ARM processor with EtherCAT, CAN or serial
- Range
- 80 mm (v2) or 100 mm (v5) linear stroke
- Other
- v2 uses a high-response valve (about 320 Hz bandwidth), v5 an ultra-low-leakage valve (over 100 Hz). Additive-manufactured body with internal oil passages and overload protection
Large, heavy legged robots that need very high force density and shock tolerance, such as the 130 kg HyQReal pulling a 3.3-metric-ton airplane or the hydraulic Atlas doing backflips.
Small, quiet or low-maintenance robots. Hydraulics need a pump, oil, hoses and seals that can leak, and the whole field moved to electric actuators once motors improved.
Robots in the guide that use this type of actuator
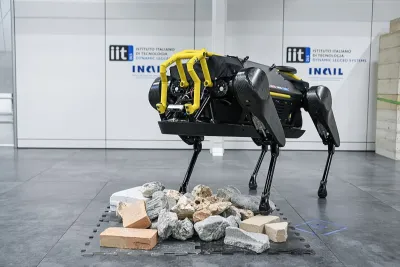
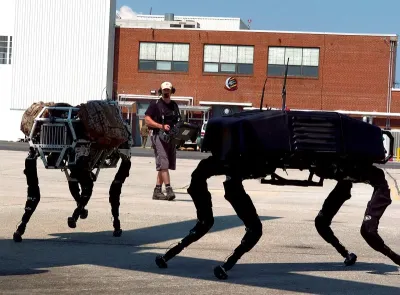
Boston Dynamics' hydraulic Atlas and LS3 used hydraulic servo actuators of undisclosed make. Raibert's 1980s 3D hopper used a hydraulic gimbal hip, and walking machines such as Mantis use industrial proportional hydraulics.
Sources Barasuol et al., Highly-Integrated Hydraulic Smart Actuators (Frontiers in Robotics and AI, 2018) ↗ · Moog and IIT test HyQReal (Moog press release, 2019) ↗ · HyQReal (IIT Dynamic Legged Systems) ↗
Buying Not available to buy. Industrial Moog servo valves and cylinders are sold through Moog distributors by quote (unconfirmed).
Festo Fluidic Muscle DMSP
Zoro listing for DMSP-20-100N-RM-CM at $321.99, October 2026, seen only in a search snippet (unconfirmed). Festo's own US store did not load for a direct check, and price rises with length and size.
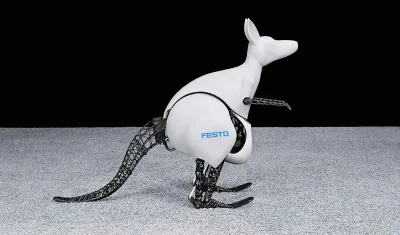
Fluidic Muscle is Festo's industrial version of the McKibben pneumatic artificial muscle. When pressurized, the fiber-braided hose widens and shortens by up to a quarter of its length, pulling with high force and no stick-slip. Festo uses it in its own bionic showcase robots and sells it as a regular catalog part for clamping and vibration machines, which makes it one of the few artificial muscles anyone can buy off the shelf.
- Force
- theoretical pulling force at max pressure 630 N (size 10), 1,500 N (size 20), 6,000 N (size 40)
- Weight
- base 58 g (DMSP-10), 169 g (DMSP-20), 675 g (DMSP-40) with RM-CM connectors, plus 94 / 178 / 340 g per meter of length
- Size
- internal diameter 10, 20 or 40 mm, nominal length 40–9,000 mm (size 10), 60–9,000 mm (20), 120–9,000 mm (40)
- Pressure
- compressed air, 0–8 bar (size 10) or 0–6 bar (sizes 20, 40)
- Motor
- single-acting pulling actuator, a chloroprene hose wrapped in aramid fibers (McKibben type)
- Range
- contracts up to 25% of nominal length
- Other
- Hysteresis up to 3% of length (size 10) or 2.5% (sizes 20 and 40), repeatability within 1% of length, hermetically sealed with no sliding parts, operates -5 to 60 °C. Festo cites an initial force up to 10 times that of a cylinder of the same diameter
Muscle-like, compliant pulling joints and exoskeletons where high force from a light, sealed actuator matters and a compressor is available.
Precise positioning without extra sensors, since force drops as it contracts and hysteresis is a few percent. It only pulls, so joints need an antagonist muscle or spring.
Festo's Airic's_arm (2007) was driven by Fluidic Muscles (unconfirmed). McKibben-style air muscles were also used in early Shadow Robot hands and many lab exoskeletons.
Sources Fluidic Muscle DMSP/MAS catalog (Festo PDF) ↗ · Fluidic muscle DMSP (Festo) ↗
Buying Festo US online store and distributors. Zoro also lists it. Lead times vary since many lengths are built to order (unconfirmed).
Soft pneumatic actuators (PneuNets bending actuator and mGrip soft fingers)
October 2026 check. The Soft Robotics Toolkit says its PneuNets documentation is intended for research, educational and scholarly use by not-for-profit organizations, built from cast silicone. Schmalz sells mGrip grippers by quote with no public price.
PneuNets are networks of air chambers molded inside silicone, developed by the Whitesides group at Harvard and documented openly in the Soft Robotics Toolkit. A stiffer strain-limiting layer on one side makes the actuator curl when pressurized, which is the basis of most soft grippers. The US company Soft Robotics Inc. turned the idea into the mGrip product, then divested its gripper business to the Schmalz Group on August 6, 2024 and now operates as Oxipital AI, while Schmalz sells mGrip for food handling.
- Force
- mGrip load capacity up to 10 kg per gripper (Schmalz figure)
- Pressure
- air pressure, 3.0–6.9 bar for mGrip. Pressure for DIY PneuNets depends on design and silicone. mGrip control units run on 24 V
- Motor
- elastomer body with embedded air chambers (PneuNets), inflated to bend, twist or grip
- Range
- bending motion set by chamber geometry and a stiffer strain-limiting layer
- Other
- mGrip handles workpieces up to 300 mm wide at up to 120 picks per minute, with FDA-compliant materials and an IP69K washdown option for food handling
Gentle grasping of fragile, irregular objects such as fruit, baked goods and meat, and safe soft robots and rehabilitation gloves.
Precise positioning, high force or fast closed-loop control, since the actuator is compliant and needs a compressor, valves and tubing.
Harvard's 2011 multigait soft quadruped (Shepherd et al.) crawled on PneuNet legs. Soft grippers of this type are common in food and e-commerce picking. SoFi, the MIT robot fish, uses a related soft actuator, but its tail is driven by pumped water rather than air.
Sources PneuNets bending actuators (Soft Robotics Toolkit) ↗ · Finger Grippers mGrip (Schmalz) ↗ · Soft Robotics Inc. (divestiture notice) ↗
Buying DIY parts (Smooth-On style casting silicone, 3D-printed molds) from general suppliers. mGrip through Schmalz Inc. (Raleigh, North Carolina) by quote (unconfirmed).
Shape memory alloy wire (Dynalloy Flexinol)
Dynalloy price guide (September 2026 archived copy), average cost per meter for orders up to 100 m. $5–6/m for 0.004–0.006 in wire, $6–12/m for thinner and thicker sizes, $3–7/m up to 1,000 m. RobotShop sells 1 m of 200 µm LT wire for $6.50 (unconfirmed).
Flexinol is Dynalloy's trade name for nickel-titanium 'muscle wire' that shortens when heated past its transition temperature and stretches back as it cools under a light load. It is driven simply by passing current through the wire. RoBeetle went further, coating NiTi wire with platinum so that burning methanol vapor heats it, with no electronics at all. This is a family entry, since no guide robot names Flexinol as its wire.
- Force
- heating pull force 8.9 g (0.025 mm wire) to 3,560 g (0.51 mm wire) at 172 MPa. Example 0.15 mm wire pulls 321 g
- Speed
- contracts in about 1 s at the listed current. Cooling (relaxing) takes 0.15 s for 0.025 mm wire up to 14–17 s for 0.51 mm wire in still air
- Size
- diameters 0.025–0.51 mm (0.001–0.020 in)
- Current
- about 45 mA (0.025 mm) to 4,000 mA (0.51 mm) for a 1 s contraction. Example 0.15 mm wire 410 mA, resistance 55 Ω/m
- Motor
- nickel-titanium shape memory alloy, heated by its own resistance
- Range
- repeatable contraction of 2–6% of wire length (typically 2–5%)
- Other
- Standard 70 °C (LT) and 90 °C (HT) transition wires. Tens of millions of cycles possible within the guideline stresses, far fewer if overstressed or overheated
Silent, tiny, very light pulling actuators, such as micro robots, latches, small grippers and animatronic details, where a motor will not fit.
Speed or efficiency, since cooling limits cycling to roughly 1 Hz or less for thicker wire, efficiency is a few percent, and stroke is only a few percent of length, so long wires or levers are needed.
RoBeetle and DASH use nickel-titanium wire of unstated brand. SMA wire is also used in many insect-scale robots and in products such as camera autofocus, valves and latches.
Sources Flexinol technical wire data (Dynalloy) ↗ · Flexinol price guide (Dynalloy) ↗ · RoBeetle (IEEE Spectrum, 2020) ↗
Buying Direct from Dynalloy (California) by quote and order, or in small lengths from RobotShop and other hobby shops. Delivery times not stated (unconfirmed).
Piezoelectric bimorph bending actuators (Thorlabs PB4NB2W reference)
Thorlabs US store prices from a July 2025 archived copy of the bender page (the live site would not load for a direct check in October 2026). PB4VB2W $66.54, PB4NB2W $78.52, PB4NB2S with PEEK holder $123.37. Ring bender PB44NBX $367.00 (unconfirmed).
A bimorph bender bonds two piezoceramic layers so that one stretches while the other does not, bending the strip when voltage is applied. This is a family entry. Harvard's RoboBee and HAMR and the University of Washington's RoboFly use custom-cut laminated PZT bimorphs, amplified by flexure transmissions to drive wings at about 120–140 beats per second or legs at up to 45 Hz, and Festo's BionicANTs use trimorphic piezo-ceramic bending transducers. None of them uses a commercial Thorlabs part. RoboFly's onboard circuit boosts 7 V to the 240 V its actuators need. Commercial benders like Thorlabs' are the off-the-shelf version for experiments.
- Force
- blocking force 1.5 N (PB4NB2W), 1.4 N (PB4VB2W), 13 N (PB44NBX ring, unconfirmed)
- Speed
- resonant frequency 370 Hz (PB4NB2W), 930 Hz (PB4VB2W), 2.0 kHz (ring), sub-millisecond response
- Size
- PB4NB2W 32.0 × 7.8 × 0.8 mm with 28 mm free length. PB4VB2W 20.0 × 8.0 × 0.8 mm
- Voltage
- 0–150 V (rectangular benders), 0–200 V (ring bender)
- Motor
- multilayer co-fired PZT ceramic bimorph
- Range
- tip deflection ±450 µm (PB4NB2W), ±135 µm (PB4VB2W), ±185 µm (ring)
- Other
- Three electrodes allow single-sided or differential drive in either direction. Bare benders are vacuum compatible to 10⁻⁷ Torr, the PEEK-holder versions are not
Insect-scale robots that need very fast, tiny, high-frequency motions, such as flapping wings at over 100 Hz or running legs, plus lab positioning and valves.
Anything needing large motion or force, since tip travel is under a millimeter and force about 1 N. Drivers need 150–240 V, which is hard to produce on a tiny robot.
Robots in the guide that use this type of actuator
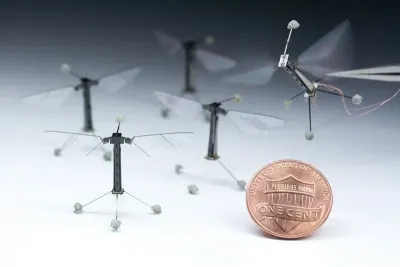 Harvard RoboBee / RoboBee X-WingNot for sale
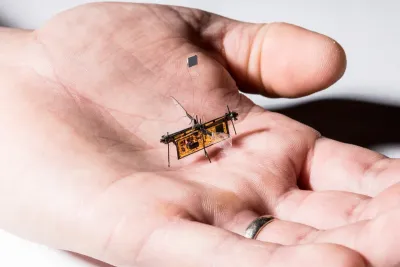 RoboFlyNot for sale
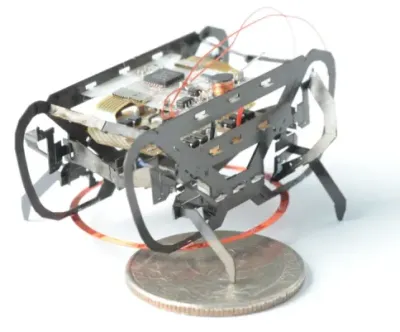 HAMRNot for sale
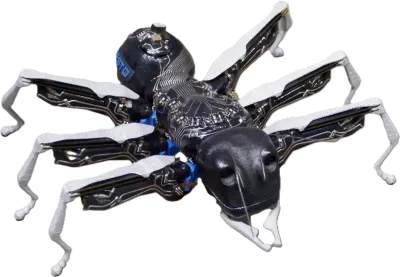 BionicANTsNot for sale
Sources Piezoelectric Benders (Thorlabs) ↗ · PB4NB2W item page (Thorlabs) ↗
Buying Thorlabs, which is based in Newton, New Jersey. Stock status and US delivery time not confirmed for October 2026 (unconfirmed).
Clone Robotics Myofiber artificial muscle
October 2026 check. Myofiber is only used inside Clone's own hands and androids. Clone Alpha reservations are listed for a 279-unit run with no public price.
Clone Robotics says it pioneered Myofiber in 2021 as a synthetic muscle fiber matching mammalian skeletal muscle, pressurized with water rather than air. The company describes it as the only artificial muscle combining that weight, power density, speed, force-to-weight ratio and efficiency, a claim not independently verified. It drives the Protoclone V1 android shown in February 2025.
- Force
- at least 1 kg (about 10 N) of contraction force from a single 3 g fiber (company figure)
- Speed
- responds in under 50 ms (company figure)
- Motor
- water-driven (hydraulic) soft artificial muscle, built as monolithic musculotendon units
- Range
- over 30% unloaded contraction (company figure)
- Other
- Protoclone V1 uses more than 1,000 Myofibers driven by a 500 W pump acting as its heart (company figure)
Biomimetic androids and hands that copy human anatomy, with muscles attached to the real attachment points on a synthetic skeleton.
Anyone who wants to buy actuators, since it is not for sale, and independent tests of force, efficiency or lifetime have not been published.
Robots in the guide that use it
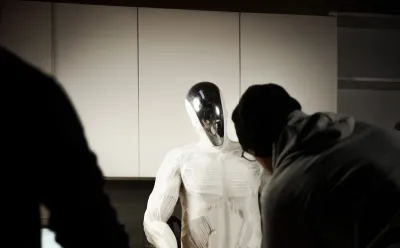
Clone Hand, the company's earlier robotic hand, was reported in 2023 as buildable for $2,800.
Sources Clone android and Myofiber description (Clone Robotics) ↗ · Clone Robotics home ↗
Buying Not available.
Series elastic actuators (HEBI T-Series and legacy X-Series)
HEBI online store (shophebi.com), October 2026 check. Every T-Series model (T5-1 to T25-40) is listed at $3,000.00. The sealed R-Series is $4,500.00 and the H-Series $10,000.00. The X-Series is legacy and no longer sold new.
A series elastic actuator puts a spring between the gearbox and the load and measures its twist to know the output torque, an idea from MIT's Leg Lab in the 1990s (unconfirmed). HEBI, founded in 2014 as a spin-off of Carnegie Mellon's snake robot lab, packages motor, gears, spring, encoders and control electronics into each module. Its X-Series from 2016 is now discontinued, replaced by the T-Series with higher continuous torque and longer life. This is a family entry, and the linked CMU snake and hexapod robots use the lab-built modules that preceded HEBI's products.
- Torque
- T5-1 2.5 N·m peak / 1.3 N·m continuous, T8-9+ 23 N·m peak / 10 N·m continuous, T25-40 80 N·m peak / 40 N·m continuous
- Speed
- T5-1 90 rpm, T8-9+ 39 rpm, T8-3+ 110 rpm, T25-8 118 rpm max
- Weight
- T5 450 g, T8 575 g, T25 1.5 kg
- Size
- T5 126 × 74 × 34 mm, T8 126 × 74 × 48 mm (15 mm hollow bore), T25 170 × 105 × 67 mm (20 mm bore)
- Voltage
- 24–48 V DC (T5, T8), 36–48 V DC (T25) per the datasheet, rated at 24 V with output limited in firmware to the 36 V equivalent. The store page says 18–48 V
- Current
- T8 1.0 A continuous / 2.5 A peak at 36 V
- Motor
- brushless DC with geartrain and an output spring
- Feedback
- multi-turn absolute position (±4 turns), velocity, output torque (0.01 N·m resolution) via the spring, 3-axis IMU, temperatures, voltage, current, internal pressure
- Interface
- 10/100 Mbps Ethernet carried over plastic optical fiber (two OptoLock ports per actuator, media converter to RJ45), APIs for MATLAB, ROS, Python and C/C++
- Range
- continuous rotation, no homing needed at boot
- Other
- Series spring between gearbox and output gives measured, compliant torque. Angular resolution 0.005°, backlash ±0.25°, designed for IP65
Research arms, legged robots and snakes that need accurate torque sensing, impact tolerance and safe contact with people.
Fast, stiff, high-bandwidth positioning, since the spring adds compliance. HEBI units are also far more expensive than hobby or quasi-direct-drive actuators.
Robots in the guide that use this type of actuator
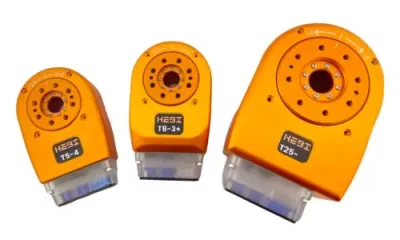 HEBI Robotics actuator modulesQuote
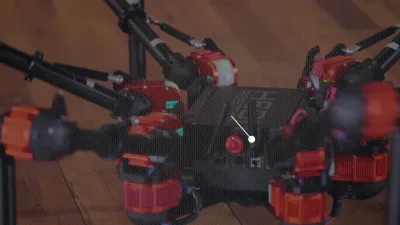 HEBI DaisyQuote
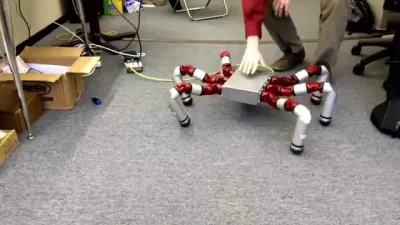 Snake MonsterNot for sale
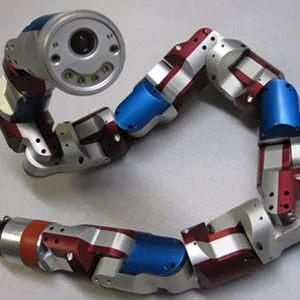 CMU Modular Snake RobotsNot for sale
Rethink Robotics' Baxter and Sawyer and ANYbotics' ANYmal C (ANYdrive) use series elastic actuators of their own design, not HEBI modules. NASA's Valkyrie humanoid also used series elastic actuators (unconfirmed).
Sources T-Series datasheet (HEBI Robotics PDF) ↗ · T-Series store page (HEBI) ↗ · HEBI actuators overview ↗
Buying HEBI online store, HEBI is based in Pittsburgh, Pennsylvania. Shipping times not stated (unconfirmed).