Comparison table
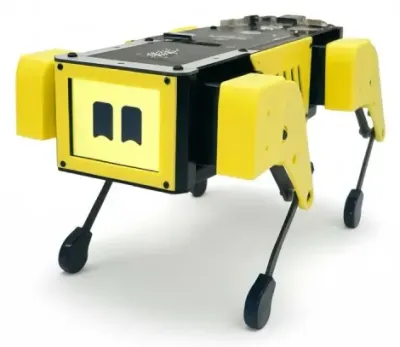 Mini Pupper 2MangDang | 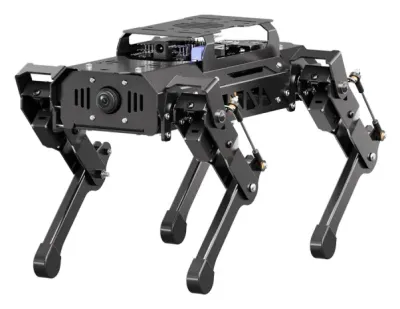 PuppyPi ProHiwonder | 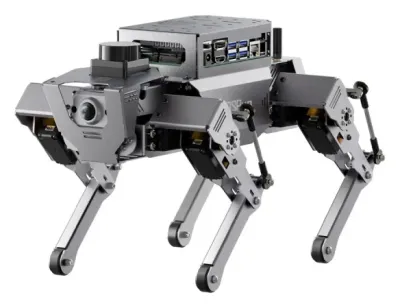 ROSPugHiwonder | 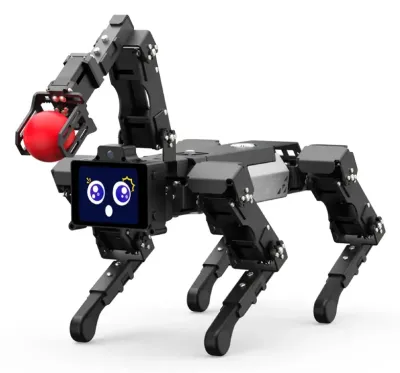 XGO-Mini2SLuwu Dynamics | |
|---|---|---|---|---|
| Price | ||||
| Price including lidar | ~$768 ($649 robot + $119 STL-06P lidar) | $829.99 – $1,179.99 (Pro and Pro Ultimate) | $1,129.99, one version | $1,599 at RobotShop |
| Stock (October 2026) | Available | Available | Available | Restocking |
| Mapping | ||||
| Lidar | LDROBOT STL-06P add-on, 360°, 12 m | LDROBOT LD19, 360°, ~12 m (unconfirmed) | Oradar MS200 TOF, 360° | Built in, model not named, 360°, 12 m |
| Official mapping (SLAM) | SLAM Toolbox, plus a Cartographer config in the repo | slam_toolbox on ROS 2, Gmapping, Hector and Karto on ROS 1 | Gmapping | None yet, a lidar scan demo only. Luwu lists SLAM as planned |
| Navigation | Nav2 with AMCL | Nav2 on ROS 2, move_base on ROS 1, multi-point routes | move_base with TEB or DWA planners, multi-point routes | None official |
| ROS version | ROS 2 Humble | ROS 2 Humble on Pi 5 kits, ROS 1 Noetic on Pi 4B kits | ROS 1 Melodic on Ubuntu 18.04 (both past end of life) | ROS 2 image in early alpha |
| Odometry for mapping | Walking odometry fused with the IMU | Published, source not documented | Laser odometry from the lidar scans | Placeholder odometry in a community port only |
| Charging dock | – No | – No | – No | – No |
| Legs and battery | ||||
| Leg servos | 12 (3 per leg), position feedback | 8 (2 per leg), coreless | 12 (3 per leg) serial bus servos with feedback, 30 kg·cm | 12 (3 per leg) with magnetic encoders, plus a 3-DOF arm |
| Weight | ~560 g | 720 g | ~1.65 kg | 915–950 g |
| Battery | 1000 mAh, ~30–50 min (press report) | 7.4 V 2200 mAh, runtime not published | 11.1 V 3500 mAh, runtime not published | 7.4 V 3800 mAh, up to ~2 h (maker) |
| Charging | Plug-in charger | Battery unplugged under a belly plate, ~1.5 h | Battery leads moved to a 12.6 V charger, ~1 h | 8.4 V charger, 1.5–2 h |
| Brain and camera | ||||
| Computer | Raspberry Pi CM4, mapping runs on a separate PC | Raspberry Pi 4B or Pi 5 (2–16 GB) | Jetson Nano 4 GB | Raspberry Pi CM5 |
| Camera | Optional add-on, sold separately | 480p, 130° wide angle | 8 MP wide angle | OV5647 (2 MP per RobotShop, 5 MP per Luwu) |
| Programmability | Open source (hardware + software) | Full SDK | Full SDK | Full SDK |
| Purchasing | ||||
| Shipping to the US | From Shenzhen, ~2–3 weeks | From Hiwonder, ~7–8 business days (the Pro is not on Amazon) | From Hiwonder, ~7–8 business days (unconfirmed) | RobotShop, restocking |
Highlighted cells are the strongest in their row. Speeds marked (est.) are not published by the maker. They come from owner measurements or the makers' gait code, explained on each robot page. Prices are US list prices as of September 2026. Each robot's page has full specs, sources and photos.
Which one fits
- Mini Pupper 2 is the cheapest of the four, at about $768 including the lidar, and has the best-documented mapping software, with SLAM Toolbox and Nav2 on ROS 2 Humble and walking odometry fused with the IMU. Mapping runs on a separate computer, the battery lasts about 30–50 minutes (press report), and the lidar and camera are sold separately.
- PuppyPi Pro includes the lidar and has the most mapping tutorials, for both ROS 1 and ROS 2. It walks on only 8 leg servos, ROS 2 needs a Pi 5 kit, and Hiwonder does not publish its runtime.
- ROSPug is the largest and strongest, with 12 bus servos, a lidar and an 8 MP camera included. Its odometry comes from the lidar scans, which avoids foot-slip errors. The software is ROS 1 Melodic on Ubuntu 18.04, both past end of life, and mapping is Gmapping only.
- XGO-Mini2S has the longest runtime, up to about 2 hours, plus encoder servos and an arm. It has no official mapping software yet and costs the most at $1,599, so it suits builders who will write their own mapping stack.