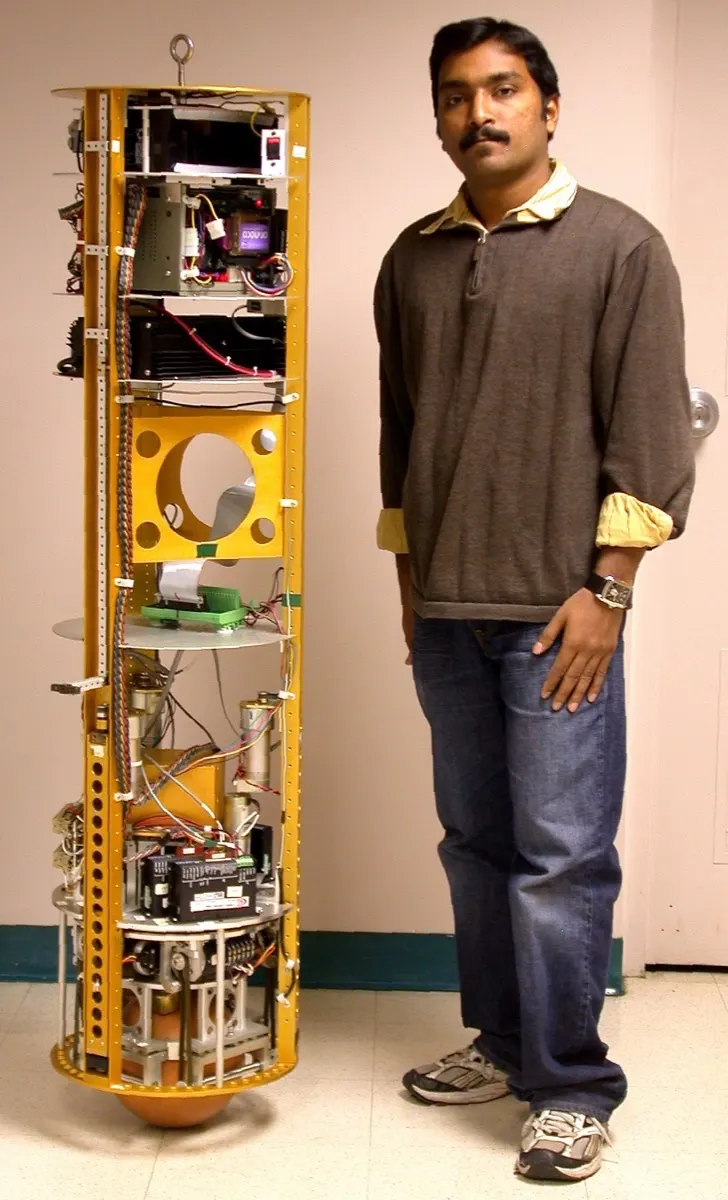
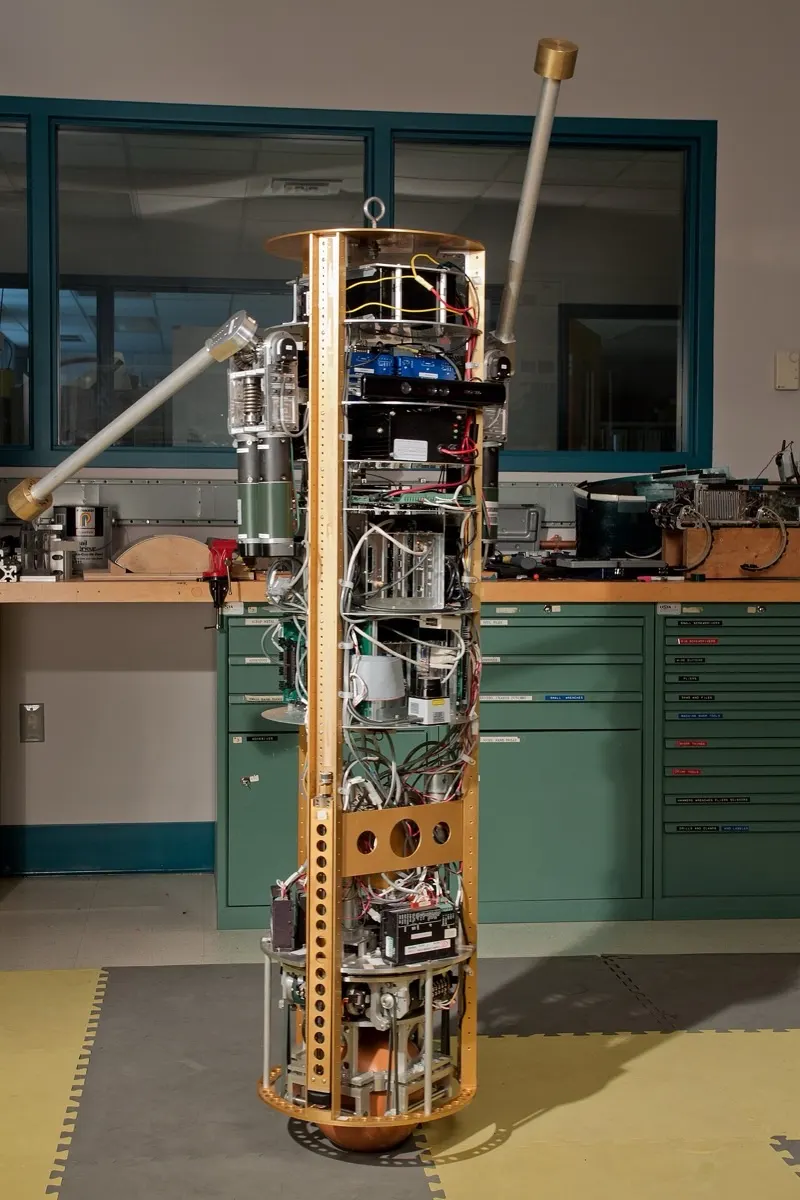
Not soldNSF-funded research platform.
Not for sale (research)Not programmableFirst ballbotPerson-sizedInverse mouse-ball driveResearch
Not soldShipping: N/A. A university research robot. Never sold.
Remote control: Not possible. A university research robot with no public interface.
Overview
The first working ballbot, shown by Ralph Hollis's group at ISRR in October 2005, a tall, thin robot that balances like an inverted pendulum on a single ball and can move in any direction without turning first. The CMU team showed it riding out shoves, navigating offices, and in 2011 it gained a pair of 2-DOF arms. It started the whole ballbot research field.
Specifications
| Category | Spherical & rolling · Research & concepts |
|---|---|
| Released | 2005 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | Lidar |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Unknown |
| Remote control | Not programmable |
| Size | Roughly person height and width, 95 lb (~43 kg) |
| Locomotion | Balances on one urethane-coated metal sphere driven by four rollers (inverse mouse-ball drive), plus a yaw motor, three retractable legs for parking |
| Compute | Onboard computer (details not published) |
| Camera | Not published |
| Sensors | IMU, encoders, Hokuyo URG-04LX laser range finder for localization and obstacle avoidance |
| Runtime | Not published |
| Speed | Not published |
| SDK | Lab-internal |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 BallIPMasaaki Kumagai lab, Tohoku Gakuin University (Japan)Not sold
 RezeroETH Zurich Autonomous Systems Lab focus project, with ZHAW and ZHdK (Switzerland)Not sold
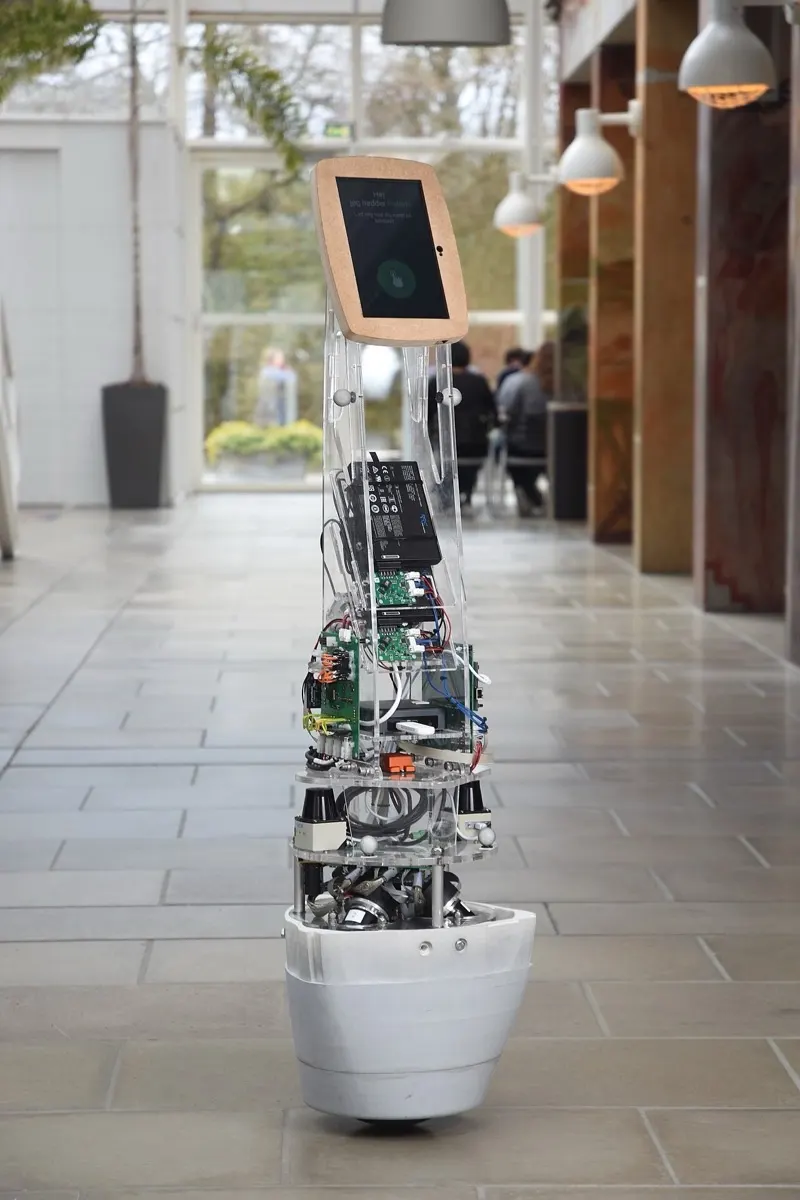 KugleAalborg University (Denmark)Not sold
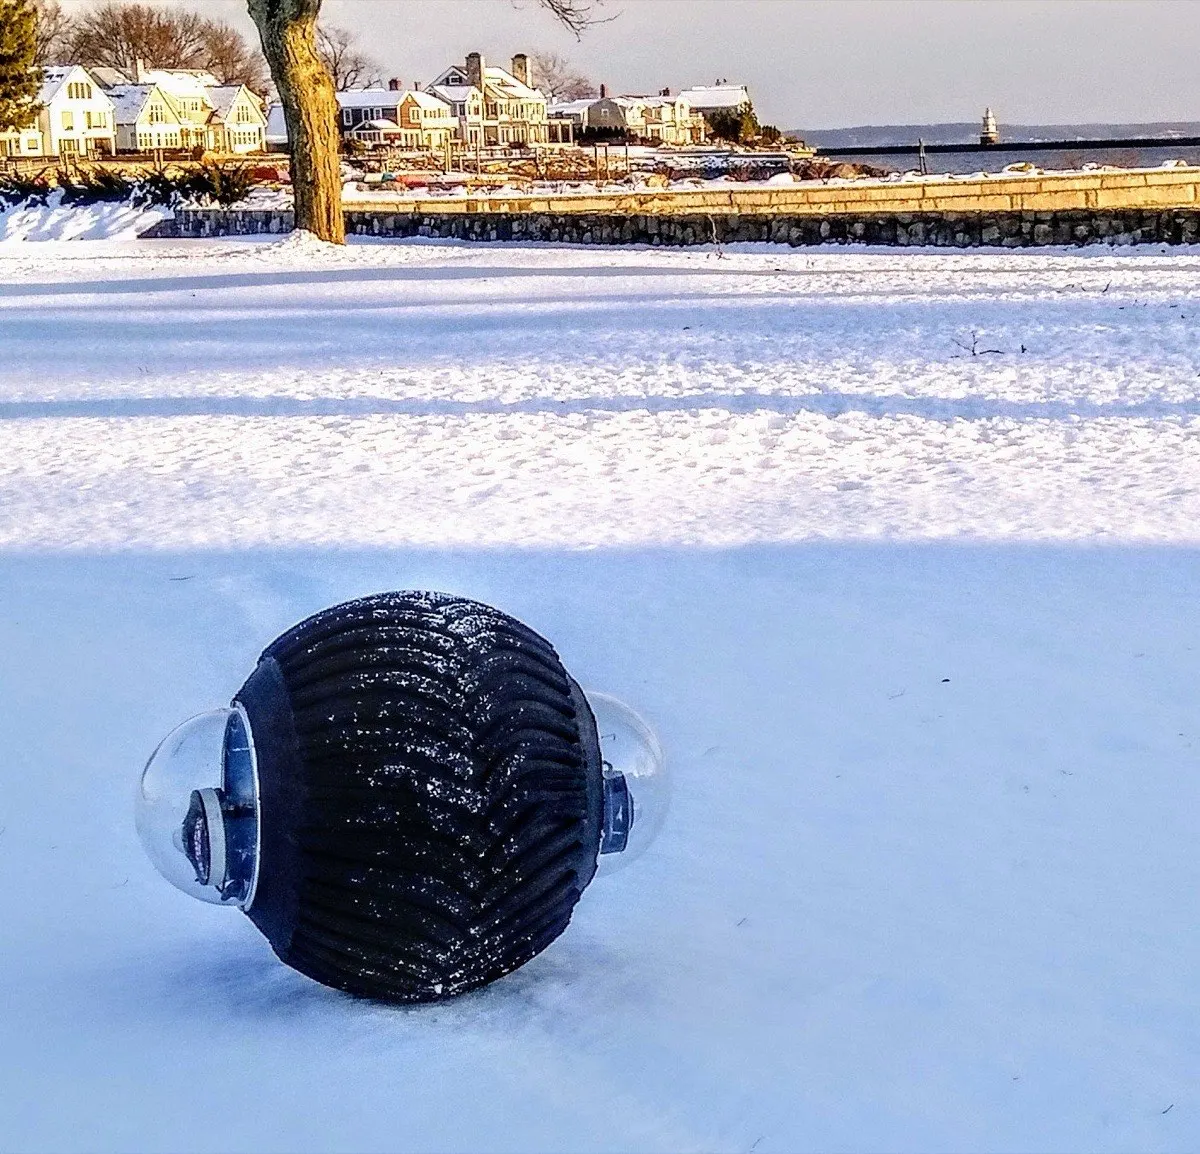 GuardBotGuardBot Inc. (USA / Sweden)Quote only
 Sphero (original) / Sphero 2.0Sphero, formerly Orbotix (USA)Was $129.99 (Sphero 2.0)
 Sphero OllieSphero (USA)Was $99 (2014)