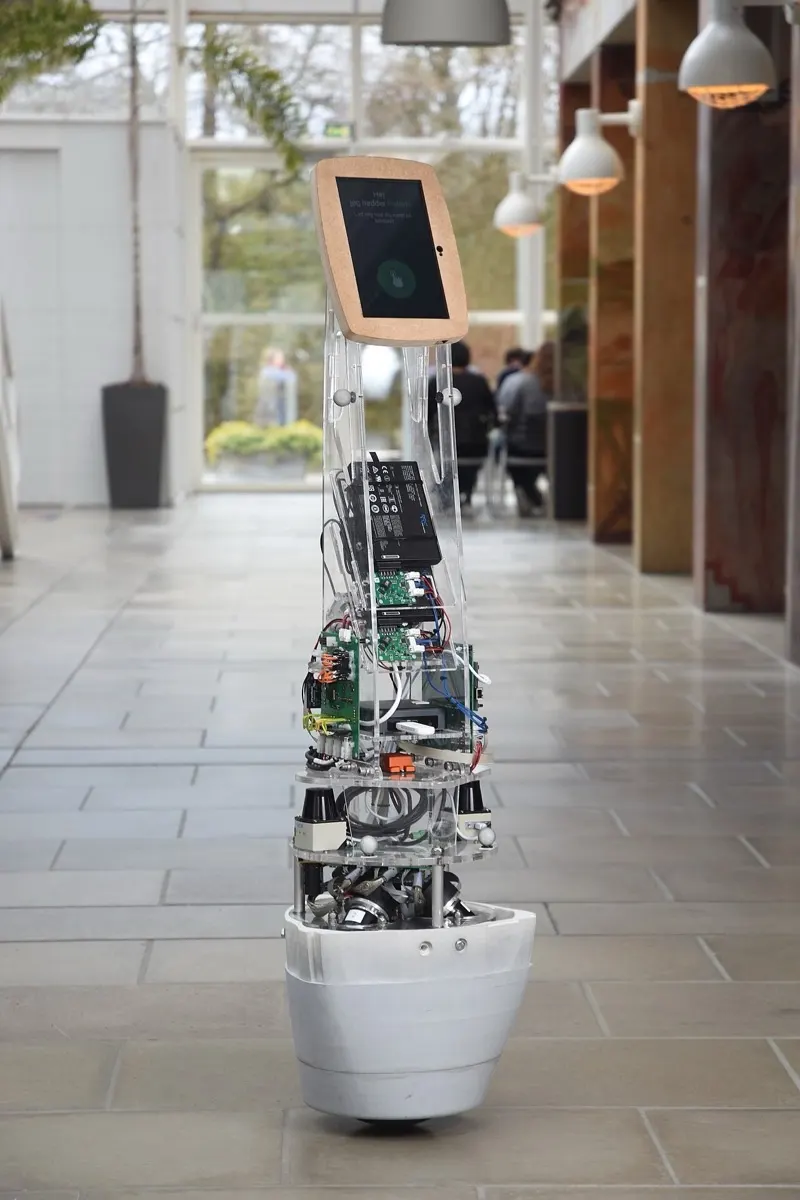
Not soldMaster's thesis robot. All code is MIT-licensed on GitHub.
Not for sale (research)Via SSH / web / bridgeOpen-source ballbotROSMPCResearch
Not soldShipping: N/A. Not sold. The design files and code on GitHub are public, but no kit exists.
Remote control: The published ROS driver runs on the robot's onboard computer. A laptop joins the ROS network over Wi-Fi to send velocity and path commands (only relevant to anyone who rebuilds one).
Overview
A ballbot built as a human guide robot for a 2019 Aalborg University master's thesis, notable for a quaternion-based model, sliding-mode balance control and an MPC path follower. It uses two lidars to localize and detect people. The whole stack (models, firmware, ROS and Gazebo) is open source, which makes it the best public reference for anyone building a ballbot.
Specifications
| Category | Spherical & rolling · Research & concepts |
|---|---|
| Released | 2019 |
| Availability | Not for sale (research) |
| Programmability | Open source (hardware + software) |
| Best for | Professionals & labs |
| Vision sensors | Lidar |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Unknown, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | 16 kg prototype (Kugle V1), roughly waist-to-chest height with a tablet head (est.) |
| Locomotion | Three omni-wheels driving the ball |
| Compute | STM32H7 real-time board (FreeRTOS) plus an onboard ROS computer |
| Camera | Tablet display, no camera published |
| Sensors | IMU, encoders, two SICK TiM571 2D lidars |
| Runtime | Not published |
| Speed | Tested to 1 m/s and 1 rad/s |
| SDK | Open-source MATLAB/Simulink models, embedded firmware, ROS driver and Gazebo simulation (MIT) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
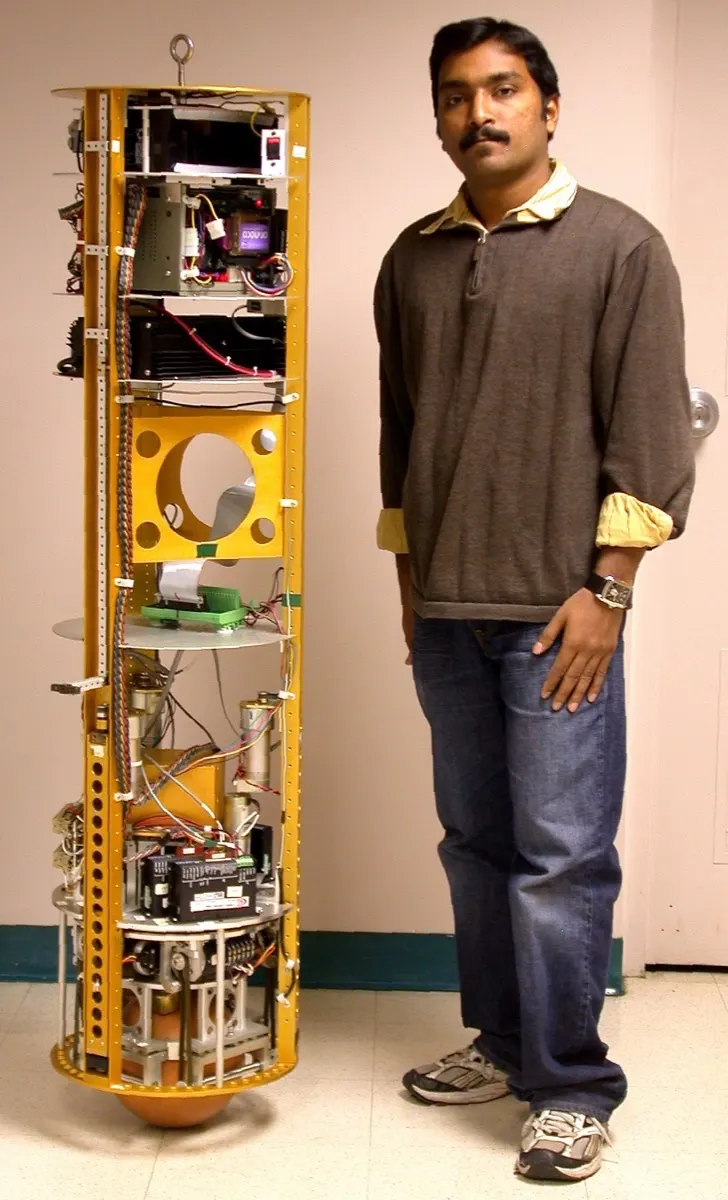 CMU BallbotMicrodynamic Systems Lab, Carnegie Mellon University (USA)Not sold
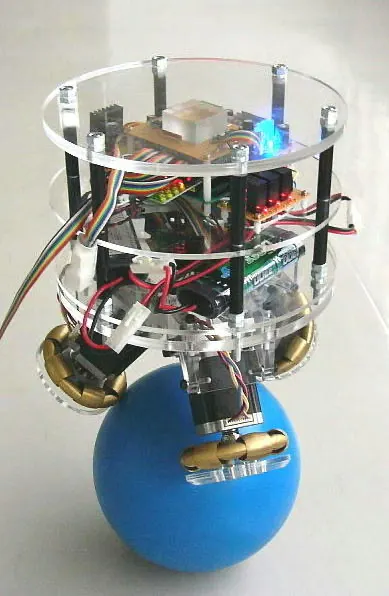 BallIPMasaaki Kumagai lab, Tohoku Gakuin University (Japan)Not sold
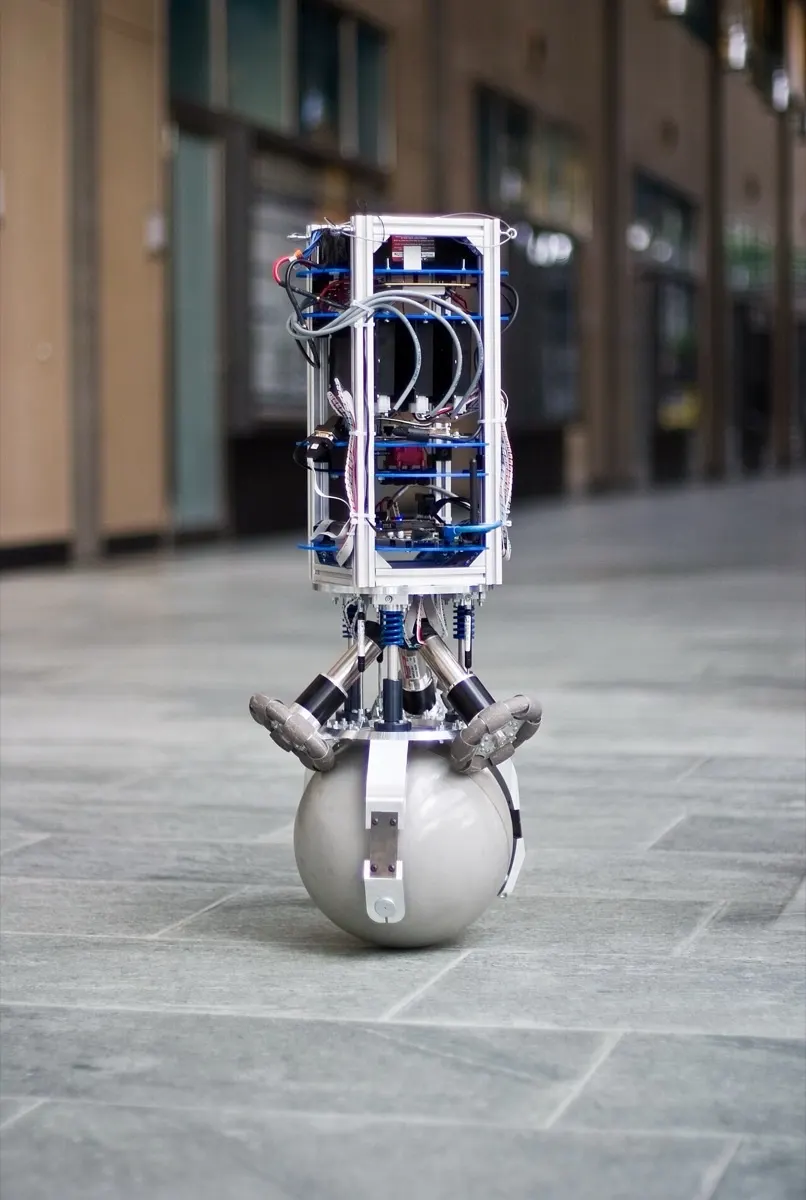 RezeroETH Zurich Autonomous Systems Lab focus project, with ZHAW and ZHdK (Switzerland)Not sold
 GuardBotGuardBot Inc. (USA / Sweden)Quote only
 Sphero (original) / Sphero 2.0Sphero, formerly Orbotix (USA)Was $129.99 (Sphero 2.0)
 Sphero OllieSphero (USA)Was $99 (2014)
Image credits
- Image 1: source (CC BY-SA 4.0, Mindthomas)