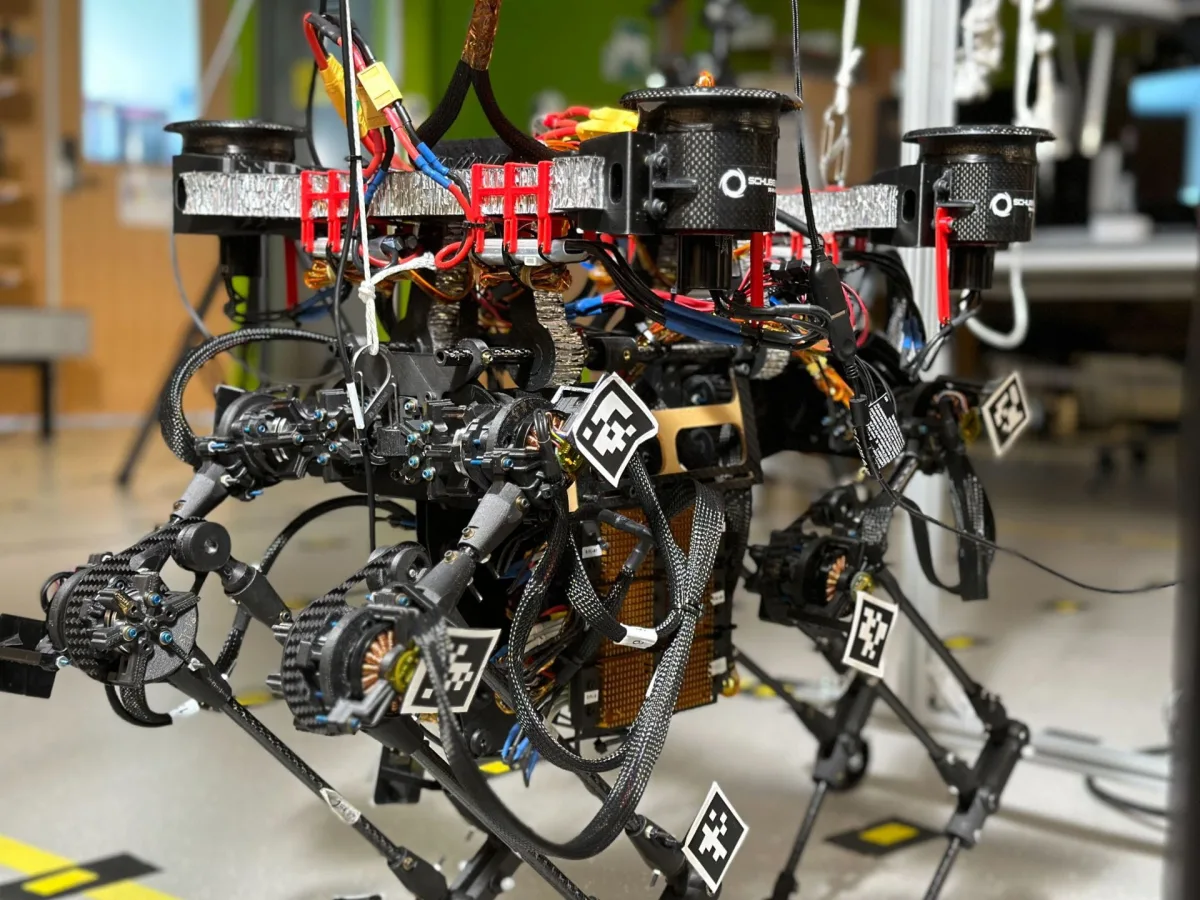
Not for saleUniversity research prototype, first described in a 2021 ICRA paper, with a redesigned v.2 shown in 2025.
Not for sale (research)Not programmableWalks + fliesQuadrupedThruster-assisted
Not for saleShipping: Not for sale. A research prototype that was never sold.
Remote control: Not possible. Research prototype.
Overview
Husky Carbon is a four-legged robot built to both walk and fly, inspired by birds that use their wings while running up slopes. The first version carried four ducted-fan thrusters on its back and trotted in place while held by support ropes, with the thrusters meant to steady its body. Steep-slope and narrow-path walking were shown in simulation. Version 2 (2025) folds its legs outward so propellers at the knees work like a quadcopter, and it trotted and hovered untethered. It comes from the same lab as Aerobat.
Specifications
| Category | Drones · Fly + drive or walk |
|---|---|
| Released | 2021 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | NVIDIA Jetson, Laptop / PC as the brain |
| Remote control | Not programmable |
| Size | Version 1 is about 0.3 m wide and 4.3 kg before thrusters, with height given as 0.8 m (2021 paper) and 0.4 m (2022 paper) |
| Drive | Four legs with three joints each (12 actuators) plus four thrusters. Version 1 uses custom brushless actuators with harmonic drives and four Schubeler electric ducted fans (about 8 kgf total). Version 2 uses Dynamixel servos and four SunnySky X4112S motors with 14-inch propellers at the knees (13.4 kg max thrust), and folds its legs into rotor arms to fly. |
| Compute | Version 1 runs on a Speedgoat IO581 real-time target machine. Version 2 carries a Jetson Orin Nano and a Cube Orange+ flight controller. |
| Vision | Intel RealSense T265 tracking camera (version 1) |
| Lidar | None |
| Sensors | VectorNav VN-100 IMU, Hall-effect encoders on each joint motor, RealSense T265 (version 1) |
| Runtime | Not published. Version 1 ran tethered to an external power supply. Version 2 hovered for about 20 seconds on two 6S LiPo batteries in its test. |
| Speed | Not published |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 LEONARDO (LEO)Autonomous Robotics and Control Lab (Soon-Jo Chung), Caltech (USA)Not for sale
 SPIDARJSK Lab (now DRAGON Lab), University of Tokyo (Japan)Not for sale
 RAVENLaboratory of Intelligent Systems (LIS), EPFL (Switzerland)Not for sale
 M4 (Multi-Modal Mobility Morphobot)Caltech CAST and Northeastern University (USA)Not for sale
 RollocopterTeam CoSTAR, NASA Jet Propulsion Laboratory (USA)Not for sale
 HyTAQRobotics Lab, Illinois Institute of Technology (USA)Not for sale
Image credits
- Image 1: source (SiliconSynapse Lab, Northeastern University, lab photo of version 1)