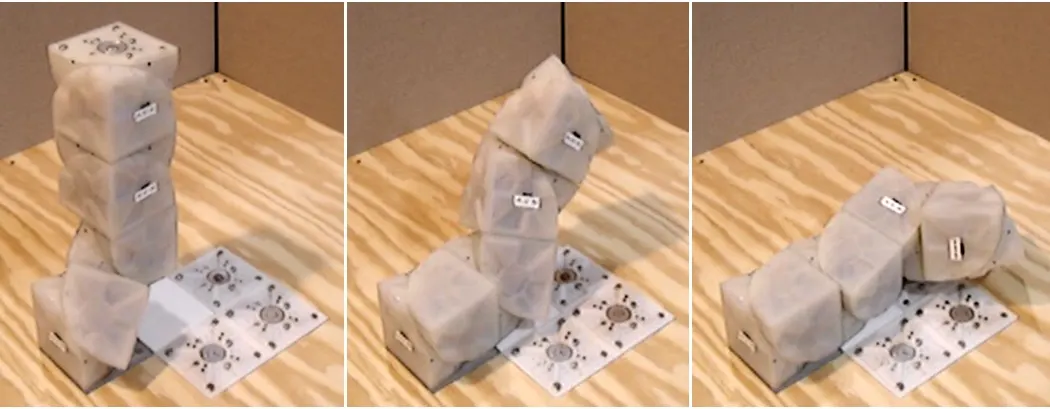
Not soldResearch robot; later open-source redesign supported by Microsoft Research and Festo.
Not for sale (research)Not programmableSelf-replicationOpen sourceCornellDiagonal joint
Not soldShipping: N/A. Research project; not for sale.
Remote control: Not possible for most, since the hardware was never sold; the later open-source designs (blueprints, firmware and schematics) were published for rebuilding.
Overview
Famous for physically demonstrating robot self-reproduction, since three- and four-module Molecube robots built copies of themselves from spare cubes. Created by Hod Lipson, Victor Zykov and Stathis Mytilinaios, it later became an open-source kit design with hinge, gripper, wheel and camera modules. Included here as a pivotal modular-robot milestone just before the 20-year window.
Specifications
| Category | Modular & reconfigurable · Research & self-reconfiguring |
|---|---|
| Released | 2005 |
| Availability | Not for sale (research) |
| Programmability | Open source (hardware + software) |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Not programmable |
| Size | 100 mm cube, 0.65 kg (original) |
| Locomotion | Each cube's two halves rotate about its long diagonal; chains of cubes reconfigure |
| Compute | Microprocessor in one half of each cube |
| Camera | Camera module in later open-source version |
| Sensors | Not published |
| Runtime | Battery module in later version (runtime not published) |
| Speed | Not published |
| SDK | Open-source blueprints, firmware and schematics (GitHub) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 HEBI Robotics actuator modules (X/T/R-Series)
 Roombots
 M-Blocks
 SMORES / SMORES-EP
 CKBot
 Cubelets
Image credits
- Image 1: source (CC BY-SA 2.5 / GFDL, Victor Zykov, Cornell Computational Synthesis Lab)