Quote
AvailableRL walkingOpen-sourceFast runnerResearch
Weeks+Shipping: Not available. Quote-based. Ships from China.
Overview
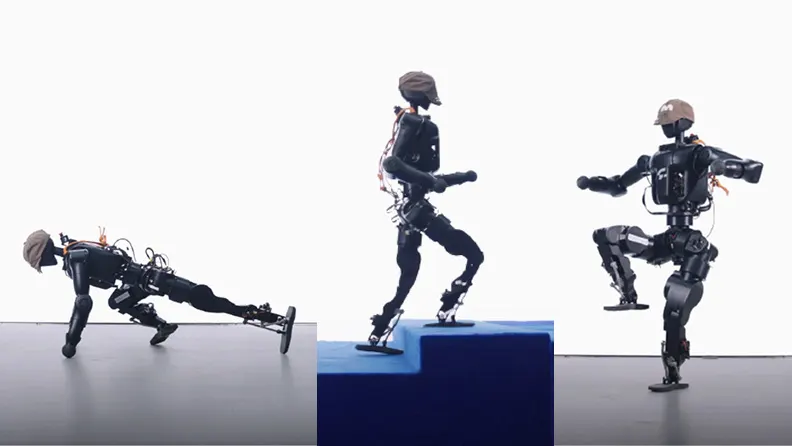
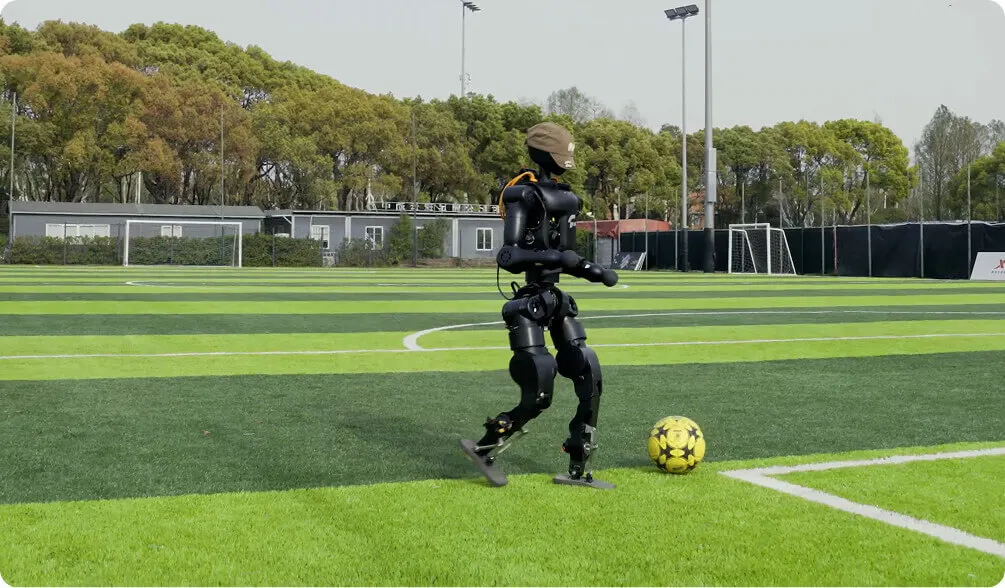
Released in March 2025 as Fourier's first open-source humanoid, publishing designs and software to encourage community research. Compact and sturdy, aimed at RL locomotion work.
Specifications
| Category | Bipeds · Kid-size humanoids (≤ 1.3 m) |
|---|---|
| Released | 2025 |
| Availability | Available |
| Programmability | Open source (hardware + software) |
| Best for | Professionals & labs |
| Vision sensors | Depth camera, Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | Unknown |
| Compute type | x86 PC (Intel / AMD) |
| Balance type | RL walking |
| Height | 124.5 cm |
| Weight | ~39 kg |
| Compute | Intel Core i7-13700H, 16 GB RAM, Ubuntu 20.04 |
| Speed | 2.7 km/h walking, 10.8 km/h (3 m/s) running |
| DOF | 23 |
| Sensors | 6-axis IMU, optional binocular depth camera |
| Balance | RL locomotion. Fourier published training code and demos of running. |
| SDK | Open-source hardware package (schematics, BOM, assembly manuals) and base control code |
Ratings & reviews
Ratings and reviews load on the live site.
 Booster K1
 Mini Pi+
 Bumi
 R1 (Air / R1 / EDU)
 N2
 SA01