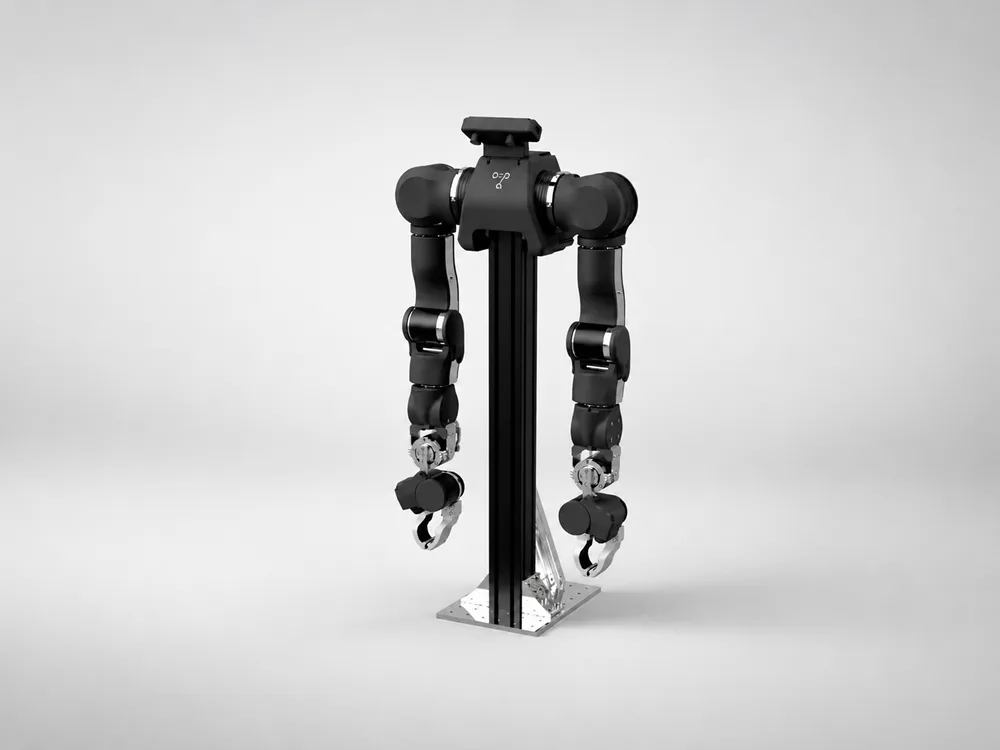
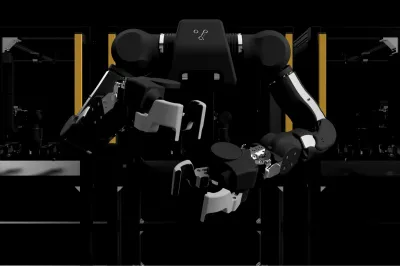
$6,500 assembled pair (WowRobo)WowRobo, an Enactic-certified manufacturer, sells a factory-assembled left and right arm system for $6,500, or $7,300 with a ZED top stereo camera (checked October 2026). Enactic gives the bill of materials as $6,500. RT Corporation sells assembled units in Japan by quote. The motorless OpenArm KER leader is $2,599 at WowRobo, and a 1.0-to-2.0 upgrade kit is $1,080.
AvailablePython from a laptopBimanual 7-DOFForce-feedback teleopIn-hand cameraCAN-FD 1 kHzCERN-OHL-S
Weeks+Shipping: ~4–6 wks (built to order). WowRobo builds each pair to order in Shenzhen with a 20–30 day lead time (Enactic's buying page says 20–40 days), then ships by DHL, UPS or FedEx. Its sample US rates are $480 express air with duties extra, or $800 with duties included. Fixed arms are exempt from the FCC's 2026 robot rule. WowRobo ↗
Remote control: Connects to a Linux PC with SocketCAN through a USB-to-CAN-FD adapter. The
openarm_can library (C++, experimental Python) and the ROS 2 packages run there. macOS has no SocketCAN, so a Mac needs a separate Linux machine.Overview
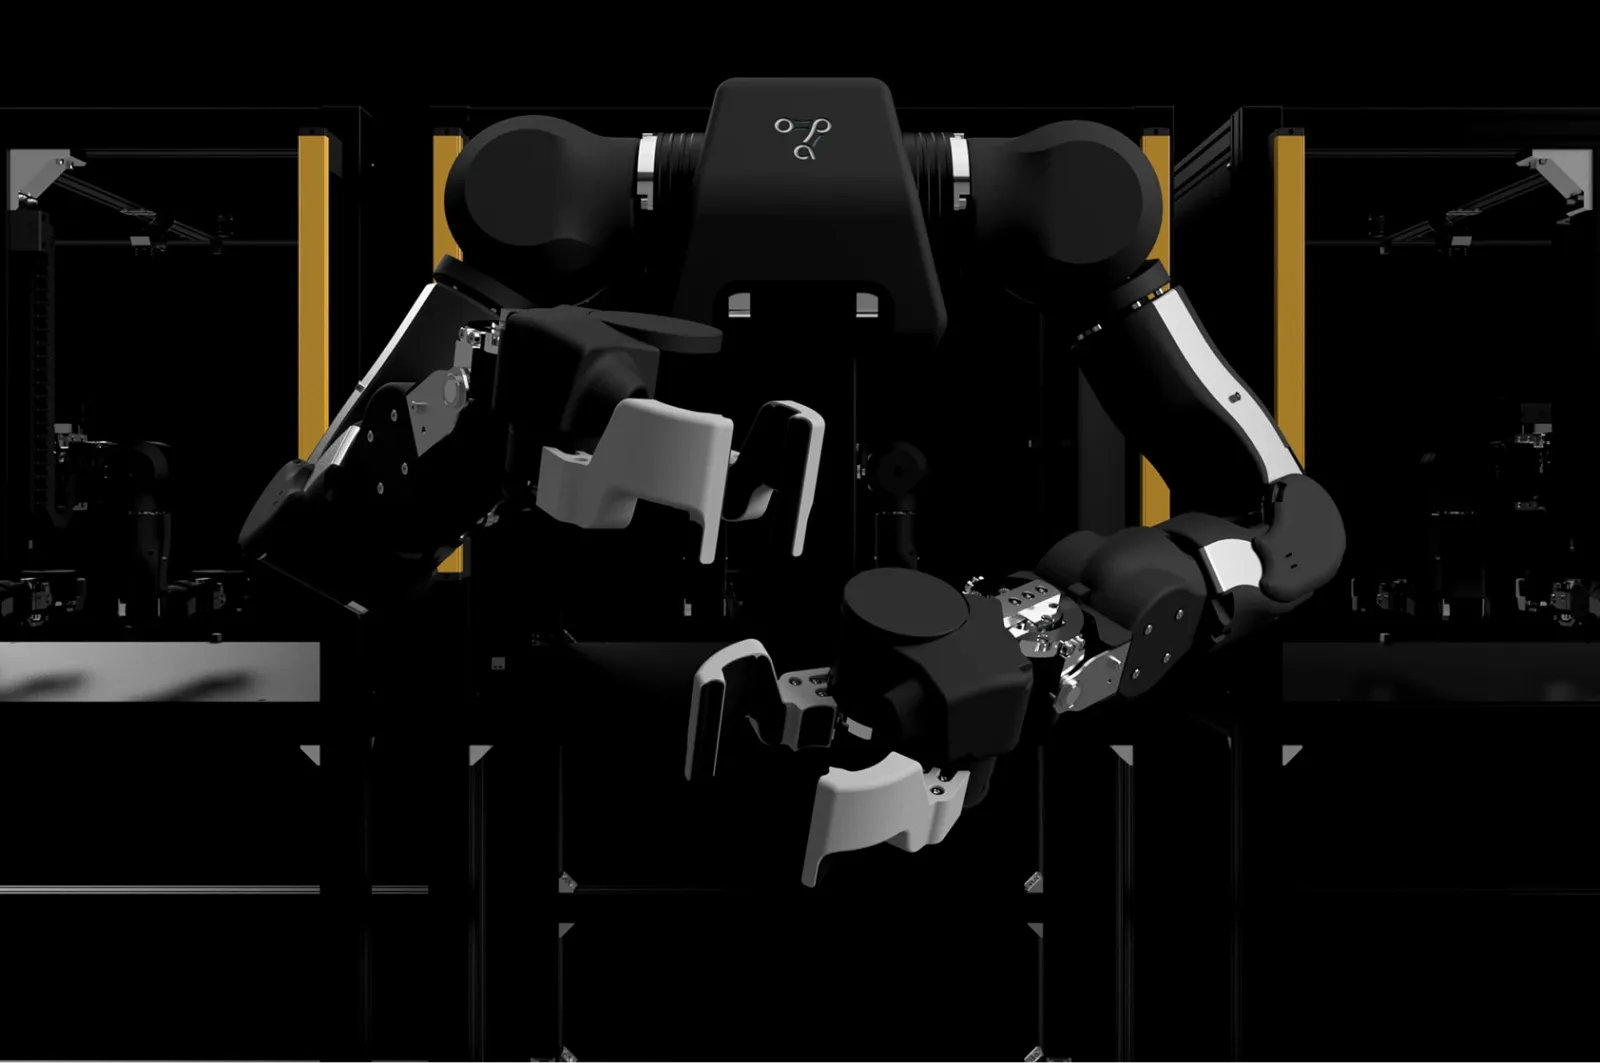
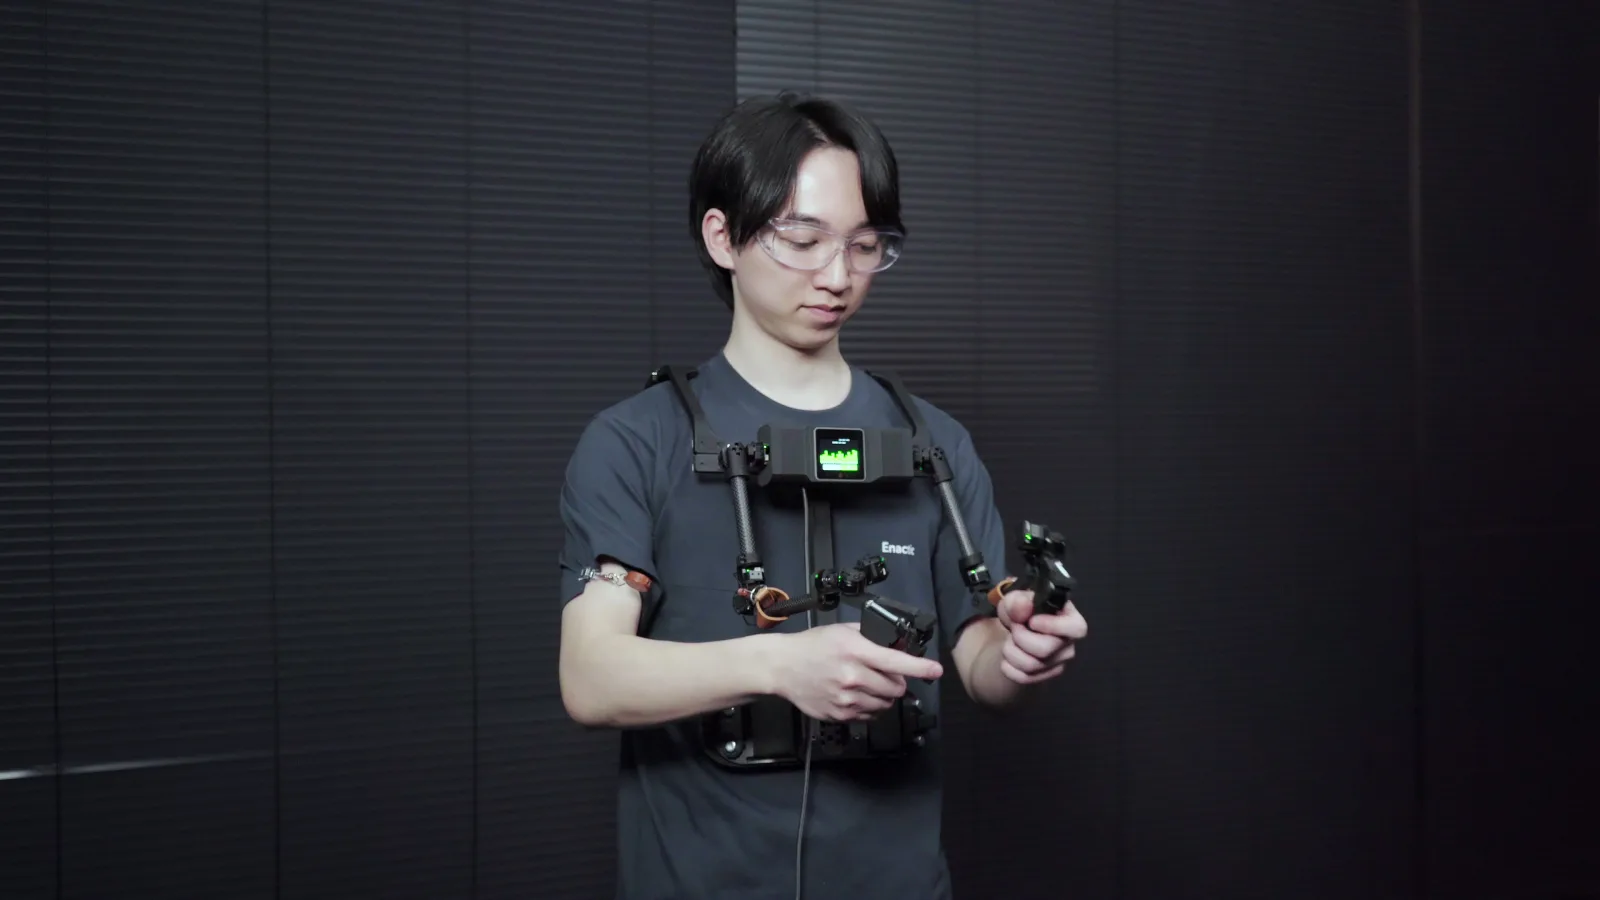
An open-source, human-scale pair of 7-DOF arms built for collecting teleoperation data and testing robot-learning policies. Two-way force feedback between a leader and a follower lets the operator feel contact, and 2.0 adds a compact gripper with a built-in camera. It suits labs that want an open alternative to ALOHA 2-style kits with a much higher payload. The catch is $6,500 for a built pair, a Linux CAN setup, no published repeatability, and a KER leader that Enactic still calls forthcoming.
Specifications
| Category | Robot arms · Research & collaborative arms |
|---|---|
| Released | 2026 |
| Country | Japan |
| Availability | Available |
| DIY build plans | OpenArm · complete system $6,500 · difficulty 5/5 |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No LLM tools from Enactic. Its tutorials train ACT imitation policies through LeRobot and serve them over a policy-server interface, and the C++/Python CAN library and ROS 2 packages could be driven by an LLM on the host PC. OpenArm docs (training) ↗ |
| MuJoCo simulation | Official model · Enactic's openarm_mujoco ships a v2 bimanual MJCF (v2/openarm_bimanual.xml) plus the Cell, and openarm_mjlab adds mjlab integration. openarm_mujoco ↗ |
| NVIDIA Isaac simulation | Official model · Isaac Lab ships openarm.py with one-arm and two-arm configs, and Enactic publishes RL tasks in openarm_isaac_lab. The Isaac model may be the 1.0 arm (unconfirmed). Isaac Lab openarm.py ↗ |
| Gazebo simulation | Maker URDF only · Official URDF/xacro with a ros2_control option for Gazebo effort control, no documented Gazebo launch package. openarm_description ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Python from a laptop |
| DOF | 7 per arm + 2-finger gripper (sold as a left/right pair) |
| Reach | 606 mm |
| Payload | 4.1 kg nominal / 6.0 kg peak per arm, end effector included |
| Repeatability | Not published |
| Weight | 5.5 kg per arm |
| Controller | None on the arm. A Linux PC drives the DAMIAO motors over CAN-FD at 1 kHz through a USB-to-CAN-FD adapter |
| Sensors | Two 14-bit magnetic encoders per motor, RGB camera inside each gripper (30 N nominal grip force), optional ZED stereo top camera (WowRobo) |
| SDK | openarm_can (C++, experimental Python bindings), ROS 2 with MoveIt 2 bimanual config, bilateral and unilateral teleop, Dora nodes for data collection and policy inference, dataset export to LeRobot format |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Niryo Ned2Niryo (France)~€3,990 (ex. VAT)
 ALOHA 2 / Trossen AI StationaryStanford & Google DeepMind (design), Trossen Robotics (kits, USA)$23,995.95
 Unitree Z1 (Air / Pro)Unitree Robotics (China)$15,999 (Z1 Pro)
 Galaxea A1 / LEMO A1ZGalaxea Dynamics (Beijing, China)$2,999 – $3,999
 UFACTORY xArm 5 / 6 / 7UFACTORY (China)$5,799 – $10,499
 UFACTORY 850UFACTORY (China)$9,899