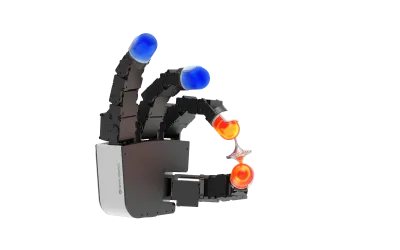
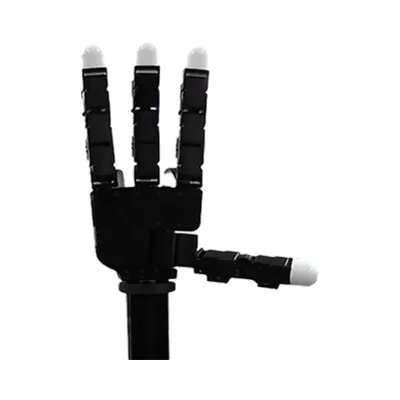
Overview
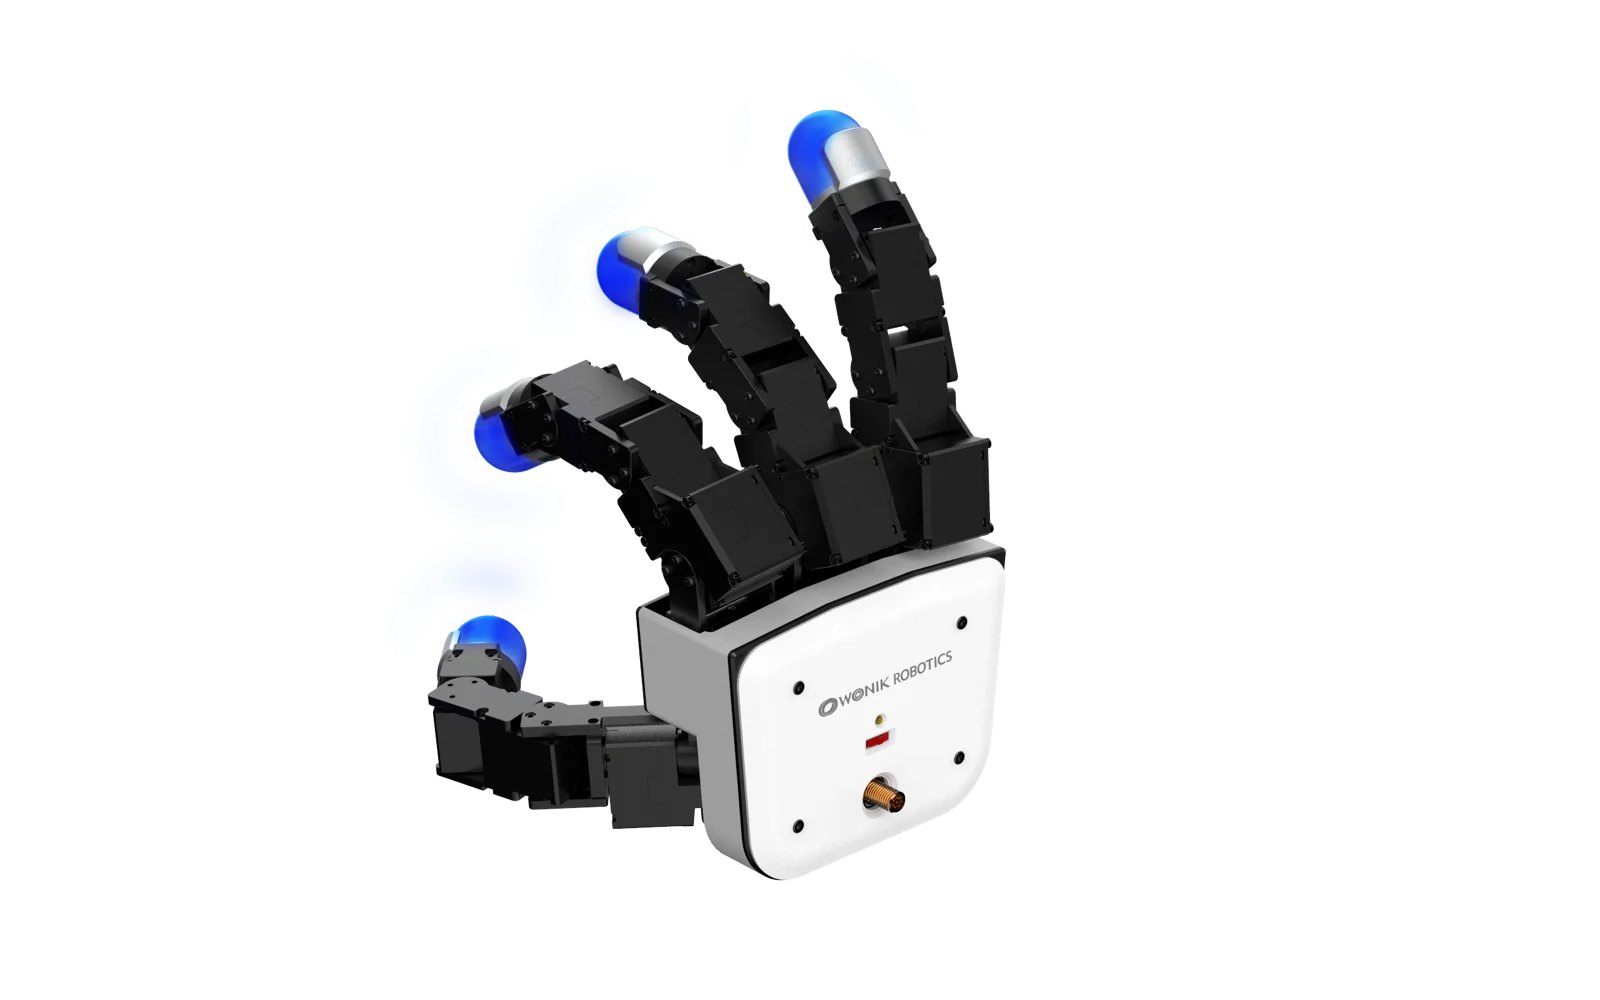
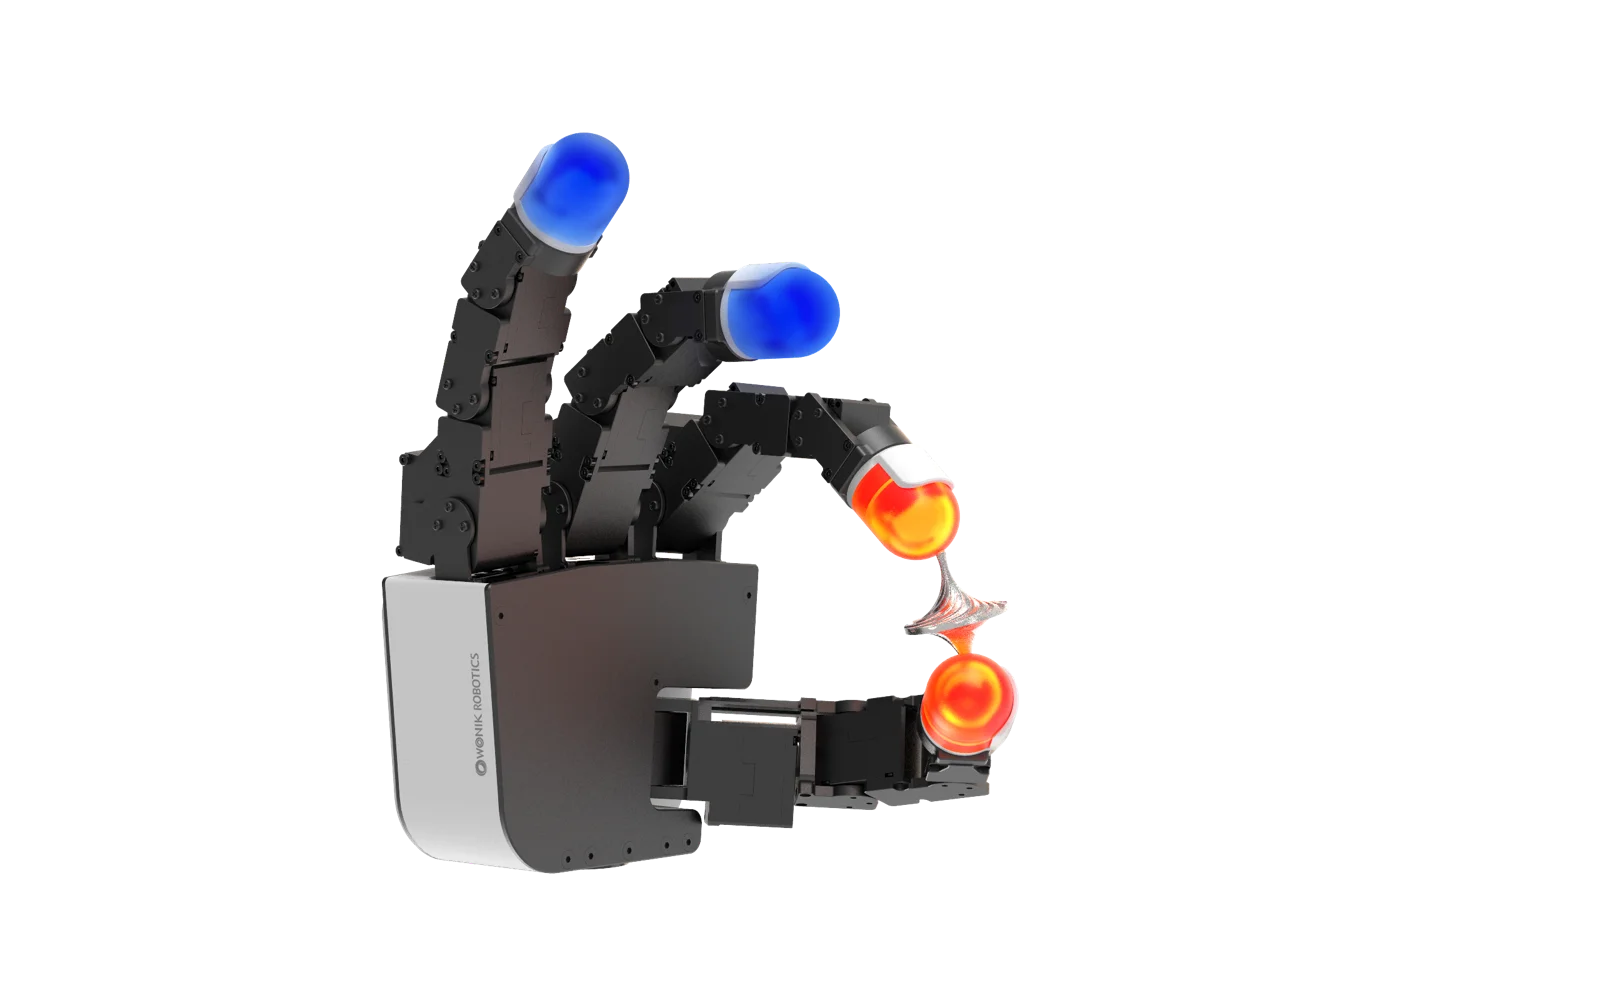
The Allegro Hand is a four-finger research hand from Wonik Robotics (formerly SimLab), based on technology licensed from Korea's KITECH institute. Its first version reached labs around 2012 (unconfirmed). It became a common platform for in-hand manipulation research, including NVIDIA's DeXtreme cube-reorientation work and Haozhi Qi's HORA in-hand rotation. Meta FAIR partnered with Wonik on a tactile-sensing Allegro Hand built on its Digit Plexus platform.
Each finger has four joints, each with its own geared DC motor and current control, so joints can be commanded by torque. The V4 is the long-running classic model. The V5 family adds stronger joints and pressure-based tactile fingertips, and V5 Sense adds 16 sensing channels with abduction. The newest V6 moves to five fingers and 20 DOF with Modbus control. The hand has no wrist. It costs several times more than LEAP Hand, which was designed as a cheaper alternative.
- Type
- Robot hand or gripper · Research & humanoid hands
- Maker
- Wonik Robotics (South Korea)
- Released
- 2012
- Price
- $9,910 (V4)
- Status
- Available
- Best for
- Professionals & labs
- Programming
- Full SDK
Price and shipping
Knoxlabs (US distributor) lists per-hand prices from $6,650 (3-finger V5), $9,910 (V4), $12,040 (V5 Plus), $14,300 (V5 Sense), $16,560 (V6 F) and $19,820 (V6 V). Prices include a provisional import allowance, with freight extra and final pricing on request. Robotics Center lists the V5 Sense at $13,000 (backorder). Checked October 2026.
Shipping: 5–10 days (Knoxlabs) to 4–6 weeks. Knoxlabs, the US distributor, quotes shipping within 5–10 days but asks buyers to confirm stock, handedness and lead time first. Robotics Center lists the V5 Sense on backorder with 4–6 week delivery. Wonik also sells through a regional sales network. Knoxlabs ↗
Specifications
| Category | Robot hands & grippers · Research & humanoid hands |
|---|---|
| Released | 2012 |
| Country | South Korea |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. The official ROS 2 drivers and C++ library let an LLM-driven program on the host PC command the hand. |
| MuJoCo simulation | Official model · In MuJoCo Menagerie (wonik_allegro, left and right Allegro Hand v3 models derived from the maker's URDF). MuJoCo Menagerie wonik_allegro ↗ |
| NVIDIA Isaac simulation | Sim-to-real kit · Isaac Lab ships an Allegro asset and cube reorientation task. Wonik's own allegro_inhand_rotation repo trains in Isaac Gym and runs the policy on a real V4 through ROS 2. Wonik allegro_inhand_rotation ↗ |
| Gazebo simulation | Maker URDF only · Wonik publishes URDF model files for the V4, which need setup for Gazebo. allegro_hand_model_v4 ↗ |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Python from a laptop |
| Fingers | 4 (3 fingers + thumb). V6 has 5, and a 3-finger V5 exists |
| DOF | 16 actuated (V4, V5 Plus, V5 Sense), 20 on V6, 9 on 3-finger V5 |
| Actuation | DC motors with reduction gears built into every finger joint (direct joint drive, no tendons), 1:369 on V4 and 288.35:1 on V5/V6 |
| Grip force / payload | 5 kg (V4), 15 kg (V5 Plus/Sense and V6), as measured by Wonik. Stall torque 0.92 Nm per joint on V5 (1.84 Nm at the 2nd finger joint), V4 max torque 0.70 Nm. Fingertip force up to 10 N per Robotics Center |
| Weight | 1.08 kg (V4), 1,024 g (V5 Plus), 1,240 g (V5 Sense), 1,150 g (V6) |
| Sensors | Joint position sensing (potentiometers on V4, 0.088° resolution on V5), current-controlled joints, pressure-based fingertip tactile sensors on V5 Plus/Sense, plus joint and palm pressure sensors on V6 F, GelSight-style vision tactile fingertips on V6 V |
| Interface | CAN bus to a host PC (333 Hz on V4 and V5 Sense, 500 Hz on V5 Plus), 24 V / 100–120 W. V6 uses RS-485 or Ethernet with Modbus RTU/TCP |
| SDK | Official ROS 2 and ROS 1 drivers per version, Linux and Windows control code, BHand grasping library (also built for Jetson ARM), Allegro Hand UXD GUI, MoveIt support, teleoperation code |
Common questions
How much does Allegro Hand cost?
Allegro Hand is listed at $9,910 (V4). Knoxlabs (US distributor) lists per-hand prices from $6,650 (3-finger V5), $9,910 (V4), $12,040 (V5 Plus), $14,300 (V5 Sense), $16,560 (V6 F) and $19,820 (V6 V). Prices include a provisional import allowance, with freight extra and final pricing on request. Robotics Center lists the V5 Sense at $13,000 (backorder). Checked October 2026.
Can Allegro Hand be bought today?
Yes, it is on sale. Typical shipping time is 5–10 days (Knoxlabs) to 4–6 weeks. Knoxlabs, the US distributor, quotes shipping within 5–10 days but asks buyers to confirm stock, handedness and lead time first. Robotics Center lists the V5 Sense on backorder with 4–6 week delivery. Wonik also sells through a regional sales network.
Who makes Allegro Hand?
Allegro Hand is made by Wonik Robotics (South Korea). It came out in 2012.
Can Allegro Hand be programmed?
Full SDK. Official ROS 2 and ROS 1 drivers per version, Linux and Windows control code, BHand grasping library (also built for Jetson ARM), Allegro Hand UXD GUI, MoveIt support, teleoperation code.
Does Allegro Hand have AI chat or LLM support?
Possible via SDK. No built-in LLM. The official ROS 2 drivers and C++ library let an LLM-driven program on the host PC command the hand.
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 LEAP HandCarnegie Mellon University (Deepak Pathak's lab), open sourceUnder $2,000 DIY parts, Lite ~$715
 Shadow Dexterous HandShadow Robot Company (UK)~$119,000 (quote)
 Inspire Robots RH56 (RH56DFX)Beijing Inspire-Robots Technology$5,783
 PSYONIC Ability HandPSYONICQuote only
 WUJI Hand 2WUJI Tech (Shenzhen Wuji Technology)$14,600
 Xiaomi 21-DoF Bionic HandXiaomi (Xiaomi Robotics team)Not for sale
Sources
V4 specifications ↗ · V5 Sense specifications ↗ · Wonik Robotics GitHub ↗ · Knoxlabs store (V4) ↗ · DeXtreme (NVIDIA, 2022) ↗