Overview
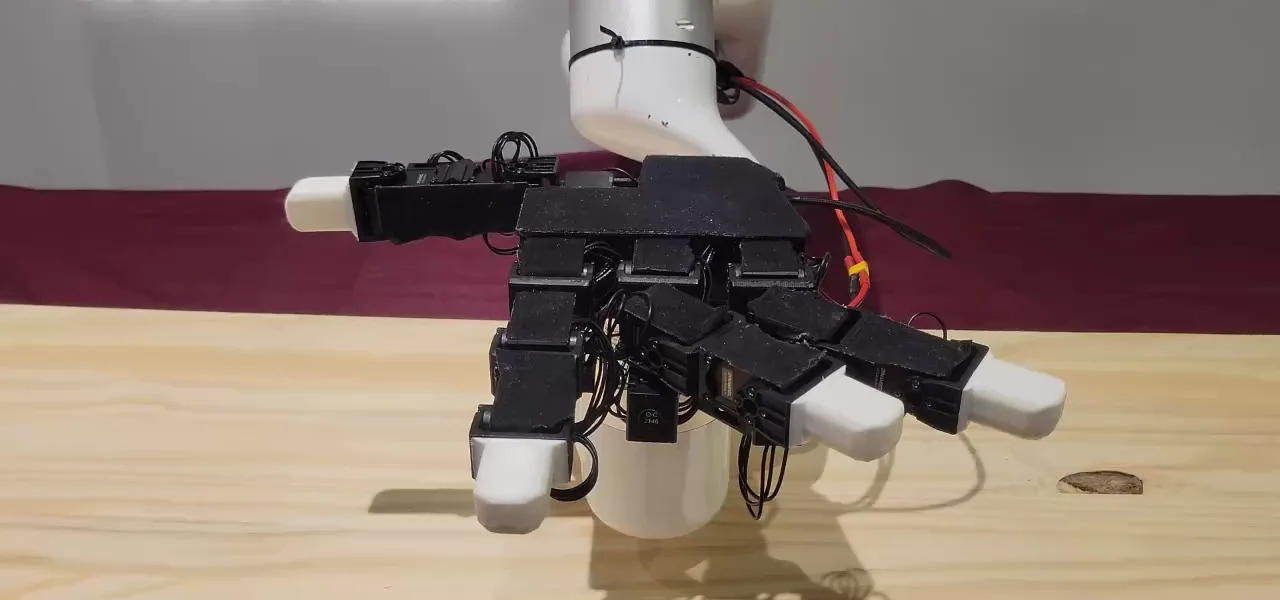
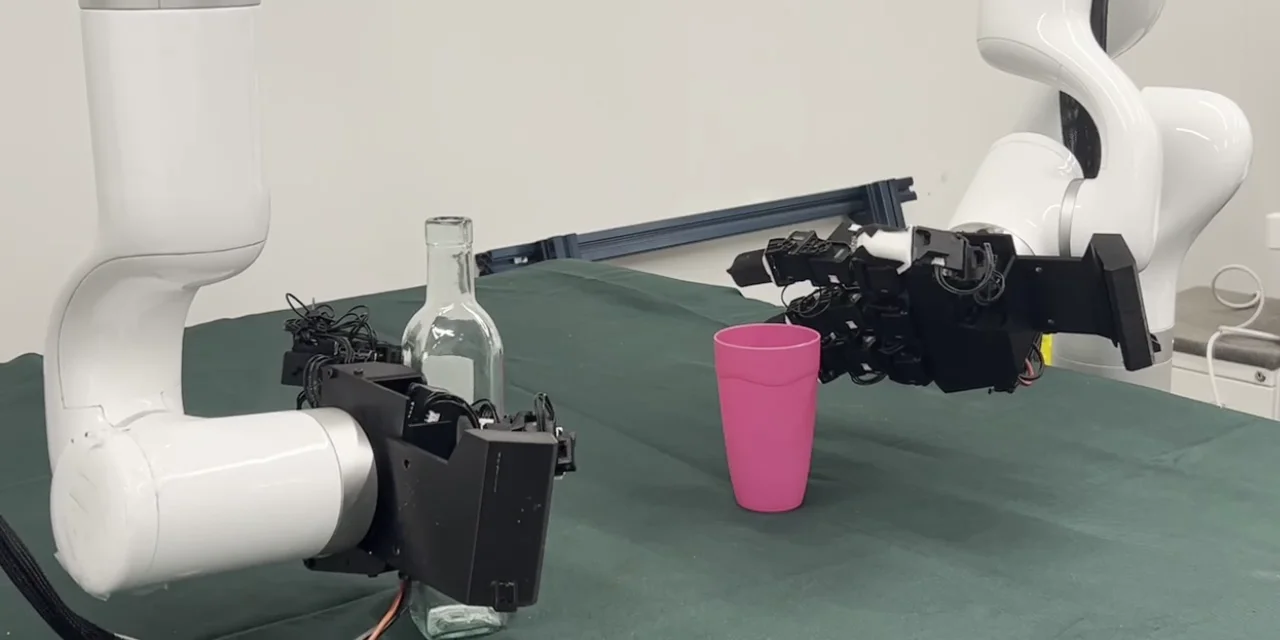
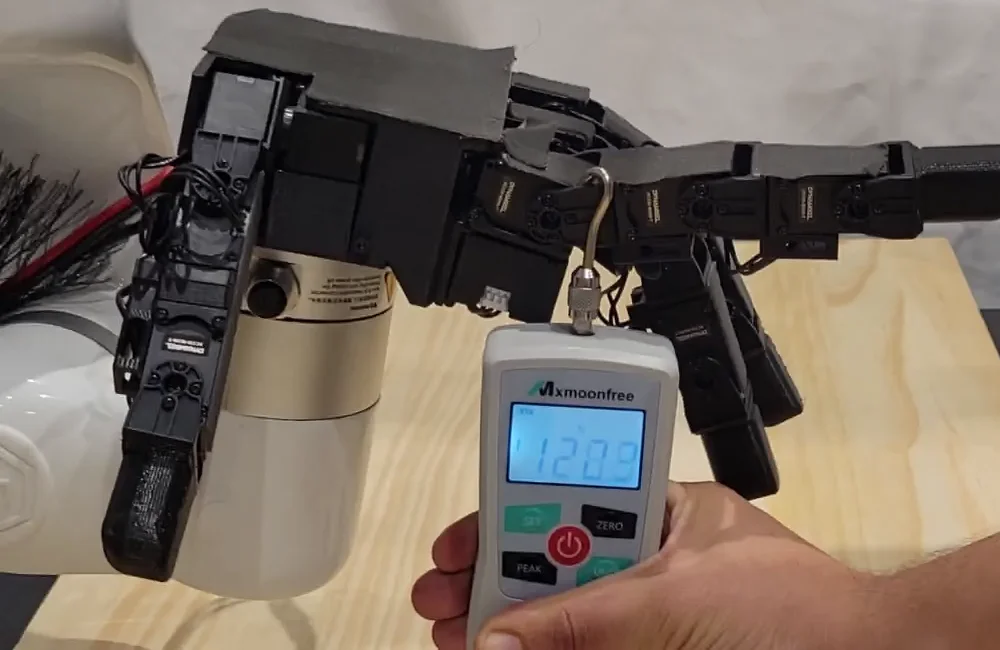
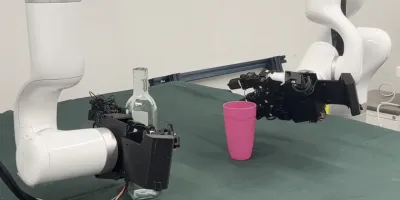
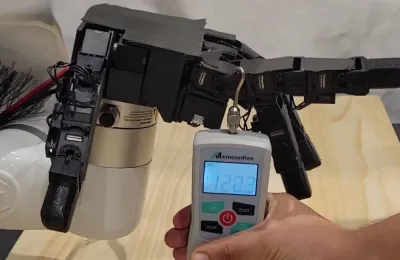
The LEAP Hand is an open-source four-finger robot hand from Carnegie Mellon University, published at RSS 2023 by Kenneth Shaw, Ananye Agarwal and Deepak Pathak. It is built from 16 Dynamixel servos, stock brackets and a few 3D-printed parts, and the project says it assembles in under three hours. Labs use it for dexterous manipulation learning, glove and Apple Vision Pro teleoperation, and sim-to-real in-hand rotation, often mounted on a UFACTORY xArm. In the paper's tests it showed 19.5 N of pullout strength against 8.5 N for the Allegro Hand, at roughly one-eighth of the Allegro's cost.
Every joint has its own servo, so all 16 joints are directly driven, with position, velocity and current feedback but no touch sensing. A universal abduction-adduction knuckle lets each finger swing side to side whether it is bent or straight. The hand weighs 595 g and is about 30% larger than a human hand. In 2025 the lab previewed two tendon-driven successors, where cables pull the finger joints. They are the $200 LEAP Hand v2 with 8 motors and the $3,000 v2 Adv with 17 motors, 21 DOF and a jointed palm. The original v1 CAD is licensed CC BY-NC-SA, so building one for research is allowed but selling builds is not.
- Type
- Robot hand or gripper · Open-source & low-cost hands
- Maker
- Carnegie Mellon University (Deepak Pathak's lab), open source
- Released
- 2023
- Price
- Under $2,000 DIY parts, Lite ~$715
- Status
- Available
- Best for
- Ages 16+
- Programming
- Open source (hardware + software)
Price and shipping
No assembled hand is sold by the project. Its parts list totals $1,771.74 for the full hand and $714.30 for the Lite version (August 2023 prices). Robotis US now lists the XC330-M288-T servo at $103.39 with a one-month lead time, so the 16 motors cost about $1,654 (estimate). The Robotis LEAP Hand Bundle (XC330) of all Dynamixel parts is listed at $1,796.87 but shows sold out with a two-month lead time. The project says its Robotis/Dexbotics kit partnership has ended because of tariffs. A third-party "fully assembled" Amazon listing linked from the project's Purchase page showed "Currently unavailable" (checked October 2026).
Shipping: Weeks+ (parts lead times, then self-assembly). The hand is bought as parts and built by the owner. Robotis US shows a one-month lead time on the XC330-M288-T servo and lists its LEAP Hand Dynamixel bundle as sold out with a two-month lead time. 3D-printed parts take under 24 hours to print, and assembly takes under three hours per the project (October 2026). Robotis US XC330-M288-T ↗
Specifications
| Category | Robot hands & grippers · Open-source & low-cost hands |
|---|---|
| Released | 2023 |
| Country | USA |
| Availability | Available |
| DIY build plans | LEAP Hand · parts $1,800 (2023) (estimate) · difficulty 2/5 |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No official LLM tools. The Python, C++, ROS and ROS 2 APIs take joint-angle commands from a host PC, so an LLM running there could drive it through code. |
| MuJoCo simulation | Official model · Left and right hand models in MuJoCo Menagerie (leap_hand), plus LEAP Hand cube-reorientation tasks in MuJoCo Playground. MuJoCo Menagerie leap_hand ↗ |
| NVIDIA Isaac simulation | Sim-to-real kit · The lab's Isaac Lab extension trains in-hand cube reorientation and deploys it on the real hand through the Python or ROS 2 API. An older Isaac Gym repo (LEAP_Hand_Sim) adds a pretrained policy and sim-to-real code. LEAP_Hand_Isaac_Lab ↗ |
| Gazebo simulation | Maker URDF only · The lab publishes a URDF (assets/leap_hand/robot.urdf in LEAP_Hand_Sim), with no Gazebo package. LEAP_Hand_Sim ↗ |
| Best for | Ages 16+ (estimated) |
| Vision sensors | No vision sensors |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Python from a laptop |
| Fingers | 4 (3 fingers + thumb) |
| DOF | 16 actuated (4 per finger) |
| Actuation | 16 Dynamixel XC330-M288-T smart servos (XL330-M288-T in the Lite version), one at each joint inside the fingers, direct drive through stock FPX330 brackets |
| Grip force / payload | 19.5 N pullout strength (paper test), held a 2 kg weight on one fingertip for an hour |
| Weight | 595 g |
| Sensors | Servo position, velocity and current feedback only, no tactile sensors |
| Interface | USB to a Dynamixel U2D2 adapter and TTL Dynamixel bus, 5 V 30 A power supply, host PC as the brain |
| SDK | Official Python, C++, ROS and ROS 2 APIs (LEAP_Hand_API), Manus glove and Apple Vision Pro teleoperation repos, MANO-to-LEAP retargeting tool |
Common questions
How much does LEAP Hand cost?
LEAP Hand is listed at Under $2,000 DIY parts, Lite ~$715. No assembled hand is sold by the project. Its parts list totals $1,771.74 for the full hand and $714.30 for the Lite version (August 2023 prices). Robotis US now lists the XC330-M288-T servo at $103.39 with a one-month lead time, so the 16 motors cost about $1,654 (estimate). The Robotis LEAP Hand Bundle (XC330) of all Dynamixel parts is listed at $1,796.87 but shows sold out with a two-month lead time. The project says its Robotis/Dexbotics kit partnership has ended because of tariffs. A third-party "fully assembled" Amazon listing linked from the project's Purchase page showed "Currently unavailable" (checked October 2026).
Can LEAP Hand be bought today?
Yes, it is on sale. The hand is bought as parts and built by the owner. Robotis US shows a one-month lead time on the XC330-M288-T servo and lists its LEAP Hand Dynamixel bundle as sold out with a two-month lead time. 3D-printed parts take under 24 hours to print, and assembly takes under three hours per the project (October 2026).
Who makes LEAP Hand?
LEAP Hand is made by Carnegie Mellon University (Deepak Pathak's lab), open source. It came out in 2023.
Can LEAP Hand be programmed?
Open source (hardware + software). Official Python, C++, ROS and ROS 2 APIs (LEAP_Hand_API), Manus glove and Apple Vision Pro teleoperation repos, MANO-to-LEAP retargeting tool.
Does LEAP Hand have AI chat or LLM support?
Possible via SDK. No official LLM tools. The Python, C++, ROS and ROS 2 APIs take joint-angle commands from a host PC, so an LLM running there could drive it through code.
What age is LEAP Hand for?
Ages 16+ (estimated).
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 AmazingHandPollen Robotics (Hugging Face), open source~$140 DIY parts, kits $99 – $179
 Allegro Hand (V4 / V5 / V6)Wonik Robotics (South Korea)$9,910 (V4)
 SO-101 (SO-ARM101)TheRobotStudio × Hugging Face (open source)~$230 DIY parts (pair), kits $199 – $460
 ORCA HandORCA Dexterity (from ETH Zurich's Soft Robotics Lab), open source$3,500 – $7,100 assembled
 Shadow Dexterous HandShadow Robot Company (UK)~$119,000 (quote)
 Inspire Robots RH56 (RH56DFX)Beijing Inspire-Robots Technology$5,783
Sources
Parts list ↗ · Purchase options ↗ · GitHub (LEAP_Hand_API) ↗ · GitHub (Isaac Lab sim-to-real) ↗ · Paper (arXiv 2309.06440) ↗ · LEAP Hand v2 ↗ · LEAP Hand v2 Adv ↗