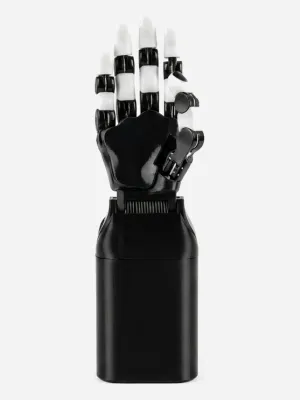
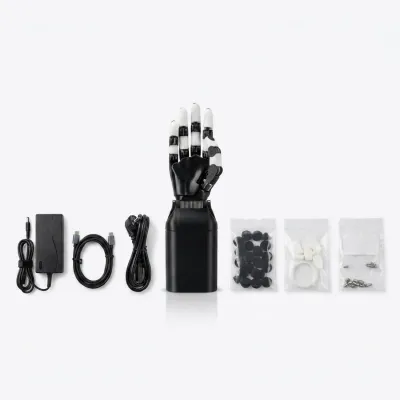
orca_core Python package calibrates and tensions the tendons and sends joint-space commands, on Linux, macOS or Windows serial ports.Overview
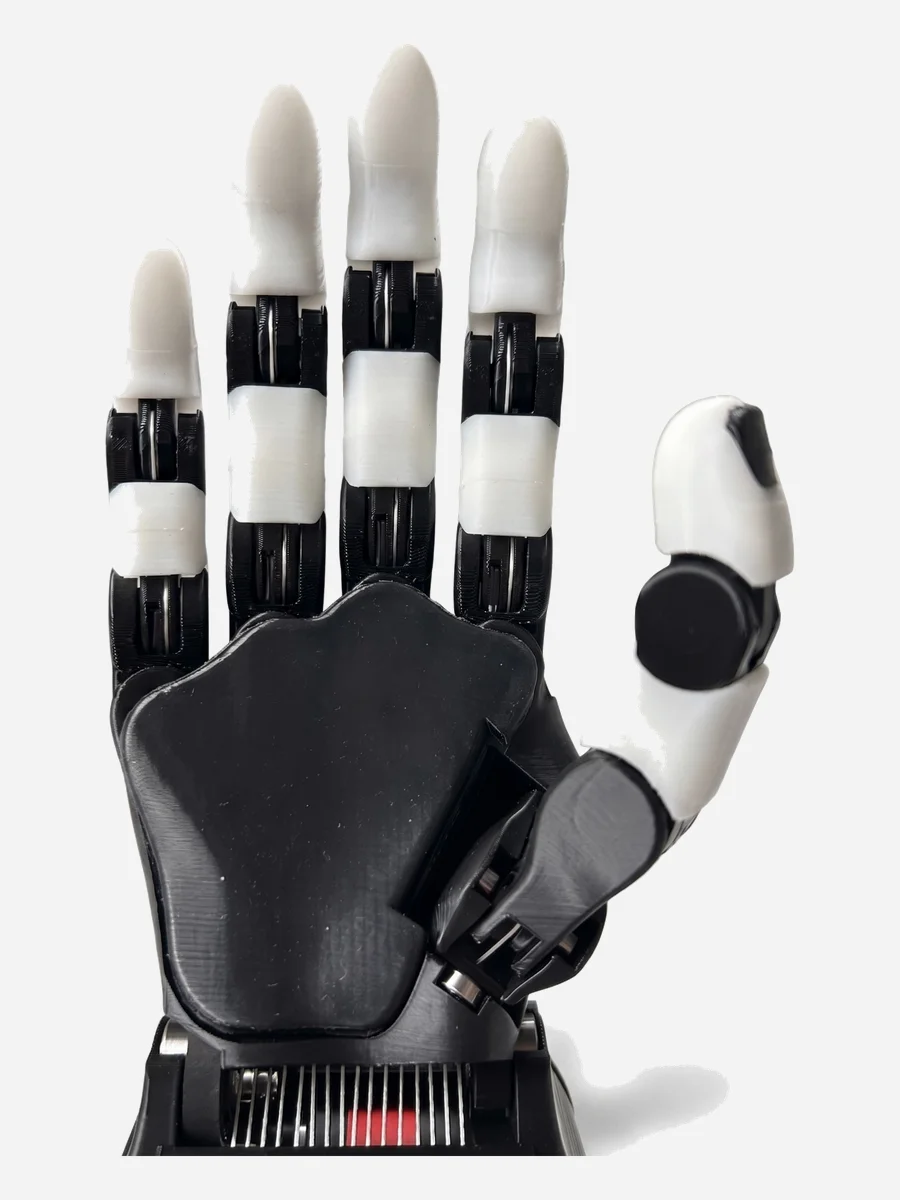
The ORCA Hand is an open-source, human-sized robot hand that began at ETH Zurich's Soft Robotics Lab. Its v1 design was published at IROS 2025 by Clemens Christoph, Maximilian Eberlein and colleagues. The founders now develop and sell it through ORCA Dexterity, which assembles hands in Zurich. Labs use it for teleoperation, imitation learning and sim-to-real reinforcement learning. It bolts onto standard arm flanges such as those of the Franka Research 3 and UR5e. The v1 paper reports a pick-and-place run of 7 hours and over 10,000 cycles without hardware failure.
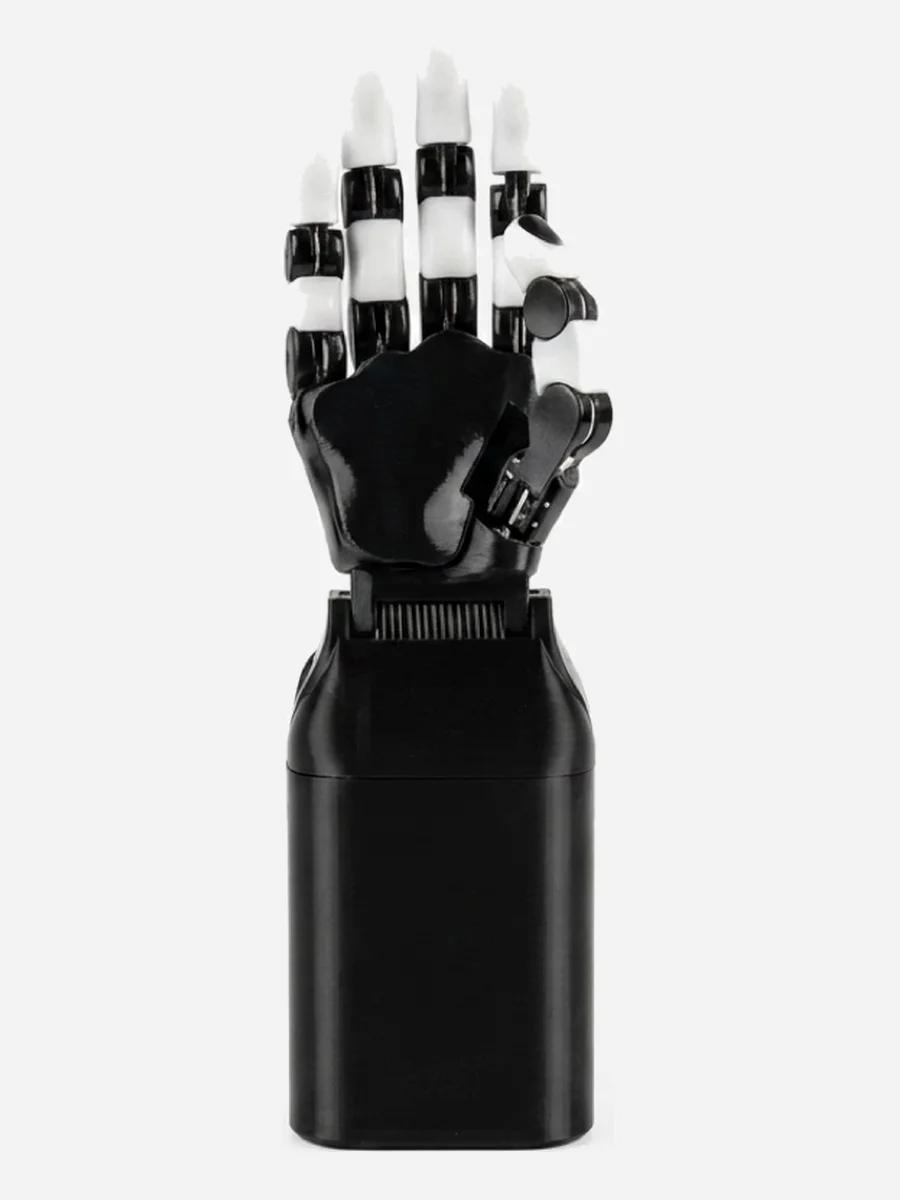
The hand is tendon-driven, meaning cables run from 17 servos in the forearm tower to pull the finger joints. Each finger has its own motors for knuckle curl, middle-joint curl and side-to-side spread, and the tip joint is left out. Joints are built to pop out under overload and snap back in. The current v2.1 adds metal spool holders so tendon tension cannot bend the servos. Buyers choose Dynamixel servos, which run cooler under continuous use, or cheaper Feetech servos. The v1 CAD is CC BY 4.0, while the touch version's sensor module stays closed-source.
- Type
- Robot hand or gripper · Open-source & low-cost hands
- Maker
- ORCA Dexterity (from ETH Zurich's Soft Robotics Lab), open source
- Released
- 2025
- Price
- $3,500 – $7,100 assembled
- Status
- Available
- Best for
- Ages 16+
- Programming
- Open source (hardware + software)
Price and shipping
ORCA Dexterity prices, checked October 2026. The assembled orcahand costs $3,500 with Feetech servos or $4,500 with Dynamixel servos. The orcahand touch, with tactile fingertips, costs $6,100 or $7,100. An add-on with joint encoders is $1,500 on pre-order, and the Max Kit add-on is $350. Labs and universities can ask for academic and quantity discounts. ROBOTIS America lists the Orcahand at $5,855 but sends buyers to the ORCA site. The v1 paper put the self-build material cost under CHF 2,000.
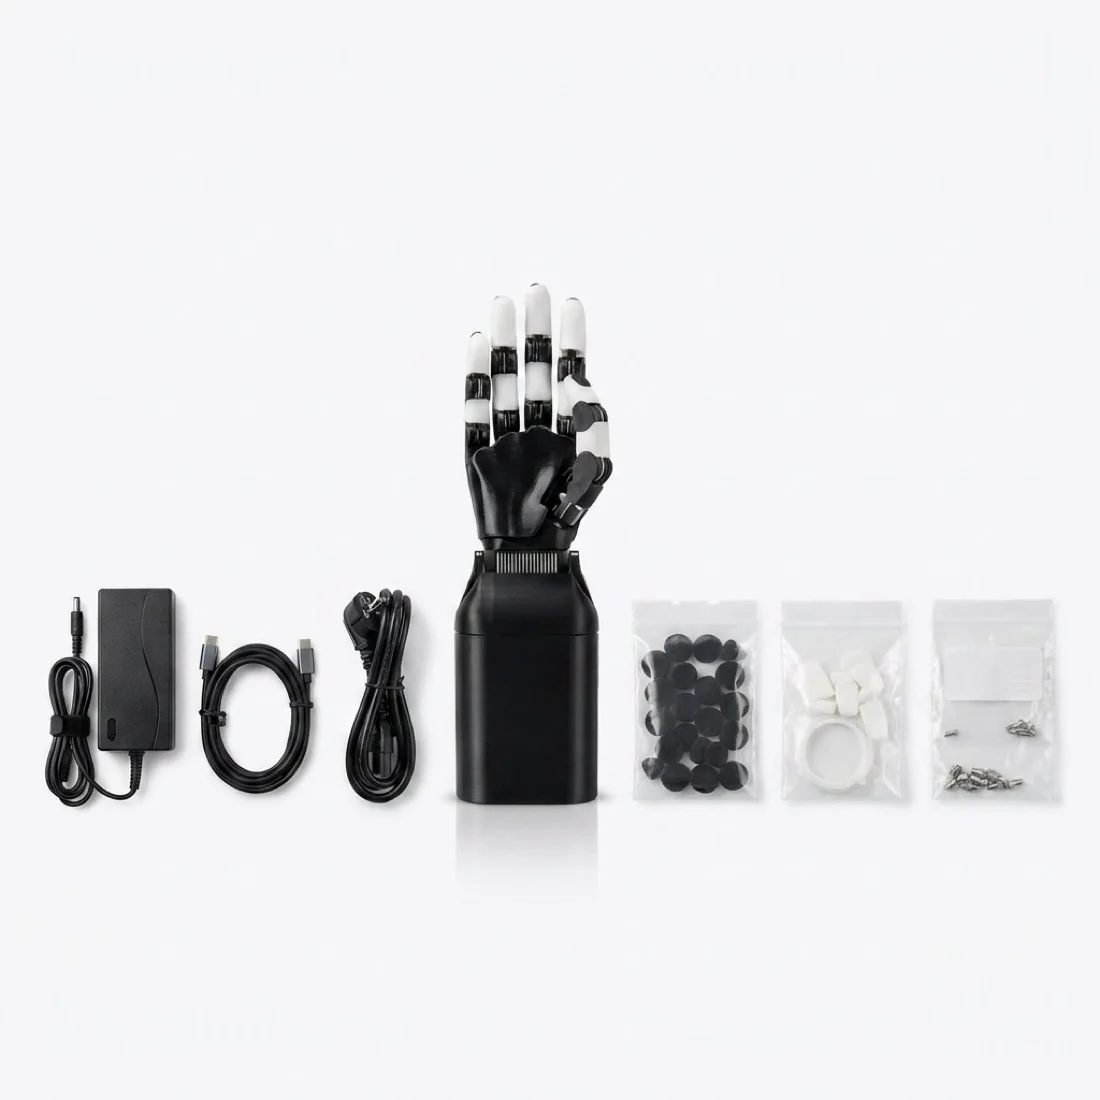
Shipping: ~6 weeks production for assembled hands. ORCA Dexterity quotes about 6 weeks of production lead time for assembled hands and 3 weeks for BOM kits (October 2026). Hands ship from Zurich, Switzerland or Hong Kong by DHL. Import taxes and duties are paid by the buyer. Every assembled hand comes with a CNC-machined Franka connector and mounting screws. ORCA Dexterity ↗
Specifications
| Category | Robot hands & grippers · Open-source & low-cost hands |
|---|---|
| Released | 2025 |
| Country | Switzerland |
| Availability | Available |
| DIY build plans | ORCA Hand · parts $2,000 (estimate) · difficulty 4/5 |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No official LLM tools. The orca_core Python library takes joint-space commands from a host PC, so an LLM running there could drive the hand through code. |
| MuJoCo simulation | Official model · The maker publishes MJCF and URDF models of the v1 and v2 hands (orcahand_description) and an orca_sim Gymnasium package built on MuJoCo. orcahand_description ↗ |
| NVIDIA Isaac simulation | Maker URDF only · The v1 paper trained a zero-shot sim-to-real ball-rotation policy in Isaac Gym, but no packaged Isaac Lab or Isaac Sim asset was found. The maker's URDF can be imported. ORCA paper (arXiv 2504.04259) ↗ |
| Gazebo simulation | Maker URDF only · URDF files are in orcahand_description, with no Gazebo package. orcahand_description ↗ |
| Best for | Ages 16+ (estimated) |
| Vision sensors | No vision sensors |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Python from a laptop |
| Fingers | 5 (4 fingers + thumb) |
| DOF | 17 actuated (16 finger joints + 1 wrist) |
| Actuation | 17 serial-bus servos in the forearm tower (Dynamixel XC330-T288 for fingers and XC430-T240BB for the wrist, or Feetech HL-2915 and HL-3930). Tendons drive the finger joints and a belt drives the wrist |
| Grip force / payload | Finger servos 0.92 N·m stall, wrist servo 1.9 N·m. The v1 paper reports holding up to 10.5 kg (103 N) with four fingers and 2 kg (19.6 N) with the index finger alone |
| Weight | 1.1 kg (v2.1), ~1.25 kg (touch) |
| Sensors | Servo encoders give each joint angle to about ±5°. The touch version adds 351 Hall-effect taxels with 6D force/torque output. A joint-encoder add-on (<1°) is on pre-order |
| Interface | USB-C to a host PC through the hand's driver board, plus one power cable. Mounts on ISO 9409-1-50-4-M6 arm flanges, with a Franka adapter included |
| SDK | orca_core Python controller (MIT), orca_ui web setup tool, retargeting and hand-to-hand teleop repos, orca_sim MuJoCo environments. No official ROS 2 driver |
Common questions
How much does ORCA Hand cost?
ORCA Hand is listed at $3,500 – $7,100 assembled. ORCA Dexterity prices, checked October 2026. The assembled orcahand costs $3,500 with Feetech servos or $4,500 with Dynamixel servos. The orcahand touch, with tactile fingertips, costs $6,100 or $7,100. An add-on with joint encoders is $1,500 on pre-order, and the Max Kit add-on is $350. Labs and universities can ask for academic and quantity discounts. ROBOTIS America lists the Orcahand at $5,855 but sends buyers to the ORCA site. The v1 paper put the self-build material cost under CHF 2,000.
Can ORCA Hand be bought today?
Yes, it is on sale. Typical shipping time is ~6 weeks production for assembled hands. ORCA Dexterity quotes about 6 weeks of production lead time for assembled hands and 3 weeks for BOM kits (October 2026). Hands ship from Zurich, Switzerland or Hong Kong by DHL. Import taxes and duties are paid by the buyer. Every assembled hand comes with a CNC-machined Franka connector and mounting screws.
Who makes ORCA Hand?
ORCA Hand is made by ORCA Dexterity (from ETH Zurich's Soft Robotics Lab), open source. It came out in 2025.
Can ORCA Hand be programmed?
Open source (hardware + software). orca_core Python controller (MIT), orca_ui web setup tool, retargeting and hand-to-hand teleop repos, orca_sim MuJoCo environments. No official ROS 2 driver.
Does ORCA Hand have AI chat or LLM support?
Possible via SDK. No official LLM tools. The orca_core Python library takes joint-space commands from a host PC, so an LLM running there could drive the hand through code.
What age is ORCA Hand for?
Ages 16+ (estimated).
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 LEAP HandCarnegie Mellon University (Deepak Pathak's lab), open sourceUnder $2,000 DIY parts, Lite ~$715
 Allegro Hand (V4 / V5 / V6)Wonik Robotics (South Korea)$9,910 (V4)
 AmazingHandPollen Robotics (Hugging Face), open source~$140 DIY parts, kits $99 – $179
 Shadow Dexterous HandShadow Robot Company (UK)~$119,000 (quote)
 Inspire Robots RH56 (RH56DFX)Beijing Inspire-Robots Technology$5,783
 PSYONIC Ability HandPSYONICQuote only
Sources
ROBOTIS America listing ↗ · GitHub (orca_core) ↗ · GitHub (orcahand_hardware) ↗ · GitHub (orcahand_description) ↗ · Paper (arXiv 2504.04259) ↗