Several parts changed after the full build video was recorded, so a separate written addendum must be followed alongside it.
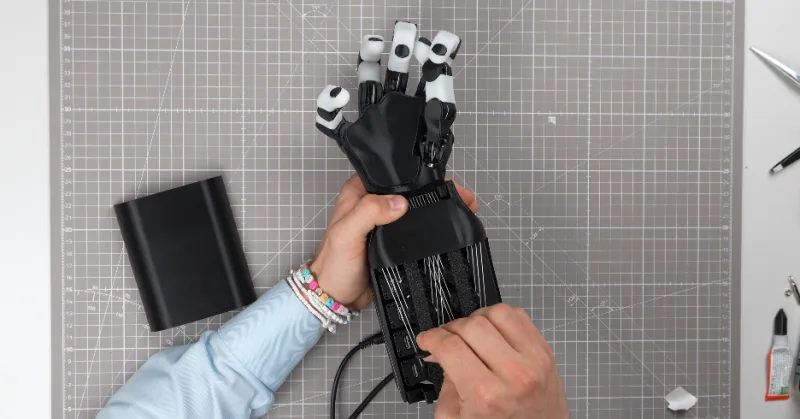
A 17-DoF tendon-driven humanoid hand that began at ETH Zurich and is now developed by the spin-off ORCA Dexterity. Servos sit in a forearm tower and pull tendons through 3D-printed fingers with poppable joints and a cast silicone skin. Builds can use Dynamixel or cheaper Feetech servos, and the Python library orca_core handles calibration, tendon tensioning and joint control.
At a glance
| Parts cost | $2,000 project · Stated by the project source ↗ |
|---|---|
| Difficulty | 4/5 Advanced · Seventeen tendons must be routed and tensioned through PTFE-lined channels, and the skin is cast in silicone, which takes patience and care. |
| Build time | Under 8 hours of assembly (project-stated) source ↗ |
| Tools needed | 3D printer (one multi-plate 3MF print file), silicone casting with printed molds (or soft TPU skin instead), small hand tools |
| Motors | 16 Dynamixel XC330-T288 finger servos + 1 XC430-T240BB wrist servo, or Feetech HL-2915/HL-3930 equivalents |
| Controller | PC over USB via U2D2 (Dynamixel) or Feetech FE-URT-2 board, 12 V 5 A supply |
| Sensors | Servo encoders; optional joint-position sensing and a proprietary tactile module on the commercial Touch version |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✓ Video Full assembly video + written addendum in the GitHub repo, parts list Google Sheet, orcahand.com wiki |
| Activity | Last update 2026-09-18 · 205 GitHub stars · Discord; orca_core has 597 stars and 155 forks |
| Kits | Assembled hands and kits sold by ORCA Dexterity (the Touch variant is listed at $6,100 with Feetech servos) |
Licenses
| Design files | CC BY 4.0 (all files in the hardware repo, CAD/STL/3MF and code) source ↗ |
|---|---|
| Code | MIT (orca_core) source ↗ |
| Documentation | CC BY 4.0 for repo docs; the orcahand.com wiki shows no license source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- The assembly video predates several part changes, so a written addendum covers the new PTFE tube positions, the redesigned thumb with a single slit, a missing carpal pin and bearing step, and the newer spools. Reading it before starting avoids rebuilding steps. source ↗
- Silicone casting is described as fiddly, and the team suggests printing the skin in soft TPU or making custom molds instead. Two near-duplicate mold sets exist in the repo, and the 07_Molds set is the one a builder confirmed working. source ↗
- Random motor dropouts on Dynamixel builds were traced to the small connector PCBs between motors. The team switched to short cables to daisy-chain the servos. source ↗
- On a Feetech build, distant servos stopped answering pings because the chain was effectively powered over USB. A proper 12 V supply on the power line fixed it. source ↗
- The Lite variant files are published, but the company discontinued it and does not provide a parts list, assembly guide or support for it. source ↗
Other hands plans
- LEAP Hand · $1,800 (2023) · difficulty 2/5
- AmazingHand · $140 · difficulty 2/5
- UMI gripper (Universal Manipulation Interface) · $370 (2024) · difficulty 2/5
- RUKA hand · $1,300 · difficulty 3/5
- Aero Hand Open · $320 · difficulty 3/5
- YUBI glove and gripper (Toyota) · $550–$750 · difficulty 4/5
- Yale OpenHand (Model T42 / Model O) · $1,400 · difficulty 3/5
- DexHand (The Robot Studio) · $300 (2023) · difficulty 4/5