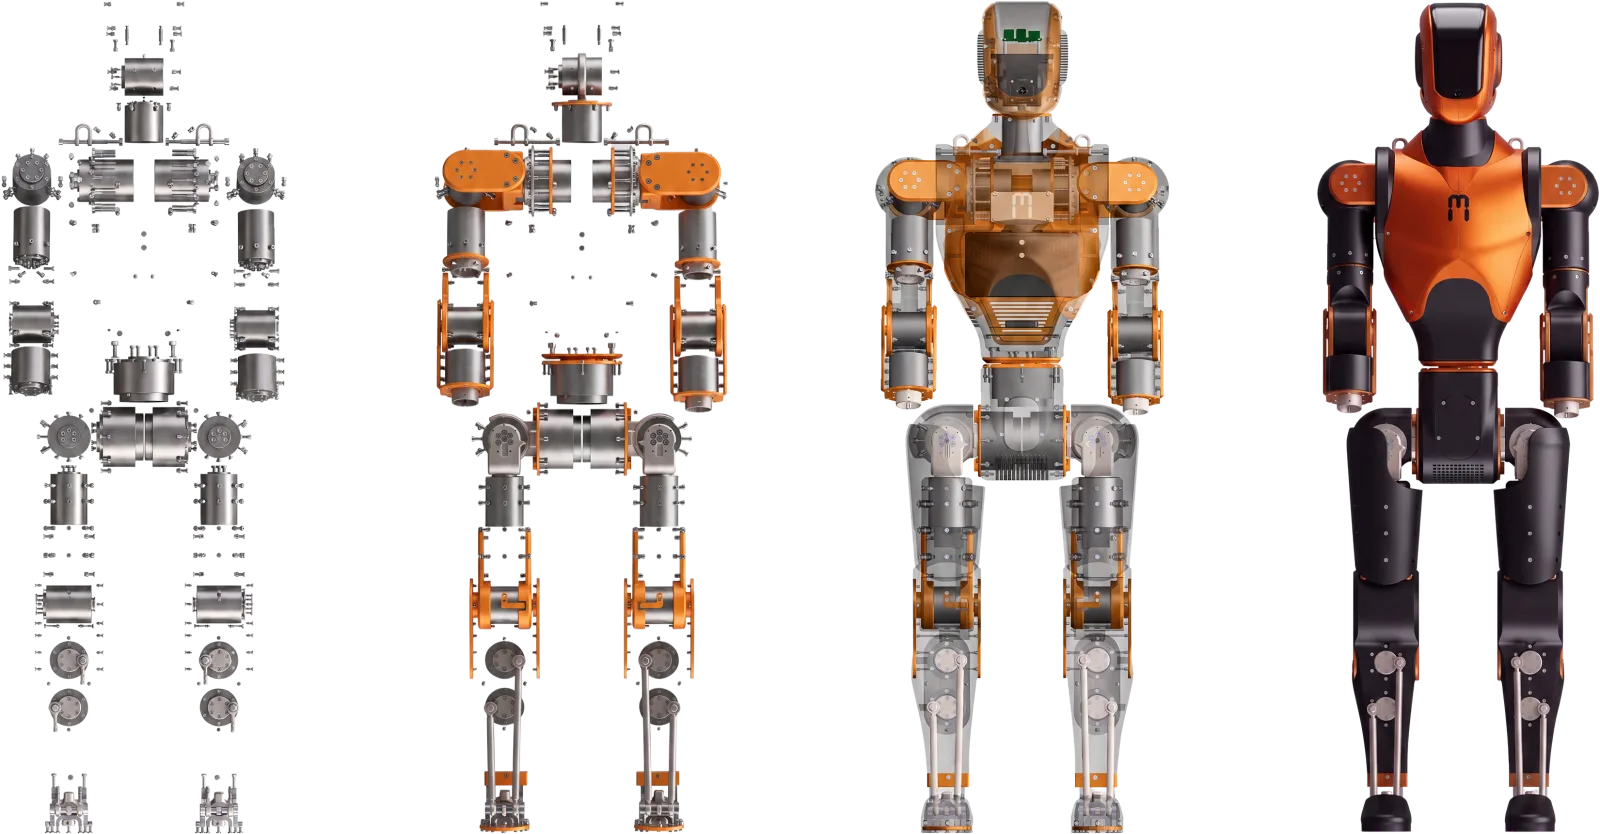
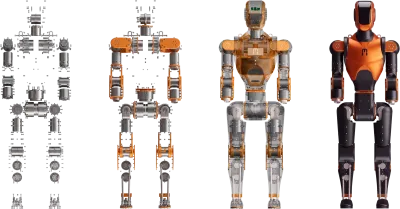
$20,000 kitDIY kit, $20,000 delivered with duties and tariffs covered in most countries (Menlo, October 2026), ordered with a $499 deposit. The March 2026 "Here Be Dragons" pre-order targeted $15,000. Hands, tools and 4G/5G modules are not included. The full BOM is public for self-sourcing
AvailableRL walkingOpen hardware~100 h assemblyIsaac Lab RL kitNo hands
Weeks+Shipping: Monthly batches. The first production batch shipped in late August 2026, with further batches planned monthly. Menlo ships worldwide with duties and tariffs covered in most countries, and lists assembly and servicing partners in the USA and Singapore. Where the kit is made is not published, so how the July 2026 FCC Covered List rule applies to US orders is unclear. Order ↗
Overview
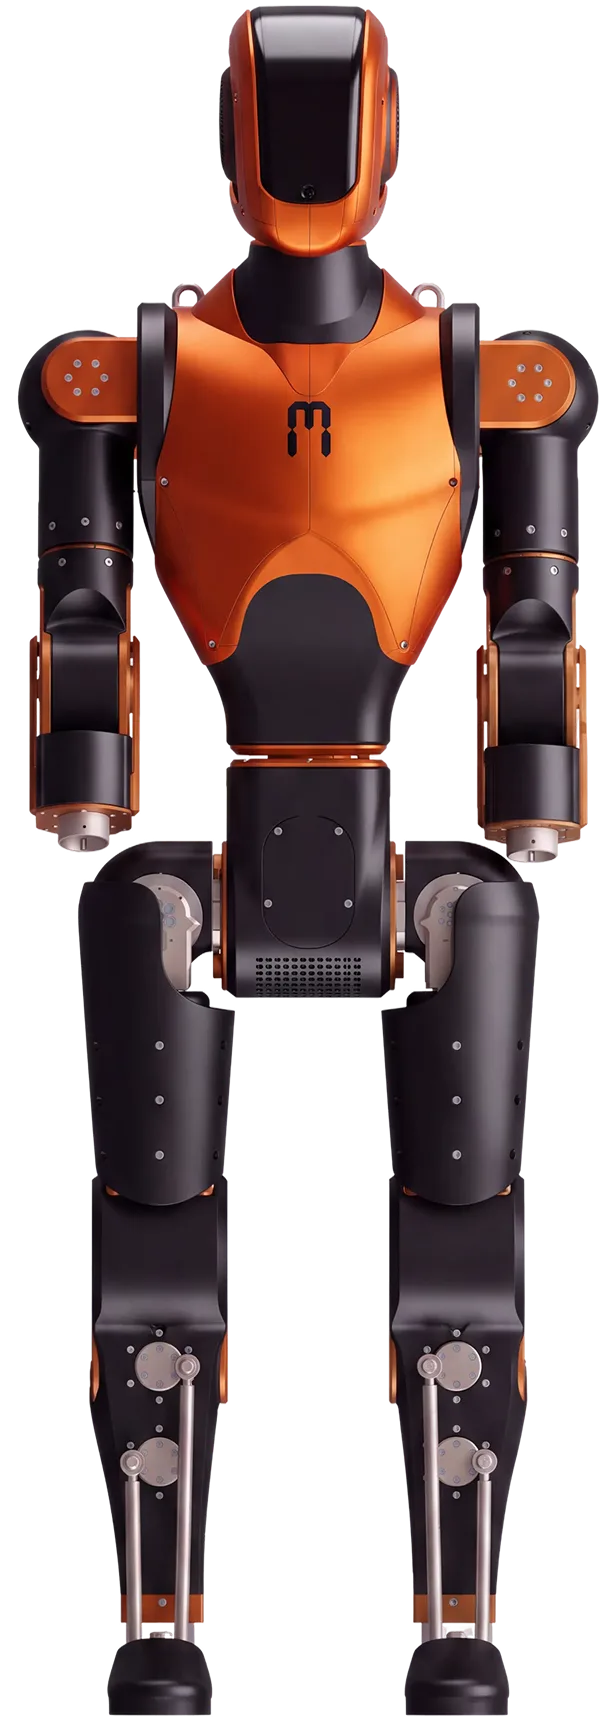
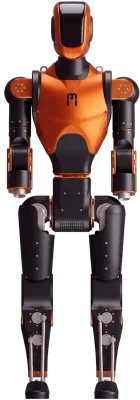
An open-source 1.2 m humanoid sold as an unassembled kit, with the CAD, schematics, simulation model and onboard code all public. It is aimed at labs and serious builders who want a robot they can repair and modify themselves, with a Python SDK and an Isaac Lab training repo for locomotion. The catch is roughly 100 hours of assembly for a $20,000 kit, no hands included, and several software pieces still listed as coming soon.
The most open full-body humanoid on sale, but a long, expensive build rather than a ready-made robot.
Specifications
| Category | Bipeds · Open-source RL bipeds |
|---|---|
| Released | 2026 |
| Country | Singapore, Vietnam, USA |
| Availability | Available |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. The menlo-sdk Python SDK drives stand, balance, walk, joints, camera and audio, so an LLM on a computer could control it. Asimov SDK docs ↗ |
| MuJoCo simulation | Official model · Official MJCF in the asimov-1 repo. Menlo's earlier asimov-mjlab training repo covers the legs-only v0, not Asimov 1. asimov-1 ↗ |
| NVIDIA Isaac simulation | Sim-to-real kit · Menlo's Cyclotron is an Isaac Lab extension (PPO + AMP) for training Asimov 1 locomotion and deploying it to the real robot. Cyclotron ↗ |
| Gazebo simulation | Maker URDF only · Official URDF in the asimov-1 repo, no Gazebo package. asimov-1 ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | Speaker, Microphone |
| Compute type | Raspberry Pi, Other ARM chip |
| Balance type | RL walking |
| Height | 1.2 m |
| Weight | 35 kg |
| Compute | Raspberry Pi 5 (media, networking) + Radxa CM5 (motion control and locomotion) |
| Speed | 0.3 m/s in the SDK walk example (top speed not published) |
| DOF | 25 (6/leg, 5/arm, 1 waist, 2 neck), EC-A series actuators, 12–40 N·m rated, 36–120 N·m peak, parallel RSU ankles |
| Sensors | 2 MP monocular camera, 6-axis IMU, stereo mic array, 10 W speaker |
| Balance | Full-body RL locomotion policy in the firmware. Cyclotron trains new policies in Isaac Lab, and the docs say policies trained in Isaac Lab or MJLab deploy zero-shot. |
| SDK | Open source, with mechanical and electrical CAD, MJCF/URDF and onboard software (hardware CERN-OHL-S-2.0, software GPL-2.0). menlo-sdk (Python) for stand/walk/joints/camera/audio over the network or LiveKit. Client SDK, full-body teleop and firmware downloads listed as coming soon |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 MicroduckPollen Robotics / Hugging Face$399
 Open Duck Mini v2Antoine Pirrone & community~$400 DIY · $600 kit · $900–1,000 built
 BimoMekion$500
 Z-Bot (Zeroth Bot)K-Scale Labs (defunct) & communityNot for sale · DIY BOM from ~$350
 ToddlerBot 2.0Stanford (Haochen Shi et al.)~$6,000 DIY · $4,299 built
 Berkeley Humanoid LiteUC Berkeley Hybrid Robotics~$4,300 DIY BOM