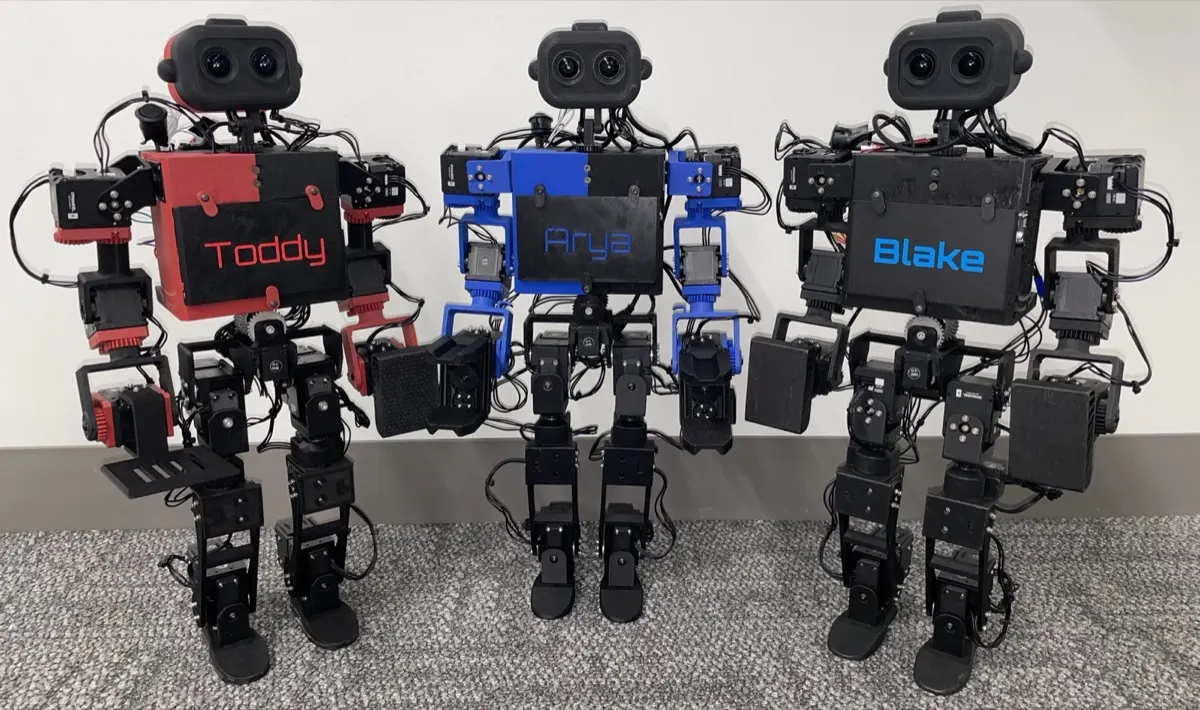
~$6,000 DIY · $4,299 builtWowRobo assembled price excludes Jetson, Wi-Fi and batteries (sold out). ROBOTIS Dynamixel bundle $4,336 (sold out)
Out of stockRL walking30 DOFJetson Orin NXMuJoCo MJXLoco-manipulation
Weeks+Shipping: 4–8 wks (est.). The WowRobo assembled unit (30-day pre-order) and the ROBOTIS bundle were both sold out. DIY means Dynamixels from ROBOTIS US plus a Jetson, then 1–2 weeks of printing and assembly. WowRobo ↗
Overview
The most capable small research platform, and MuJoCo end to end, so MuJoCo sim experience transfers directly. The price is the problem ($4.3–6k, mostly Dynamixels), and both ready-made options were sold out. Get it for manipulation and whole-body skills, not just balance.
Specifications
| Category | Bipeds · Open-source RL bipeds |
|---|---|
| Released | 2025 |
| Availability | Out of stock |
| Programmability | Open source (hardware + software) |
| Best for | Professionals & labs |
| Vision sensors | Camera, Depth camera |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | Speaker, Microphone |
| Compute type | NVIDIA Jetson |
| Balance type | RL walking |
| Height | 56 cm |
| Weight | 3.4–3.7 kg |
| Compute | NVIDIA Jetson Orin NX 16 GB |
| Speed | 0.25 m/s walk, 1 rad/s turn |
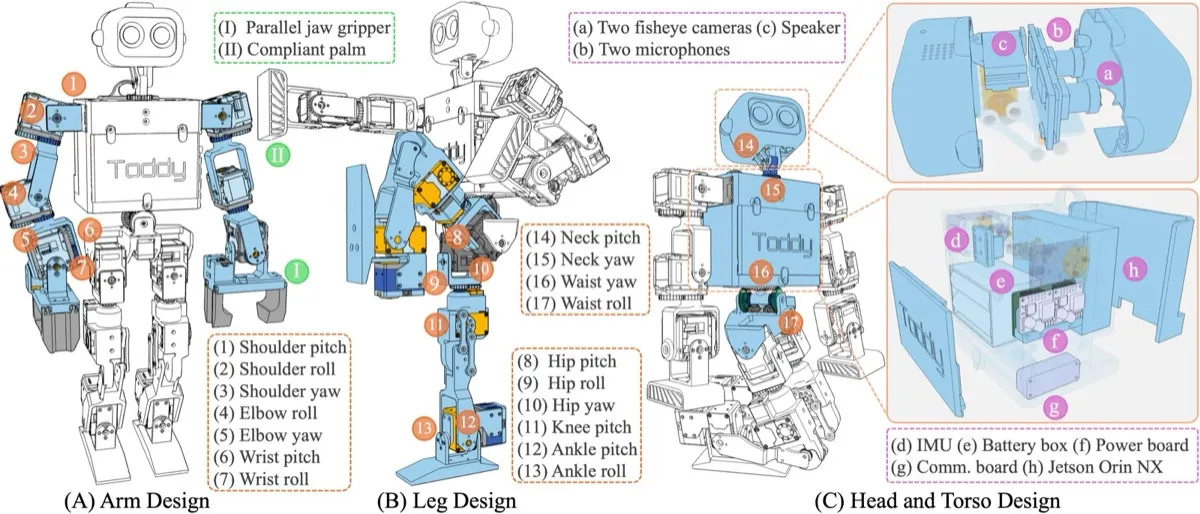
| DOF | 30 Dynamixel (7/arm, 6/leg, 2 neck, 2 waist) |
| Sensors | 2 fisheye cameras (stereo), BNO085 IMU, 2 mics, speaker |
| Balance | RL walking/turning policies trained in MuJoCo MJX, zero-shot transfer. Very robust per the project, survives ~7 falls before a part breaks. |
| SDK | toddlerbot Python package: MJX training, keyframe GUI, VR teleop, diffusion-policy manipulation |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 MicroduckPollen Robotics / Hugging Face$399
 Open Duck Mini v2Antoine Pirrone & community~$400 DIY · $600 kit · $900–1,000 built
 BimoMekion$500
 Z-Bot (Zeroth Bot)K-Scale Labs (defunct) & communityNot sold · DIY BOM from ~$350
 Berkeley Humanoid LiteUC Berkeley Hybrid Robotics~$4,300 DIY BOM
 Lingxi X1AgiBot (Zhiyuan Robotics, China)Quote