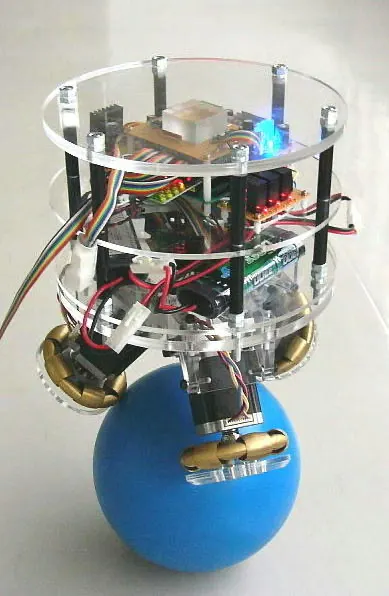
Not sold
Not for sale (research)Not programmableBallbotOmni-wheel driveCooperative transportResearch
Not soldShipping: N/A. A university research robot; never sold.
Remote control: Not possible. A university research robot with no public interface.
Overview
The second major ballbot design, and the one that set the template most later ballbots copy, using three omni-wheels on a ball instead of CMU's rollers-plus-yaw-motor. Kumagai's group used several BallIPs to demonstrate carrying loads and cooperative transport. Its omni-wheel design with a continuous contact line was reused by ETH's Rezero.
Specifications
| Category | Spherical & rolling · Research & concepts |
|---|---|
| Released | 2008 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Unknown |
| Remote control | Not programmable |
| Size | Not published (rides on a rubber-coated bowling ball) |
| Locomotion | Three custom omni-wheels driving the ball directly, which also controls yaw |
| Compute | Not published |
| Camera | None |
| Sensors | IMU, wheel encoders |
| Runtime | Not published |
| Speed | Not published |
| SDK | Lab-internal |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 CMU BallbotMicrodynamic Systems Lab, Carnegie Mellon University (USA)Not sold
 RezeroETH Zurich Autonomous Systems Lab focus project, with ZHAW and ZHdK (Switzerland)Not sold
 KugleAalborg University (Denmark)Not sold
 GuardBotGuardBot Inc. (USA / Sweden)Quote only
 Sphero (original) / Sphero 2.0Sphero, formerly Orbotix (USA)Was $129.99 (Sphero 2.0)
 Sphero OllieSphero (USA)Was $99 (2014)
Image credits
- Image 1: source (GFDL / CC BY-SA, Unagaraj)