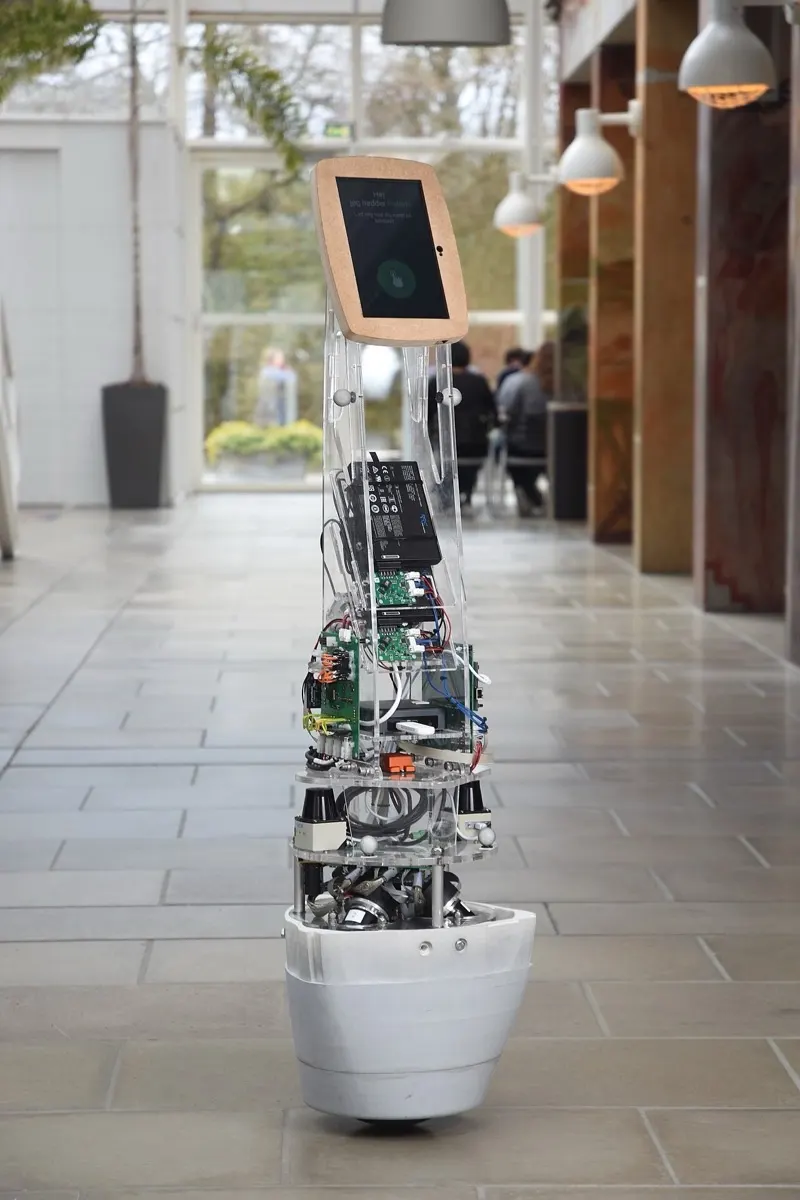
Overview
A ballbot built as a human guide robot for a 2019 Aalborg University master's thesis, notable for a quaternion-based model, sliding-mode balance control and an MPC path follower. It uses two lidars to localize and detect people. The whole stack (models, firmware, ROS and Gazebo) is open source, which makes it the best public reference for anyone building a ballbot.
- Type
- Rolling robot · Research & concepts
- Maker
- Aalborg University (Denmark)
- Released
- 2019
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Master's thesis robot. All code is MIT-licensed on GitHub.
Shipping: N/A. Not for sale. The design files and code on GitHub are public, but no kit exists.
Specifications
| Category | Spherical & rolling · Research & concepts |
|---|---|
| Released | 2019 |
| Country | Denmark |
| Availability | Not for sale (research) |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | Sim-to-real kit · Maker's Kugle-Gazebo uses the same ROS topics and messages as the real robot's driver. Kugle-Gazebo ↗ |
| Best for | Professionals & labs |
| Vision sensors | Lidar |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Unknown, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | 16 kg prototype (Kugle V1), roughly between waist and chest height with a tablet head (est.) |
| Locomotion | Three omni-wheels driving the ball |
| Compute | STM32H7 real-time board (FreeRTOS) plus an onboard ROS computer |
| Camera | Tablet display, no camera published |
| Sensors | IMU, encoders, two SICK TiM571 2D lidars |
| Runtime | Not published |
| Speed | Tested to 1 m/s and 1 rad/s |
| SDK | Open-source MATLAB/Simulink models, embedded firmware, ROS driver and Gazebo simulation (MIT) |
Common questions
How much does Kugle cost?
Not for sale. Master's thesis robot. All code is MIT-licensed on GitHub.
Can Kugle be bought today?
No. It was never sold to the public.
Who makes Kugle?
Kugle is made by Aalborg University (Denmark). It came out in 2019.
Can Kugle be programmed?
Open source (hardware + software). Open-source MATLAB/Simulink models, embedded firmware, ROS driver and Gazebo simulation (MIT).
Does Kugle have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 CMU BallbotMicrodynamic Systems Lab, Carnegie Mellon University (USA)Not for sale
 BallIPMasaaki Kumagai lab, Tohoku Gakuin University (Japan)Not for sale
 RezeroETH Zurich Autonomous Systems Lab focus project, with ZHAW and ZHdK (Switzerland)Not for sale
 GuardBotGuardBot Inc. (USA / Sweden)Quote only
 Rotundus GroundBotRotundus AB (Sweden)Quote only
 Sphero (original) / Sphero 2.0Sphero, formerly Orbotix (USA)Was $129.99 (Sphero 2.0)
Sources
Image credits
- Image 1: source (CC BY-SA 4.0, Mindthomas)