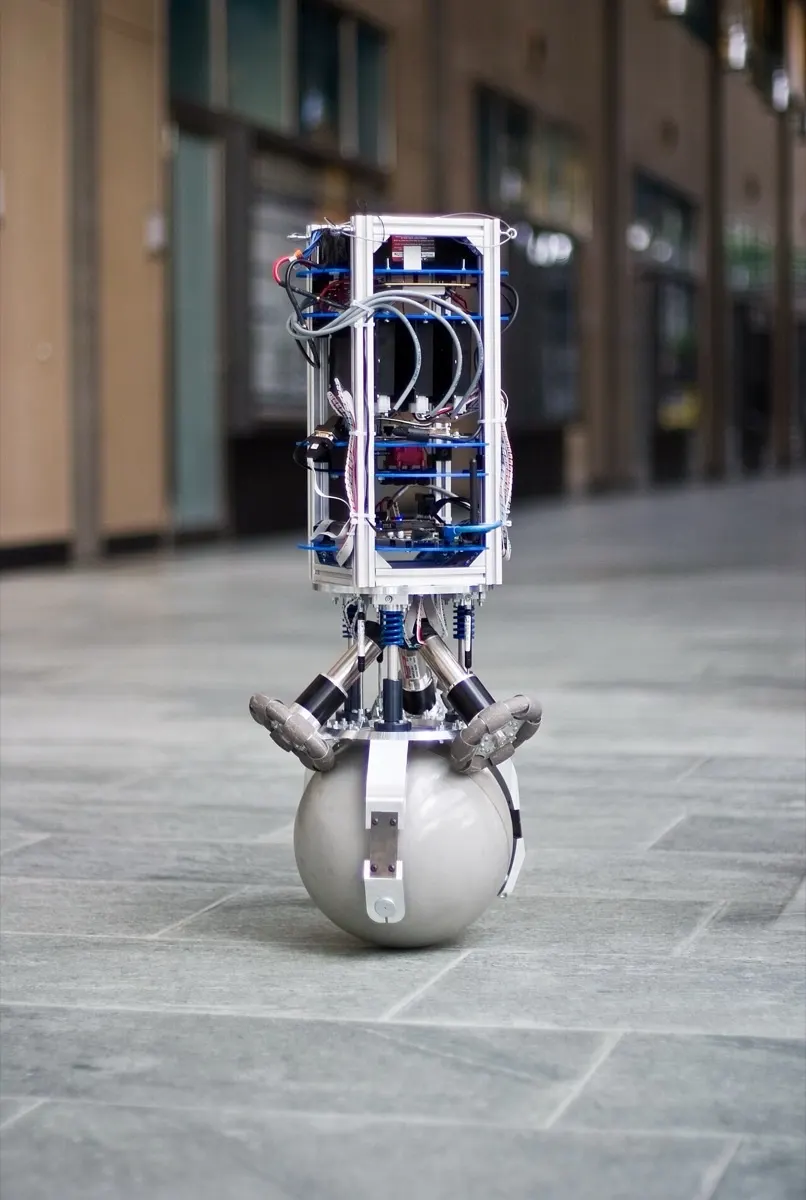
Not soldStudent focus project.
Not for sale (research)Not programmableFast ballbot3.5 m/sROSResearch
Not soldShipping: N/A. A one-off university project; never sold.
Remote control: Not possible. A one-off student research robot.
Overview
A 2010 ETH Zurich student ballbot built to show how fast and graceful a ballbot can be, rather than just that it can balance. It reached 3.5 m/s and had a 'breathing' shell that could lower over the ball to park.
Specifications
| Category | Spherical & rolling · Research & concepts |
|---|---|
| Released | 2010 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | Sonar / ultrasonic |
| Actuators | Brushless / direct-drive motors |
| Audio | Microphone |
| Compute type | Unknown |
| Remote control | Not programmable |
| Size | 19.5 kg with casing (14.5 kg without) |
| Locomotion | Three maxon EC-4pole 200 W motors driving custom omni-wheels on a rubber-coated aluminum sphere |
| Compute | Real-time low-level computer plus a Linux high-level computer running ROS |
| Camera | None published (laser and ultrasonic ranging) |
| Sensors | 160 Hz IMU with compass, laser distance sensors, ultrasonic sensors (~6.5 m, 360°), surround microphones, encoders |
| Runtime | ~5 h |
| Speed | Up to 3.5 m/s (12.6 km/h); 3 m/s² acceleration; 20° max lean |
| SDK | Team-internal (joystick, MATLAB trajectory planning, ROS) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
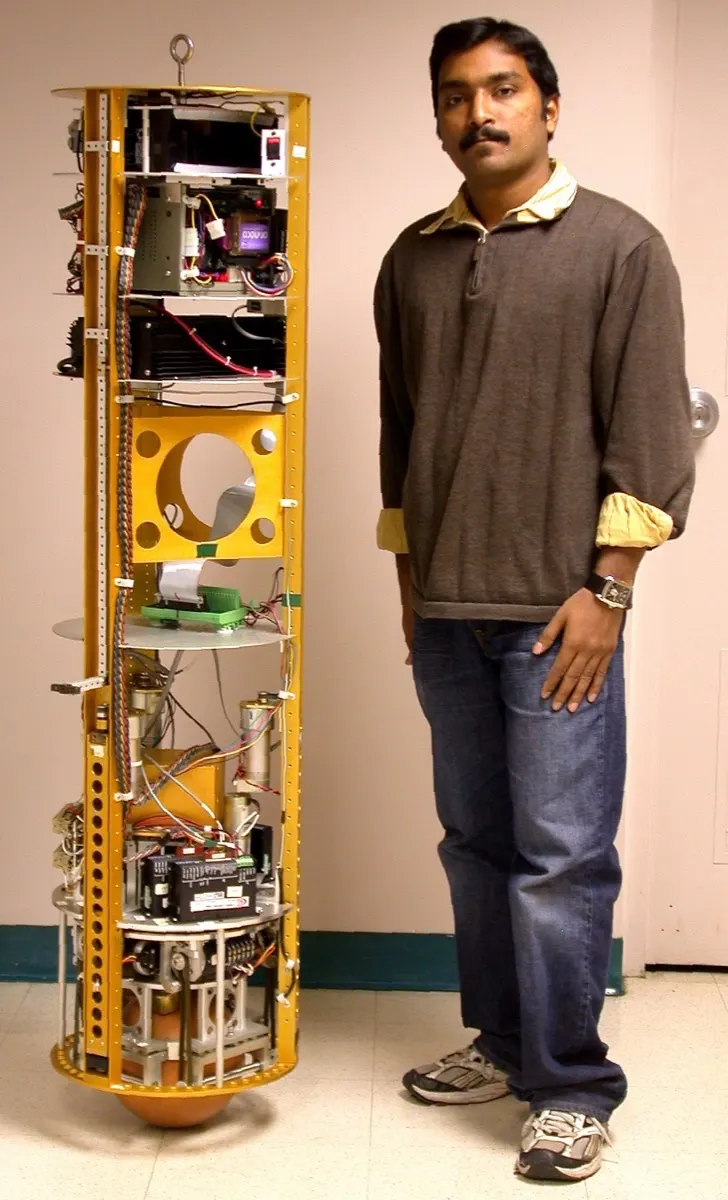 CMU BallbotMicrodynamic Systems Lab, Carnegie Mellon University (USA)Not sold
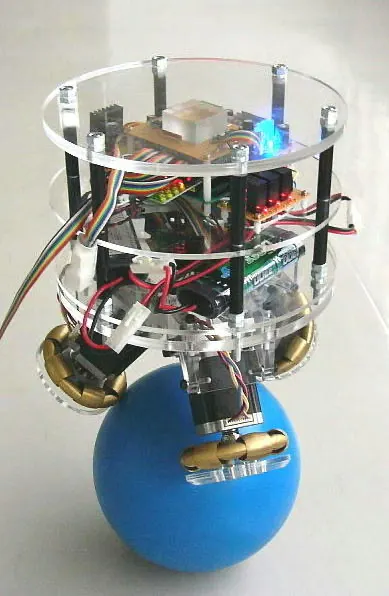 BallIPMasaaki Kumagai lab, Tohoku Gakuin University (Japan)Not sold
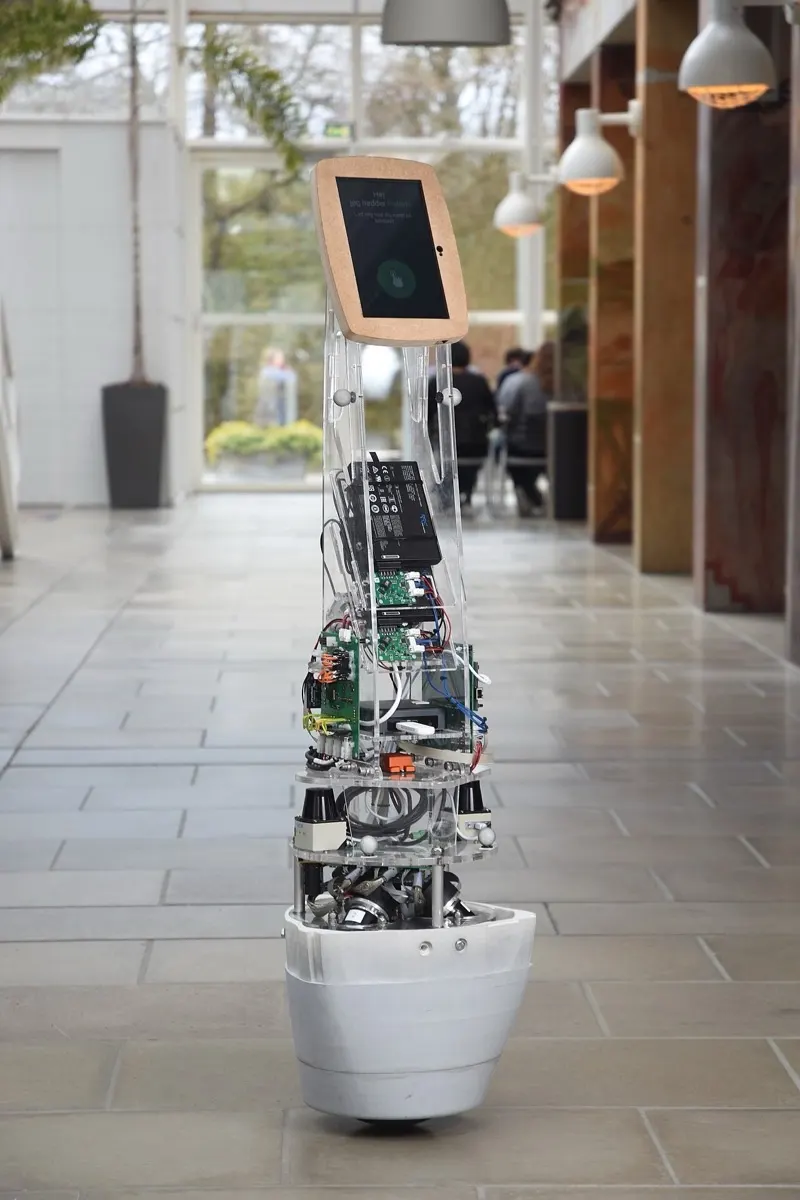 KugleAalborg University (Denmark)Not sold
 GuardBotGuardBot Inc. (USA / Sweden)Quote only
 Sphero (original) / Sphero 2.0Sphero, formerly Orbotix (USA)Was $129.99 (Sphero 2.0)
 Sphero OllieSphero (USA)Was $99 (2014)
Image credits
- Image 1: source (GFDL / CC BY-SA, Péter Fankhauser)