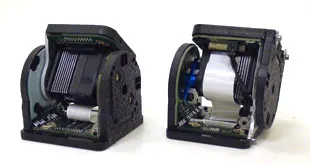
Not soldResearch modules. Project page dated 2009 (development began earlier).
Not for sale (research)Via SSH / web / bridgeChain modularDynamic gaitsCAN busUPenn
Not soldShipping: N/A. Lab research project. Not for sale.
Remote control: A laptop connects to a module cluster over Bluetooth or XBee radio modules plugged into the CAN bus (research setup).
Overview
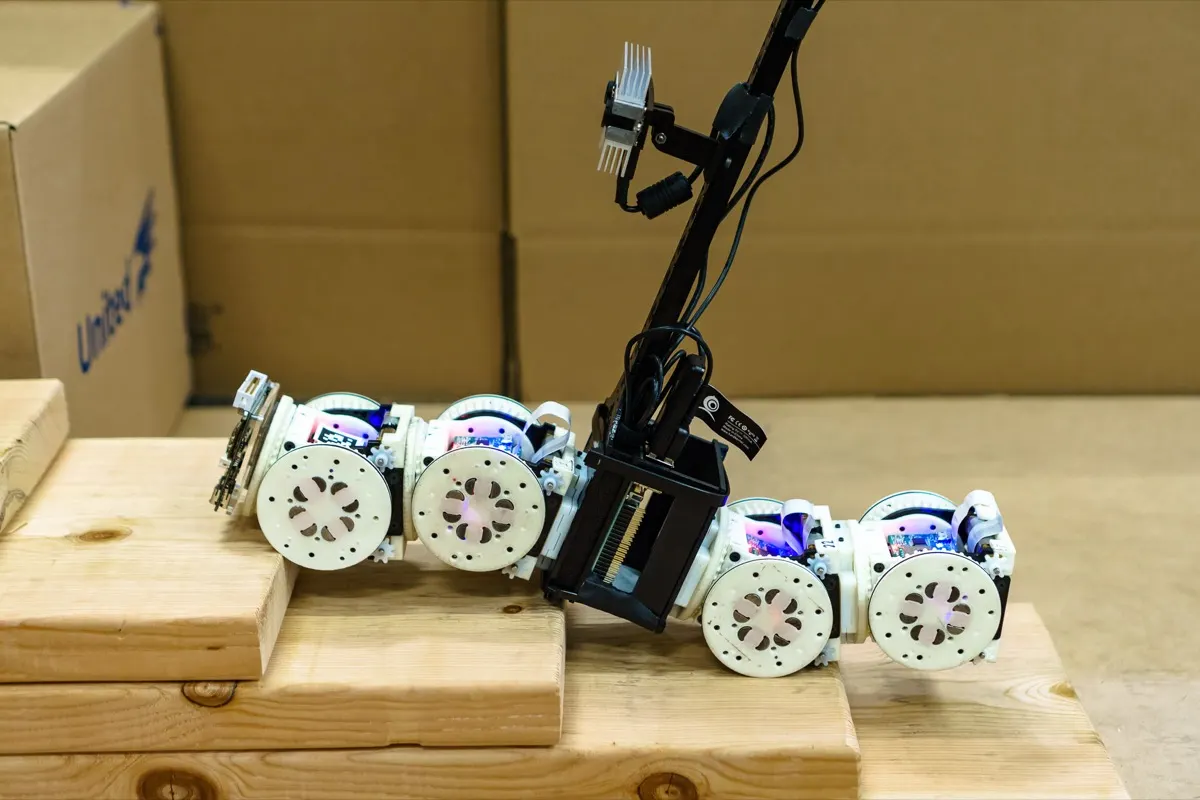
Connector Kinetic roBot, with fast, inexpensive single-DOF modules small enough to fit through a 3-inch pipe, built by Mark Yim's lab to study dynamic modular locomotion rather than slow, statically stable gaits. Modules connect with screws and share power and data over a CAN bus, with IR links between clusters.
Specifications
| Category | Modular & reconfigurable · Research & self-reconfiguring |
|---|---|
| Released | 2009 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | 60 mm cube, 138 g per module |
| Locomotion | Manually reconfigured chains: snakes, walkers, rolling loops, wheel attachments |
| Compute | PIC18F2680 per module, clusters share a CAN bus |
| Camera | Optional smart camera module |
| Sensors | IR proximity modules, 7 IR pairs per module for inter-cluster links |
| Runtime | 7.4 V LiPo (runtime not published) |
| Speed | Not published |
| SDK | Research software, Bluetooth/XBee link to a laptop |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
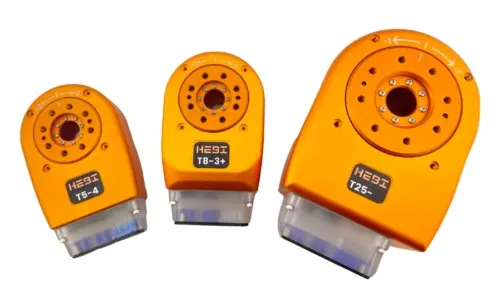 HEBI Robotics actuator modules (X/T/R-Series)
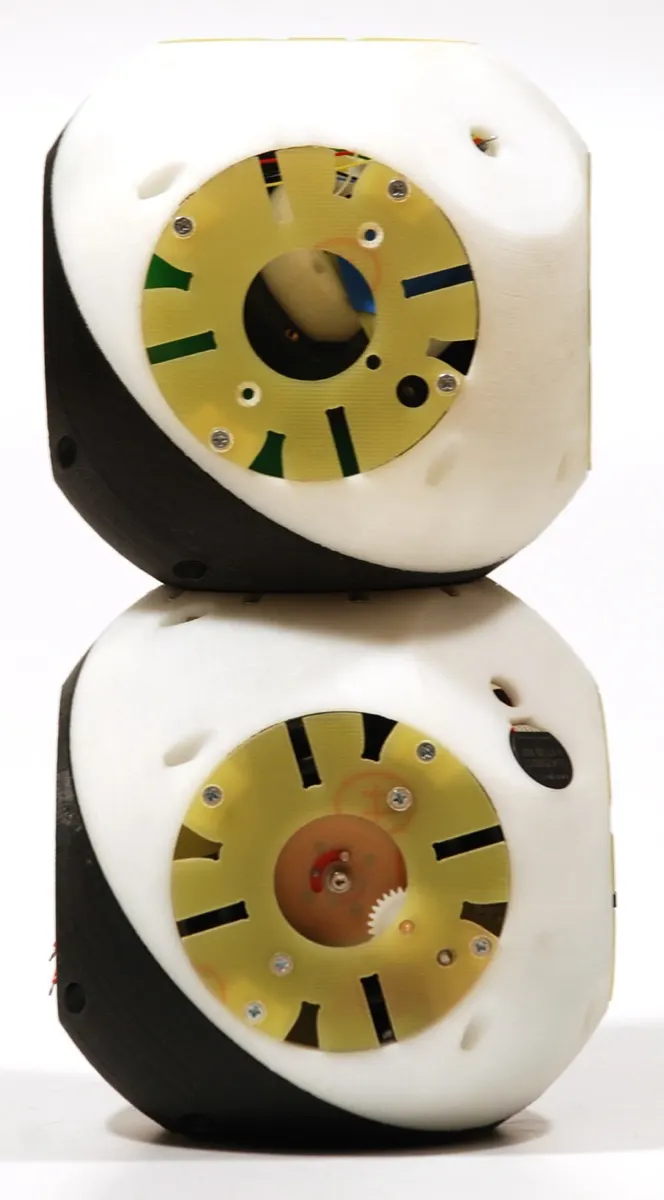 Roombots
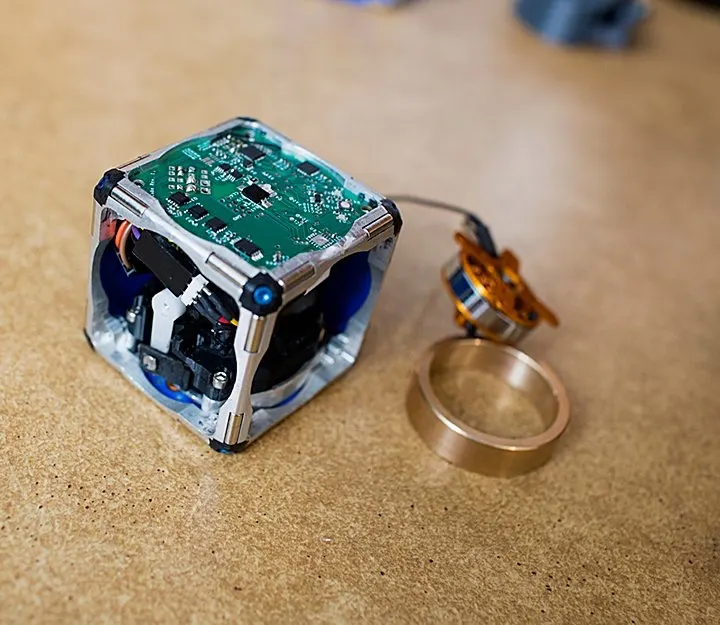 M-Blocks
 SMORES / SMORES-EP
 Molecubes
 Cubelets
Image credits
- Image 1: source (UPenn ModLab image)