$99 – $125$99 for the robot and $125 for the kit with an ESP-NOW remote controller (Hat Mini JoyC + StickC-Plus), both in stock on M5Stack's store (October 2026 check). Also sold on AliExpress and Taobao. Kickstarter early-bird pledges started at $59–$65 plus shipping. Dated 2026 for M5Stack's version, which launched on Kickstarter in January 2026 and reached its store in February 2026. The original DIY Stack-chan dates from 2021.
AvailableVia SSH / web / bridgePalm-sizedOpen sourceESP32-S3Screen facePan/tilt head
Possibly ≤ 1 weekShipping: About 1–2 weeks (unconfirmed). Sold from M5Stack's own store, which ships from China, and on AliExpress. No US warehouse or Amazon US listing was confirmed. M5Stack store ↗
Remote control: Code is written on a Mac or PC in Arduino IDE, PlatformIO, ESP-IDF or the browser-based UiFlow2 and flashed over USB-C, so programs run on the robot itself. The phone app also gives remote avatar control and video over Wi-Fi.
Overview
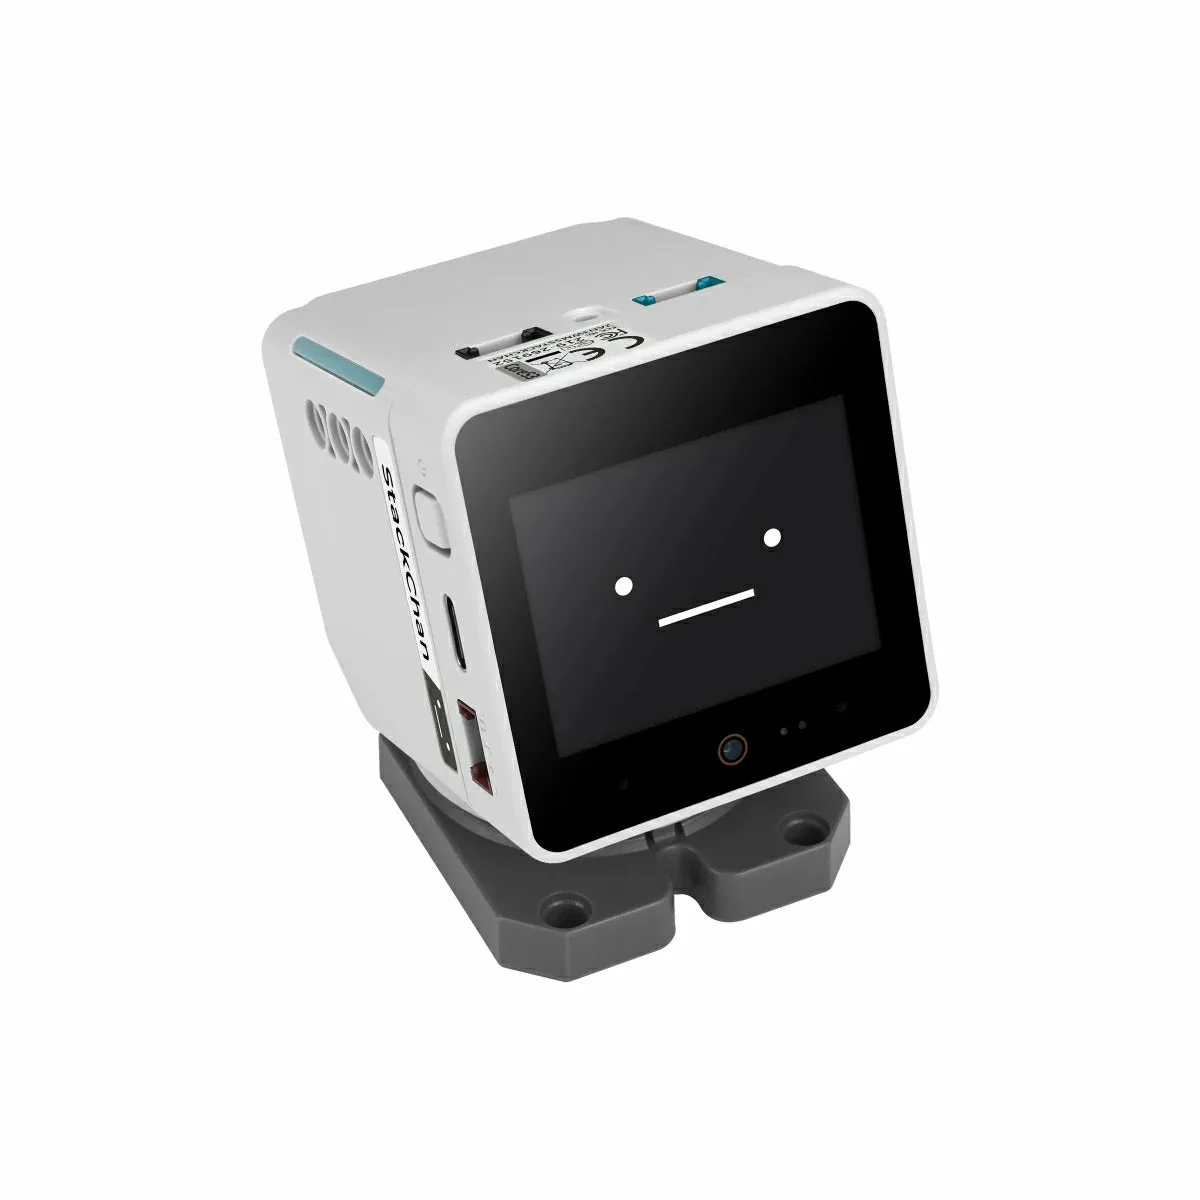
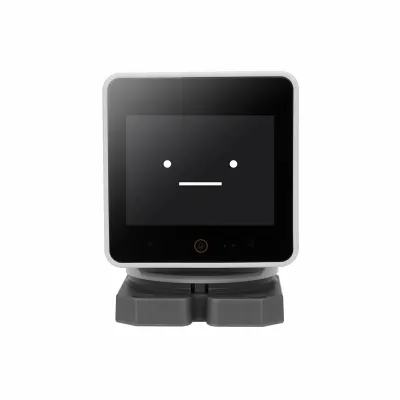
An official, ready-built version of Shinya Ishikawa's Stack-chan, a hobby robot that began in 2021 as an open-source project (GitHub stack-chan/stack-chan) where makers put an M5Stack screen module on a small servo pan/tilt body. M5Stack's version uses the CoreS3 module, whose 2-inch screen shows the face, and adds a camera, two microphones, touch zones, NFC and an AI voice agent out of the box. Unlike Vector it cannot drive around the desk, only turn and nod, but firmware, app, server and hardware files are all published, so it is far easier to reprogram. The default AI service is the Chinese XiaoZhi platform, which some owners will want to replace with a self-hosted server.
A cheap, cute and fully hackable desk head, best for makers who want to write their own robot personality.
Specifications
| Category | Companion robots · Desk & social robots |
|---|---|
| Released | 2026 |
| Country | China, Japan |
| Availability | Available |
| Sales | 4,142 Kickstarter backers pledged HK$3,582,197 (about $460,000) by February 2026 (estimate) Kickstarter ↗ |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | Built-in LLM chat · The factory firmware's AI Agent runs on the XiaoZhi voice platform, set up in M5Stack's StackChan World app (which lets the owner pick the AI model, voice and personality), and other XiaoZhi-based firmware can point at the open-source xiaozhi-esp32-server, which accepts any OpenAI-compatible LLM. M5Stack StackChan docs ↗ |
| MuJoCo simulation | None found · Nothing found. It is a stationary pan/tilt head, so simulation is of little use. |
| NVIDIA Isaac simulation | None found · Nothing found. It is a stationary pan/tilt head, so simulation is of little use. |
| Gazebo simulation | None found · Nothing found. It is a stationary pan/tilt head, so simulation is of little use. |
| Best for | Ages 10+ (estimated) |
| Vision sensors | Camera |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | Speaker, Microphone |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
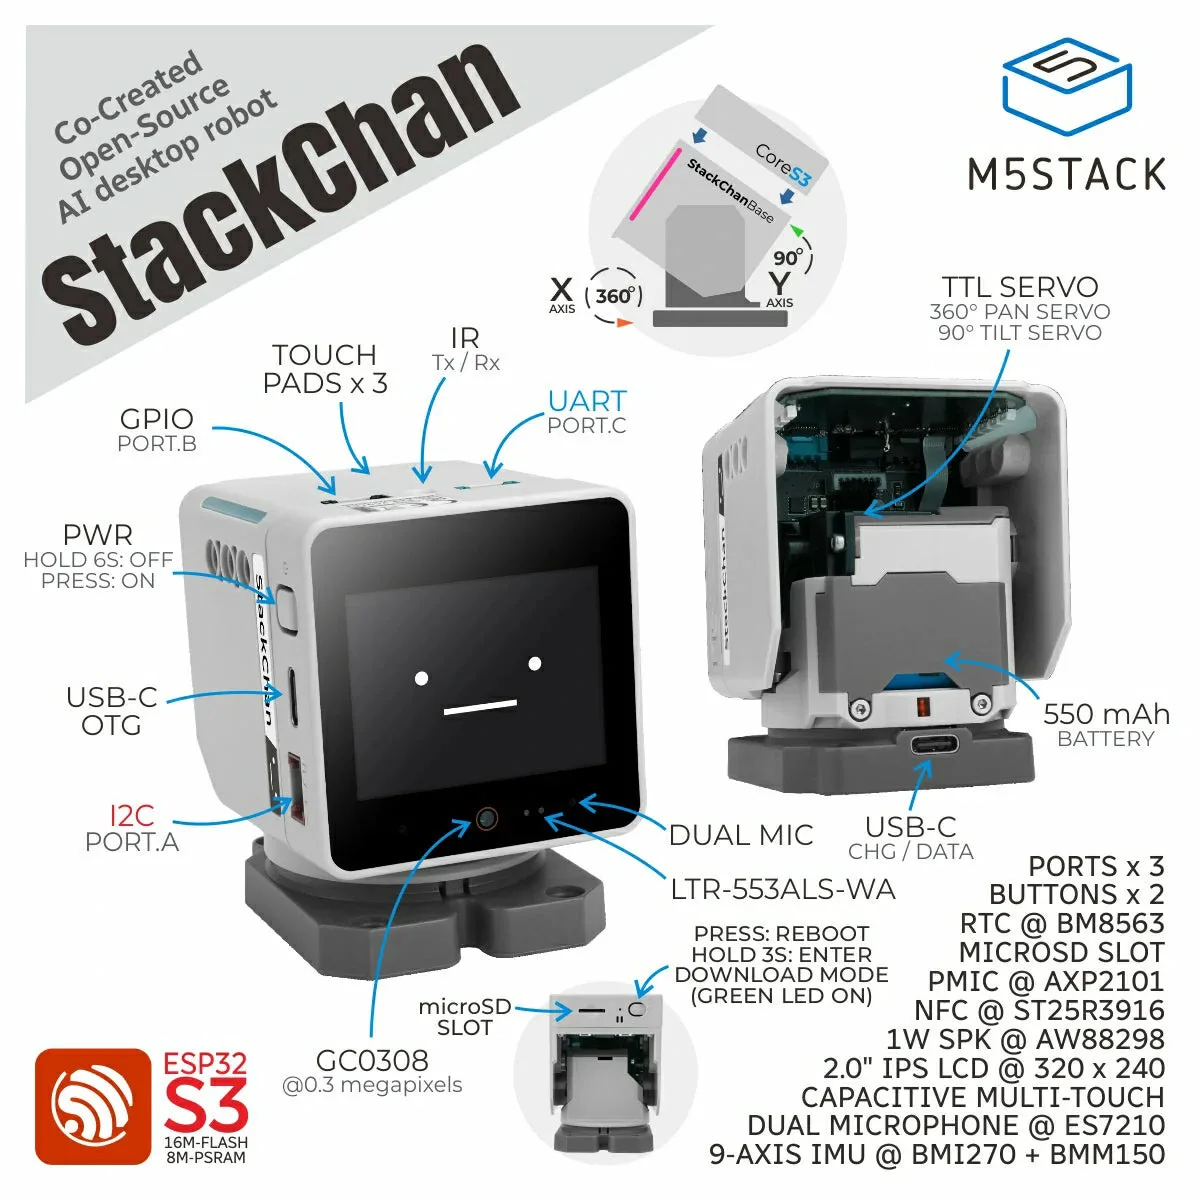
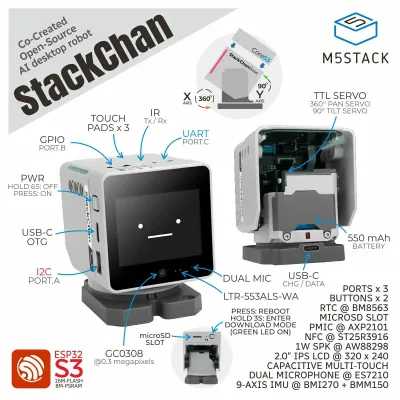
| Size | 70.5 × 61.5 × 54 mm, about 187 g |
| Drive | None (stationary). Head pans 360° (continuous) and tilts 90° on two feedback servos |
| Compute | M5Stack CoreS3 (ESP32-S3, 240 MHz dual-core, 16 MB flash, 8 MB PSRAM) |
| Vision | 0.3 MP camera (GC0308, 640×480) and a 2-inch 320×240 touchscreen face |
| Lidar | None |
| Sensors | Dual microphones, 1 W speaker, proximity/ambient light sensor, 9-axis IMU, three-zone touch panel, NFC, infrared Tx/Rx, 12 RGB LEDs, microSD slot, Wi-Fi and Bluetooth |
| Runtime | Not published (550 mAh battery, USB-C charging) |
| Speed | Not applicable (stationary head) |
| SDK | Open-source firmware, iOS/Android app and server on GitHub (m5stack/StackChan). Programmable with Arduino (StackChan BSP library), UiFlow2 blocks/MicroPython, PlatformIO or ESP-IDF, and the community Stack-chan firmware uses JavaScript/TypeScript (Moddable SDK) |
Ratings & reviews
Ratings and reviews load on the live site.
 Doly
 AIBI Pocket
 Vector 2.0
 EMO
 Jibo
 Moxie