$74,200 – $130,800 (reseller)RobotShop lists the Walker E Voice & Vision at $74,200 and the Walker E Embodied Intelligence at $130,800 (RobotShop US, September 2026). In China the 20-DOF base Tiangong Walker launched in March 2025 at RMB 299,000 (about $41,000). UBTECH publishes no US list price.
AvailableRL walkingResearch humanoidOpen joint APITiangong-based
Weeks+Shipping: Quote / weeks+ (unconfirmed). Listed by RobotShop US in two versions. Lead time was not published and is likely weeks for a made-to-order humanoid (unconfirmed). RobotShop ↗
Overview
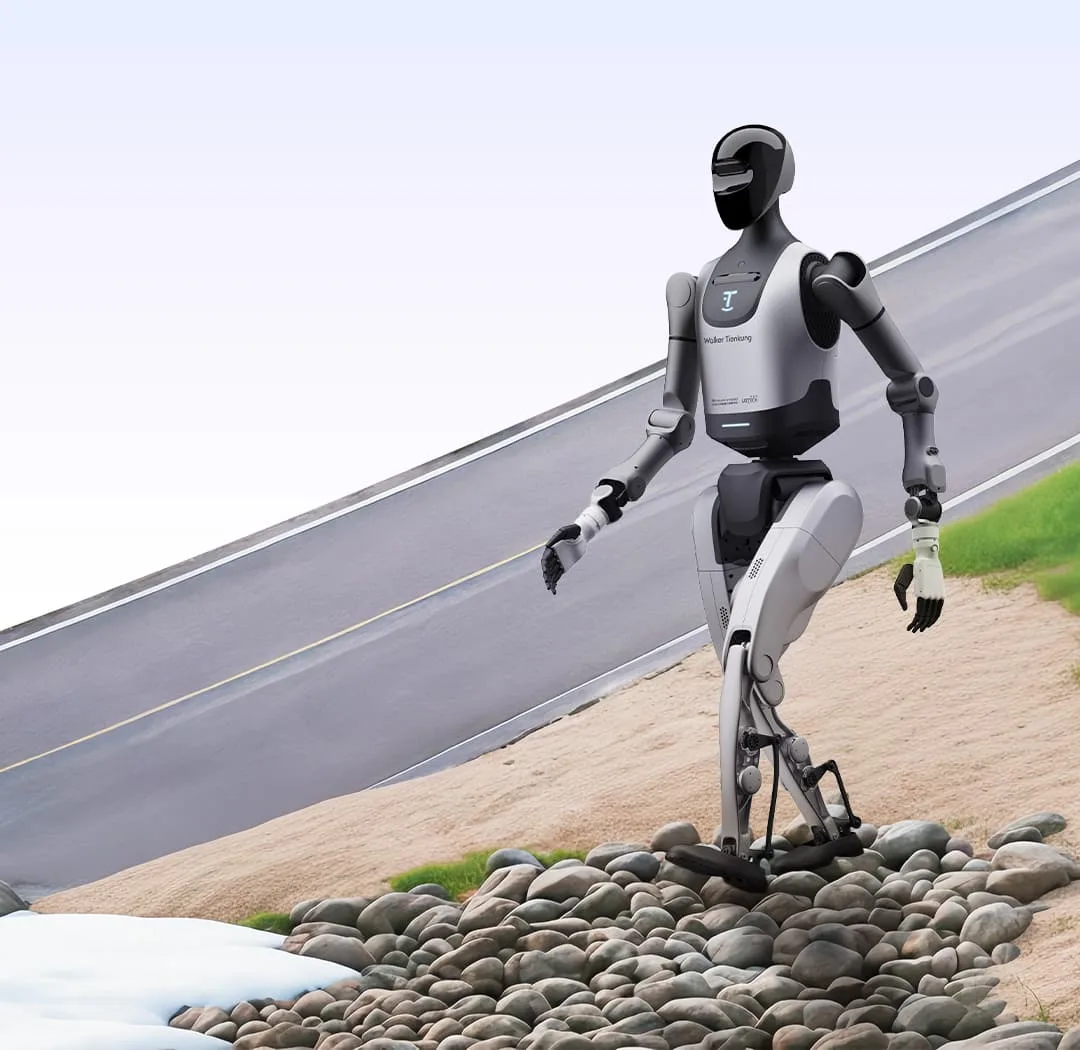
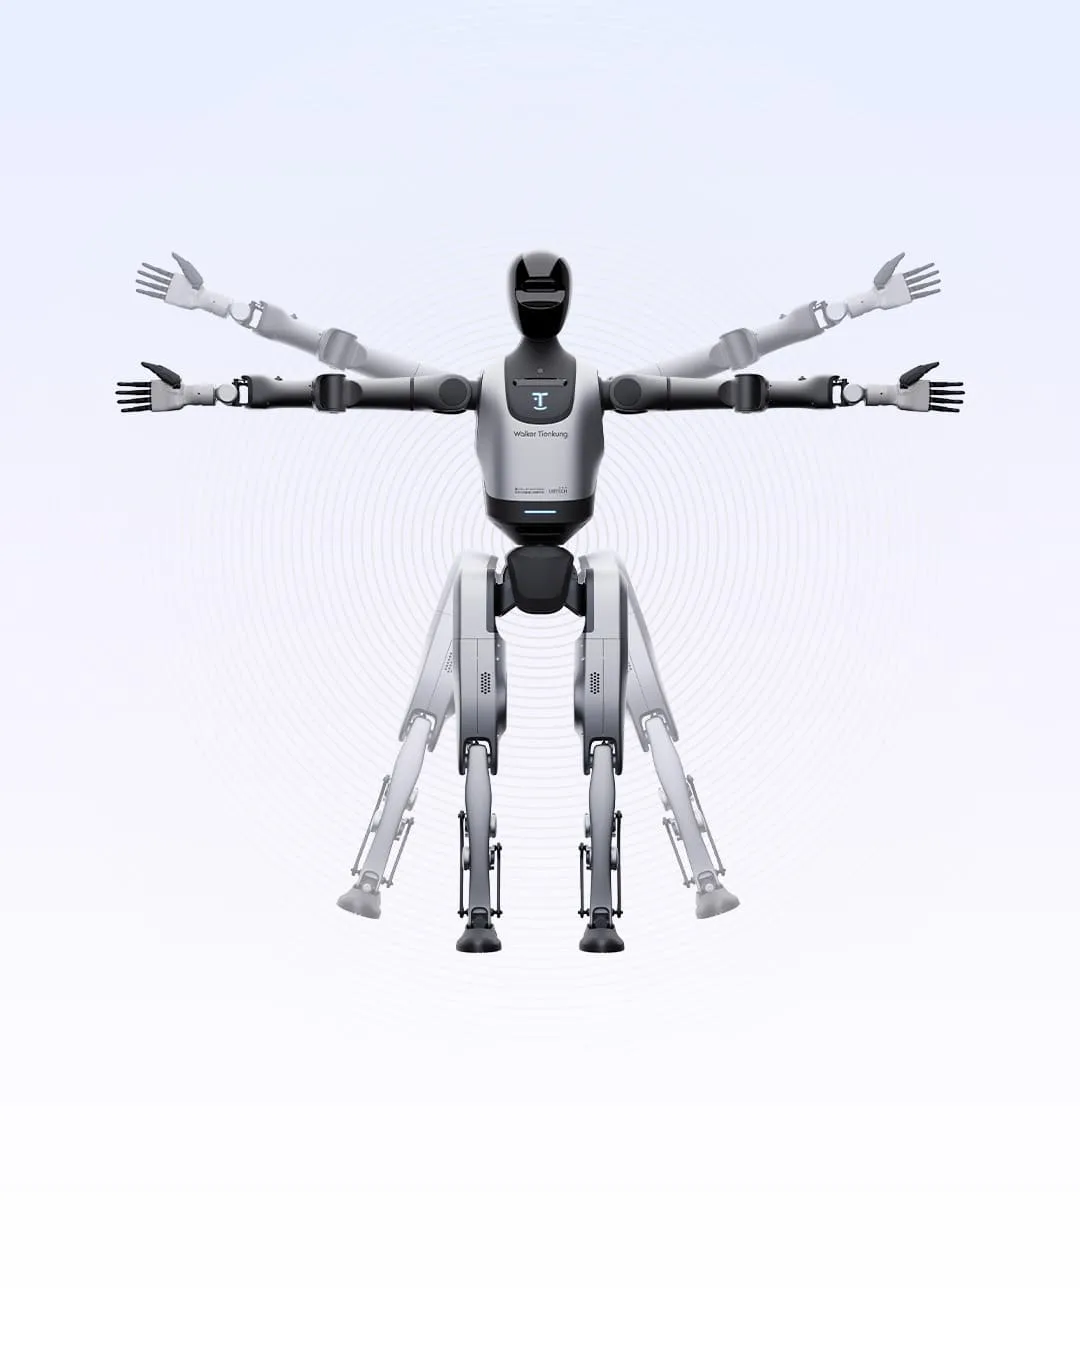
RobotShop's name for UBTECH's Walker Tienkung (Tiangong Walker), a 172 cm research and education humanoid co-developed with the Beijing Humanoid Robot Innovation Center on its Tiangong platform and launched in March 2025. Unlike the enterprise-only Walker S2, it is sold openly to universities and labs, with open interfaces for every joint and sensor, URDF models and reinforcement-learning training tools. The Voice & Vision version has 21 DOF with simple 4-DOF arms, while the Embodied Intelligence version adds 7-DOF arms, dexterous hands, force sensors and a second Jetson AGX Orin.
Specifications
| Category | Bipeds · Full-size humanoids |
|---|---|
| Released | 2025 |
| Country | China |
| Availability | Available |
| Sales | About 100 units on order by July 2025, with over 300 deliveries expected in 2025 (estimate) Jiemian ↗ |
| Programmability | Full SDK |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Official LLM tools · Ships with a voice module and supports user-deployed large language and vision models for voice interaction, rather than a default LLM assistant. UBTECH Walker Tienkung docs ↗ |
| MuJoCo simulation | Official model · UBTECH's TienKung-Lab includes MuJoCo sim2sim for Walker Tienkung. TienKung-Lab (UBTECH) ↗ |
| NVIDIA Isaac simulation | Sim-to-real kit · UBTECH's TienKung-Lab trains in Isaac Lab, and Deploy_Tienkung runs policies on the real robot. TienKung-Lab (UBTECH) ↗ |
| Gazebo simulation | Maker URDF only · UBTECH publishes Walker Tienkung URDFs, with no Gazebo package. Walker_TienKung_URDF ↗ |
| Best for | Professionals & labs |
| Vision sensors | Depth camera, Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | Speaker, Microphone |
| Compute type | x86 PC (Intel / AMD), NVIDIA Jetson |
| Balance type | RL walking |
| Height | 172 cm (spec sheet 1730 ± 10 mm) |
| Weight | 68 kg (Voice & Vision) / 75 kg (Embodied Intelligence) |
| Compute | Intel Core i7-1355U motion computer plus one (Voice & Vision) or two (Embodied Intelligence) NVIDIA Jetson AGX Orin 64GB, up to 550 TOPS |
| Speed | Up to 10 km/h running (UBTECH launch figure) |
| DOF | 21 (Voice & Vision) / 42 (Embodied Intelligence, 7-DOF arms and dexterous hands) |
| Sensors | RGB-D cameras in the head, waist and back, 720p RGB camera, 4-mic array, high-precision IMU. Embodied Intelligence adds 6-axis force sensors. |
| Balance | Real-time dynamic balance with resistance to impacts, walking on slopes, sand and snow. UBTECH ships AMP-style reinforcement-learning frameworks and gait-training tools. |
| SDK | Ubuntu 22.04 with ROS, open interfaces for all joints and sensors, URDF models, RL gait-training and imitation-learning SDKs |
Ratings & reviews
Ratings and reviews load on the live site.
 Optimus (Gen 1 / Gen 2 / V3)
 Figure 01 / Figure 02
 Figure 03
 NEO
 Digit
 Apollo