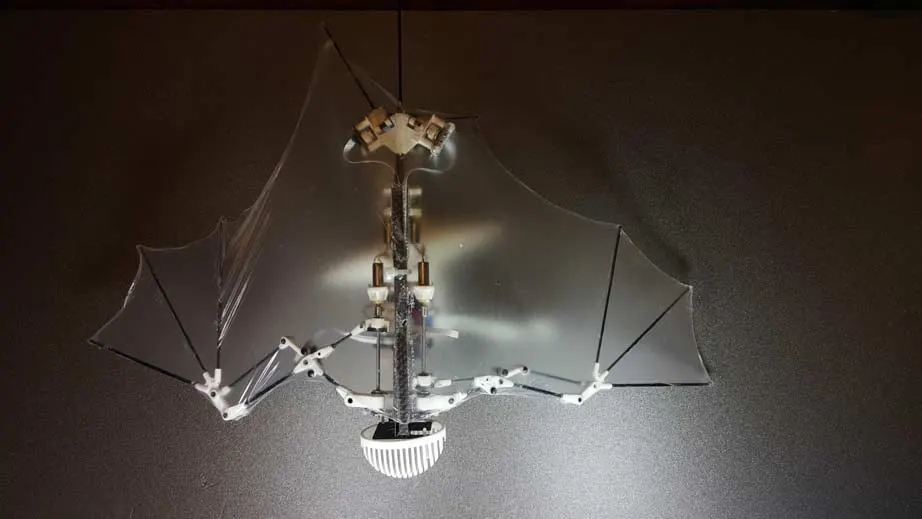
Not soldAcademic research robot (Science Robotics, February 2017).
Not for sale (research)Not programmableRobotic batMorphing membrane wings93 g
Not soldShipping: Not sold. Not available; a university research project.
Remote control: Not possible. A university research platform.
Overview
Bat Bot mimics the bat's highly articulated wing by driving only a few dominant joints and letting an ultrathin, stretchable silicone membrane morph with them. It achieved fully self-contained autonomous flight using virtual-constraint control, and was published in Science Robotics in 2017 as a platform for studying bat flight. Lead author Alireza Ramezani later continued the line with the Aerobat morphing-wing project.
Specifications
| Category | Flapping-wing fliers · Flapping-wing robots |
|---|---|
| Released | 2017 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | Unknown |
| Remote control | Not programmable |
| Size | 93 g; wingspan about 47 cm per IEEE Spectrum (Caltech describes it as roughly one foot) |
| Locomotion | Articulated morphing armwings with a 56-micrometre silicone membrane skin; asynchronous wing and leg (tail) motions |
| Compute | STMicroelectronics STM32F429 microcontroller on a custom main control board, with SD-card logging; Bluetooth and an 8-channel RC receiver link to a host |
| Camera | None |
| Sensors | VectorNav VN-100 IMU; five AS5048 Hall-effect encoders at the elbows, hips and flapping joint |
| Runtime | Not published |
| Speed | Peak of about 14 m/s recorded in a diving maneuver |
| SDK | None |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
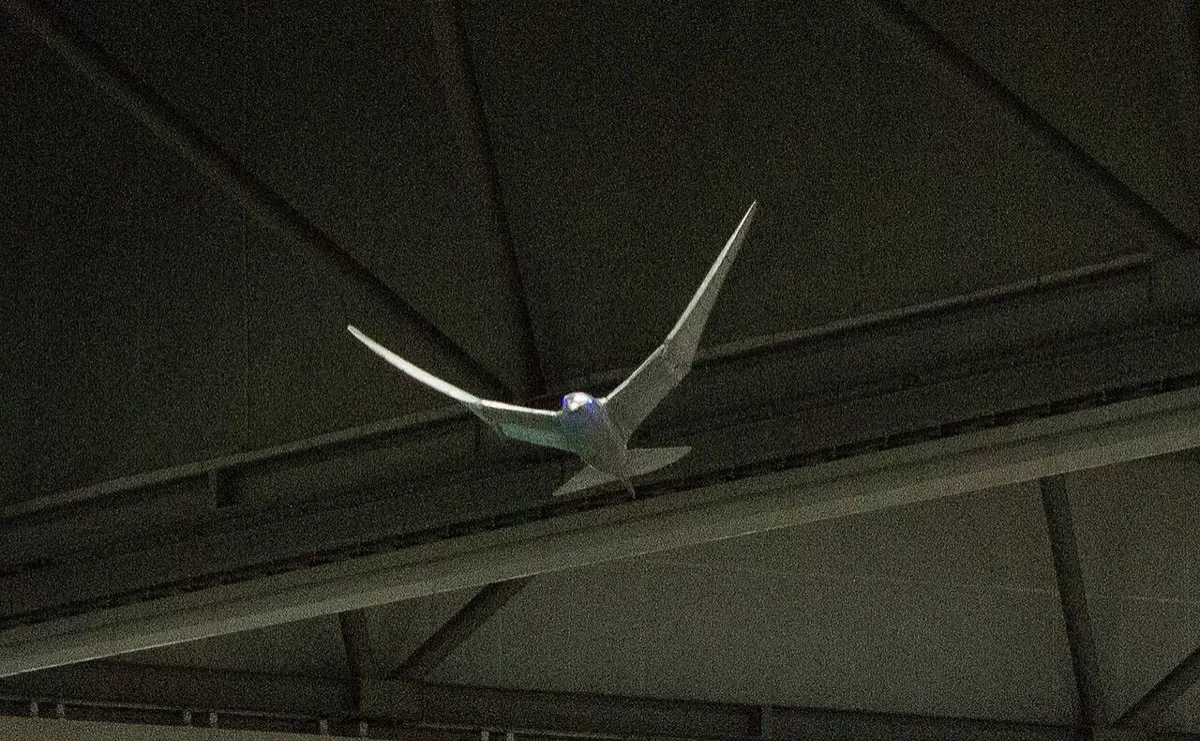 Festo SmartBirdFesto Bionic Learning Network (Germany)Not sold
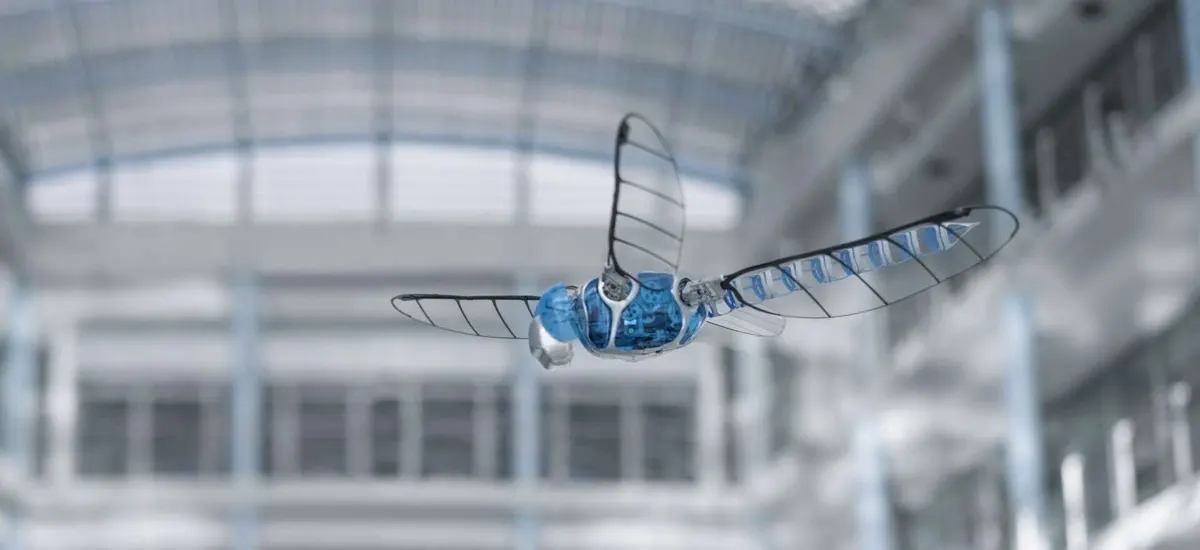 Festo BionicOpterFesto Bionic Learning Network (Germany)Not sold
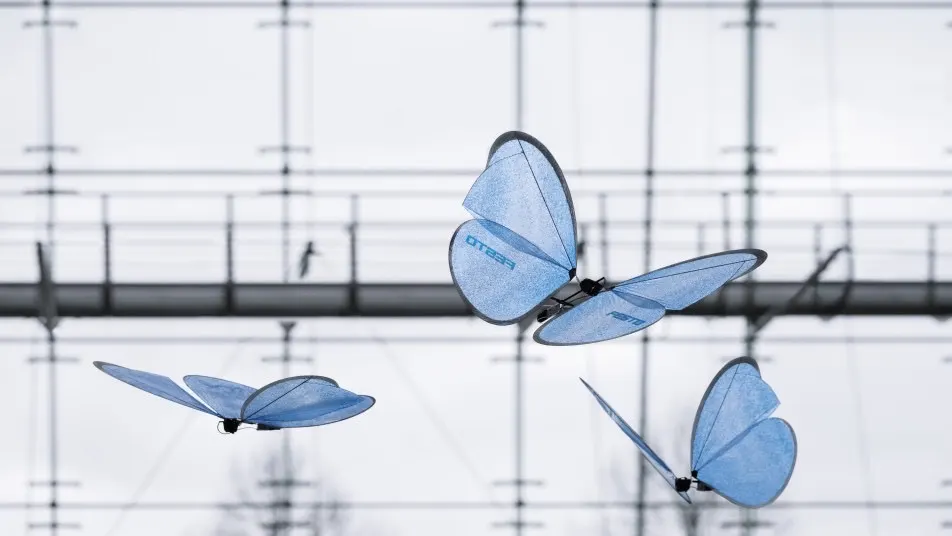 Festo eMotionButterfliesFesto Bionic Learning Network (Germany)Not sold
 Festo BionicSwiftFesto Bionic Learning Network (Germany)Not sold
 Harvard RoboBee / RoboBee X-WingHarvard Microrobotics Lab / Wyss Institute (USA)Not sold
 AeroVironment Nano HummingbirdAeroVironment (USA), for DARPANot sold
Image credits
- Image 1: source (Ramezani, Chung and Hutchinson, Science Robotics 2017, Fig. 2 photo of B2; © The Authors)