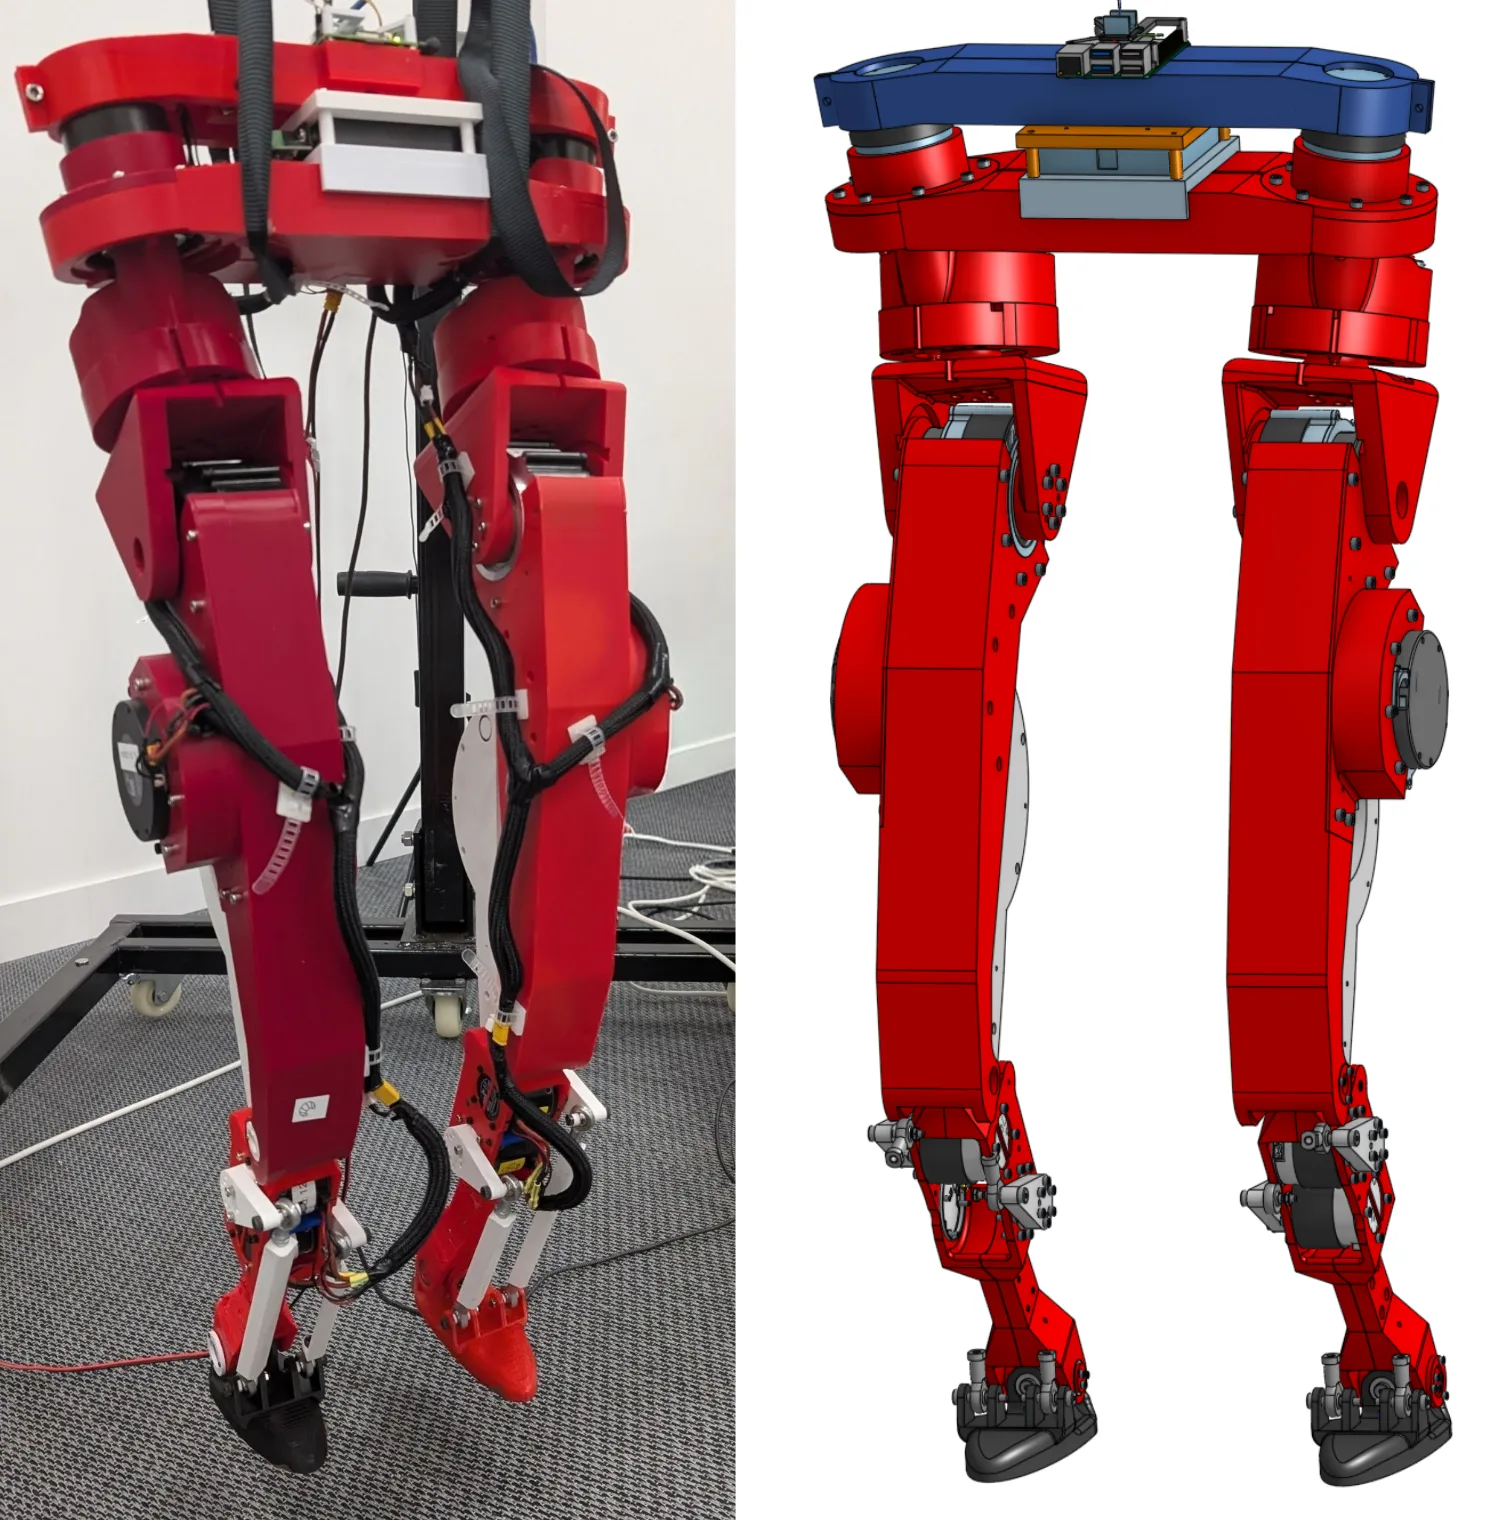
~$2,600 DIY partsDIY only, no kit or assembled version is sold. The hardware repo's BOM estimate (April 30, 2026) totals $2,636 for the biped including ~3.5 kg of PLA+, excluding shipping, duties and taxes. Hugging Face's launch post says around $2,500 in parts, and the project's longer-term target for the full robot is under $5,000. A 3D printer is needed
AvailableRL walkingLegs only (12 DOF)MuJoCo / MJLab RL3D-printedStanding policy so far
Weeks+Shipping: DIY build. Nothing to order from Hugging Face. Builders buy the parts on the hardware repo's BOM (RobStride motors, Raspberry Pi 5, IMU, CAN adapter, bearings, fasteners) and print 75 parts. Motor lead times and print time set the schedule. Hardware repo ↗
Overview
Hugging Face's open-source biped, a 3D-printed pair of legs on RobStride motors with a Raspberry Pi 5 brain and roughly $2,600 in parts. It suits builders who want a real QDD biped to study sim-to-real, since the CAD, runtime and a system-identification pipeline that tunes the MuJoCo model from real logs are all public. The catch is that it is an early research platform. At launch only a standing policy ran on the hardware, there are no arms yet, and the robot is tested on a gantry.
A cheap, fully open QDD biped for sim-to-real research, but a build project with unfinished locomotion rather than a robot that walks out of the box.
Specifications
| Category | Bipeds · Open-source RL bipeds |
|---|---|
| Released | 2026 |
| Country | France, USA |
| Availability | Available |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · Open-source Python runtime with a LeRobot integration, no LLM features. lerobot-humanoid-runtime ↗ |
| MuJoCo simulation | Sim-to-real kit · Official MJCF/URDF in lerobot-humanoid-model, MJLab walking tasks in lerobot-legged-zoo, and a runtime that runs the same ONNX policies in MuJoCo and on the real robot. lerobot-humanoid-runtime ↗ |
| NVIDIA Isaac simulation | Maker URDF only · Official URDF in lerobot-humanoid-model, no Isaac package. lerobot-humanoid-model ↗ |
| Gazebo simulation | Maker URDF only · Official URDF in lerobot-humanoid-model, no Gazebo package. lerobot-humanoid-model ↗ |
| Best for | Ages 18+ (estimated) |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Raspberry Pi |
| Balance type | RL walking |
| Height | Not published |
| Weight | ~12.7 kg (sum of link masses in the official URDF) |
| Compute | Raspberry Pi 5 (Ubuntu, Python 3.13) with a USB dual-CAN FD adapter |
| Speed | Not published (no real-robot walking speed released) |
| DOF | 12 (6/leg, legs only, no arms yet), RobStride O0/O2/O3/O5 actuators over CAN |
| Sensors | IMU (BNO055 or BNO085), motor encoders |
| Balance | RL policies trained in MJLab (MuJoCo) and run as ONNX on the Pi. As of the May 2026 launch, an early sim-to-real standing policy runs on the real robot. Walking is trained in simulation, and real-robot walking had not been shown (unconfirmed since). |
| SDK | Open source under Apache-2.0, covering hardware (Onshape CAD, 75 STLs, BOM, wiring), model (MJCF/URDF), runtime (MuJoCo + real robot, calibration, gamepad, LeRobot integration), CMA-ES system identification, MJLab training zoo |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 MicroduckPollen Robotics / Hugging Face$399
 Open Duck Mini v2Antoine Pirrone & community~$400 DIY · $600 kit · $900–1,000 built
 BimoMekion$500
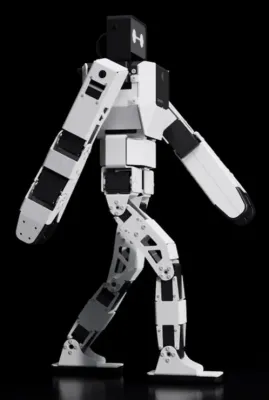 Z-Bot (Zeroth Bot)K-Scale Labs (defunct) & communityNot for sale · DIY BOM from ~$350
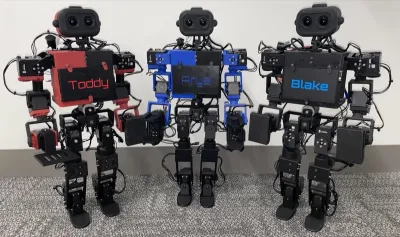 ToddlerBot 2.0Stanford (Haochen Shi et al.)~$6,000 DIY · $4,299 built
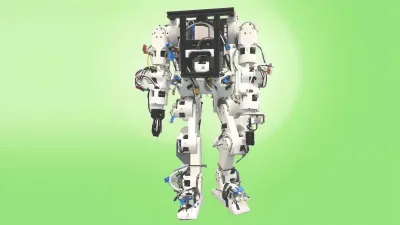 Berkeley Humanoid LiteUC Berkeley Hybrid Robotics~$4,300 DIY BOM
Image credits
- Image 1: source (official photo and CAD render, Hugging Face blog)