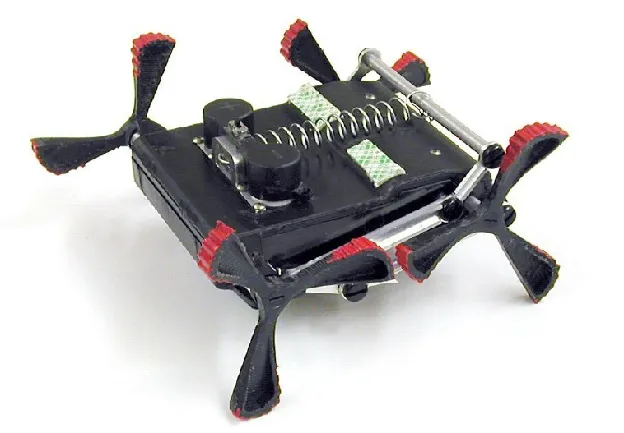
Not for saleUniversity research robots, developed with DARPA and other government funding. Never offered as products.
Not for sale (research)Wheel-legsCockroach-inspiredSingle drive motorResearch
Not for saleShipping: Not for sale. University research robots. The wheg concept is simple enough that many hobby builds copy it.
Overview
A family of robots from Roger Quinn's lab with Roy Ritzmann's cockroach biology group, which started around 2001 with Whegs I. Each three-spoke "wheg" mixes a wheel's simplicity with a leg's climbing, and torsional compliance lets a single motor produce a tripod gait that adapts to terrain on its own. Whegs II added a cockroach-like body joint for taller obstacles, and palm-sized Mini-Whegs later ran, jumped and even climbed walls. The idea is related to RHex and has inspired many hobby builds.
Specifications
| Category | Multi-legged robots · Research & legacy |
|---|---|
| Released | 2001 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Compute | Low-power microcontrollers (Whegs II), PIC-based control on some variants |
| Weight | 125 g (Mini-Whegs), larger versions not published |
| Speed | Mini-Whegs sustain over 10 body lengths/s. A 60 cm Whegs variant reached about 1.2 m/s |
| Legs / DOF | Six three-spoke whegs driven by one motor, servo steering, plus a servo body-flexion joint on Whegs II |
| Sensors | Whegs II has mechanical antennae, ultrasonic ranging and sound localization. Mini-Whegs usually carry none |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 PhantomX AX Hexapod (MK-III)Interbotix Labs / Trossen Robotics (USA)Was $1,095.95 – $1,999.95
 Robugtix T8Robugtix / Amoeba RoboticsWas $2,950
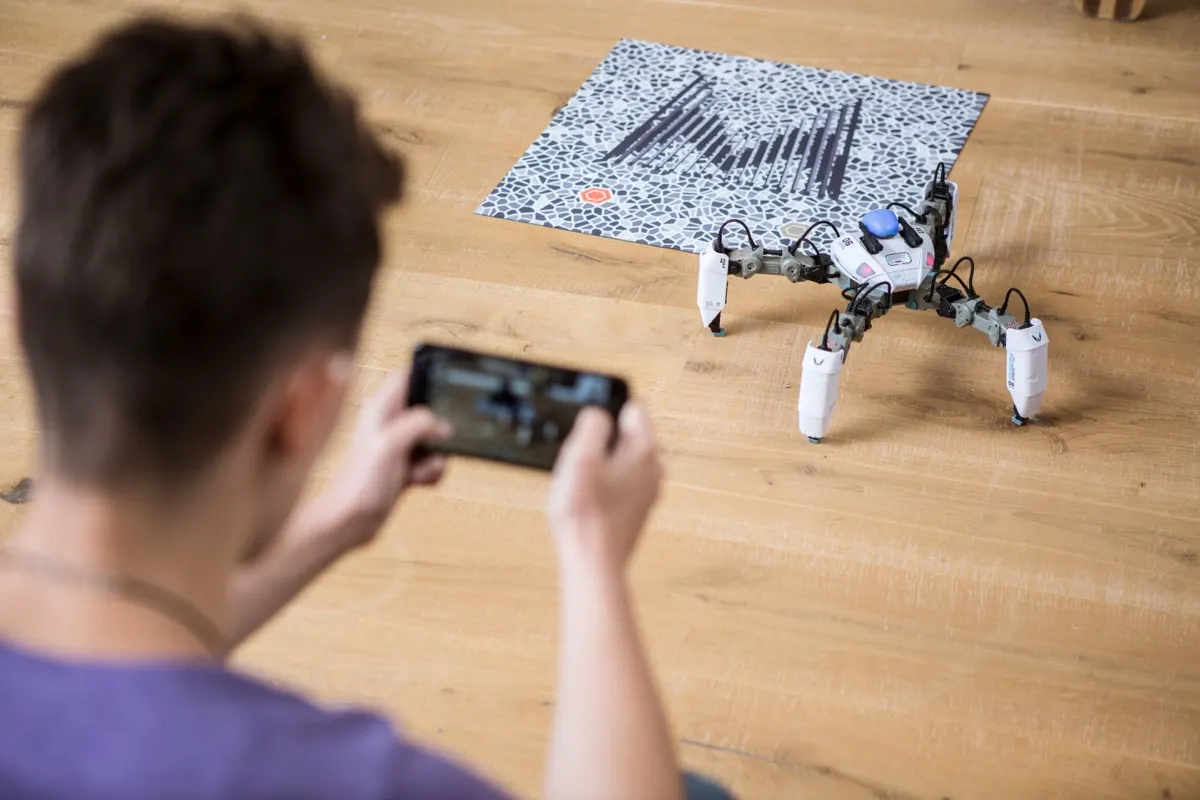 MekaMonReach Robotics (UK)Was $300
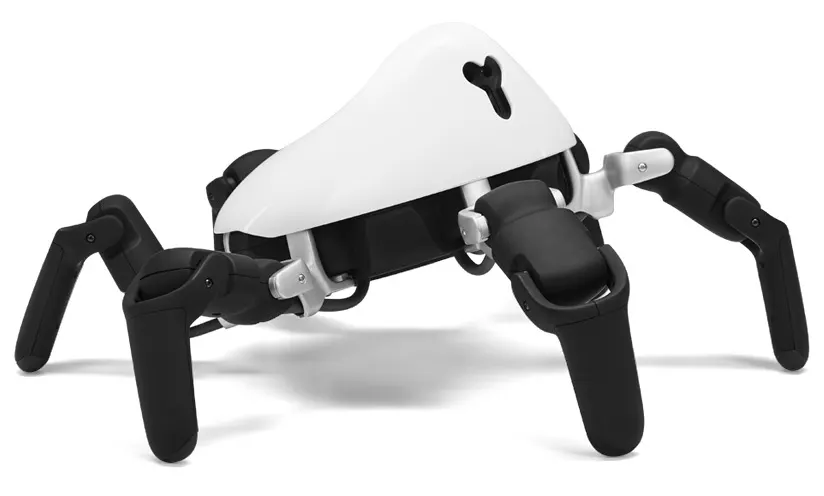 Vincross HEXAVincross (China)Was $999
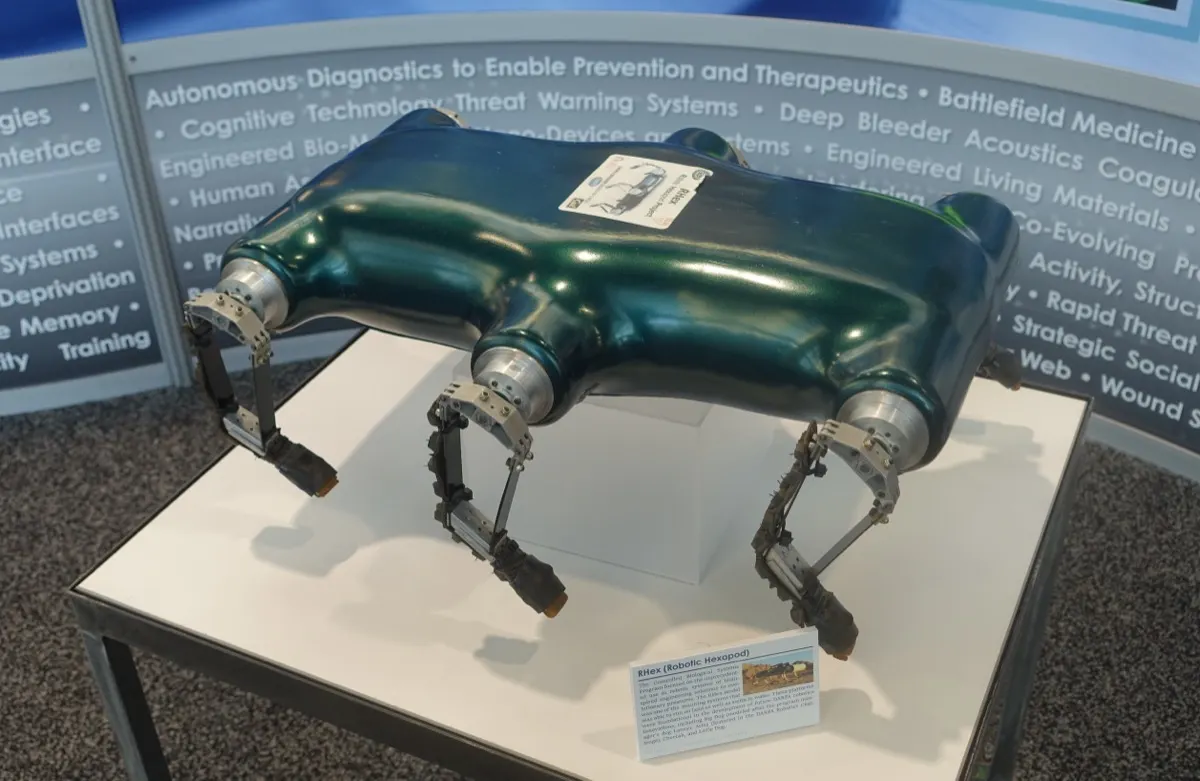 RHexBoston Dynamics / multi-university DARPA project (USA)Not for sale
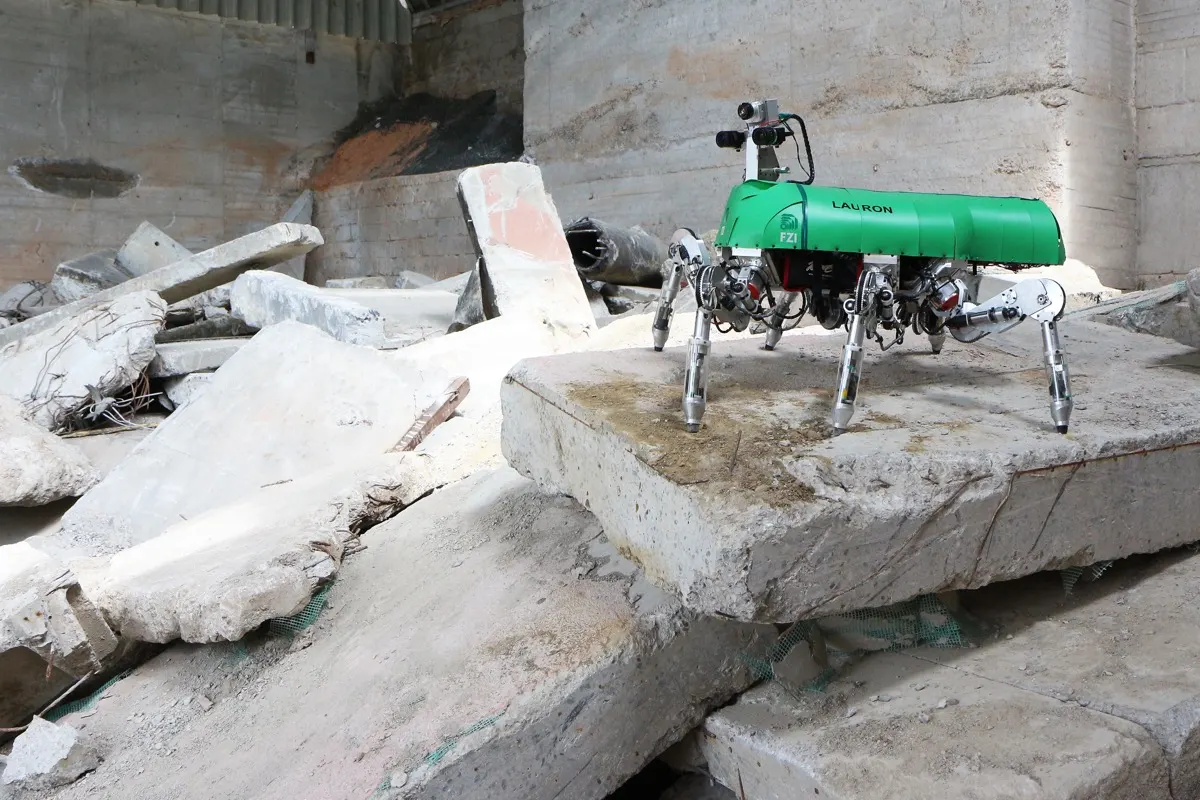 LAURON VFZI Forschungszentrum Informatik (Germany)Not for sale