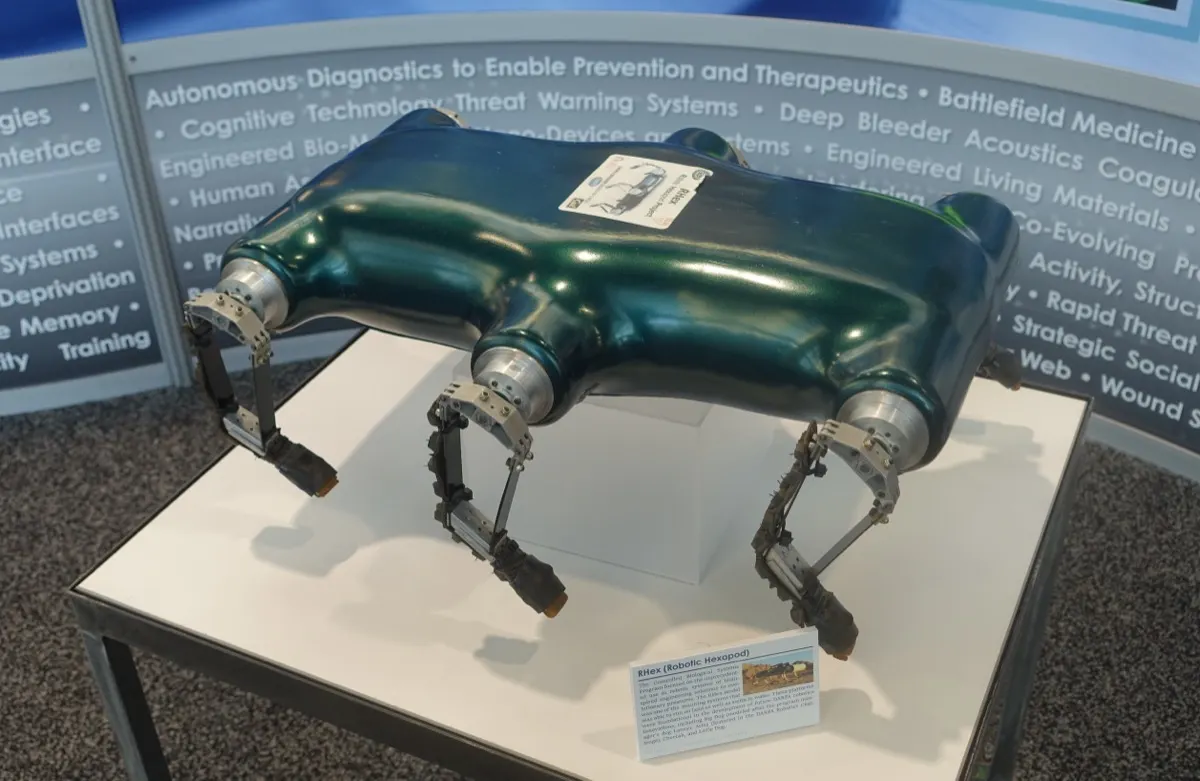
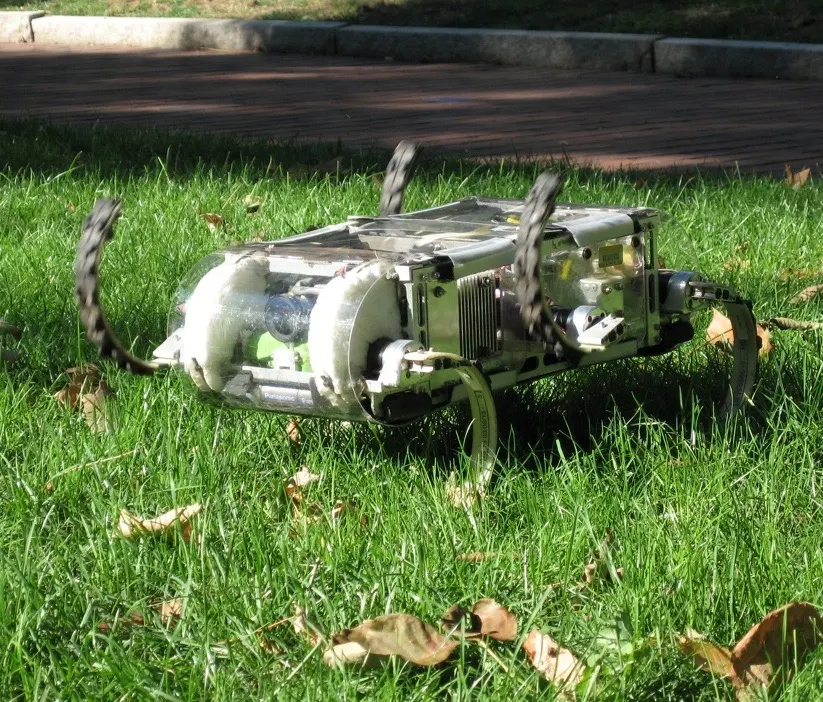
Not soldResearch platform (original academic RHex from ~2000); Boston Dynamics' ruggedized version was publicized around 2009 and tested for government use.
Not for sale (research)One motor per legRuggedStair climbingLegacy
Not soldShipping: N/A. Research and government platform; never sold to the public.
Overview
A deceptively simple hexapod with one motor per springy C-shaped leg that runs at five body lengths per second, climbs stairs, self-rights and even swims. It emerged from a DARPA-funded project spanning Michigan, McGill, CMU, Berkeley, Princeton and Cornell, and Boston Dynamics built a sealed, all-weather version remote-controlled up to 700 m away. Its compliant-leg approach inspired later designs such as Whegs.
Specifications
| Category | Multi-legged robots · Research & legacy |
|---|---|
| Released | 2009 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Compute | Onboard computer; teleoperated from an operator control unit |
| Weight | Not published |
| Speed | Up to 2.7 m/s (research versions) |
| Legs / DOF | 6 compliant C-shaped legs, 1 actuator each (6 DOF) |
| Sensors | Visible/IR cameras and illuminators front and rear (BD version); IMU and leg proprioception (research) |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
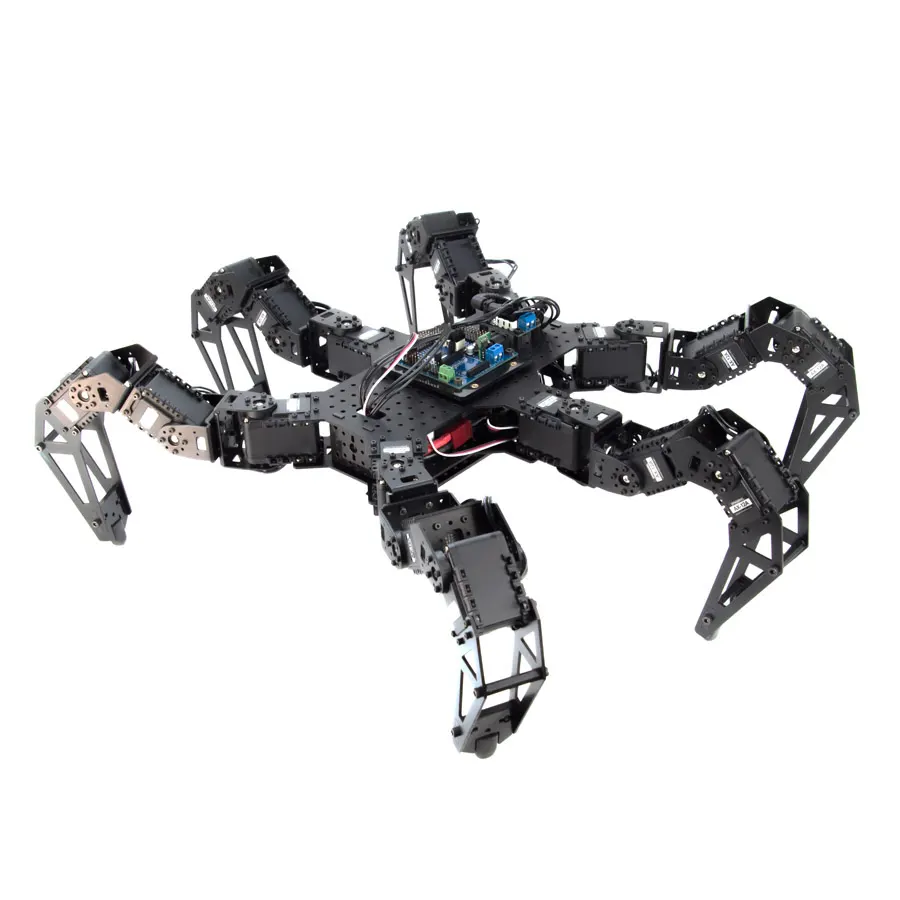 PhantomX AX Hexapod (MK-III)
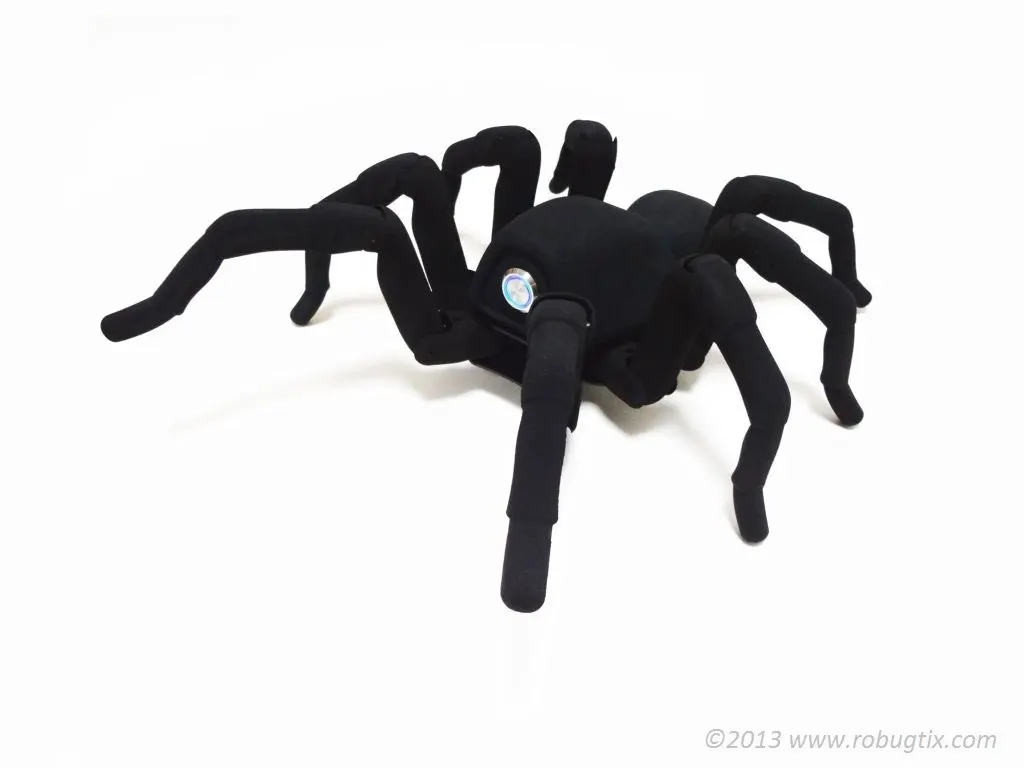 Robugtix T8
 MekaMon
 Vincross HEXA
 LAURON V
 ATHLETE