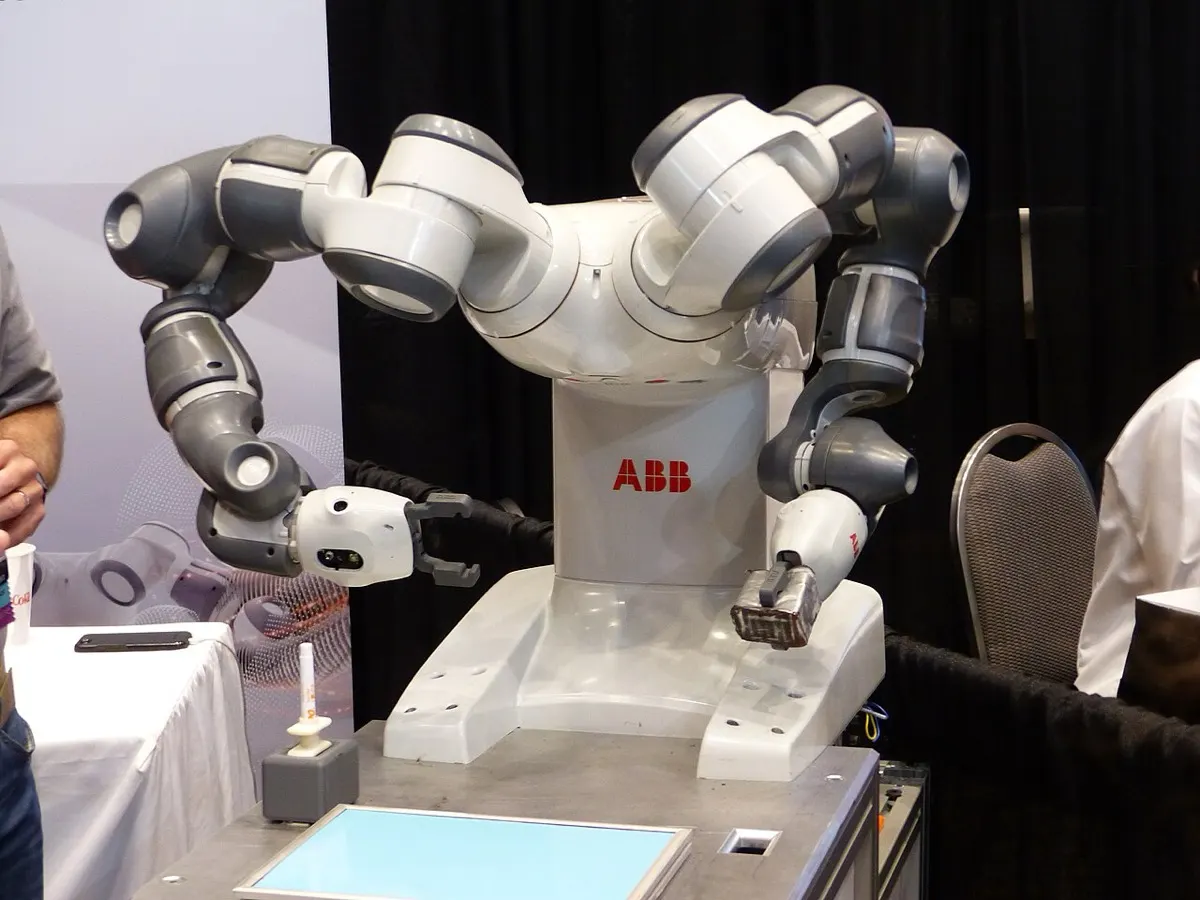
Quote onlyNo public list price; unveiled in 2014 and launched in 2015.
AvailableVia SSH / web / bridgeDual-armPadded armsSmall-parts assembly
Weeks+Shipping: Integrator lead time. Sold through ABB and its integrators on quotation; used units appear from labs and factories.
Remote control: A laptop can drive it through ABB Robot Web Services or EGM, typically via the ROS-Industrial
abb_robot_driver; native programs are written in RAPID.Overview
ABB's human-sized, padded two-armed robot for electronics and small-parts assembly, launched in 2015 as what ABB called the first truly collaborative robot. Its low payload limits industrial use, but it became a common dual-arm research platform. ABB later added a single-arm 7-axis YuMi and the larger GoFa and SWIFTI cobots.
Specifications
| Category | Robot arms · Industrial & legacy |
|---|---|
| Released | 2015 |
| Availability | Available |
| Programmability | Limited SDK |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Remote control | Via SSH / web / bridge |
| DOF | 14 (7 per arm) |
| Reach | 559 mm |
| Payload | 0.5 kg per arm |
| Repeatability | 0.02 mm |
| Weight | 38 kg |
| Controller | ABB IRC5 controller built into the torso |
| Sensors | Motor-current collision detection; optional SmartGrippers with integrated camera, vacuum and servo fingers |
| SDK | RAPID language in RobotStudio; Robot Web Services and Externally Guided Motion for external control; ROS-Industrial abb_robot_driver |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
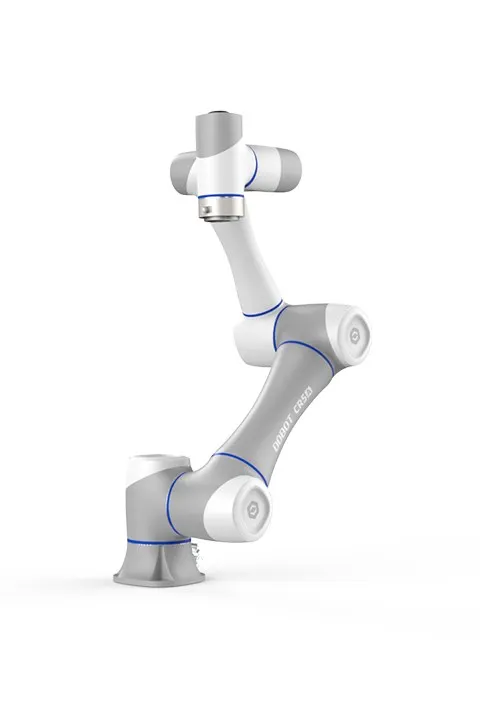 Dobot CR / CRA seriesDobot (China)Quote only
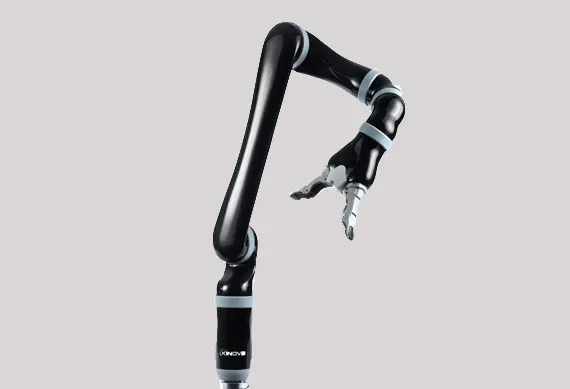 Kinova JACOKinova (Canada)Quote only
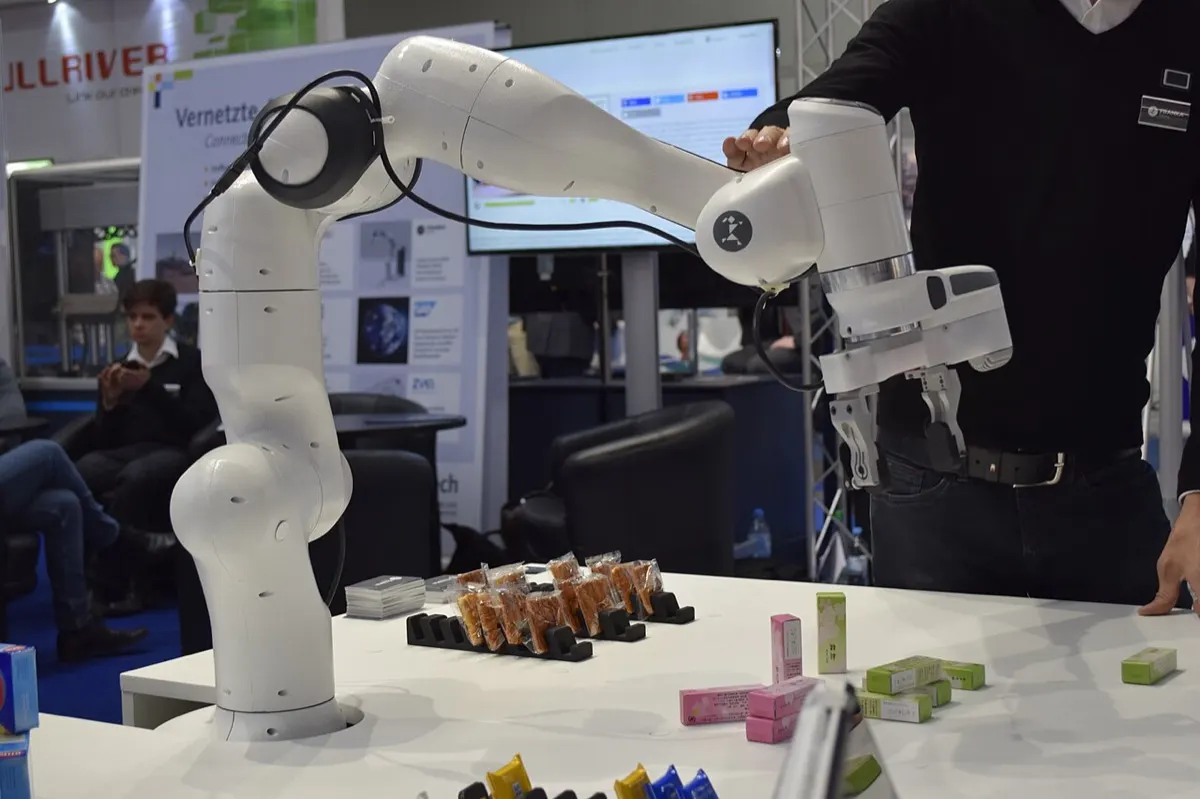 Franka Emika PandaFranka Emika (Germany)Was €9,900 (2016 pre-order)
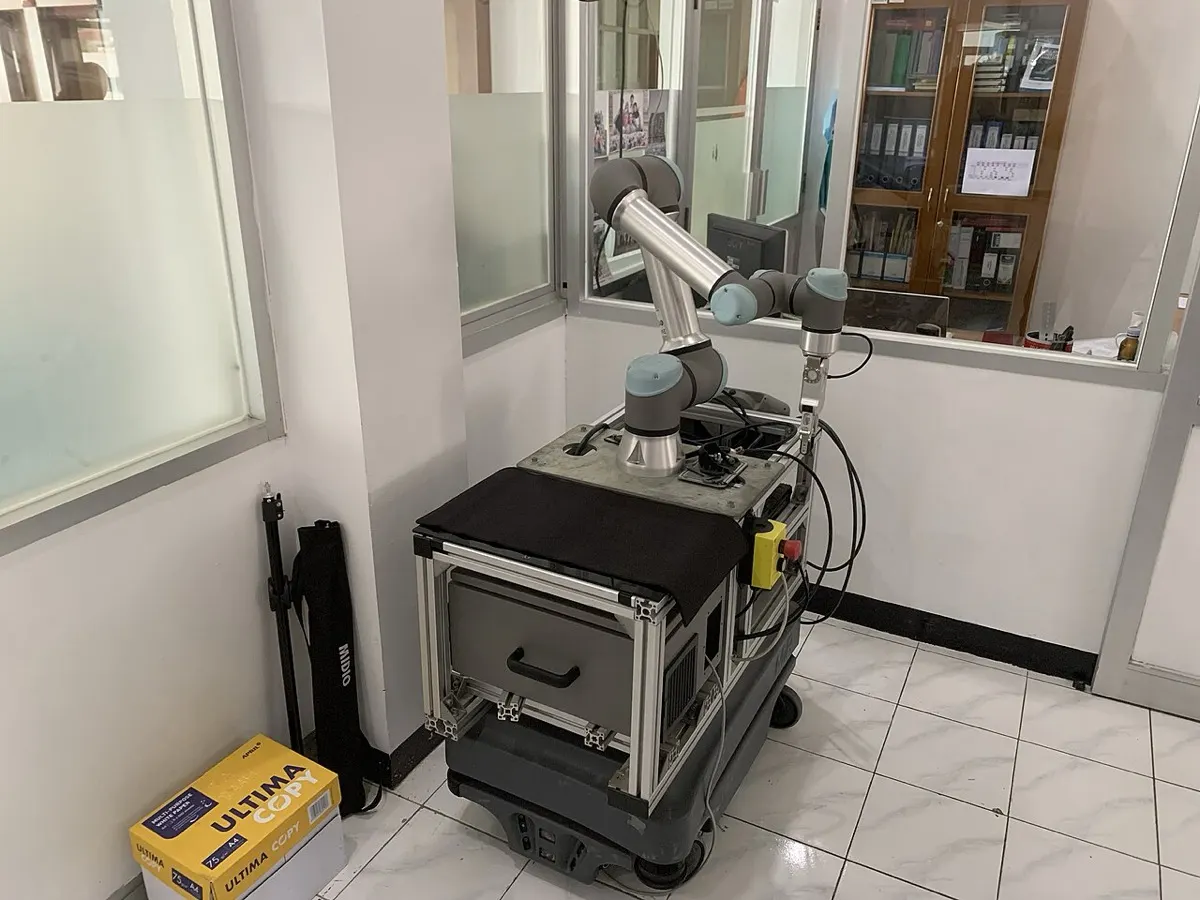 Universal Robots UR5e (UR7e)Universal Robots (Denmark; Teradyne)Quote only
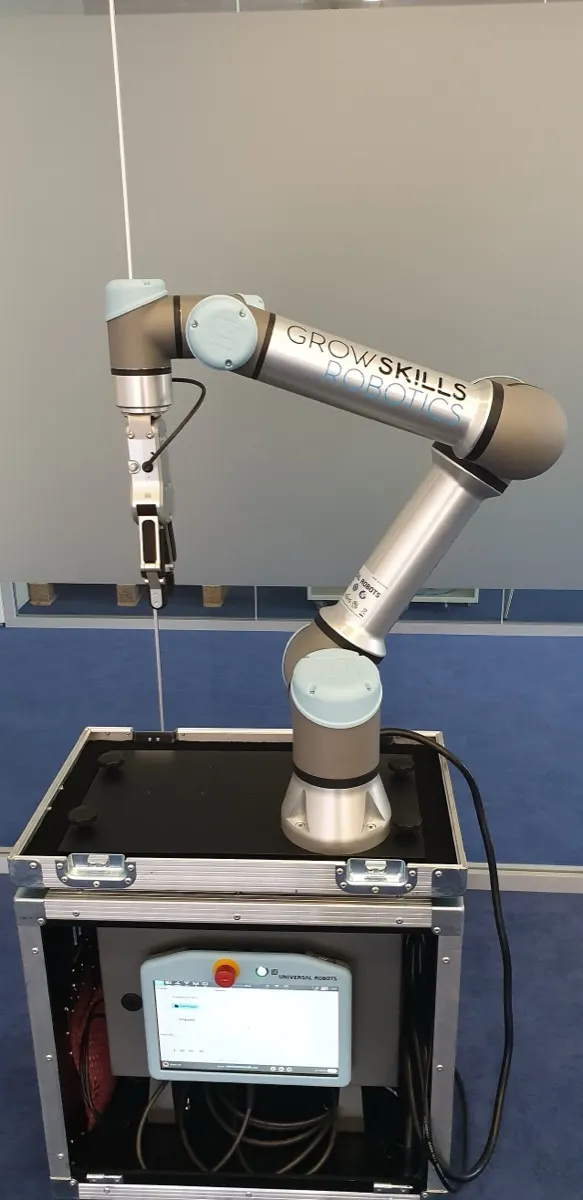 Universal Robots UR5 (original)Universal Robots (Denmark)Was about €20,000 (2012)
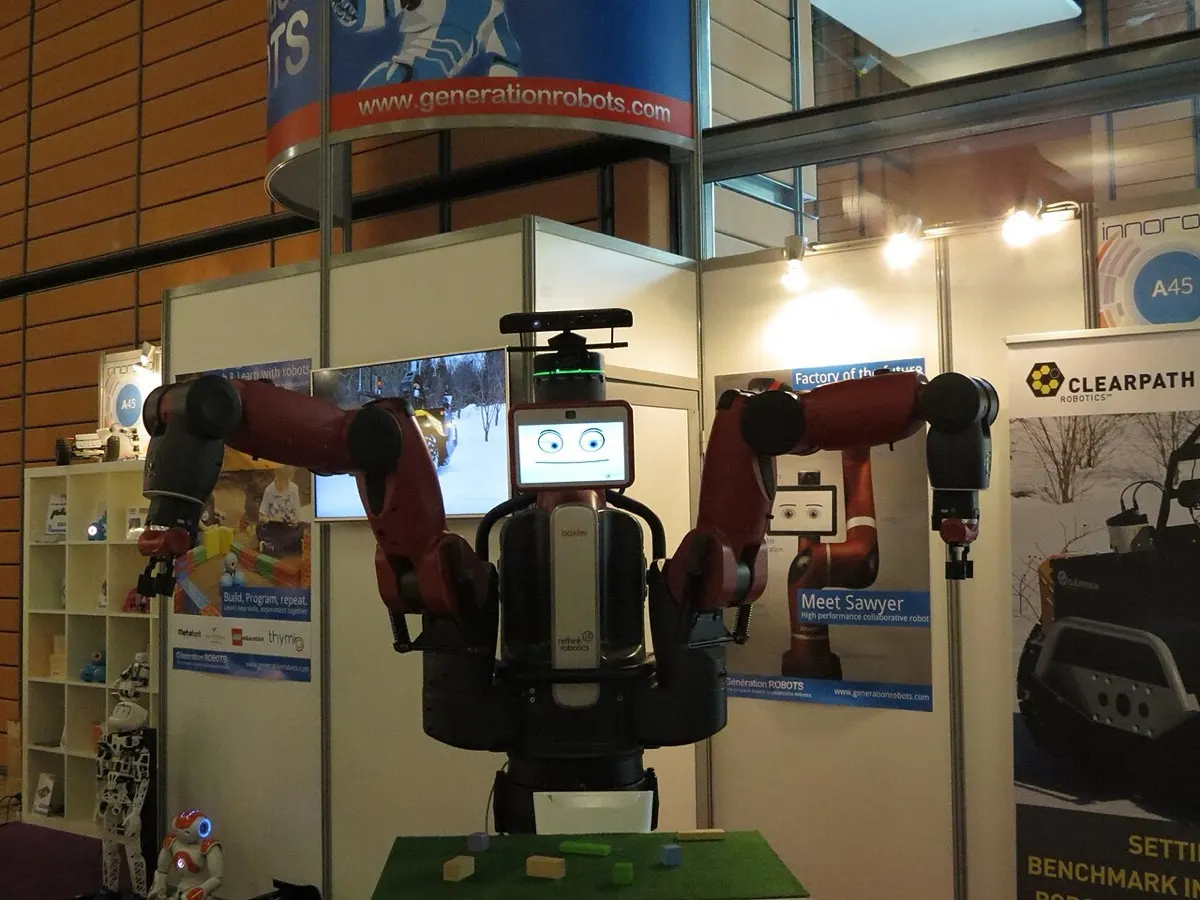 Rethink Robotics BaxterRethink Robotics (USA)Was $22,000 (2012)
Image credits
- Image 1: source (CC BY-SA 4.0, Stilfehler)