Comparison table
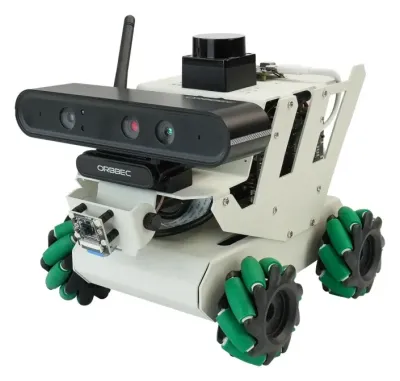 RDK X3 Robot CarYahboom | 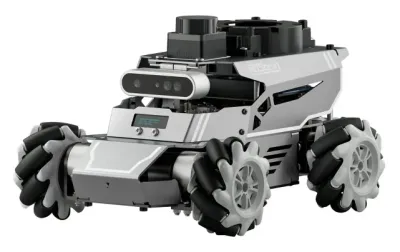 ROSOrinHiwonder | 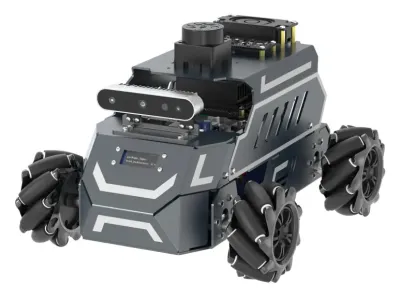 ROSMASTER M1Yahboom | 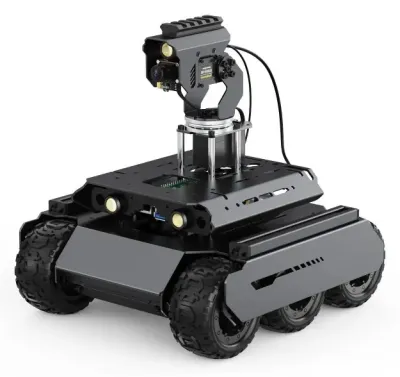 UGV RoverWaveshare | 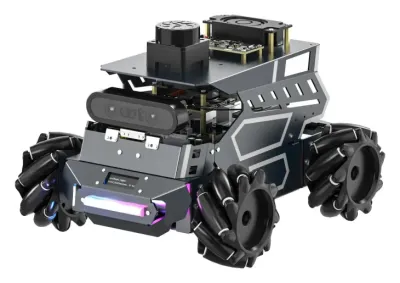 ROSMASTER M3Yahboom | 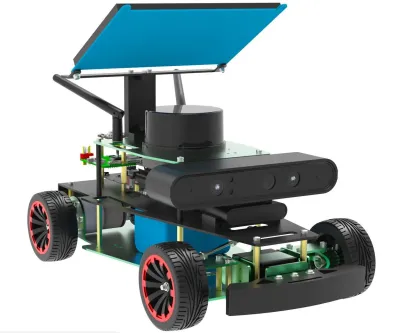 ROSMASTER R2Yahboom | 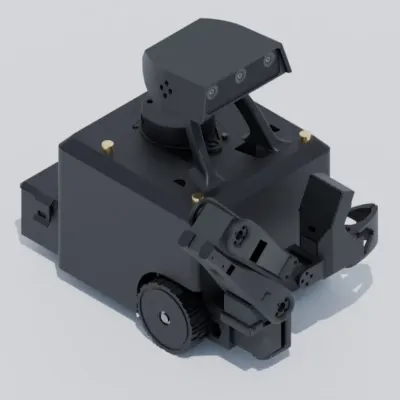 MARSInnate | |
|---|---|---|---|---|---|---|---|
| Price | |||||||
| Price range | $359 – $519 | $299.99 – $1,499.99 | $349.90 – $1,169.90 | $245 – $727 | $779.90 – $2,409.90 | $655 – $2,375 | $995 |
| Version compared | Advanced Kit with RDK X3 4 GB $459 | Standard with Pi 5 4 GB $619.99, mecanum only (Advanced at $719.99 adds Ackermann and differential chassis) | Superior with RDK X5 $669 | PT ROS 2 kit with Pi 5 4 GB $726.99 | Standard with RDK X5 8 GB $959.90 | Standard with Pi 5 8 GB $985 | MARS $995, ships assembled |
| Also needed | Nothing listed | Nothing listed | Nothing listed | Three 18650 cells | Nothing listed | Nothing listed | Nothing listed |
| Seeing obstacles | |||||||
| Depth camera | Orbbec Astra Pro Plus | Aurora930 Pro | Nuwa-HP60C | Luxonis OAK-D Lite stereo | Orbbec DaBai DCW2 | Orbbec Astra Pro Plus | Stereo head that tilts |
| Depth range | 0.6–8 m | 0.15–3 m | 0.2–4 m | Not published | 0.15–3 m (5 m in high-power mode) | 0.6–8 m | 0.4–6 m |
| Lidar | Oradar MS200, 12 m | STL-19P D500 (range unconfirmed) | T-MINI Plus, 12 m | D500 360° | T-mini Plus, 12 m | RPLIDAR A1M8, 12 m | 2D 360°, 6 m |
| Depth used in navigation lessons | RTAB-Map 3D mapping and navigation | RTAB-Map 3D mapping and navigation | Not confirmed | 3D mapping in the ROS 2 chapters | RTAB-Map mapping and navigation, depth ranging and following | RTAB-Map 3D mapping, ORB-SLAM2 with Octomap | Mapping and navigation in Innate OS |
| Spotting the cat | |||||||
| On-board computer | RDK X3 4 GB | Raspberry Pi 5 4 GB | RDK X5 | Raspberry Pi 5 4 GB | RDK X5 8 GB | Raspberry Pi 5 8 GB | Jetson Orin Nano Super 8 GB |
| AI accelerator | 5 TOPS on the RDK X3 | None (Jetson versions from $789.99) | Up to 10 TOPS on the RDK X5 | On the OAK-D Lite camera | 10 TOPS on the RDK X5 | None (Jetson versions from $1,015) | 67 TOPS on the Jetson |
| Detection lessons | 80-class object detection, whose standard COCO classes include cat | YOLOv11 (TensorRT on the Jetson versions) | YOLOv11 | MobileNet-SSD example whose 20 classes include cat | YOLOv11 detection and tracking with the depth camera | YOLOv11 with TensorRT on the Orin boards only | Python skills and LLM agents, no detector named |
| Moving | |||||||
| Drive | Mecanum wheels | Mecanum wheels (Ackermann and differential packs on Advanced) | Mecanum wheels | 6 rubber wheels, skid steer | Mecanum wheels with suspension | Ackermann steering, rubber tires | Differential drive |
| Speed | Not published | Not published | Not published | 1.3 m/s | Not published | 1.8 m/s | 0.4 m/s (0.8 m/s in Mad mode) |
| Battery life | About 3.5 h | Not published (6,000 mAh) | Not published (6,000 mAh) | About 1.5 h | About 3 h | About 2 h with the Pi 5 | About 5 h |
| Size and weight | 23.6 × 18.1 × 18.5 cm, 1.93 kg | 27.7 × 21.2 × 16.6 cm, 2.66 kg (mecanum) | 28 × 23 × 18 cm (unconfirmed) | 23 × 25 × 26 cm, 2.2 kg | 23.7 × 21.2 × 17.4 cm, 2.88 kg | 33.8 × 19.1 × 26 cm (unconfirmed), 2.5 kg | About 25 cm tall |
| Programming | |||||||
| ROS version | ROS 2 Foxy (Humble on the RDK X5 version) | ROS 2 Humble | ROS 2 Humble | ROS 2 Humble | ROS 2 Humble | ROS 2 Foxy in Docker on the Pi 5 | Innate OS, built on ROS 2 |
| Gazebo simulation | None found | Official package | None found | Official package | None found | None found | Robot model only |
| LLM support | Possible via SDK | Official LLM tools | Official LLM tools | Official LLM tools | Official LLM tools | Built-in LLM chat | LLM plans actions |
| Purchasing | |||||||
| Suggested ages | 14+ | 14+ | 14+ | 14+ | 14+ | 14+ | 14+ |
| Shipping to the US | ~1–2 wks (est.) | ~1 wk (est.) | ~1–2 wks (est.) | ~1–2 weeks direct | ~1–2 wks (est.) | ~1–2 wks (est.) | Unconfirmed |
Highlighted cells are the strongest in their row. Speeds marked (est.) are not published by the maker. They come from owner measurements or the makers' gait code, explained on each robot page. Prices are US list prices as of September 2026. Each robot's page has full specs, sources and photos.
Which one fits
- UGV Rover is the strongest all-round pick for following a cat. It has six rubber wheels for carpet and thresholds, 1.3 m/s, an OAK-D Lite that can run detection on the camera itself, and an official on-board detector whose classes include cat. Battery life is about 1.5 hours, and the three 18650 cells cost extra.
- RDK X3 Robot Car is the cheapest way to get lidar, a depth camera and an AI accelerator, at $459 with about 3.5 hours of battery. Its Astra Pro Plus cannot see closer than 0.6 m, it runs the older ROS 2 Foxy on the RDK X3, and Mecanum wheels grip carpet less well than tires.
- ROSOrin pairs a Raspberry Pi 5 with a depth camera that sees from 0.15 m, tied for the closest here, plus an official Gazebo simulation and RTAB-Map lessons. The $719.99 Advanced kit adds the differential chassis, which suits carpet better than Mecanum wheels.
- ROSMASTER M1 Superior with the RDK X5 is the cheapest pairing of a depth camera with a 10 TOPS accelerator, at $669. Whether its course uses the depth camera for navigation is not confirmed, and it rolls on Mecanum wheels.
- ROSMASTER M3 has a close-range DaBai DCW2 depth camera, the RDK X5 accelerator, YOLOv11 tracking lessons that use the depth camera, suspension and about 3 hours of battery. It costs $959.90 and still uses Mecanum wheels.
- ROSMASTER R2 is the fastest here at 1.8 m/s, on rubber tires. Its car-style Ackermann steering needs room for multi-point turns in hallways and doorways, its Astra Pro Plus cannot see closer than 0.6 m, and the Pi 5 version runs ROS 2 Foxy in Docker.
- MARS ships assembled with a Jetson Orin Nano Super (67 TOPS), a tilting stereo head, an arm and about 5 hours of battery, so it can run far larger detectors than the rest. It is the slowest at 0.4 m/s, its LLM agent features use Innate's cloud, and US shipping times are unconfirmed.