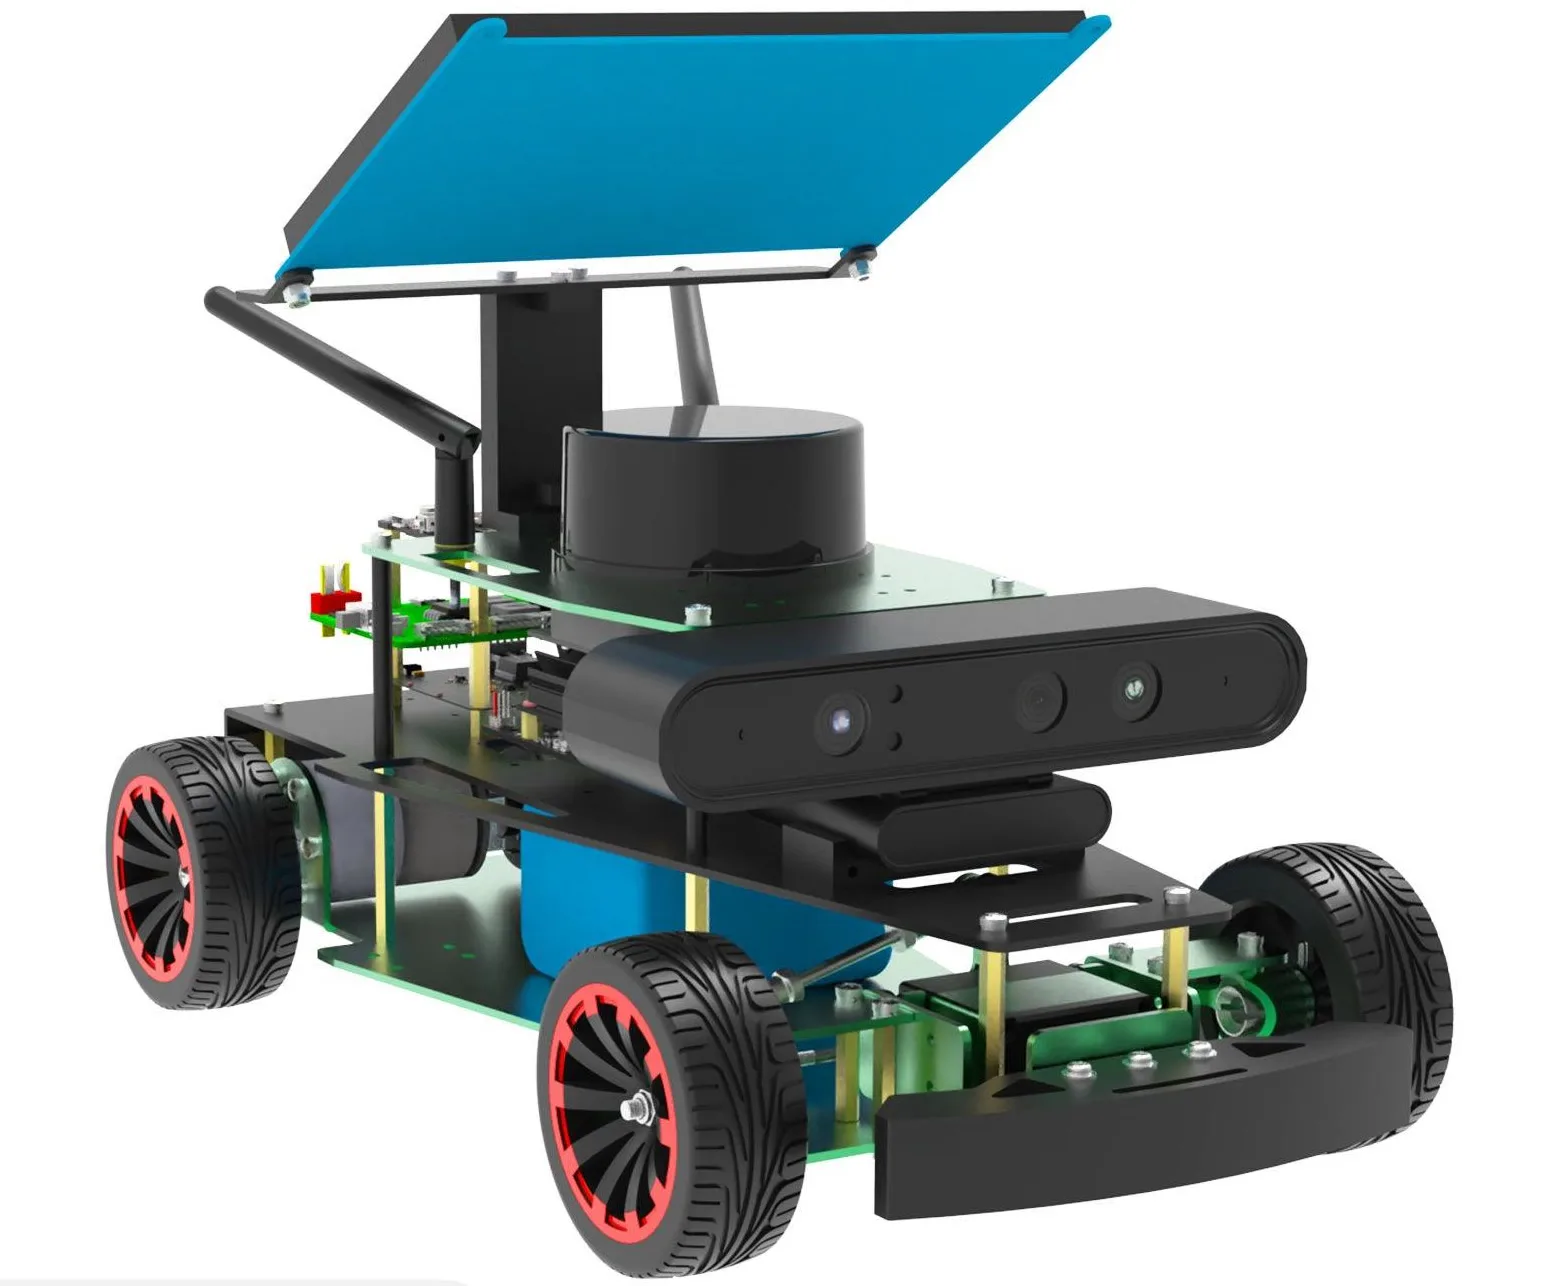
$655 – $2,375Yahboom store, October 2026. Every kit includes an Orbbec Astra Pro Plus depth camera. Standard (with RPLIDAR A1M8) $655 without a board (Pi 5 kit, cheapest version with a depth camera), $985 with Pi 5 8 GB (cheapest with a board), $1,015 with Jetson Nano 4 GB. Superior adds a 7-inch display, $765 to $825 without a board and $1,095 to $2,175 with one (Pi 5 up to Orin NX Super 16 GB). Ultimate adds a voice module and swaps in a YDLIDAR 4ROS lidar, $965 to $1,025 without a board and $1,295 to $2,375 with one. Orin boards are not offered on the Standard kit. Battery is included.
AvailableVia SSH / web / bridgeROS 2LidarDepth cameraAckermannPi 5
Weeks+Shipping: ~1–2 wks (est.). Ships from Yahboom in Shenzhen, China. Yahboom's shipping policy says orders are usually processed within 24 hours and shipped the next business day, most arrive within 6 working days after dispatch, and orders over $499 ship free by DHL, UPS or FedEx. Import duties and taxes are paid by the buyer. Yahboom ↗
Remote control: The Pi 5 version runs Raspberry Pi OS with ROS 1 Melodic or ROS 2 Foxy in Docker, the Jetson Nano runs ROS 1 Melodic with ROS 2 Foxy in Docker, and Orin boards run ROS 2 Humble on Ubuntu 22.04. A laptop connects over SSH, VNC or ROS networking for RViz.
Overview
Yahboom's older Ackermann rover, first sold in 2022 and updated with Pi 5 and Orin Super boards, and the only robot in this group with a published top speed (1.8 m/s). Every kit includes an Astra Pro Plus depth camera, and the course uses it for RTAB-Map and ORB-SLAM2 3D mapping. The Astra's 0.6 m minimum range is a limit for close following, and the Pi 5 and Jetson Nano images use ROS 2 Foxy, which is past end of life. It costs more than the newer ROSMASTER A1, which has a more current Humble course and LLM chapters.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2022 |
| Country | China |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Built-in LLM chat · Yahboom's R2 course adds LLM tutorials that run chat models such as DeepSeek-R1, Qwen2, Llama 3 and Phi-3 on the robot's board, but these are not tied to robot control. Voice commands use a separate command-word module on the Ultimate kit. Yahboom tutorials ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · The course has general ROS 1 and ROS 2 Gazebo lessons and a URDF chapter, and the store page shows RViz simulation control, but no R2-specific Gazebo world was confirmed. Yahboom tutorials ↗ |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Lidar, Depth camera, Camera |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Raspberry Pi, NVIDIA Jetson, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | 33.8×19.1×26 cm (unconfirmed, read from Yahboom's dimension drawing), 2.5 kg |
| Drive | Ackermann steering, 2 520 encoder metal motors and a 20 kg·cm metal steering servo, rubber racing tires |
| Compute | Raspberry Pi 5 8 GB, Jetson Nano 4 GB, Jetson Orin Nano Super 4/8 GB or Orin NX Super 8/16 GB, plus Yahboom's STM32 ROS expansion board |
| Vision | Orbbec Astra Pro Plus structured-light depth camera, 0.6–8 m, 1080p color |
| Lidar | SLAMTEC RPLIDAR A1M8 360° 0.15–12 m (Standard/Superior), YDLIDAR 4ROS ToF 0.05–30 m (Ultimate) |
| Sensors | 9-axis IMU, wheel encoders, OLED display, RGB tail light, buzzer, voice interaction module (Ultimate), 7-inch display (Superior/Ultimate) |
| Runtime | About 2 h with Pi 5, 1.5 h with Jetson Nano, 1 h with Orin boards (12.6 V 6,000 mAh battery) |
| Speed | 1.8 m/s max (published) |
| SDK | ROS 1 and ROS 2, Python, Gmapping and Cartographer SLAM (plus Hector, Karto and RRT exploration in ROS 1), navigation and obstacle avoidance, RTAB-Map 3D mapping and navigation, ORB-SLAM2 with Octomap, depth-camera color and KCF tracking, MediaPipe, YOLOv11 with TensorRT (Orin boards), voice control (Ultimate) |
Ratings & reviews
Ratings and reviews load on the live site.
Compared side by side
Similar robots
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3
Image credits
- Image 1: source (official product image, cropped)