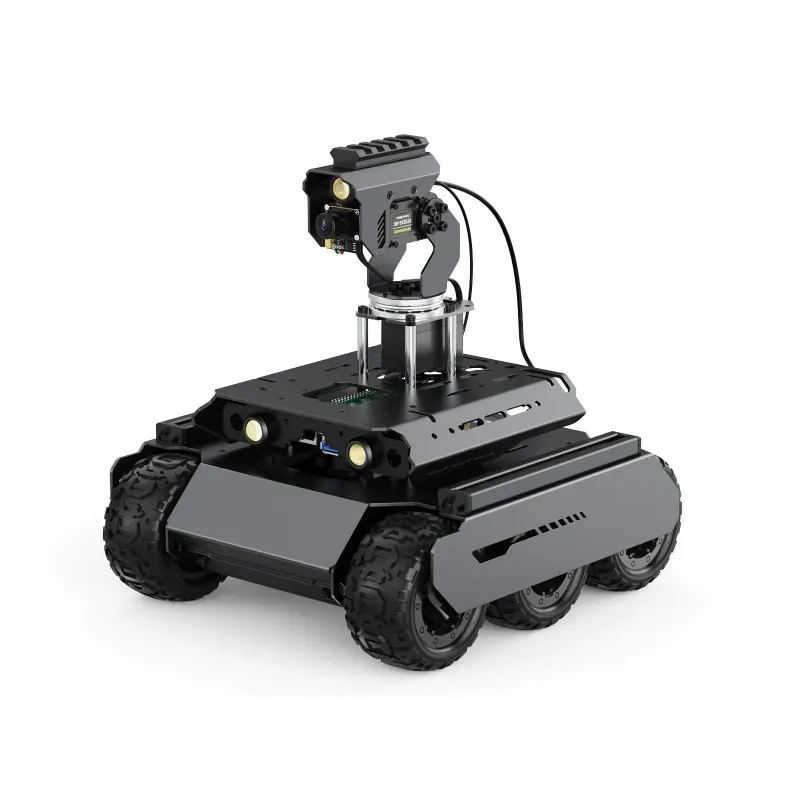
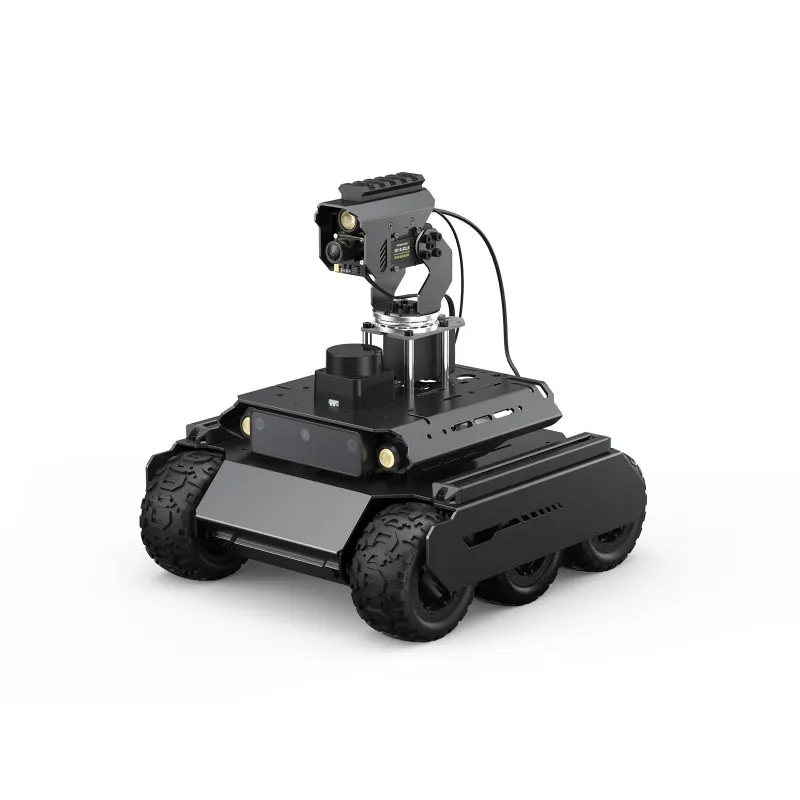
$245 – $727At Waveshare direct, AI kits are $245–487 (with/without Pi, pan-tilt); ROS 2 kit with D500 lidar + OAK-D Lite depth $535–727; Jetson Orin kits $340–1,071. Amazon listings vary ($293–614 for the pan-tilt Pi 5 kit). 3×18650 cells not included
AvailablePython from a laptopJSON API from laptopPan-tilt camCarpet-capableAssembledLidar kit option
≤ 1 weekShipping: 1–3 days (Prime) · 1–2 wks direct. The pan-tilt Pi 5 4 GB kit was Prime on Amazon Sept 24 (2-day, "only 2 left"). Waveshare direct ships from Shenzhen by DHL/FedEx (~3–8 working days + duties; warehouse closed Sept 25–27). Buy 3×18650 cells separately. Amazon ↗
Remote control: From Python on a laptop, connect a
python-socketio client to http://<pi>:5000 and emit JSON like {"T":1,"L":0.2,"R":0.2} on the json event; read MJPEG frames from /video_feed. No ROS needed (ROS 2 runs on the Pi in Docker for later use).Overview
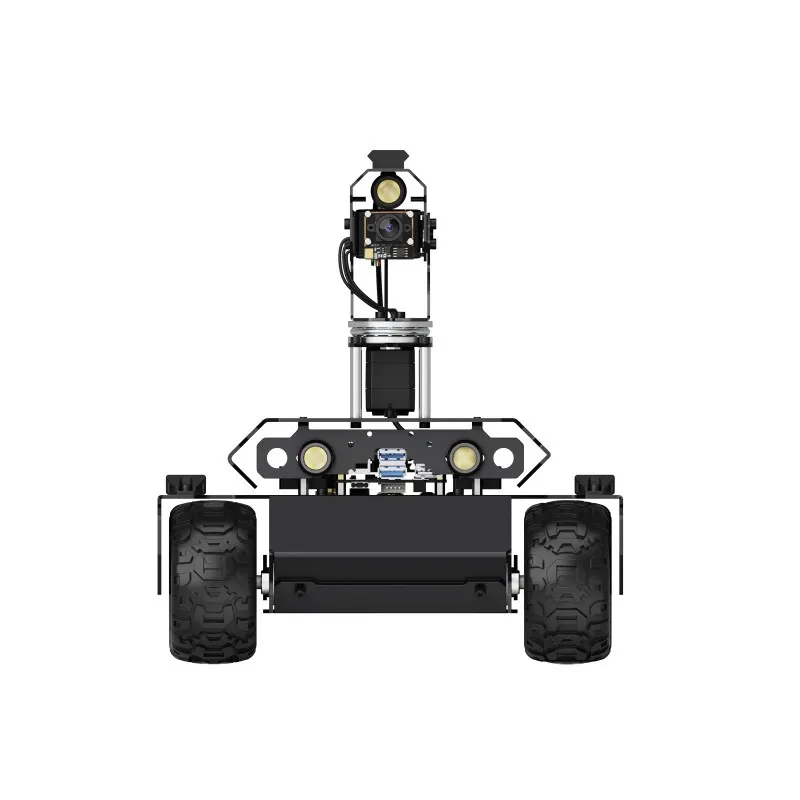
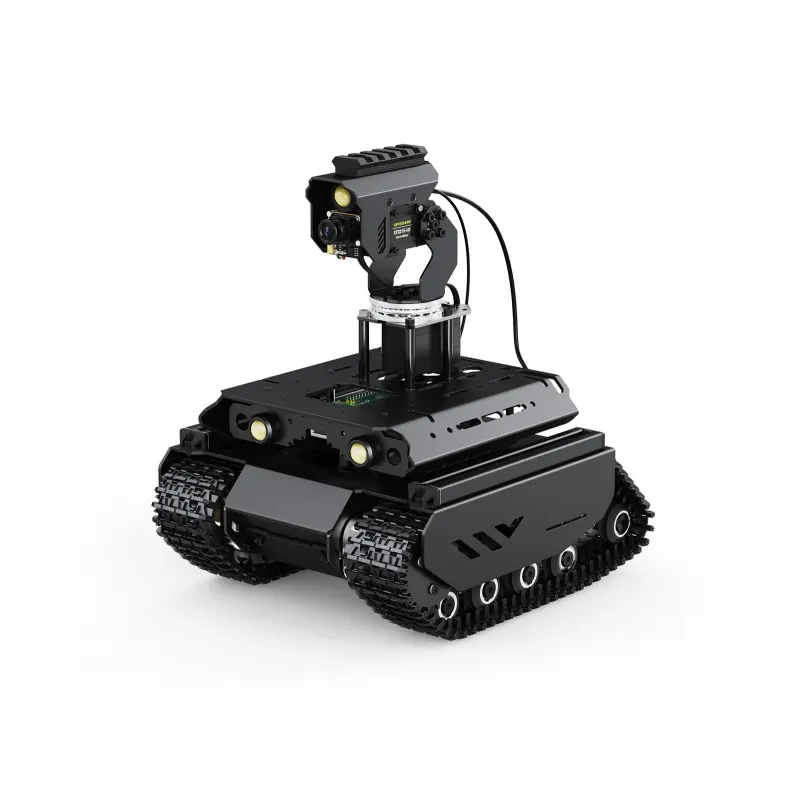
A solid, cheap, pre-assembled metal rover that handles carpet and thresholds far better than omni-wheel kits, and the ROS 2 kit adds lidar and depth for real mapping for under $750. Its stock web app already exposes a Socket.IO JSON API and an MJPEG stream, so an LLM agent loop on a laptop is a few dozen lines of Python. It's fast and fairly loud on hard floors, it doesn't dock itself, and the 18650 cells are sold separately. No arm, and the docs are functional but rough.
Overall top pick for this use case. It is assembled, carpet-capable and drivable from laptop Python with plain JSON, with a lidar/depth upgrade path, and some kits arrive in days via Prime.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2024 |
| Availability | Available |
| Programmability | Full SDK |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Camera, Depth camera, Lidar |
| Actuators | DC / gear motors |
| Audio | Speaker, Microphone |
| Compute type | Raspberry Pi, Arduino / ESP32 / microcontroller, NVIDIA Jetson |
| Remote control | Python from a laptop |
| Size | 23×25×26 cm, 2.2 kg |
| Drive | 6-wheel / 4WD skid-steer, rubber tires, metal body |
| Compute | Raspberry Pi 5 (or 4B; Jetson variant exists) + ESP32 motor controller |
| Vision | 5 MP 160° cam on pan-tilt; OAK-D Lite stereo depth in ROS 2 kit |
| Lidar | Optional D500 360° 2D (included in ROS 2 kit) |
| Sensors | 9-axis IMU, battery monitor, speaker + mic, LEDs, GPIO |
| Runtime | Not published (3S 18650 UPS; the bare UGV02 chassis is rated 45 min at full power) |
| Speed | 1.3 m/s |
| SDK | Open-source ugv_rpi (Python, Flask, OpenCV/MediaPipe), ESP32 JSON firmware, ROS 2 Humble with SLAM / Nav2 |
Ratings & reviews
Ratings and reviews load on the live site.
 MARS (Builders Edition)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3
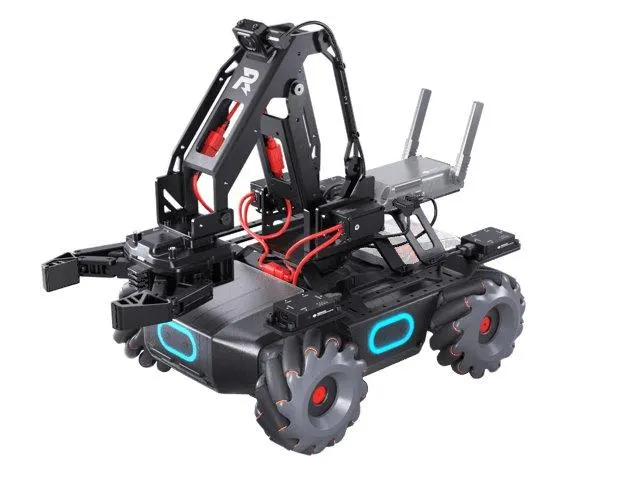 RoboMaster EP Core