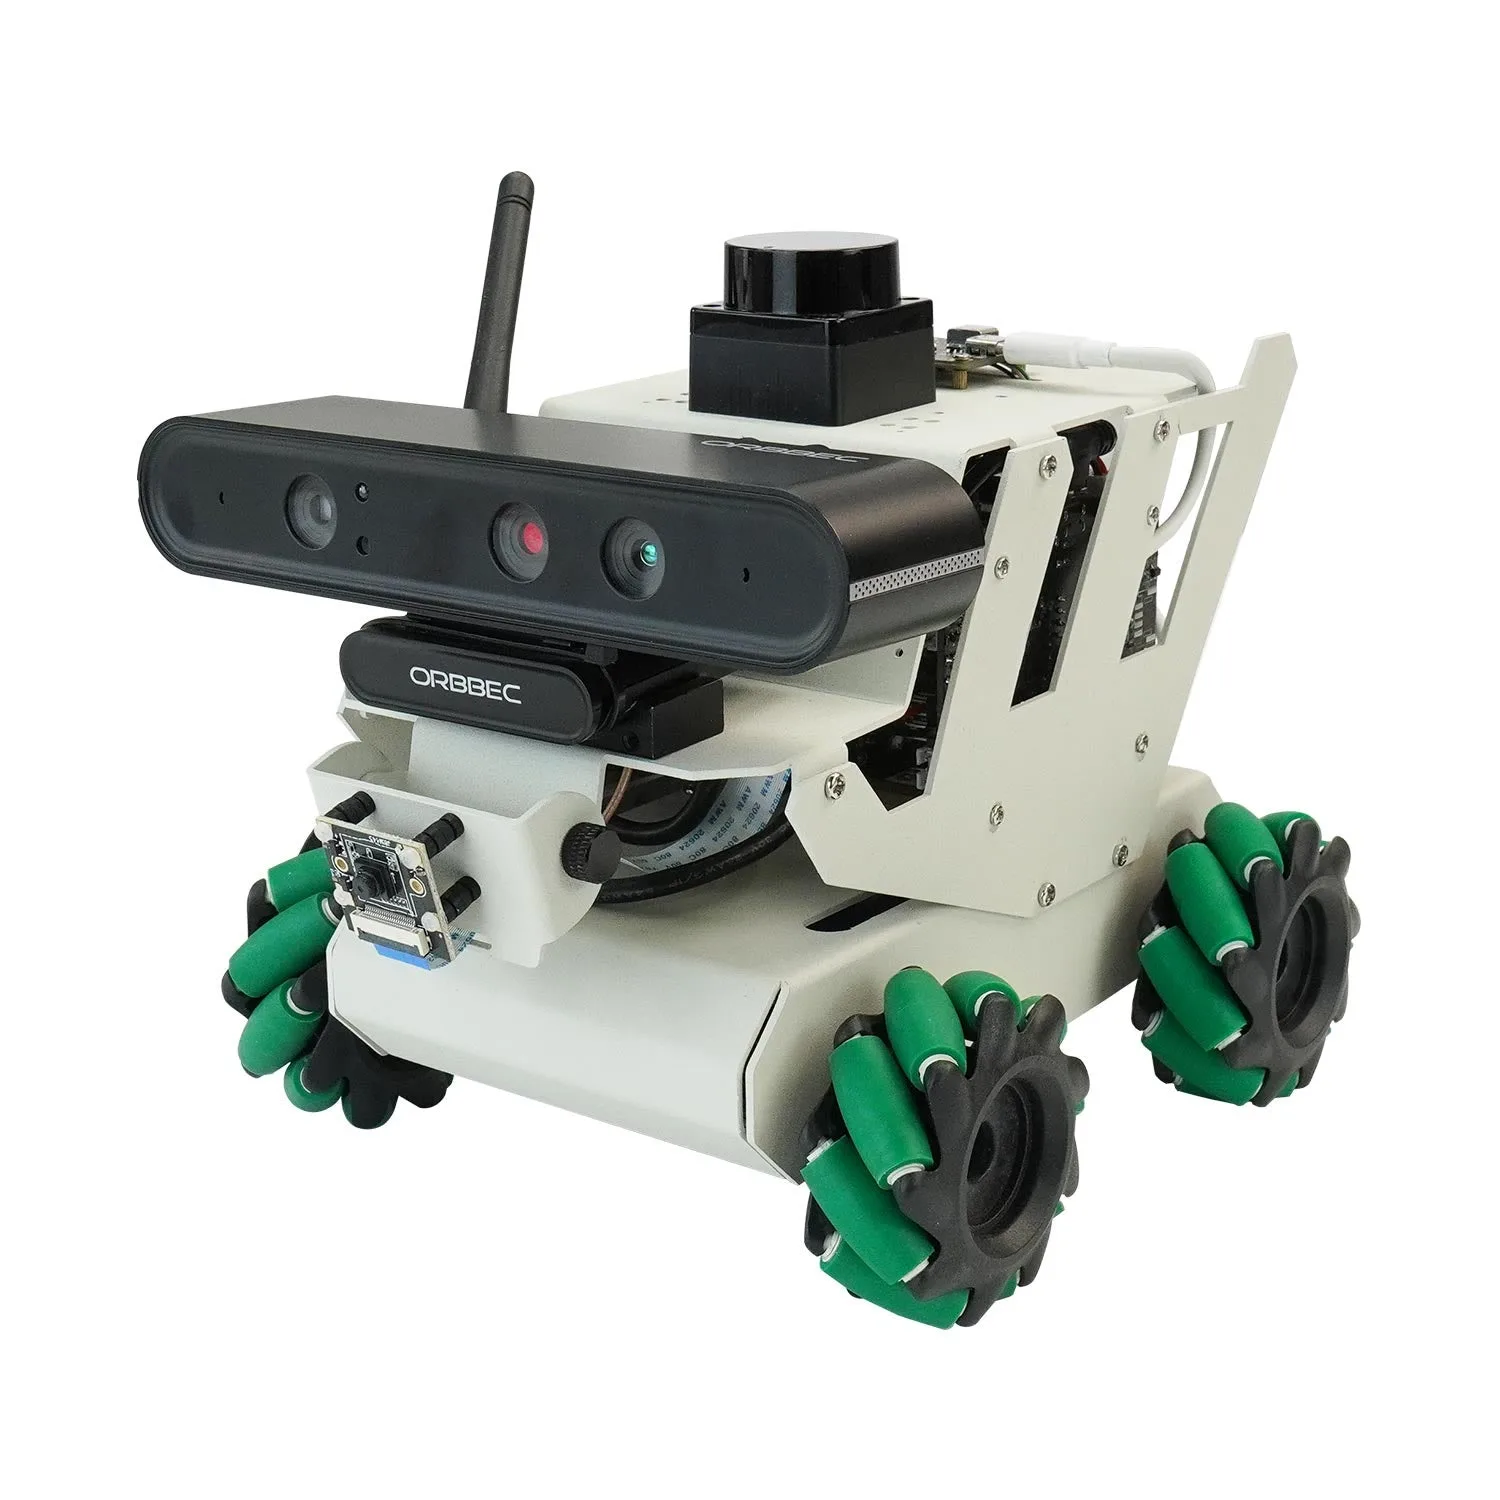
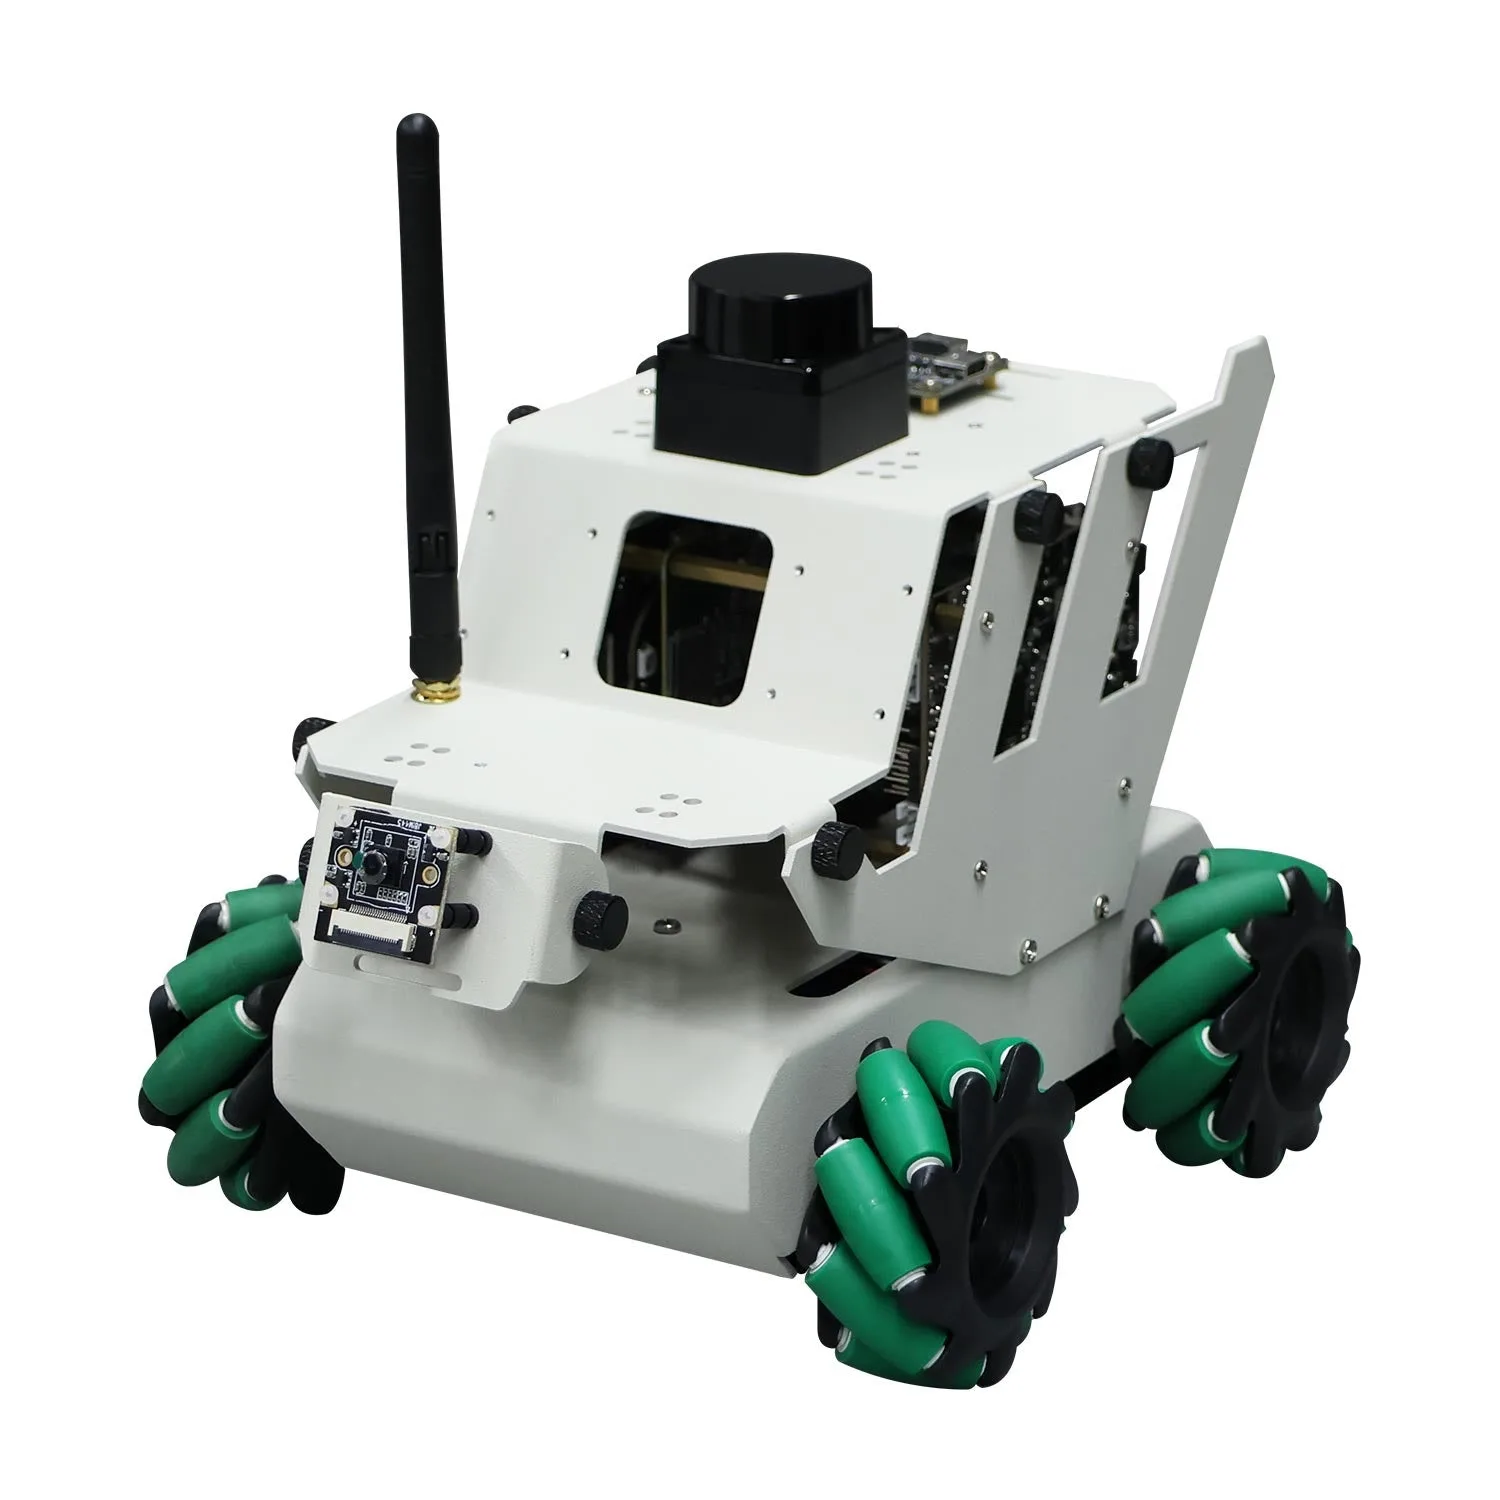
$359 – $519Yahboom store, October 2026. Standard Kit $359 with RDK X3 4 GB or $419 with RDK X5 8 GB (8 MP MIPI camera and MS200 lidar, no depth camera). Advanced Kit adds an Orbbec Astra Pro Plus depth camera, $459 with RDK X3 4 GB (cheapest version with a depth camera) or $519 with RDK X5 8 GB. Every kit includes the board, a 64 GB TF card, battery, charger and wireless controller. An Amazon US listing for the Advanced RDK X3 kit appears in search results (price unconfirmed).
AvailableVia SSH / web / bridgeROS 2LidarDepth cameraMecanum wheelsRDK X3Kit
Weeks+Shipping: ~1–2 wks (est.). Ships from Yahboom in Shenzhen, China. Yahboom's shipping policy says orders are usually processed within 24 hours and shipped the next business day, most arrive within 6 working days after dispatch, and orders over $499 ship free by DHL, UPS or FedEx. Import duties and taxes are paid by the buyer. An Amazon US listing for the Advanced RDK X3 kit shows up in search results, but its price and Prime status were not confirmed. Yahboom ↗
Remote control: ROS 2 runs on the robot's board (Foxy on Ubuntu 20.04 for RDK X3, Humble on Ubuntu 22.04 for RDK X5). A laptop connects over SSH, VNC, Jupyter Lab or ROS 2 networking, and Yahboom supplies a virtual machine image for the PC side.
Overview
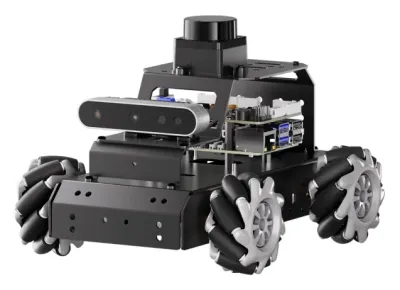
A compact aluminum mecanum rover built around D-Robotics RDK boards instead of a Raspberry Pi or Jetson, and the lowest-priced Yahboom robot in this group with both lidar and a depth camera. The Advanced Kit adds an Orbbec Astra Pro Plus camera, and the course uses it for RTAB-Map 3D mapping and distance-keeping tracking. The RDK X3 version runs the older ROS 2 Foxy, so the RDK X5 version on Humble is the better match for current packages. There are no LLM or voice features, and it comes as a kit to assemble.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2023 |
| Country | China |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Possible via SDK · Yahboom's RDK X3 Robot course has no LLM chapters. The ROS 2 topics, Python driver library and Jupyter Lab examples are open, so an LLM agent could be connected with custom code. Yahboom tutorials ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · The course has a general ROS 2 Gazebo lesson and a URDF model chapter, but no robot-specific Gazebo simulation was confirmed. Yahboom says a 3D model is provided with the car. Yahboom tutorials ↗ |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Lidar, Depth camera, Camera |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Other ARM chip, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | 23.6×18.1×18.5 cm, 1.93 kg |
| Drive | 4 mecanum wheels (65 mm), 4 MD310 geared motors with Hall encoders (1:20) |
| Compute | D-Robotics RDK X3 4 GB (5 TOPS) or RDK X5 8 GB (10 TOPS), plus Yahboom's STM32 ROS expansion board V3.0 |
| Vision | 8 MP Sony IMX219 MIPI camera (all kits), Orbbec Astra Pro Plus structured-light depth camera 0.6–8 m (Advanced Kit) |
| Lidar | Oradar MS200 360° 2D ToF lidar, 0.03–12 m |
| Sensors | 9-axis IMU on the expansion board, wheel encoders, OLED status display, buzzer |
| Runtime | About 3.5 h (7.4 V 6,600 mAh battery) |
| Speed | Not published |
| SDK | ROS 2 with TogetherROS, Python and Jupyter Lab, OpenCV, Gmapping and Cartographer SLAM, Navigation2 single- and multi-point navigation, RTAB-Map 3D mapping and navigation with the depth camera, depth-based color tracking and KCF object tracking, deep-learning object detection (80 classes), gesture control and human tracking |
Ratings & reviews
Ratings and reviews load on the live site.
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3