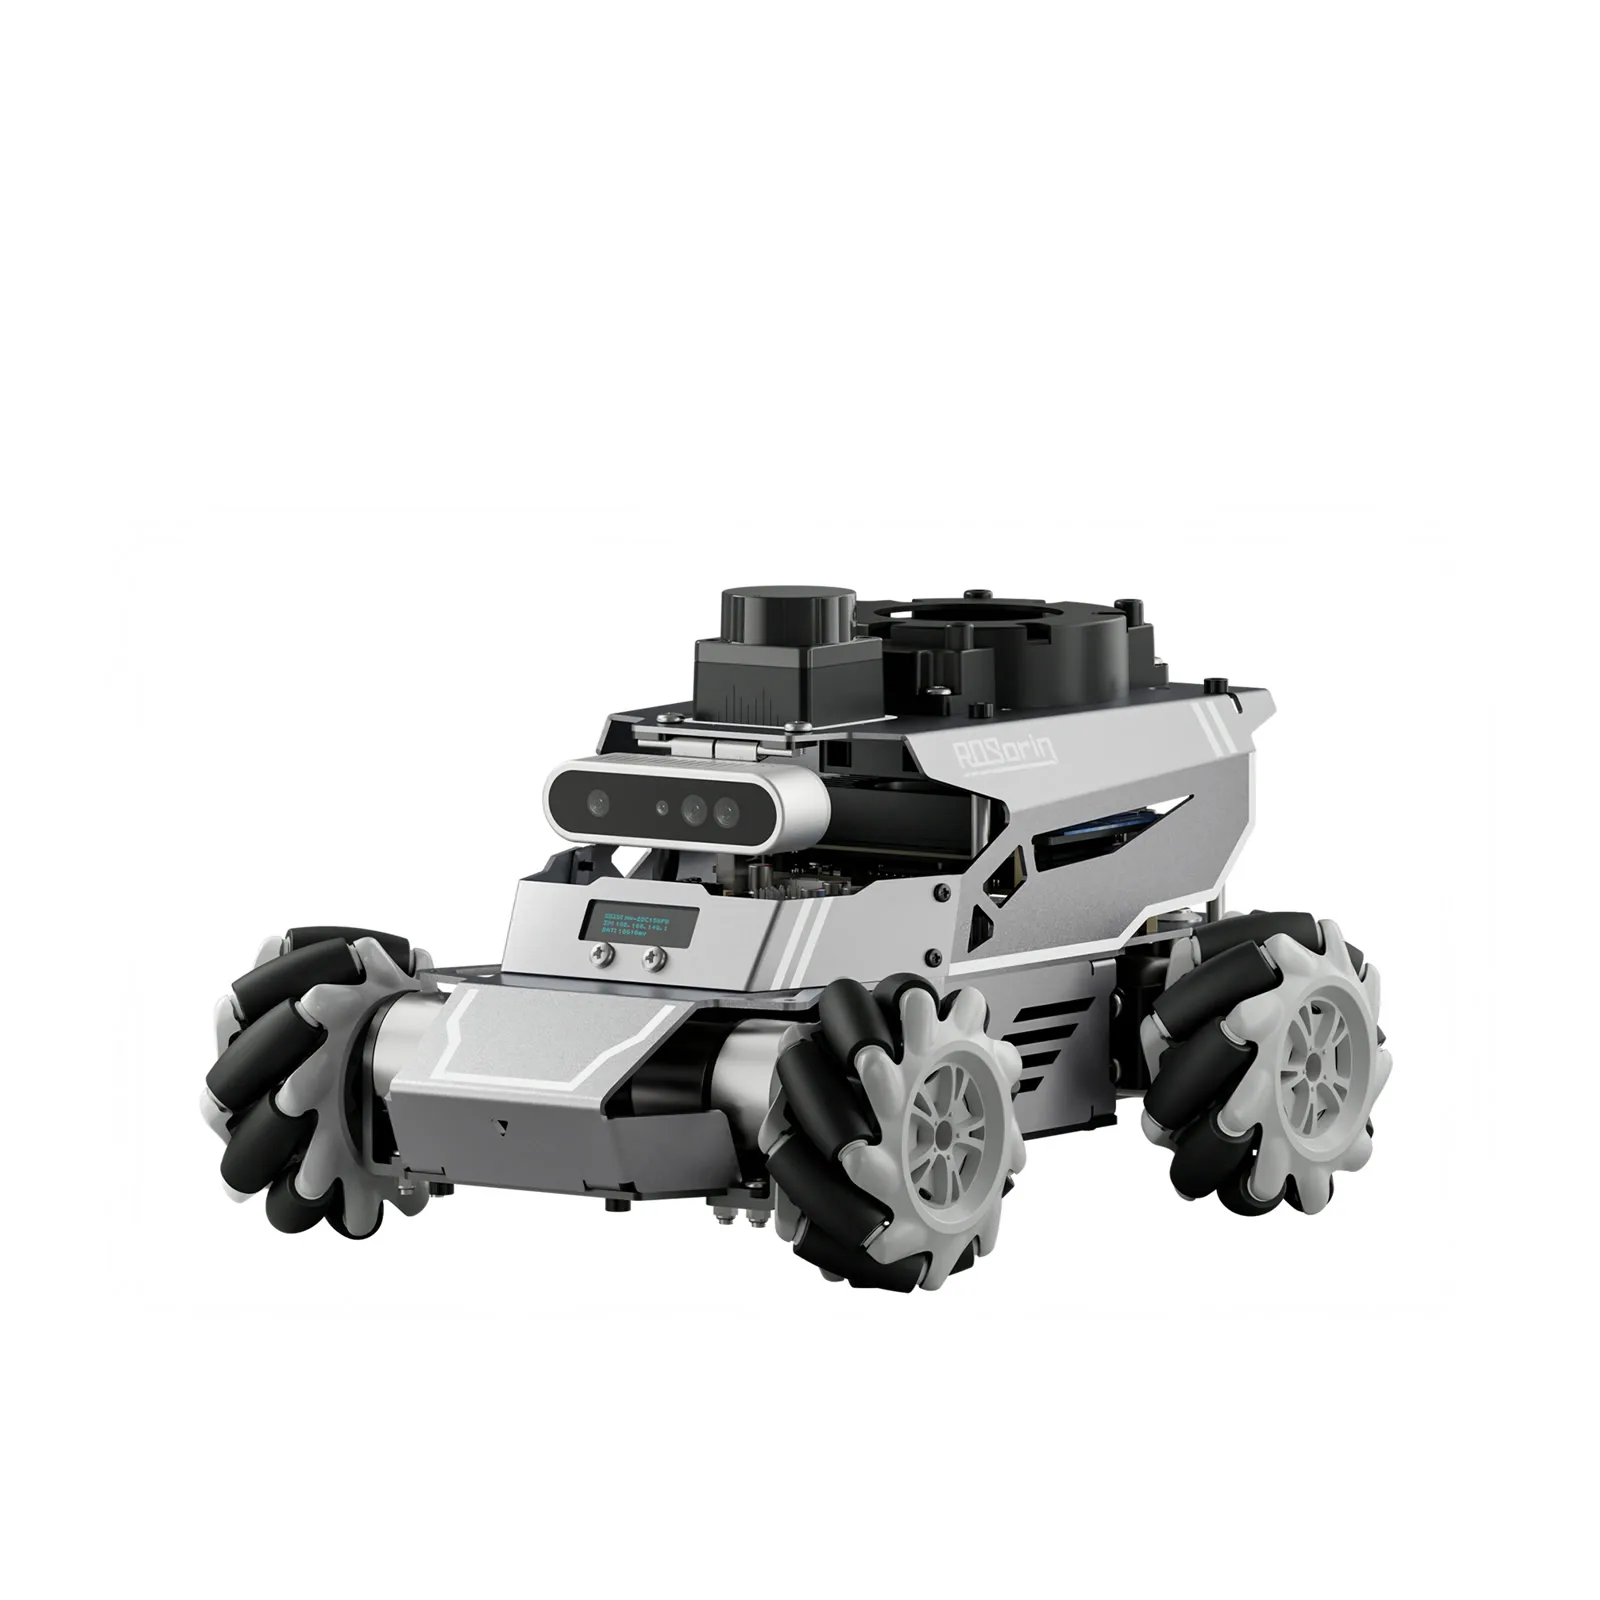
$299.99 – $1,499.99Hiwonder store, October 2026. Chassis is not a separate option. Starter and Standard ship with the mecanum chassis only, while Advanced and Ultimate add a 3-in-1 chassis pack for Ackermann and 4-wheel differential drive. Starter (monocular camera) $299.99 without a board to $1,199.99 with an Orin NX Super 8 GB. Standard adds the Aurora930 Pro depth camera, $429.99 without a board, $619.99 / $719.99 with a Pi 5 4 / 8 GB, $789.99 Jetson Nano 4 GB, $929.99 / $1,029.99 Orin Nano Super 4 / 8 GB, $1,329.99 Orin NX Super 8 GB. Advanced (all three chassis) is $100 more at each step, $529.99 to $1,429.99. Ultimate swaps the voice box for a 6-mic array, $599.99 to $1,499.99. The cheapest version with a depth camera is Standard with a Pi 5 4 GB at $619.99 (mecanum only), and the cheapest with depth and all three chassis is Advanced with a Pi 5 4 GB at $719.99. Amazon US (sold by Hiwonder-US) lists Standard without a controller at $479.99 and Advanced without a controller at $579.99.
AvailableVia SSH / web / bridgeROS 2LidarDepth cameraMecanum wheelsAckermannJetson
≤ 1 weekShipping: ~1 wk (est.). Amazon US lists it sold by Hiwonder-US and shipped from Amazon, with delivery in about a week. Hiwonder's shipping policy says orders are usually processed within 24 hours and shipped the next business day, and the store offers free shipping over $499. The ship-from location for store orders is not stated (China, unconfirmed). Amazon ↗
Remote control: ROS 2 Humble runs on the robot's board. Orin versions run Ubuntu 22.04 with Humble, while the Jetson Nano runs Ubuntu 18.04 with ROS Melodic and Humble in Docker. Remote access through VNC and a virtual machine on a PC.
Overview
A mid-size Hiwonder rover whose chassis converts between mecanum, Ackermann and differential drive, though the Ackermann and differential parts only come with the Advanced and Ultimate kits. It takes either a Raspberry Pi 5 or a range of Jetson boards, and every kit from Standard up pairs a depth camera with a TOF lidar. The course covers slam_toolbox, Nav2, RTAB-Map 3D mapping and Gazebo simulation, which suits university and maker use. Speed and runtime are not published, and the store and manual name different lidar models.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2025 |
| Country | China |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Official LLM tools · ROSOrin's Large AI Model Courses cover LLM, speech and vision language models through OpenAI or OpenRouter APIs, voice control, vision tracking and voice-driven multi-point navigation, plus offline large-model lessons. The store page also advertises OpenClaw agent integration. Hiwonder ROSOrin tutorials ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | Official model · Hiwonder's ROSOrin course has a Gazebo chapter with a virtual machine image, URDF model, and Gazebo mapping and navigation simulation. Hiwonder ROSOrin tutorials ↗ |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Lidar, Depth camera, Camera |
| Actuators | DC / gear motors |
| Audio | Speaker, Microphone |
| Compute type | Raspberry Pi, NVIDIA Jetson, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | Mecanum 27.7×21.2×16.6 cm, 2.66 kg. Ackermann 27.7×20.4×16.9 cm, 2.15 kg. Differential 27.7×20.4×16.6 cm, 2.26 kg |
| Drive | Modular chassis with swing-arm suspension, mecanum wheels by default, Ackermann (LD-1501MG steering servo) or 4-wheel differential with the 3-in-1 pack, 520 metal-gear motors with AB quadrature encoders |
| Compute | Raspberry Pi 5 4 or 8 GB, Jetson Nano 4 GB, Jetson Orin Nano Super 4 or 8 GB, Jetson Orin NX Super 8 GB, or none, plus an STM32 controller board |
| Vision | Aurora930 Pro structured-light depth camera, 0.15–3 m, 640×400 depth and RGB at 12 fps (Standard and up). Starter has a monocular camera |
| Lidar | STL-19P D500 TOF lidar per the store page (the online manual describes an MS200 with a 12 m radius, so range is unconfirmed for the STL-19P) |
| Sensors | IMU on the expansion board, encoders, lidar, depth camera, WonderEcho Pro AI voice box (Starter to Advanced) or 6-mic far-field array (Ultimate), speaker |
| Runtime | Not published (11.1 V 6,000 mAh battery) |
| Speed | Not published |
| SDK | ROS 2 Humble (ROS 1 Melodic on Jetson Nano), Python, C/C++, OpenCV, MediaPipe and YOLOv11 lessons with TensorRT on Jetson (the store page mentions YOLO26), slam_toolbox mapping, Nav2 navigation with AMCL, DWA and TEB, RTAB-Map 3D mapping and navigation with the depth camera, lidar obstacle avoidance and following, autonomous driving, Gazebo simulation, large AI model and voice lessons |
Ratings & reviews
Ratings and reviews load on the live site.
Compared side by side
Similar robots
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3
Image credits
- Image 1: source (official product image)