The custom servos, control board and plates come from MangDang, mostly only as a kit.
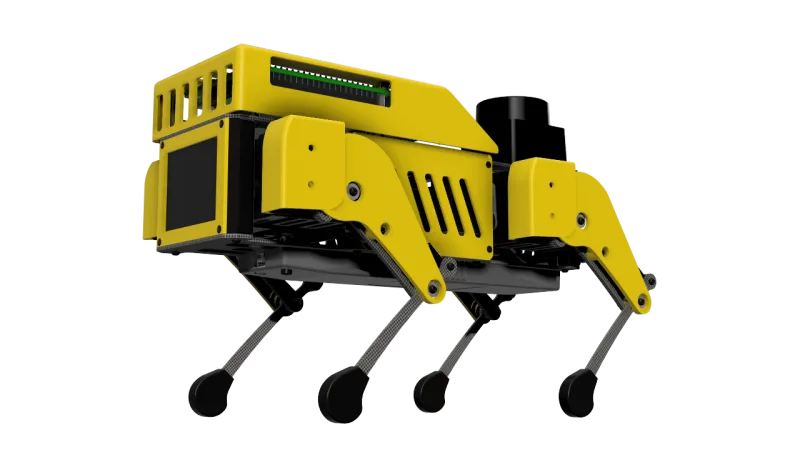
Mini Pupper is a small 12-servo Raspberry Pi robot dog from MangDang, derived from the Stanford Pupper and sold mainly as a kit. Its software is open, including ROS and ROS 2 stacks with SLAM and navigation. MangDang also shares the parts list, STL files and board schematics for the first version, though these come with no license.
At a glance
| Parts cost | $760 project · Stated by the project as a parts list total of $755.71 for the original Mini Pupper. The custom servos are sold separately, but the control board, LCD board and carbon-fiber plates are not, so in practice it is built from the $649 kit source ↗ |
|---|---|
| Difficulty | 2/5 Easy · Kit assembly with guides and videos, but a full scratch build depends on MangDang's custom servos and board. |
| Build time | Not stated |
| Tools needed | 3D printer (only if printing the older body parts), small screwdrivers |
| Motors | 12 MangDang custom servos |
| Controller | Raspberry Pi with MangDang custom board |
| Sensors | Optional lidar and OAK-D-Lite camera |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✗ Wiring✓ Software✓ Video ReadTheDocs site + Google Drive (STL, parts list, schematics) + Fusion 360 share + YouTube; Discord |
| Activity | Last update 2026-08-26 · 1,162 GitHub stars · Discord and Facebook group; QuadrupedRobot repo 1,162 stars |
| Kits | Commercial kits from MangDang (Mini Pupper, Mini Pupper 2) |
Licenses
No license is stated for the design files. They are published for building, but without a license the right to copy, modify or redistribute them is not granted.
| Design files | None found (STL, parts list and schematics shared via Google Drive without a license) source ↗ |
|---|---|
| Code | MIT (QuadrupedRobot); Apache-2.0 (mini_pupper, mini_pupper_ros, mini_pupper_2_bsp) source ↗ |
| Documentation | None found for the docs site (MiniPupperDocs repo has no LICENSE); the org profile repo with product images is CC BY 4.0 source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- The servos are MangDang's own design rather than a standard hobby part. The spec sheet was only shared after the crowdfunding campaign, so substitutes must match its size and torque. source ↗
- Kit buyers have reported parts such as body bushings missing from the parts list with no specs given, which makes sourcing them independently hard. source ↗
- The body and hip parts moved from 3D-printed to molded plastic for kits after April 2022, so the shared STLs reflect the older printed design. source ↗
- Owners of the first-generation robot reported that the linked software image folder only held images for Mini Pupper 2 and later. source ↗
- A long thread on one leg servo not moving traced back in some cases to a dead servo channel, worked around by moving it to a spare pin. source ↗
Other quadrupeds plans
- Kame32 (MiniKame successor) · $90–$100 · difficulty 2/5
- Stanford Pupper (servo version) · $900–$1,000 (2024) · difficulty 3/5
- Spot Micro (SpotMicroAI) · $420–$510 · difficulty 3/5
- SpotMicroESP32 Leika · $230–$600 · difficulty 3/5
- Pupper v3 · $2,000 · difficulty 4/5
- ODRI Solo 12 · $7,100 (2022) · difficulty 5/5
- Dingo Quadruped · $900 · difficulty 3/5
- Stanford Pupper v2.1 (DJI motor version) · $1,600 (2023) · difficulty 4/5
- openDog V3 · $2,800–$3,400 (2023) · difficulty 4/5