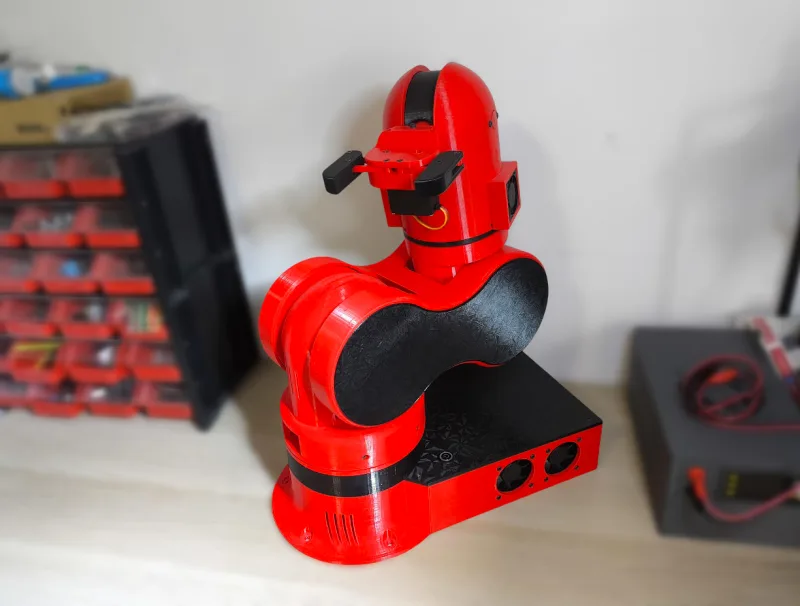
Thor is a fully 3D-printed 6-axis robotic arm by Ángel Larrañaga Muro, with a joint layout like an industrial manipulator and a reach of about 625 mm. It uses stepper motors with printed gears, belts and pulleys, and is controlled with G-code through GRBL or RepRapFirmware, with ROS 2 support. It was designed entirely in open tools such as FreeCAD and KiCad.
At a glance
| Parts cost | $390 project · Stated by the project as about 350 EUR in components, excluding the 3D printer source ↗ |
|---|---|
| Difficulty | 4/5 Advanced · Around 200 h of printing, many gears and belts, and a self-built control PCB unless a third-party board is used. |
| Build time | About 200 hours of printing plus about 10 hours of assembly once the steps are known; the FAQ says several weeks or months overall source ↗ |
| Tools needed | 3D printer with at least 200x200 mm bed (about 3-4 kg PLA/PETG + 0.5 kg ABS, ~200 h), soldering (SMD and through-hole if building Thor ControlPCB), PCB fabrication order (or a commercial Fly Super8Pro board instead) |
| Motors | 7 Nema 17 stepper motors (some with 5:1 printed reduction), MG995 servo for the gripper |
| Controller | Arduino Mega + custom Thor ControlPCB with 8x A4988 drivers, or a Fly Super8Pro board running RepRapFirmware |
| Sensors | 4 optical endstops + 1 micro endstop for homing |
| Published | ✓ Parts list✓ CAD/STL✓ Assembly guide✓ Wiring✓ Software✓ Video Project website (parts list, print guide, assembly videos and interactive instructions, electronics, firmware) + GitHub + forum + Discord |
| Activity | Last update 2025-05-09 · 1,603 GitHub stars · Project forum and Discord, 274 forks, world map of builds on the site |
| Kits | No regular kit; the FAQ points to one printing service for a quote and says no electronics kits are known |
Licenses
| Design files | CC BY-SA 4.0 (FreeCAD, STEP and STL files) source ↗ |
|---|---|
| Code | CC BY-SA 4.0 (Asgard control software and Thor-ROS repos) source ↗ |
| Documentation | CC BY-SA 4.0 (FAQ states all project files are under this license) source ↗ |
Builder notes
Practical points from the project's issue tracker, forum and docs, each linked to its source.
- Early builds had steppers overheating enough to deform printed gears. The design was revised to allow airflow and 40 mm fans, and heat-resistant gear materials help. source ↗
- GT2 pulleys from different sellers use different set-screw sizes, so the holes in the printed gears may not line up and the model or the pulley choice needs adjusting. source ↗
- The custom ControlPCB is not sold in shops, and PCB fabs have minimum order quantities. The electronics page documents the commercial Fly Super8Pro board as an alternative, and two Uno CNC shields can also work. source ↗
- One builder reported the articulation 2 gears slipping after use due to flex at the joint, with no confirmed fix in the thread. source ↗
Other arms plans
- MeArm · $40 · difficulty 1/5
- SO-101 arm · $230 · difficulty 2/5
- EEZYbotARM MK2 · $100 (2018) · difficulty 2/5
- GELLO teleoperation arms · $280 (2023) · difficulty 2/5
- reBot-DevArm (Seeed Studio) · $1,500 · difficulty 4/5
- OpenArm · $6,500 · difficulty 5/5
- Koch v1.1 arm · $480 (2024) · difficulty 2/5
- ROBOTIS OpenMANIPULATOR-X · $1,600 · difficulty 2/5
- BCN3D Moveo · $430 · difficulty 4/5
- PAROL6 · $970 · difficulty 4/5
- Faze4 robotic arm · $1,000–$1,500 (2020) · difficulty 4/5