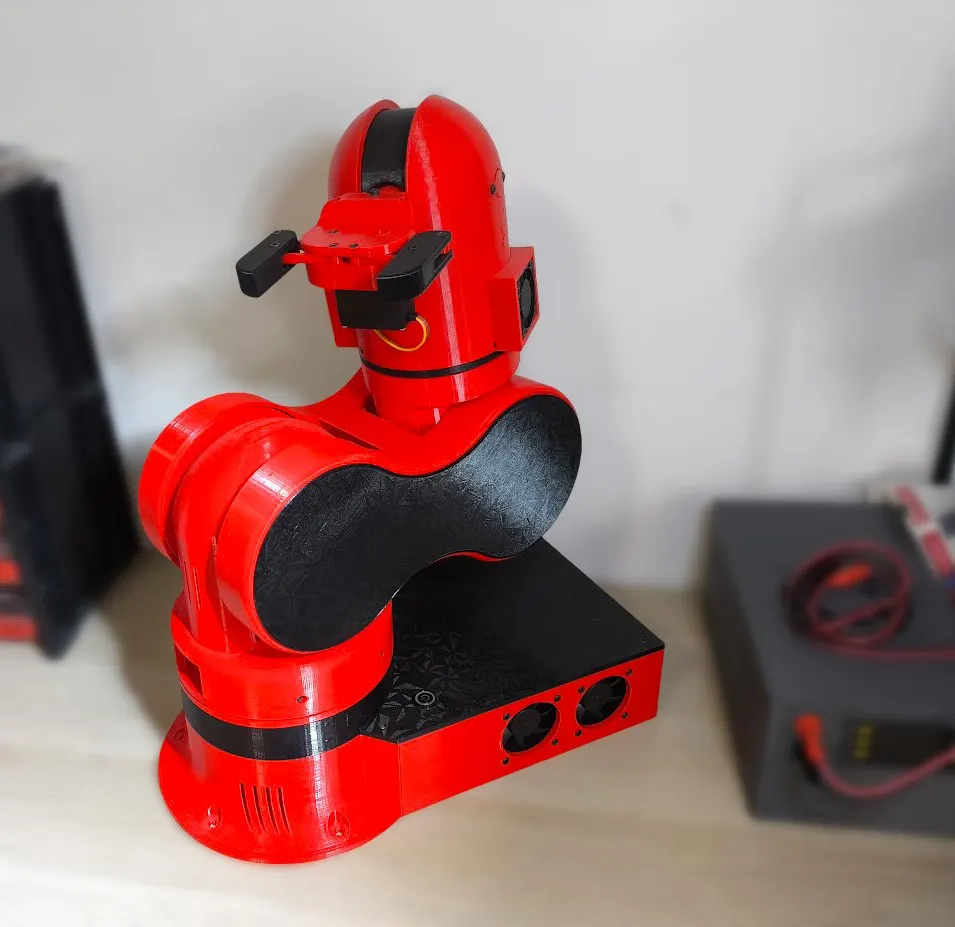
DIY, < €350 partsProject's own estimate of hardware cost; no official kit.
AvailableVia SSH / web / bridge3D printedCC BY-SA 4.0G-codeROS 2
Weeks+Shipping: DIY build. No commercial kit; parts are printed and sourced from the project's bill of materials.
Remote control: Streams G-code over USB serial (any Python serial script works) or runs through the Thor-ROS ROS 2 / MoveIt 2 packages.
Overview
One of the longest-running open-source 3D-printed 6-DOF arms, started in 2015 as a university final-degree project and developed publicly since (the GitHub repository dates from 2015). It uses an industrial wrist layout and is driven by G-code like a 3D printer, which keeps electronics cheap but limits it to open-loop steppers.
Specifications
| Category | Robot arms · Desktop & hobby arms |
|---|---|
| Released | 2015 |
| Availability | Available |
| Programmability | Open source (hardware + software) |
| Best for | Ages 16+ (estimated) |
| Vision sensors | No vision sensors |
| Actuators | Stepper motors |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| DOF | 6 (yaw-roll-roll-yaw-roll-yaw) |
| Reach | Not published (625 mm tall stretched) |
| Payload | 750 g max (incl. end effector) |
| Repeatability | Not published |
| Weight | Not published |
| Controller | Arduino Mega + custom shield (ThorControlPCB) or commercial 3D-printer boards running GRBL or RepRapFirmware |
| Sensors | Endstops for homing (BOM lists four optical endstops and one micro endstop) |
| SDK | G-code over serial; Asgard control GUI; ROS 2 + MoveIt 2 packages |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 SO-101 (SO-ARM101)TheRobotStudio × Hugging Face (open source)~$230 DIY parts (pair); kits $199 – $419
 SO-100 (SO-ARM100)TheRobotStudio × Hugging Face (open source)~$232 DIY parts (pair)
 Koch v1.1 Low-Cost Robot ArmAlexander Koch (original); v1.1 by Jess Moss (open source)~$477 DIY parts (pair)
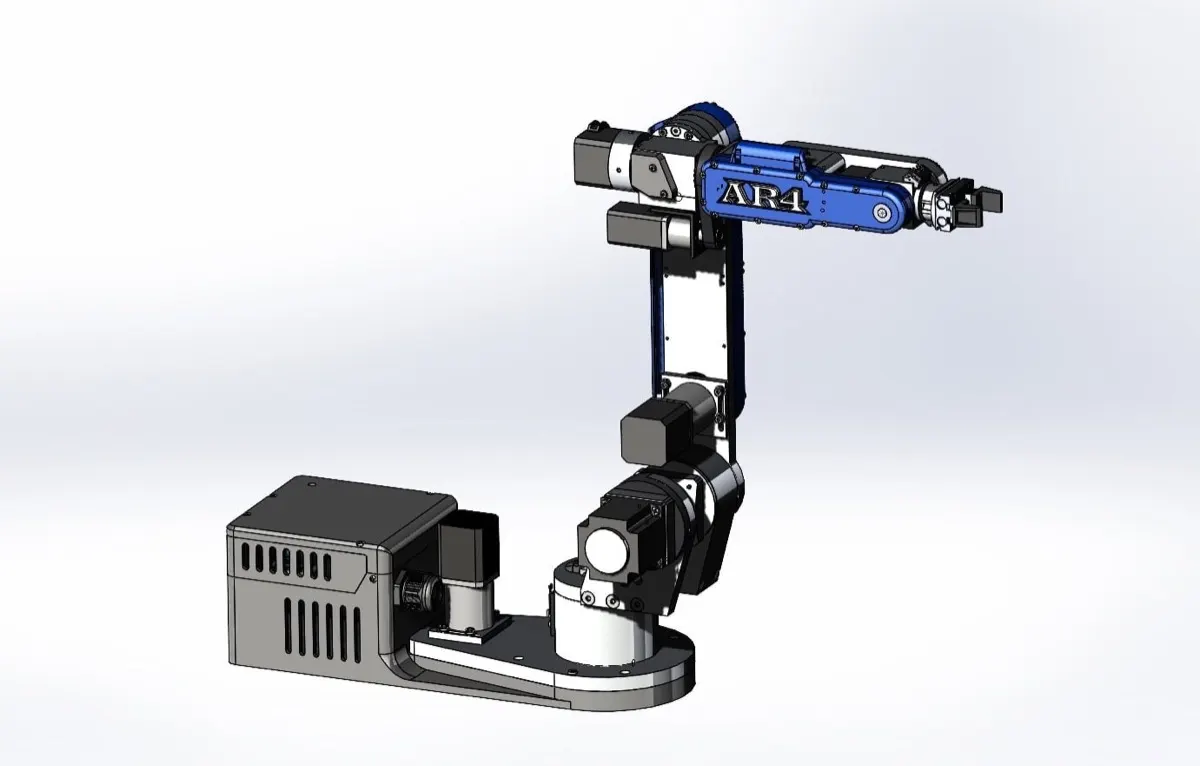 Annin Robotics AR4Annin Robotics (USA)$1,189 kit + motors/drivers
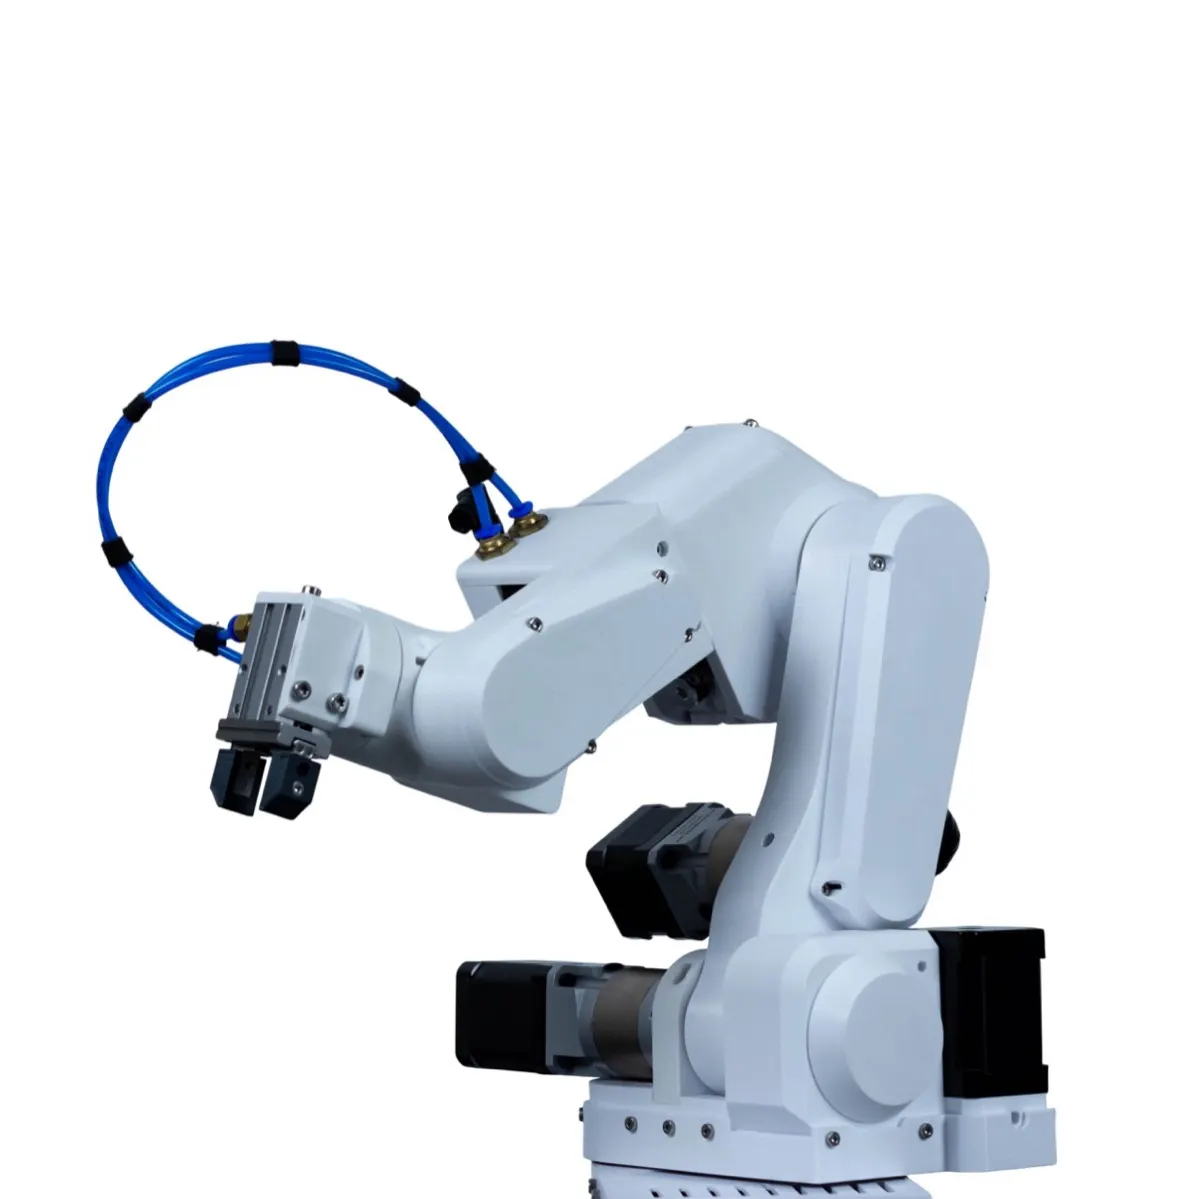 PAROL6Source Robotics (Croatia)~$2,500 kit / ~$3,800 assembled (est. from €)
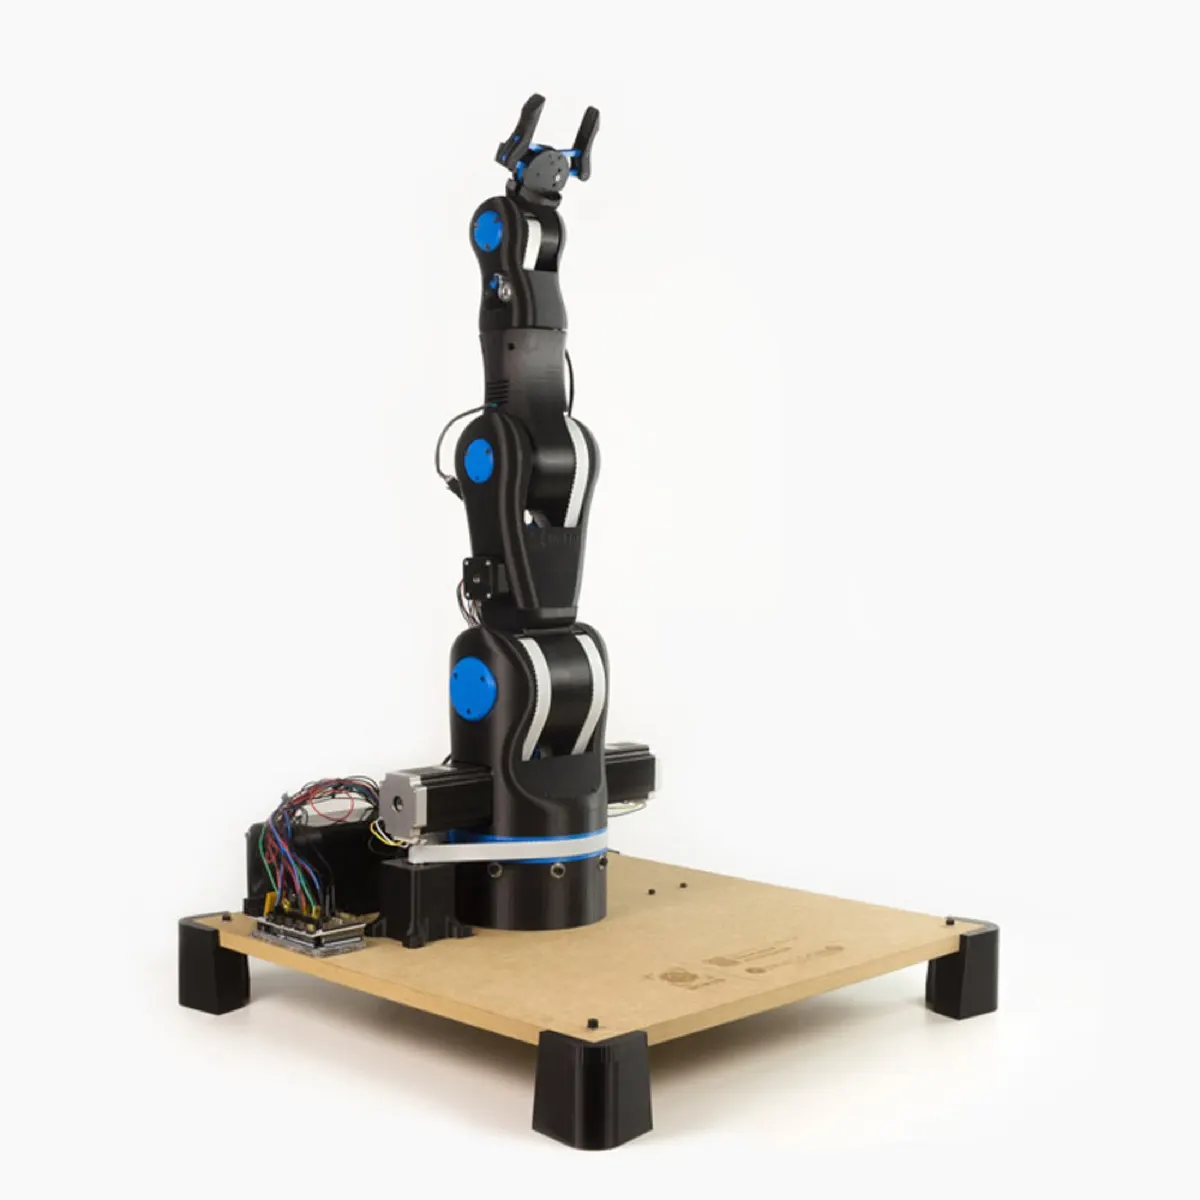 BCN3D MoveoBCN3D Technologies (Spain)DIY (parts only)
Image credits
- Image 1: source (cropped; CC BY-SA 4.0, AngelLM)