Not announcedNo official price or order page as of October 2026. ROBOTIS's docs say specifications "may change as the product approaches launch". ROBOTIS has a US arm (ROBOTIS America), but as a new foreign-made mobile robot it would need FCC Conditional Approval under the July 2026 Covered List rule, so US sales are unclear
Announced onlyRL walkingDYNAMIXEL-Q QDDJetson Orin NXIsaac + MuJoCo RLNot yet on sale
Not releasedShipping: Not released. Not orderable as of October 2026. ROBOTIS has published software, simulation models and docs, and says the hardware is approaching launch, but no date or order page exists. Docs ↗
Overview
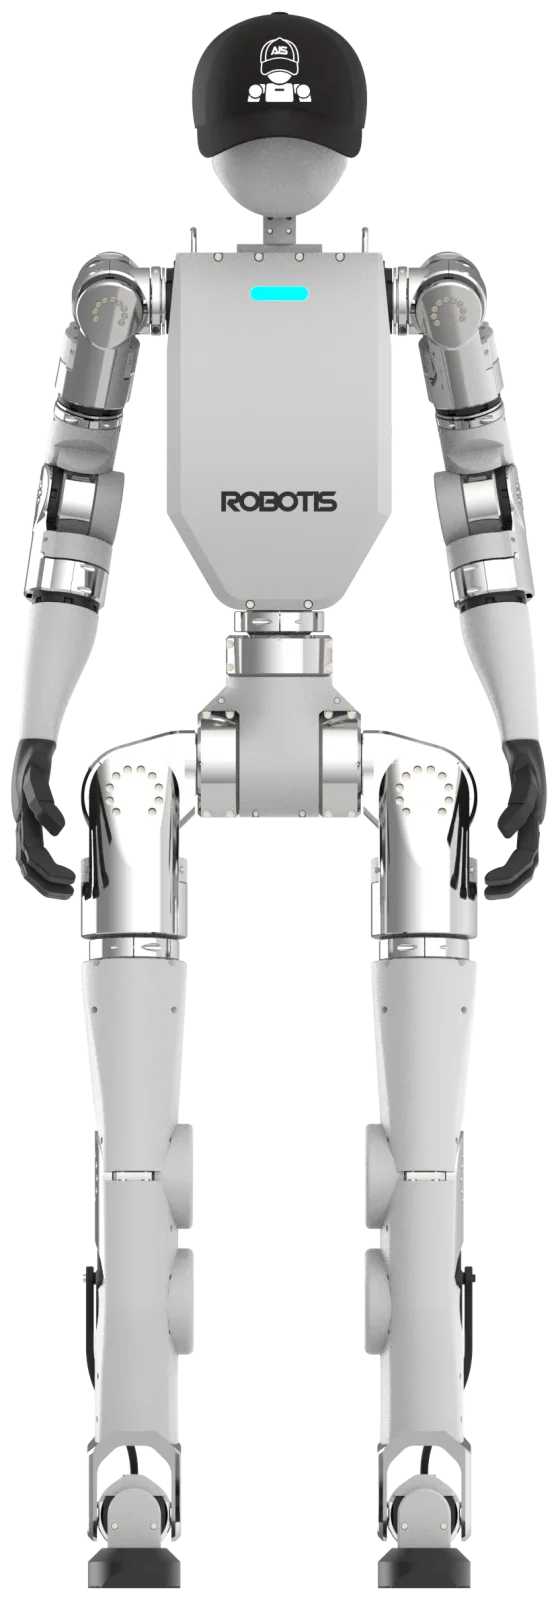
ROBOTIS's open humanoid platform, teased as the K0 in April 2026 and documented since as the K1 production revision. It suits labs that want a kid-size QDD humanoid with ROS 2, a Jetson Orin NX and ready Isaac Lab and MJLab training repos, all from the maker of the OP3. The catch is that it is not on sale yet, there is no price, and the BOM and CAD promised for self-builds have not been released.
Promising open kid-size humanoid from an established maker, but nothing to buy yet.
Specifications
| Category | Bipeds · Kid-size humanoids (≤ 1.3 m) |
|---|---|
| Released | 2026 |
| Country | South Korea |
| Availability | Announced only |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. ROS 2 and a Python SDK expose the robot, so an LLM on a computer could drive it. AI Sapiens docs ↗ |
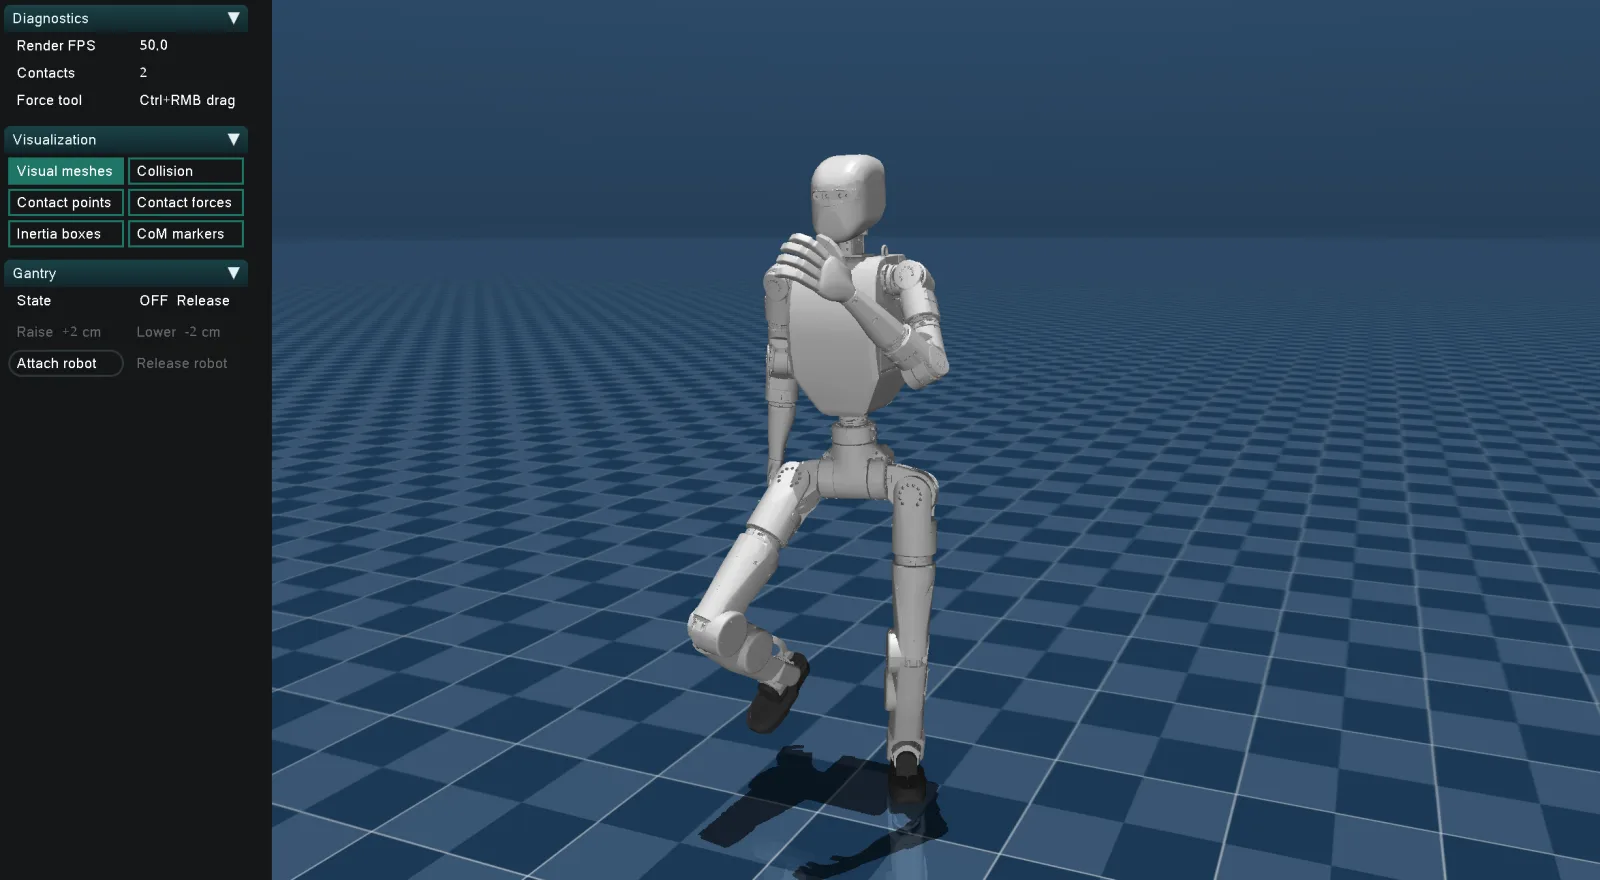
| MuJoCo simulation | Sim-to-real kit · Official K1 MJCF in ai_sapiens with MuJoCo sim2sim of the real control stack, plus cyclo_mjlab (MJLab) training for locomotion and dance policies. cyclo_mjlab ↗ |
| NVIDIA Isaac simulation | Sim-to-real kit · ROBOTIS trains AI Sapiens locomotion in Isaac Sim, and cyclo_lab provides Isaac Lab tasks and Sim2Real workflows. USD model not yet public. cyclo_lab ↗ |
| Gazebo simulation | Maker URDF only · Official K1 URDF in ai_sapiens, no Gazebo package. ai_sapiens ↗ |
| Best for | Professionals & labs |
| Vision sensors | Unknown |
| Actuators | Brushless / direct-drive motors |
| Audio | Unknown |
| Compute type | NVIDIA Jetson |
| Balance type | RL walking |
| Height | 1.355 m (K1, K0 teaser 1.3 m) |
| Weight | 35 kg (K1, K0 teaser 34 kg) |
| Compute | NVIDIA Jetson Orin NX 16GB (up to 157 TOPS), 256 GB SSD, STM32 HAT board |
| Speed | Not published |
| DOF | 23 (6/leg, 5/arm, 1 waist), DYNAMIXEL-Q QDD actuators (K1 has 12× QC060 at 30 N·m max, 11× QC080 at 72.6 N·m max) |
| Sensors | IMU (ICM-42688-P or BNO085), joint encoders. Cameras not published |
| Balance | RL locomotion trained in Isaac Sim / Isaac Lab or MJLab, deployed as ONNX policies by the open ai_sapiens_sim2real runtime, which ships walk and dance policies. Real-robot push recovery not published. |
| SDK | ROS 2 Jazzy (ros2_control, rmw_zenoh) in Docker on Cyclo OS, Python SDK, Apache-2.0 software. BOM, STEP files, PCB files and firmware are listed as coming soon (hardware to be CERN-OHL-P-2.0) |
Ratings & reviews
Ratings and reviews load on the live site.
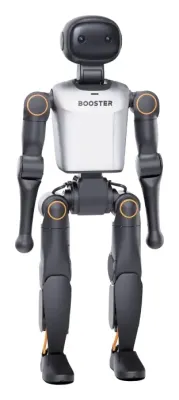 Booster K1
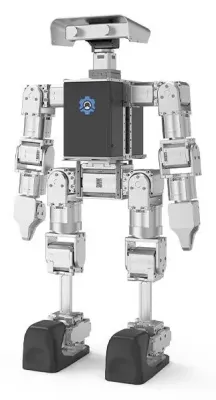 Mini Pi+
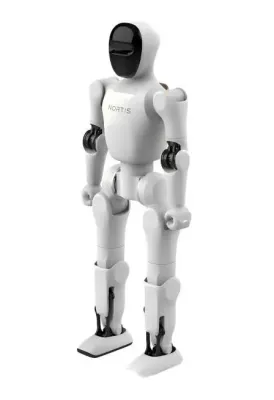 Bumi
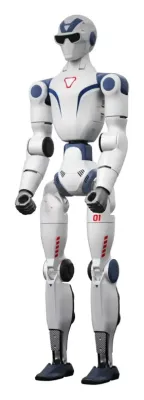 R1 (Air / R1 / EDU)
 N2
 SA01