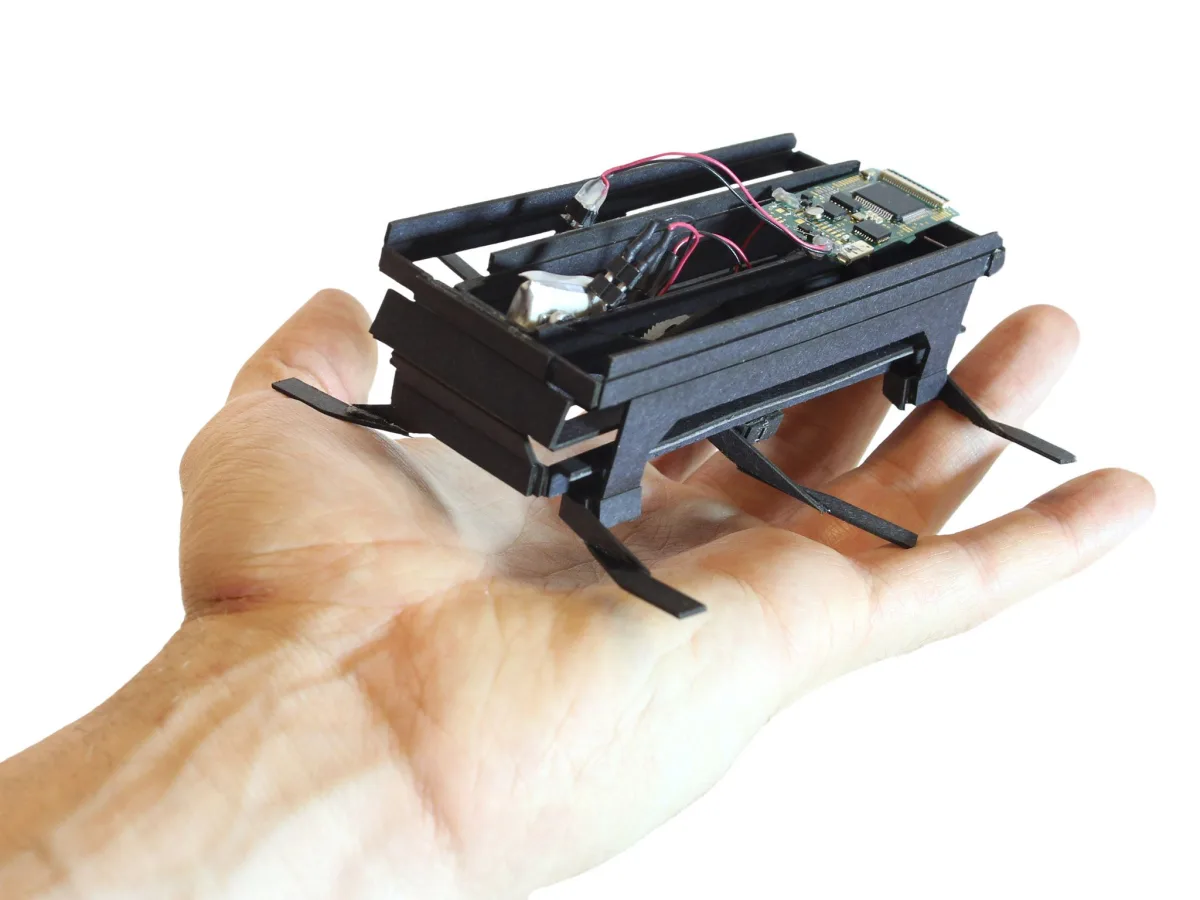
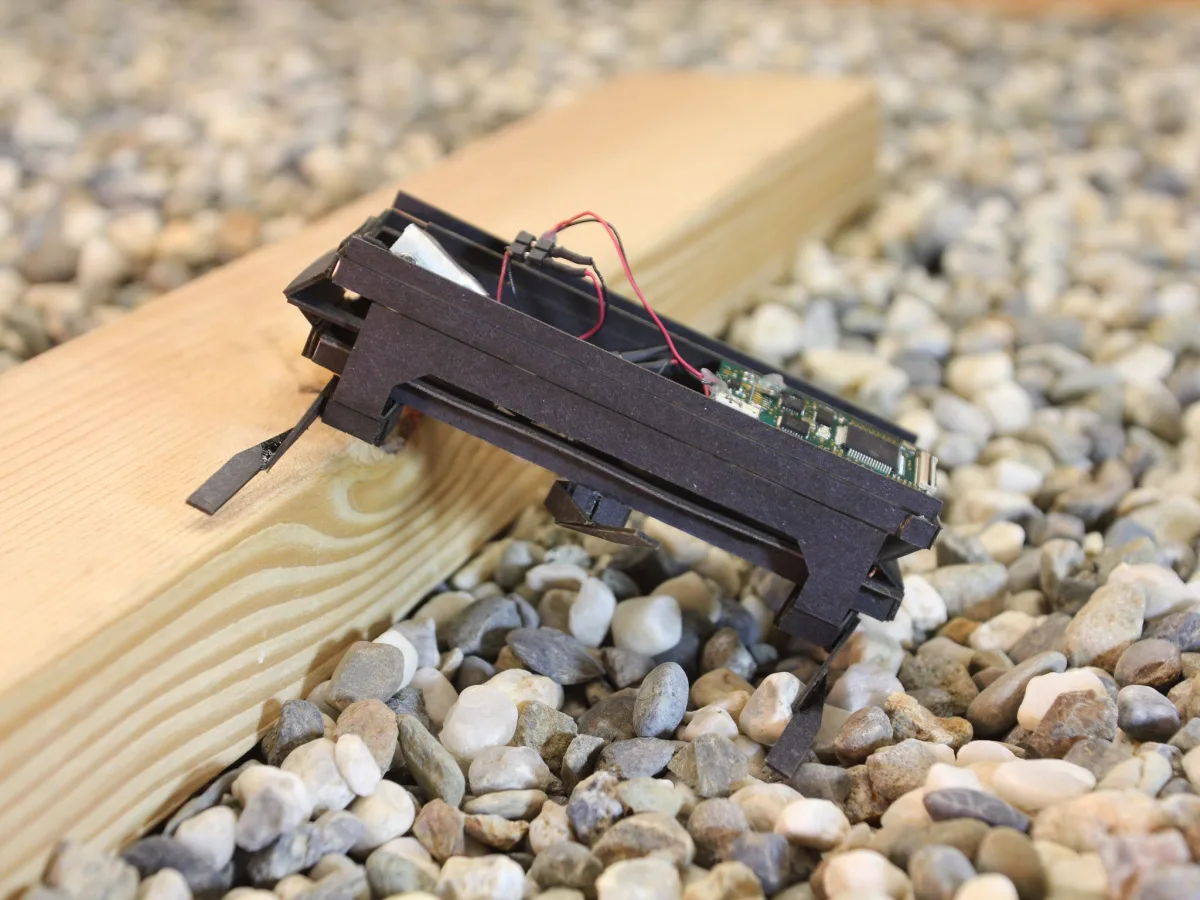
Not for saleUniversity research robot, never sold. Parts cost was about $100 according to IEEE Spectrum's ROBOTS guide (October 2026 check). Year from the IEEE IROS 2009 paper.
Not for sale (research)Palm-sizedFolded cardboard body1.5 m/sSurvives big falls
Not for saleShipping: Not for sale. Not available. A university research prototype. The related Kamigami kits were the consumer offshoot.
Overview
A 16 g, 10 cm hexapod built from folded cardboard-like composite with flexible polymer hinges, using the Smart Composite Manufacturing process. One motor drives all six legs, yet it runs at 1.5 m/s and survived a 28 m drop without damage. DASH co-creator Paul Birkmeyer later co-founded Dash Robotics, whose Kamigami toy robots use a chassis closely based on the DASH design. As a lab prototype it was never sold, and it is no longer an active project.
Specifications
| Category | Multi-legged robots · Research & legacy |
|---|---|
| Released | 2009 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no public SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Compute | 40 MHz microcontroller board on the robot |
| Weight | 16 g (10 cm long) |
| Speed | 1.5 m/s, about 15 body lengths per second |
| Legs / DOF | 2 (one DC motor drives all six legs, one shape-memory-alloy actuator bends the body to steer) |
| Sensors | 3-axis accelerometer, 3-axis gyroscope, optional cellphone camera module |
| SDK | None public. Lab firmware only |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
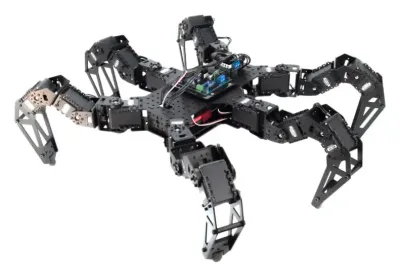 PhantomX AX Hexapod (MK-III)Interbotix Labs / Trossen Robotics (USA)Was $1,095.95 – $1,999.95
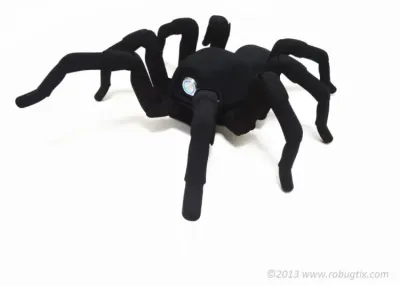 Robugtix T8Robugtix / Amoeba RoboticsWas $2,950
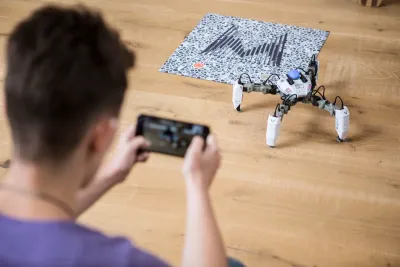 MekaMonReach Robotics (UK)Was $300
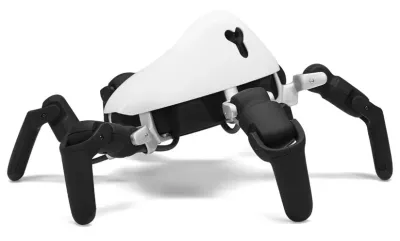 Vincross HEXAVincross (China)Was $999
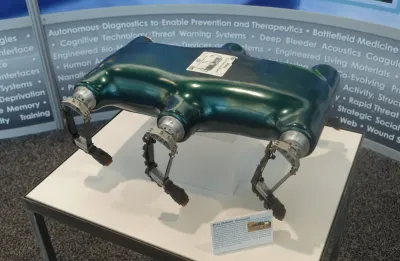 RHexBoston Dynamics / multi-university DARPA project (USA)Not for sale
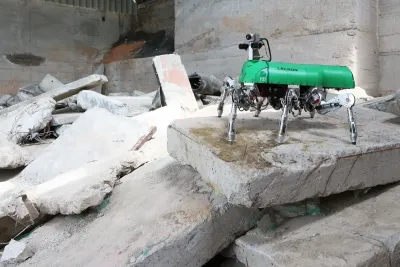 LAURON VFZI Forschungszentrum Informatik (Germany)Not for sale