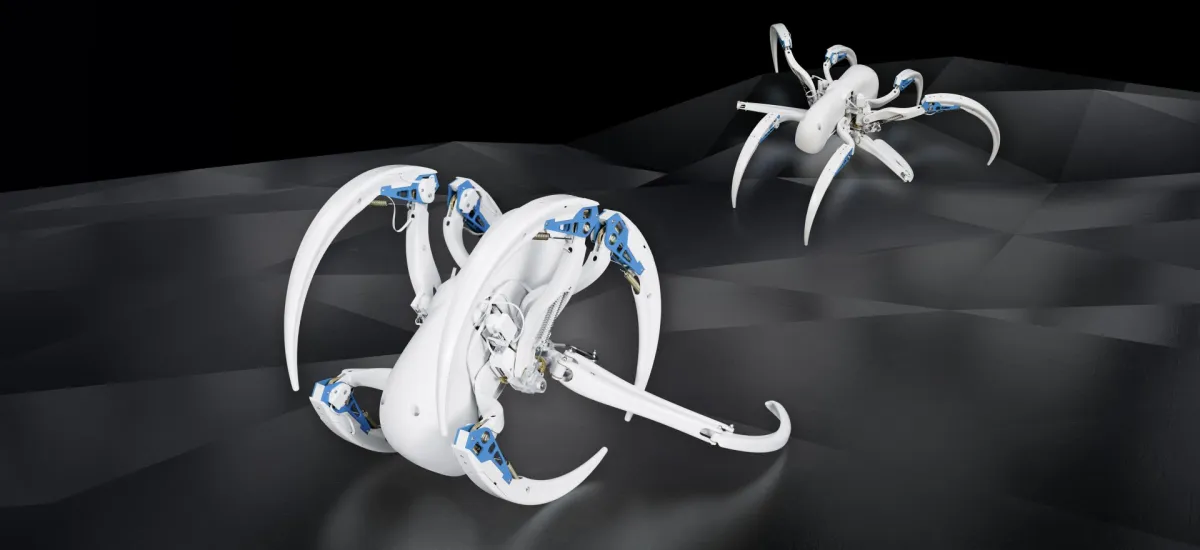
Not for saleResearch demonstrator. Festo's brochure is dated March 2018.
Not for sale (research)Walks and rolls8 legsFlic-flac spiderSTM32
Not for saleShipping: Not for sale. Never sold.
Overview
A spider robot modelled on the Moroccan flic-flac spider, which Professor Ingo Rechenberg of TU Berlin discovered in 2008 and later helped turn into this machine. It walks with a tripod gait on six legs, then curls those legs into a 267 mm wheel and uses the remaining two to push off and keep itself rolling. Self-locking worm gears mean it only spends energy while moving, not while standing. A showcase project shown alongside the BionicFlyingFox in 2018, never a product.
Specifications
| Category | Multi-legged robots · Research & legacy |
|---|---|
| Released | 2018 |
| Country | Germany |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Compute | STM32F4 microcontroller, 866 MHz radio, controlled from a tablet |
| Weight | Not published (up to 570 mm long, 796 mm wide, 238 mm high) |
| Speed | Not published (rolls much faster than it walks, climbs slopes up to 5%) |
| Legs / DOF | 15 DOF across 8 legs, from 14 self-locking worm-gear units and 1 servo motor |
| Sensors | Bosch BNO055 absolute orientation sensor (IMU) |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
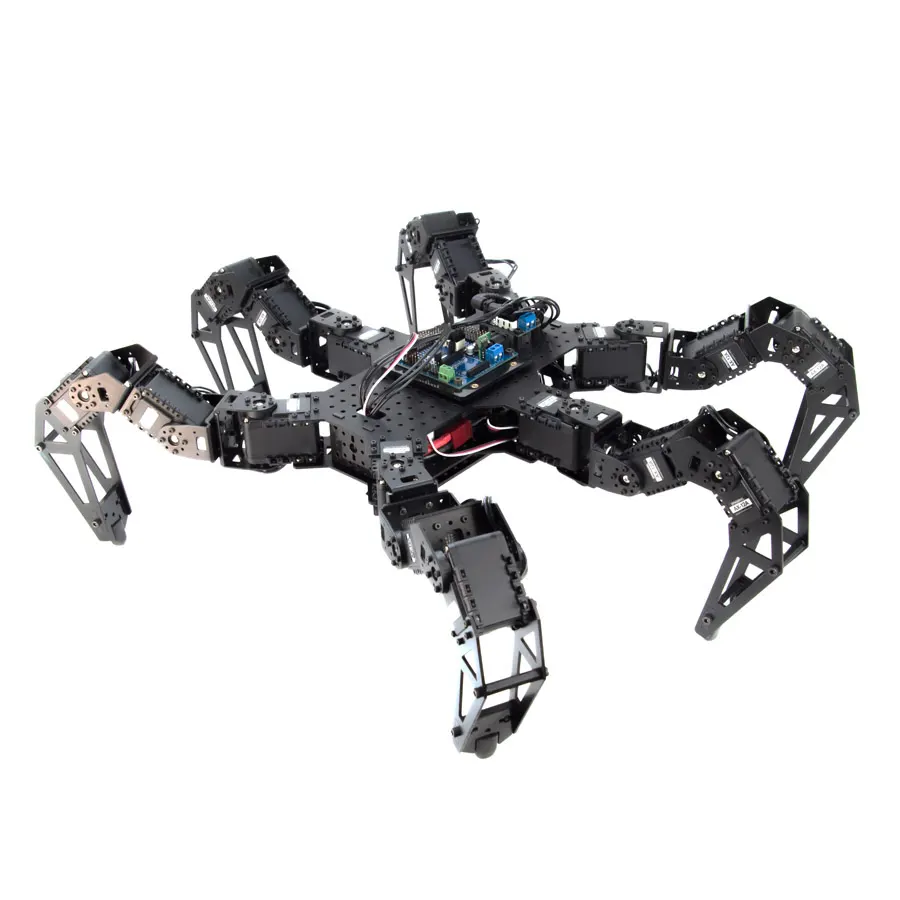 PhantomX AX Hexapod (MK-III)Interbotix Labs / Trossen Robotics (USA)Was $1,095.95 – $1,999.95
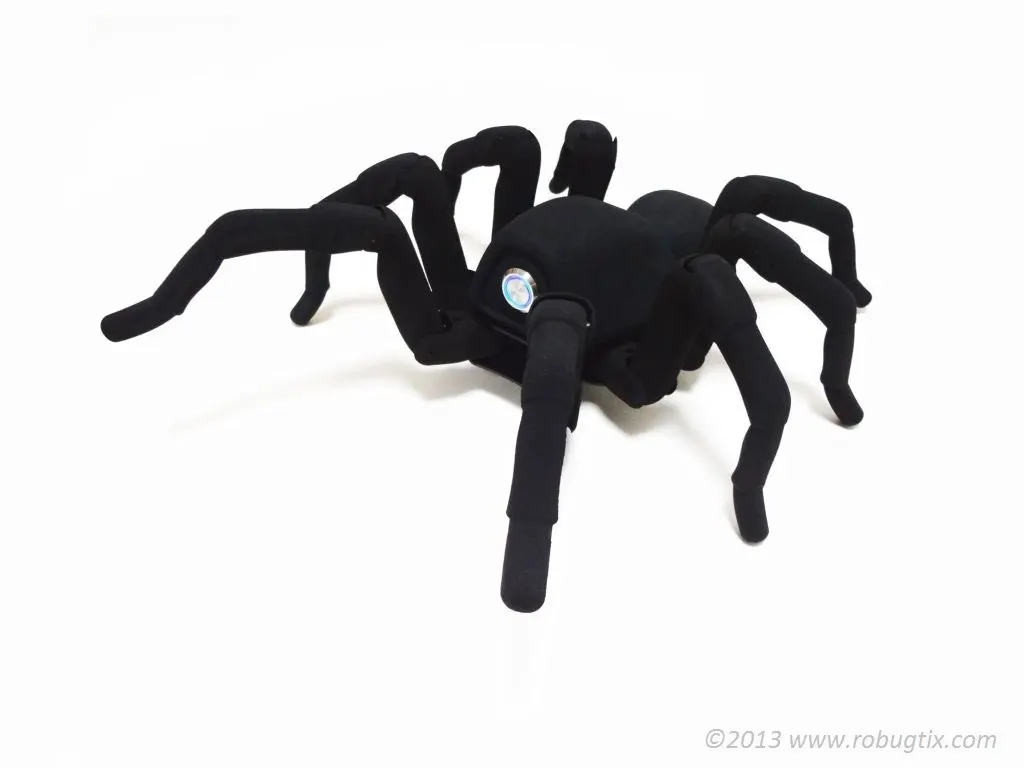 Robugtix T8Robugtix / Amoeba RoboticsWas $2,950
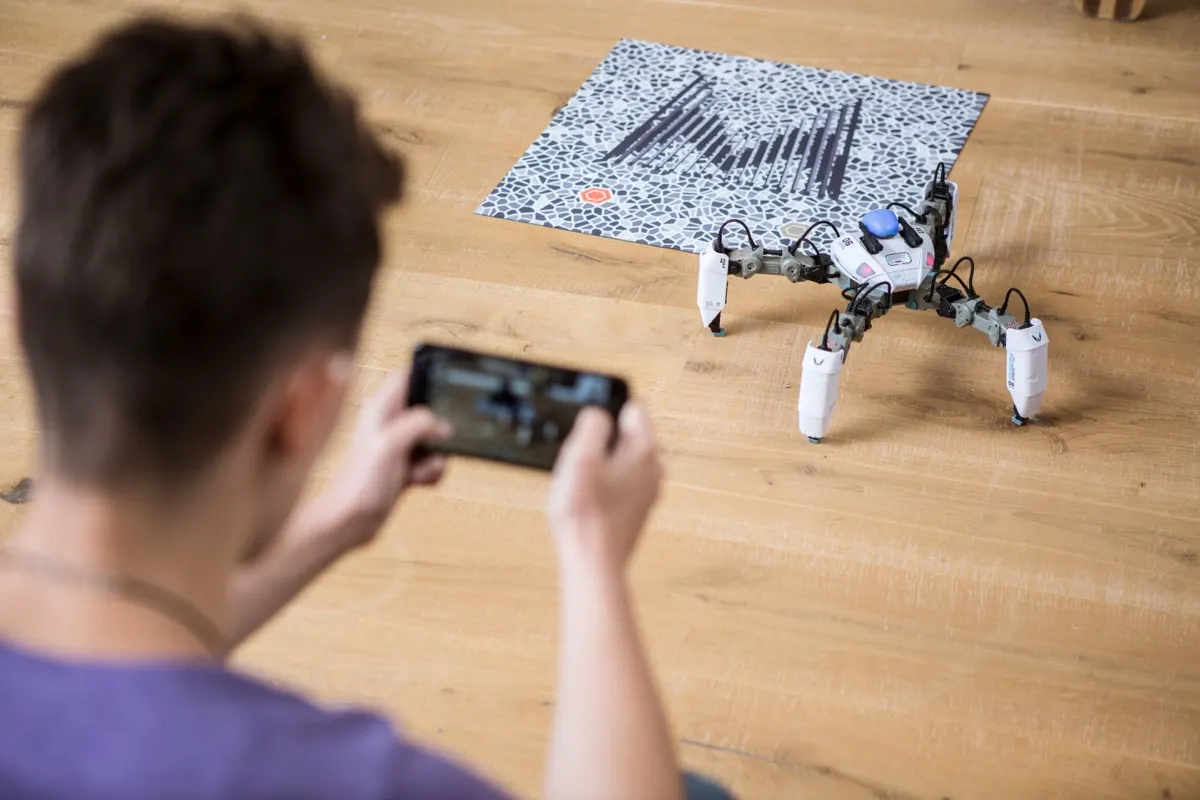 MekaMonReach Robotics (UK)Was $300
 Vincross HEXAVincross (China)Was $999
 RHexBoston Dynamics / multi-university DARPA project (USA)Not for sale
 LAURON VFZI Forschungszentrum Informatik (Germany)Not for sale
Image credits
- Image 1: source (Festo press image, via Wayback Machine, rights with manufacturer)