Not for saleUniversity research prototype, first shown in 2012 and described in an ICRA 2013 paper.
Not for sale (research)Not programmableFly + rollRolling cageQuadrotor
Not for saleShipping: Not for sale. A research prototype that was never sold.
Remote control: Not possible. Research prototype.
Overview
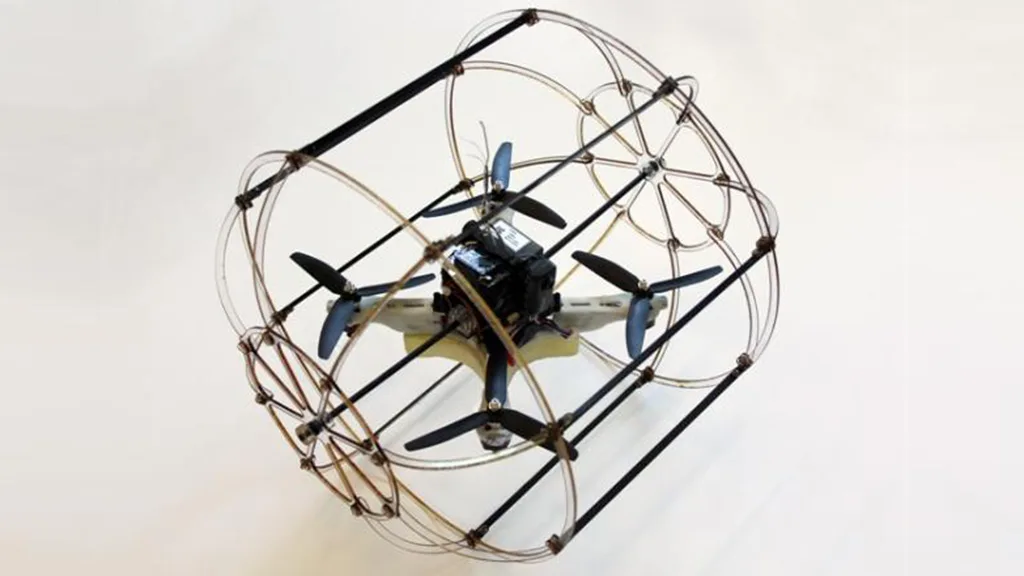
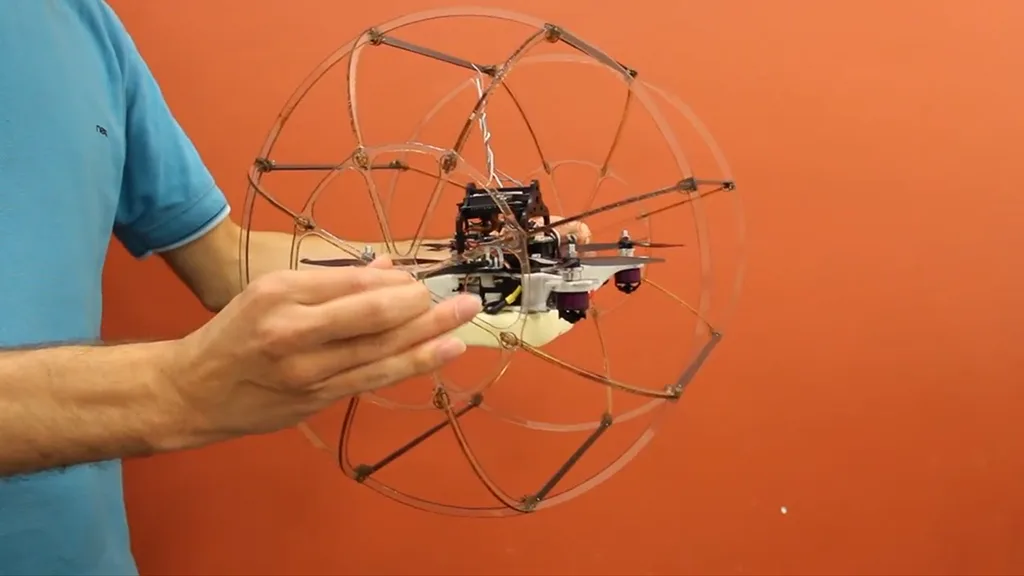
HyTAQ is a small quadrotor hinged inside a cylindrical cage of polycarbonate and carbon fiber. On the ground the rotors pitch forward and push the cage along like a wheel, and when it meets an obstacle it flies over it. Rolling only has to overcome rolling resistance, so in 2012 tests it ran 27 minutes rolling against about 5 minutes in the air. The cage also protects the propellers in crashes. NASA JPL's Team CoSTAR used a HyTAQ-style cage in an early version of its Rollocopter.
Specifications
| Category | Drones · Fly + drive or walk |
|---|---|
| Released | 2012 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Unknown |
| Remote control | Not programmable |
| Size | Not published. The cage is a cylinder of polycarbonate and carbon fiber, and the patent analysis assumes a cage mass of about 25% of the quadrotor. |
| Drive | Quadrotor with four 11.1 V brushless motors (1700 kV, 75 W) and 5 x 3 in three-blade propellers. A free-spinning cylindrical cage is joined to the quadrotor by a shaft with two rotating joints, so the same rotors fly it and push the cage along the ground. |
| Compute | Not published |
| Vision | Onboard camera (model not published) |
| Lidar | None |
| Sensors | Not published |
| Runtime | About 5 min flying versus 27 min rolling in the 2012 tests. The patent reports 50 min of rolling on linoleum. 3S 1350 mAh LiPo battery. |
| Speed | Most efficient rolling speed about 3 m/s. Top speed not published. |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 LEONARDO (LEO)Autonomous Robotics and Control Lab (Soon-Jo Chung), Caltech (USA)Not for sale
 SPIDARJSK Lab (now DRAGON Lab), University of Tokyo (Japan)Not for sale
 RAVENLaboratory of Intelligent Systems (LIS), EPFL (Switzerland)Not for sale
 Husky CarbonSiliconSynapse Lab (Alireza Ramezani), Northeastern University (USA)Not for sale
 M4 (Multi-Modal Mobility Morphobot)Caltech CAST and Northeastern University (USA)Not for sale
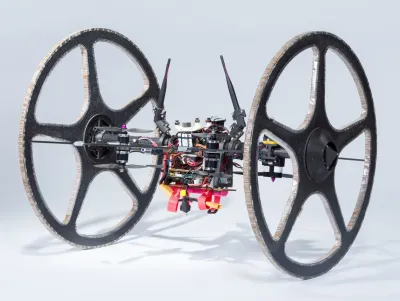 RollocopterTeam CoSTAR, NASA Jet Propulsion Laboratory (USA)Not for sale