Not for saleUniversity research prototype, first described in a 2023 Nature Communications paper.
Not for sale (research)Not programmableWheels become rotors8 modesSelf-righting
Not for saleShipping: Not for sale. A research prototype that was never sold.
Remote control: Not possible. Research prototype.
Overview
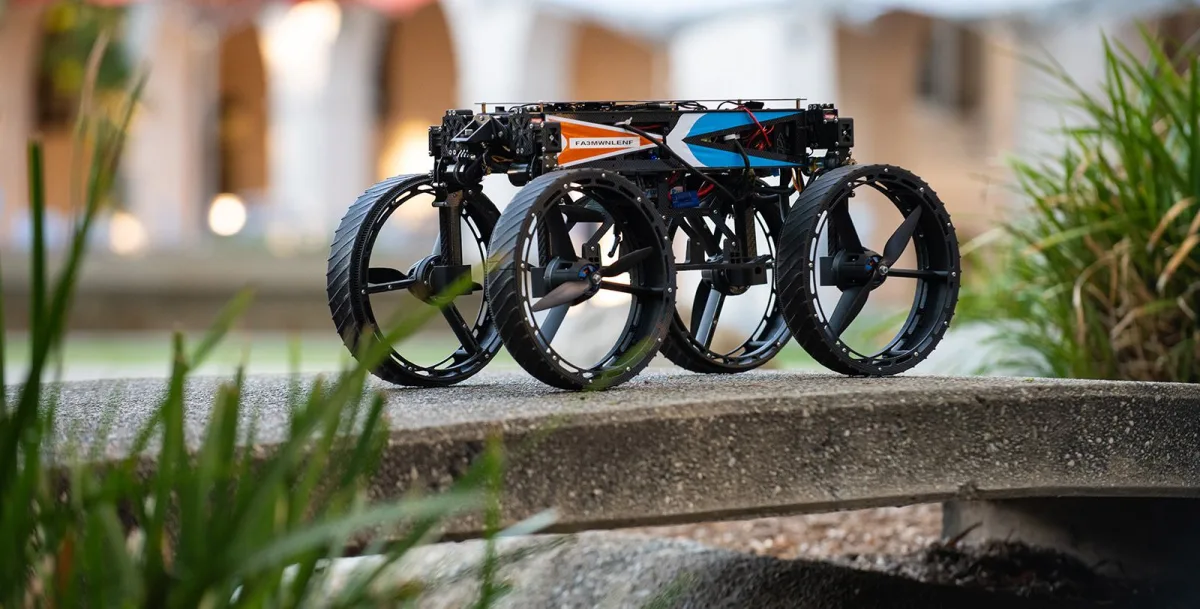
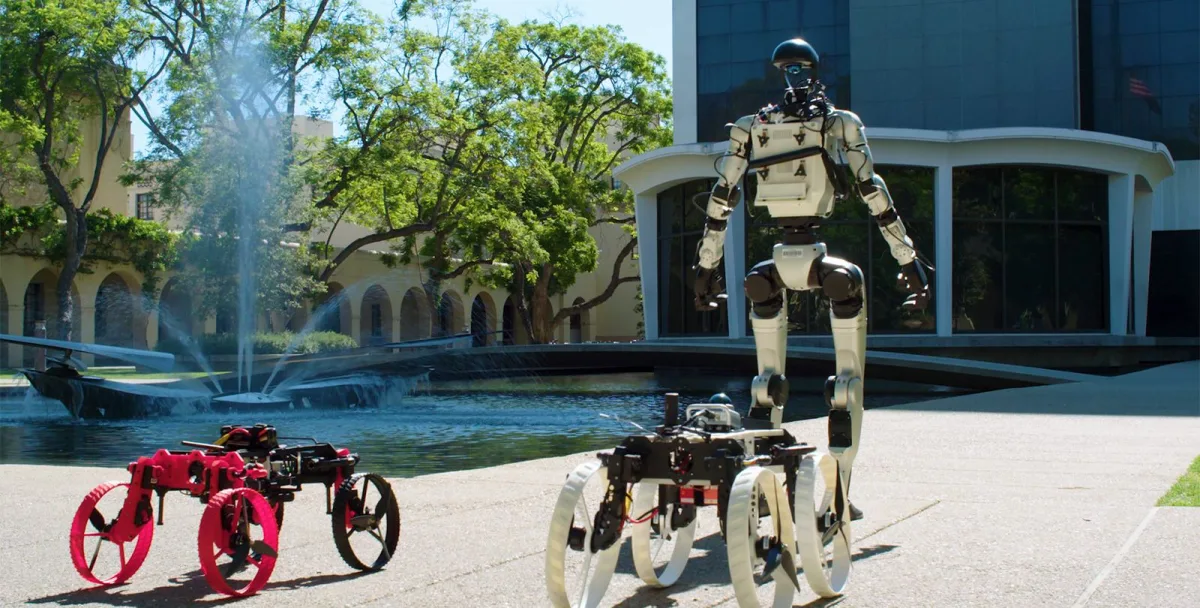
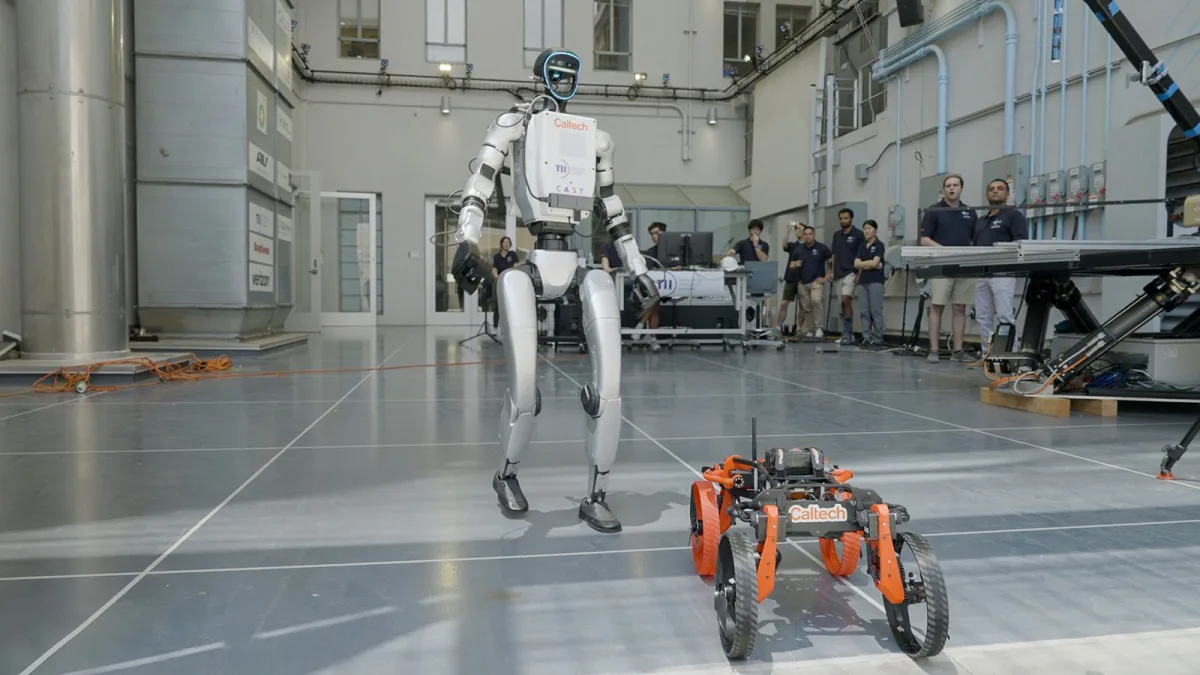
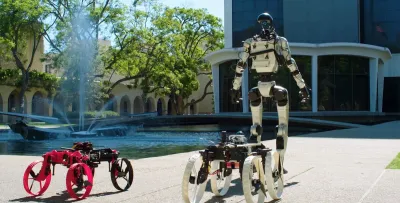
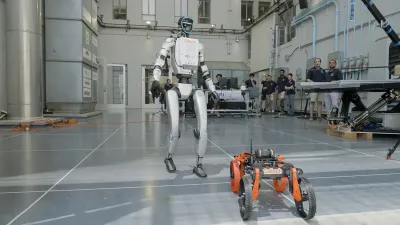
M4 is a four-wheeled research robot whose propeller shrouds are also its wheels, so it can drive, then swing its legs up and fly as a quadcopter. It can also crawl, balance upright on two wheels to look around, tumble over large obstacles and climb steep slopes with thruster help. A follow-up, ATMO (Caltech, 2025), changes from drone to car shape in mid-air before landing. In a 2025 Caltech and TII demo, a Unitree G1 humanoid carried M4 on its back and launched it.
Specifications
| Category | Drones · Fly + drive or walk |
|---|---|
| Released | 2023 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | None · No built-in LLM and no SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | Depth camera |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | NVIDIA Jetson, Arduino / ESP32 / microcontroller |
| Remote control | Not programmable |
| Size | About 0.7 m long, 0.35 m wide and tall in driving mode (1.0 m tall when balancing on two wheels), about 6 kg |
| Drive | Four shrouded propellers whose shrouds double as 0.25 m wheels, each with its own geared wheel motor. Eight hip servos swing the legs to switch between driving, flying, walking, balancing and tumbling. |
| Compute | Nvidia Jetson Nano for path planning, plus an STM32H7 flight controller and a SAM3X8E main controller |
| Vision | Intel RealSense D455 stereo depth camera |
| Lidar | None |
| Sensors | IMU, motor encoders, current and voltage sensors |
| Runtime | Not published |
| Speed | Not published. Climbs slopes up to 45 degrees with thruster help. |
| SDK | None public. Simulation and path-planning code available from the authors on request. |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 LEONARDO (LEO)Autonomous Robotics and Control Lab (Soon-Jo Chung), Caltech (USA)Not for sale
 SPIDARJSK Lab (now DRAGON Lab), University of Tokyo (Japan)Not for sale
 RAVENLaboratory of Intelligent Systems (LIS), EPFL (Switzerland)Not for sale
 Husky CarbonSiliconSynapse Lab (Alireza Ramezani), Northeastern University (USA)Not for sale
 RollocopterTeam CoSTAR, NASA Jet Propulsion Laboratory (USA)Not for sale
 HyTAQRobotics Lab, Illinois Institute of Technology (USA)Not for sale